Minkowski addition for collision detection
ID: minkowski-addition-for-collision-detection

Suppose a robot occupies a closed set relative to its chosen reference point, and a closed obstacle occupies . Keep the robot's orientation fixed and allow only translations. At reference position , its occupied set is . If touching counts as collision, the forbidden positions in this configuration space are exactlyThe minus sign reflects the robot through its reference origin: solving gives . Thus collision checking for a moving shape becomes checking whether one point lies in a fixed Minkowski sum. Steven M. LaValle derives this translational configuration space construction in Planning Algorithms, section 4.3.2, equation 4.37 and Example 4.13.
For a concrete toy example, take the robot rectangle with its reference point at the lower-left corner, and obstacle rectangle . Their collision region is the rectangleFor example, is forbidden: meets in , of area . At there is just corner contact, which our convention also forbids. Using instead would wrongly miss both reference positions. Only when , as for an origin-centred disk, does the reflection leave the robot set unchanged.
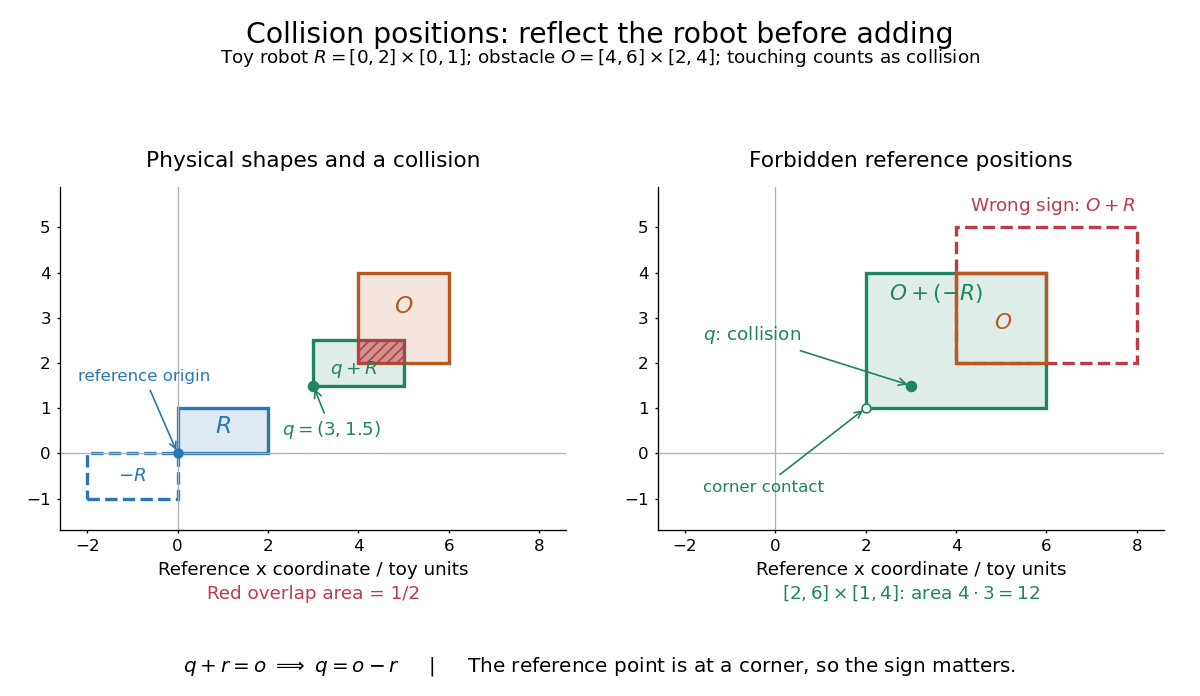
Toy translational collision geometry: a corner-referenced robot requires , of area , and its positive Minkowski sum puts forbidden positions on the wrong side
. Details. 
The same calculation handles bounded additive uncertainty. If the actual reference position is for any , the union of possible occupied sets is . There exists an allowed error causing contact exactly whenConsequently avoiding this set guarantees avoidance for every in this model. For , the example's forbidden region becomes , with area . Here because the error bounds are symmetric; a one-sided error set must still be negated. This is a worst-case geometric bound, not a probability of collision. Rotating the robot requires an orientation-dependent Minkowski sum for each orientation.
New to topics? Read the docs here!