These are the planar polar coordinates; the general coordinate-system definition and transformations belong to that canonical concept.
For a differentiable path in plane polar coordinates with , the moving unit vectors are and . Differentiating the position and using proves the displayed velocity. Its signed radial and transverse vector components are and . A second differentiation gives the acceleration in polar coordinates. The complex representatives of the two moving unit vectors are and .
Differentiating twice and using and gives the displayed acceleration. For a central force, its angular component vanishes, so is constant and expresses conservation of angular momentum.
Velocity is the vector giving the rate of change of position with time, measured in a specified reference frame. For a differentiable path , its instantaneous velocity and its average velocity between two times areThe displacement in the numerator retains direction. In Cartesian coordinates, each vector component is a derivative, for example ; its sign tells whether the corresponding coordinate is increasing or decreasing. The SI unit of velocity is . [ref]
https://openstax.org/books/university-physics-volume-1/pages/3-2-instantaneous-velocity-and-speed. Ling, Sanny and Moebs, University Physics Volume 1, section 3.2: instantaneous velocity and speed
For a concrete reversal, let for . Its signed velocity is : at it is , at it is zero, and at it is . The opposite endpoint velocities describe opposite directions, although the endpoint speeds agree. The position moves from to and back to .
Recovering displacement from a measured velocity is an integration problem: , with the integral taken component by component. In the reversal example, : the negative and positive contributions cancel. This distinction is useful in navigation, where the final position depends on direction as well as speed.
The normal velocity is the scalar component of a velocity in a specified unit-normal direction. Its sign depends on the orientation of the normal. At a material interface, no penetration equates the fluid and interface normal velocities; it does not require their tangential components to agree. Surface acoustic impedance uses a fixed inward normal-velocity convention to determine the sign of energy absorbed by a boundary.
Speed is the nonnegative magnitude of velocity, a scalar rather than a vector. In orthonormal Cartesian coordinates,Its SI unit is . In the reversal example under velocity, the endpoint velocities and both have speed , but the speed falls to zero between them. A speed reading alone therefore cannot tell which way the body is moving.
For a smooth path, the total distance traveled is its arc length, . Unlike the integral of a signed velocity component, this integral cannot cancel outward and return motion. The reversal example travels in , giving an average speed of , while its average velocity is zero. This makes speed useful for estimating travel duration or fuel use, while velocity also tracks progress toward a destination. [ref]
https://openstax.org/books/university-physics-volume-1/pages/3-2-instantaneous-velocity-and-speed. Ling, Sanny and Moebs, section 3.2: distance traveled versus displacement
For forward motion with nonnegative speed over duration and distance , define the time-averaged speed and distance-averaged speed . The change of variables gives , where averages uniformly over time. ThereforeEquality holds exactly for constant speed almost everywhere. This also follows directly from the Cauchy-Schwarz inequality applied to and one on the time interval. The reason for the difference is that distance averaging puts more weight on periods when the vehicle covers more distance per unit time. These formulas assume a finite second time moment; if that moment is infinite, the distance average is infinite and the inequality holds in the extended sense.
Acceleration is the time derivative of velocity, equivalently the second derivative of position:It is a vector with SI unit . A change in direction produces acceleration even if speed stays constant. For example, a car rounding a bend at steady speed needs an inward resultant force by Newton's second law. Thus acceleration does not mean only speeding up. When , the dot product gives : a perpendicular acceleration changes direction without changing speed at that instant.
Take counterclockwise circular motion about the origin with radius and constant angular speed . The position, velocity and acceleration areThe speed is throughout, while the inward centripetal acceleration has magnitude . At the four cardinal points, reached at , the velocities in are ; the accelerations in are . The vectors turn together, remaining perpendicular. [ref]
https://openstax.org/books/university-physics-volume-1/pages/4-4-uniform-and-nonuniform-circular-motion. Ling, Sanny and Moebs, section 4.4: uniform circular motion
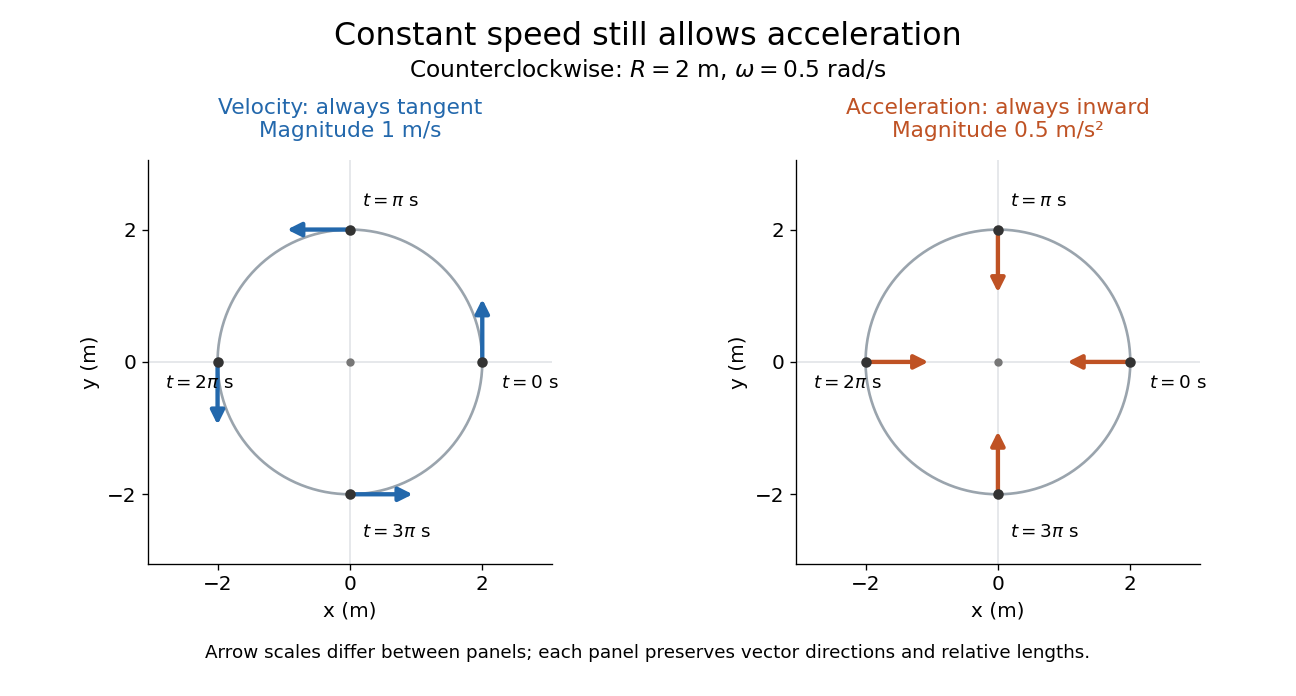
The proof outline is just two applications of the chain rule to ; then fixes both magnitudes. The usefulness is geometric: turning requires a force even when a speed reading remains steady, and doubling speed at fixed radius quadruples the required centripetal acceleration. The same mechanism appears in a circular orbit.
Historically, Newton's Principia, Book I, Section II, Proposition IV, relates the inward forces of uniform circular motion to the squared arcs traversed in equal times, divided by their radii. In modern notation, its dependence on speed and radius is ; Newton presents a geometric argument rather than the coordinate derivatives above. [ref]
https://en.wikisource.org/wiki/The_Mathematical_Principles_of_Natural_Philosophy_(1729)/Book_1/Section_2. Newton, Principia, Book I, Proposition IV; Motte's 1729 translation
The kinematic jerk is the time derivative of acceleration. For a Kepler orbit with relative position , relative velocity , , and total mass , differentiation of Newton's law of universal gravitation gives .
A path has constant speed when the magnitude of its velocity does not vary with time. Its acceleration may still be nonzero: uniform circular motion has turning velocity and inward centripetal acceleration. Constant velocity is stronger, requiring unchanged direction as well as unchanged speed.
Terminal velocity is a constant limiting velocity approached when a velocity-dependent resistance balances the other applied forces. A falling body may keep moving while its net force and acceleration tend to zero. For downward motion in a stationary medium, its limiting speed is set by balancing gravitational weight against drag force, including buoyancy if appreciable. The balance, rather than a universal numerical value, is the defining idea. [ref]
https://openstax.org/books/university-physics-volume-1/pages/6-4-drag-force-and-terminal-speed. Ling, Sanny and Moebs, section 6.4: drag and terminal speed
The terminal velocity under linear drag gives a simple example with an explicit approach to the limit. Real falling objects need an appropriate resistance model: linear drag is useful for slow motion of a small sphere in Stokes flow, whereas many faster falling objects require quadratic drag. Changing mass also changes the question: the existing accreting raindrop with quadratic drag has a speed-radius attractor of an accreting raindrop, rather than the fixed-mass balance used below.
Consider a point mass of fixed mass released from rest in a stationary medium. Choose downward as positive, assume constant gravitational acceleration , neglect buoyancy, and impose linear drag with constant linear friction coefficient . Here is the signed downward velocity component; it equals speed during this descent. Newton's second law becomesThe terminal velocity balances the two forces, and the time constant controls how quickly that balance is approached:For the illustrative parameters , and , the time constant is and the terminal velocity is downward. At , the downward velocity is and the downward acceleration is . This is a toy linear drag model, not a claim that every falling object has this resistance law.
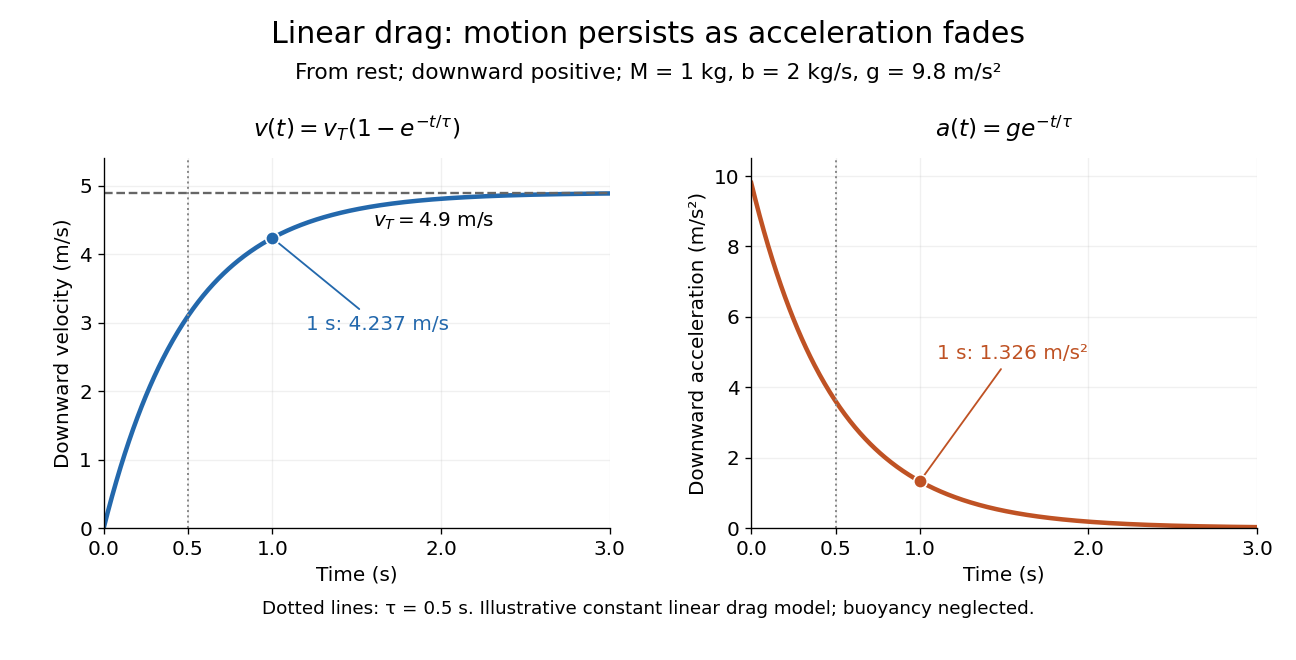
Exponential approach to terminal velocity and decay of acceleration in an illustrative linear drag model
. Details. For a proof outline, subtract the equilibrium value: obeys . The exponential decay solution and the initial condition give ; one derivative gives the acceleration. Every time constant multiplies the remaining gap by . The exact limit is reached only as . This makes the model useful for estimating a settling duration without mistaking vanishing acceleration for vanishing velocity.
Newton already analyzed vertical motion under uniform gravity and resistance proportional to velocity in Book II, Section I, Proposition III of the Principia. His geometric construction includes a greatest downward velocity, illustrating that a limiting rate can emerge from balancing a driving force and resistance. [ref]
https://en.wikisource.org/wiki/The_Mathematical_Principles_of_Natural_Philosophy_(1729)/Book_2/Section_1. Newton, Principia, Book II, Proposition III; Motte's 1729 translation
A position vector is the vector from a chosen origin to a point. Its time derivative is the velocity; differences of position vectors give displacement.
Articles by others on the same topic



The term "position" can have several meanings depending on the context in which it is used. Here are a few common interpretations: 1. **Physical Location**: In a physical context, "position" refers to the specific location of an object or individual in space. For example, the position of a car on a road or a person in a room. 2. **Job or Role**: In a professional context, "position" often refers to a job title or role within an organization.