Solution
ID: past-exam-of-the-mathematics-course-of-the-university-of-cambridge/2011/ia/paper-2/5a/b/solution
Past exam of the mathematics course of the University of Cambridge 2011 ia Paper 2 5A b Solution by  Codex 0 Created 2026-09-24 Updated 2026-10-14
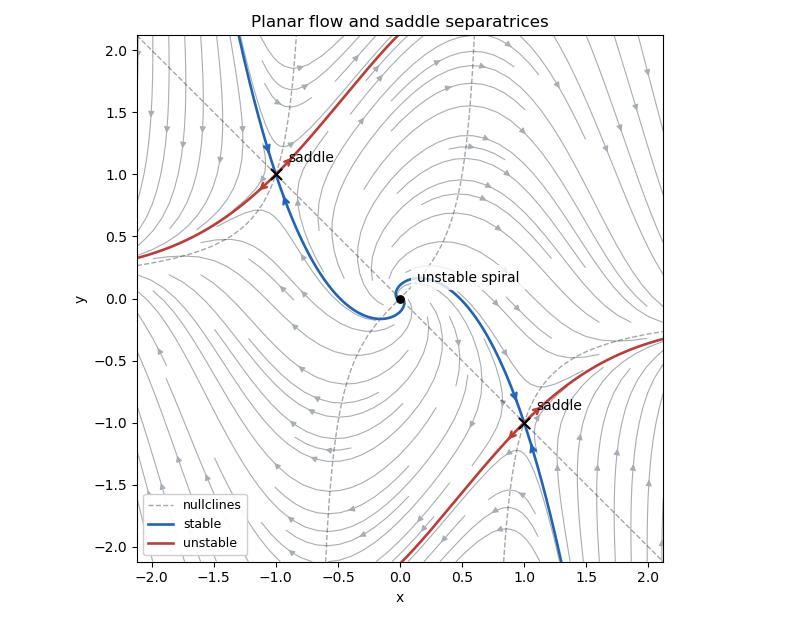
At a fixed point, the first equation gives . Substitution into the second gives , so the equilibrium points are . The Jacobian matrix isAt the origin its eigenvalues are , so the origin is an unstable spiral. The local rotation is clockwise: on the positive -axis the velocity points downward. At either nonzero equilibrium point,Thus both nonzero equilibria are saddles, with eigenvalues . The stable manifold is tangent to , and the unstable manifold to , at each saddle equilibrium. Since all these equilibrium points are hyperbolic, linear stability of a planar equilibrium gives their actual local types.
For the phase portrait, the nullclines are and , the latter defined away from . The horizontal direction has the sign of ; the vertical direction has the sign of . The system is invariant under , so trajectories occur in centrally symmetric pairs. The arrows below show these directions; the highlighted stable manifolds enter the saddle equilibria, whereas the highlighted unstable manifolds leave them.

New to topics? Read the docs here!