Stereoscopic triangulation reconstructs a scene point from corresponding image positions and known camera geometry. Each image position determines a viewing direction. Two correctly matched views constrain the point to lie on both viewing rays; one view alone leaves its position along a ray undetermined.
For an ideal aligned pair, put the left camera at the origin and the right one at in a Cartesian coordinate system, with their axes pointing in the positive direction. Assume a common focal length , square pixels, corrected distortion and image coordinates measured from aligned principal points. Forward perspective projection givesThe stereo disparity therefore determines all three coordinates:Here is depth along the camera axis; the Euclidean distance from the left camera is instead . If use pixels and the camera baseline uses metres, the recovered coordinates use metres. Without a known length scale, the images alone do not determine metric size.[ref]
Camera Calibration and 3D Reconstruction by OpenCV. Detailed Description, camera intrinsic matrix and the distortion-free pinhole projection equations
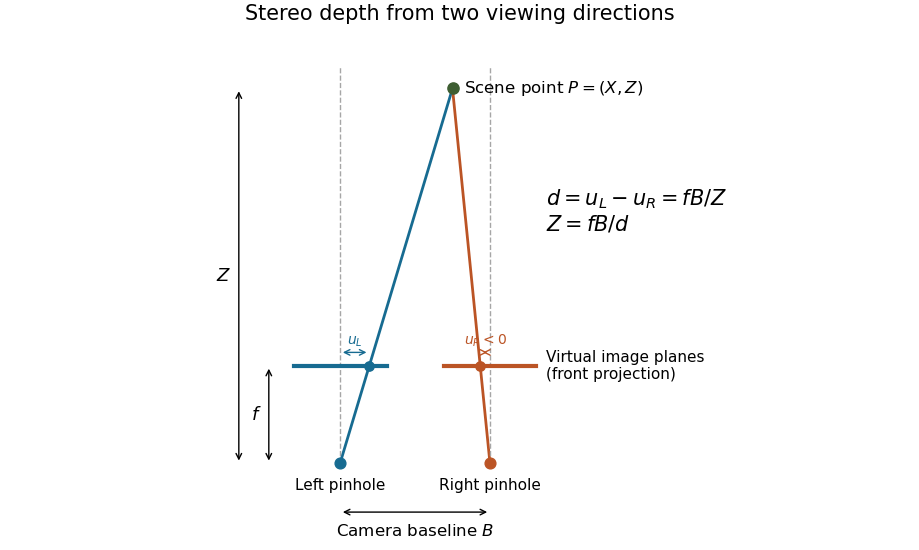

Real cameras require calibration before these simplified equations apply. Stereo rectification transforms the images to an aligned geometry. With noisy measurements, viewing rays need not intersect exactly; minimizing reprojection error instead seeks a point whose projected positions agree as closely as possible with the observations. Reconstruction also depends on stereo correspondence: a mathematically precise intersection of mismatched viewing directions can still describe the wrong scene point.[ref]
What Is Stereo Reconstruction? by MathWorks. Stereo Camera Calibration; Stereo Image Rectification; Disparity Map Computation; 3-D Scene Reconstruction
A reprojection error compares an observed image point with the position predicted by projecting a reconstructed scene point through a camera model. If is an observed position and its prediction, the residual is . One possible aggregate is the per-point root mean square Euclidean norm:Coordinates in pixels give an error in pixels. Least squares instead minimizes the associated sum of squares; normalization conventions should be stated when reporting a summary.[ref]
Camera Calibration in the OpenCV-Python tutorials. Re-projection Error, projecting known points and comparing image positions
For an observation and prediction , the Euclidean norm of the residual is 5 pixels. Camera calibration can adjust model parameters to reduce many such residuals, while stereoscopic triangulation can adjust a reconstructed point with the camera parameters fixed. Low reprojection error tests agreement with observations under that model; incorrect stereo correspondence or an incorrect camera baseline can still produce wrong scene geometry.
Articles by others on the same topic
There are currently no matching articles.