
The Bellman inequalities turn local directed edge checks into a global certificate for the shortest path problem. Here the convention is all-to-one: every journey ends at a fixed vertex , and is the cost of the original directed edge . Work in a finite directed graph with finite real costs. Write for candidate labels, normalized by , on the vertices that can reach . A feasible potential means precisely that these finite labels satisfyfor every directed edge within that set. These labels give lower bounds on costs to . A discovered directed path of cost instead gives an upper bound. The following constructed graph shows both bounds and the exact distances between them; its weights are illustrative costs, not measured travel data.
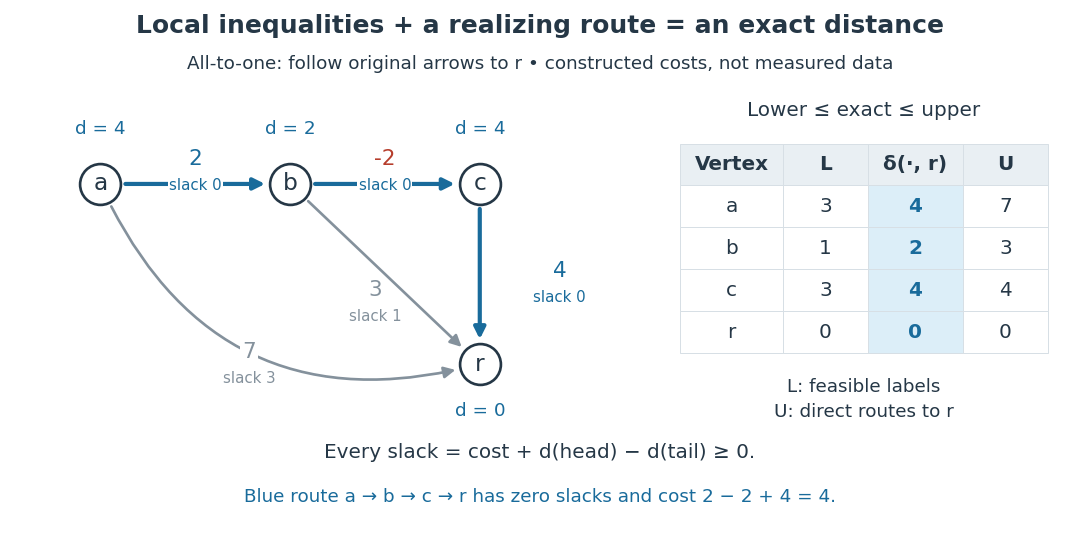

The arrows in the picture point toward the destination, whereas edge relaxation propagates an improved label in the opposite direction: an improved can lower . In the pictured graph, the directed paths from to cost , , and . Thus . The candidate in vertex order is feasible, but underestimates the exact distances . Merely satisfying the Bellman inequalities does not make a candidate exact.
Why do they give lower bounds? Along any directed path , successive substitution givesThe same calculation works for a directed walk, with repeated vertices allowed. Taking the infimum of route costs gives . A discovered route gives . If the bounds meet, , they certify an optimum without enumerating routes. Equivalently, check the Bellman inequalities for the proposed distances and exhibit directed paths realizing them. The authored Bellman-Ford algorithm implementation checks the corresponding single-source inequalities and equality on recorded route edges; reversing every directed edge gives this all-to-one convention.[ref]
https://raw.githubusercontent.com/kevin-wayne/algs4/master/src/main/java/edu/princeton/cs/algs4/BellmanFordSP.java. Sedgewick and Wayne, BellmanFordSP.java, optimality checks
For the exact labels in the picture, the slack is respectively on , , , , . Zero slack means equality; the zero-slack directed path realizes the cost . This is the useful beauty of the certificate: a few local inequalities rule out every cheaper journey, while one explicit journey attains the bound.
Keep unreachable vertices separate: when no directed path to exists, and a finite lower bound alone cannot certify that fact. Extended labels can use for finite , but never compute a slack as . If can reach a negative-cost directed cycle and then reach , repeatedly traversing the directed cycle makes route costs unbounded below: their infimum is , with no finite shortest directed walk. A finite feasible potential on such a directed cycle is impossible, since summing its Bellman inequalities would give . A negative-cost directed cycle that cannot reach does not affect distances to . These are statements about unrestricted directed walks; requiring a directed path with no repeated vertices is a different optimization problem when negative-cost directed cycles exist.[ref]
https://ocw.mit.edu/courses/6-006-introduction-to-algorithms-fall-2011/5edb13fb34cbe7f4cdccc13d131772e7_MIT6_006F11_lec17.pdf. MIT 6.006, Lecture 17, pp. 1 and 5: relevant negative cycles and simple paths
For the single-source convention, the same original directed edge instead gives with , a lower bound on distance from . The endpoint carrying the label on the left therefore changes with the direction of the problem.
New to topics? Read the docs here!