
A useful readout of a tumble is the alignment of the intermediate principal axis with the conserved angular momentum direction . In the principal body frame, write and . ThenA change from to means that the directed body axis has turned nearly relative to . It does not mean that reversed in the fixed space frame. The unsigned line through that principal axis hides this distinction, so a marked end matters in an actual demonstration.
For the normalized intermediate-axis model with , the rotational kinetic energy and squared angular momentum are and . Hence : this initial condition lies close to, but off, the intermediate-axis separatrix. An independent calculation evolves and a rotation matrix taking body components to space components. The intermediate principal axis crosses at normalized times approximately and , alternating long nearly aligned intervals with quicker reversals.
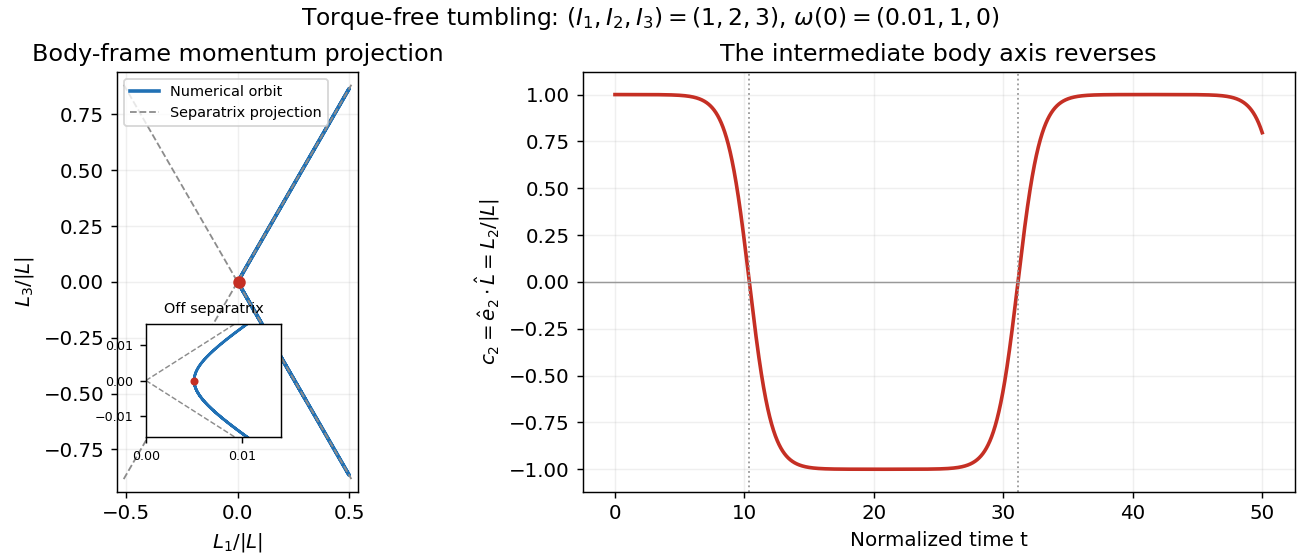
Torque-free reversals of a nearly aligned body axis
. Original independent Runge-Kutta method calculation in angular momentum and rotation matrix variables, starting with in the normalized intermediate-axis model. Left: body-frame orbit projected onto ; dashed lines are the intermediate-axis separatrix projections . The red point is the initial condition; the inset resolves its separation from those lines. Right: , with dotted lines at the first two zero crossings. The full angular momentum vector remains fixed in space. Details.
Both calculations use step size without rescaling either invariant. Over , the tumbling calculation changes rotational kinetic energy and squared angular momentum by less than relative to their initial values. Reconstructing in the fixed space frame gives relative error below . Halving the step changes the body components and rotation matrix entries by less than . These checks distinguish physical tumbling from numerical drift. On the exact intermediate-axis separatrix, approach to an intermediate-axis rotation takes infinite time; the recurrent off-separatrix example here is different.
New to topics? Read the docs here!