where:
- : matrix in the old basis
- : matrix in the new basis
- : change of basis matrix
Mnemonic is as follows: consider we have an initial basis . Now, we define the new basis in terms of the old basis, e.g.:which can be written in matrix form as:and so if we set:we have:
The usual question then is: given a vector in the new basis, how do we represent it in the old basis?
That is the matrix inverse.
When we have a symmetric matrix, a change of basis keeps symmetry iff it is done by an orthogonal matrix, in which case:
E.g. in , the underlying field is , the real numbers. And in the underlying field is , the complex numbers.
Any field can be used, including finite field. But the underlying thing has to be a field, because the definitions of a vector need all field properties to hold to make sense.
A member of the underlying field of a vector space. E.g. in , the underlying field is , and a scalar is a member of , i.e. a real number.
Articles by others on the same topic
This is a section about Vector space!
For example, this sentence. And then another one.

A vector space over a field is a set equipped with vector addition and scalar multiplication satisfying the vector space axioms. Its vectors can represent directed displacements, lists of measurements, polynomials, or entire functions. The common structure is that adding two elements and multiplying an element by a scalar remain meaningful operations inside the same space.
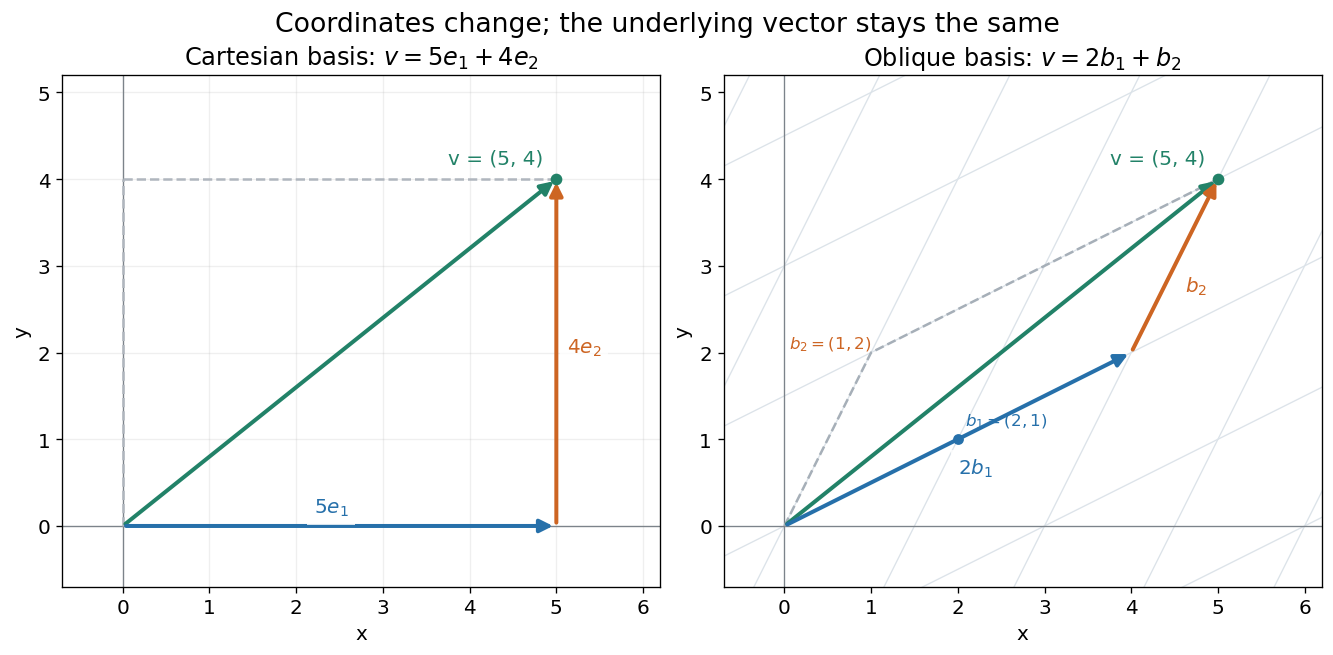
For example, uses coordinatewise addition and scaling. Withwe have . Moving twice along and once along reaches the same vector as five horizontal and four vertical steps. The two descriptions refer to different bases of the same space. A basis makes such descriptions unique; a spanning set makes them possible.
The space of real polynomials of degree at most two has basis : the polynomial is the linear combination with coordinates . The zero vector here is the zero polynomial, and addition combines coefficients. A derivative is a linear map on this space; its matrix records how it acts on the three basis vectors. The same coordinate machinery therefore handles both geometric motion and operations on functions.
The choice of field matters. The complex numbers form a one-dimensional vector space over with basis , but a two-dimensional vector space over with basis . The question "how many independent directions?" has an answer only after the allowed scalars are specified. Likewise, polynomials of degree exactly two do not form a vector space: subtraction can remove the leading term, and the zero polynomial is absent.
The usefulness of the abstraction is that a linear map is determined by its values on a basis. Once those images are known, linear combinations give its action on every vector. The rank-nullity theorem relates the number of attainable outputs to the number of invisible input directions, while change of basis lets us choose coordinates suited to the problem. Eigenvectors, for example, choose directions on which repeated application of a linear operator becomes scalar multiplication.
A historical source is Hermann Grassmann's Die lineale Ausdehnungslehre (1844). Its full title advertises applications to other branches of mathematics, statics, mechanics, magnetism and crystallography; the original edition is digitized by ETH-Bibliothek. This gives an early setting for treating geometric quantities algebraically across different applications, rather than attributing the modern axiom list to that title alone.[ref]
https://www.e-rara.ch/zut/content/titleinfo/1169335. Grassmann, Die lineale Ausdehnungslehre, Leipzig, 1844; ETH-Bibliothek Rar 5128
This is a section about Vector space!
For example, this sentence. And then another one.


A vector space (or linear space) is a fundamental concept in mathematics, particularly in linear algebra. It consists of a collection of objects called vectors, which can be added together and multiplied by scalars (numbers). These operations must satisfy certain properties.