An affine map combines a linear map with a translation. After choosing coordinate origins, it has the form , , where the matrix is its linear part of an affine map and is a fixed vector. Equivalently, it preserves every affine combination. [ref]
Curves and Surfaces in Geometric Modeling: Theory and Algorithms by Jean Gallier. §2.7, Definition 2.7.1 and linear-map construction, pp. 37–38
An original planar example isIt stretches horizontally, applies a shear mapping, and then translates. The vertices , and become , and . A square grid becomes a grid of parallelograms; straight edges and their weighted points still fit together.
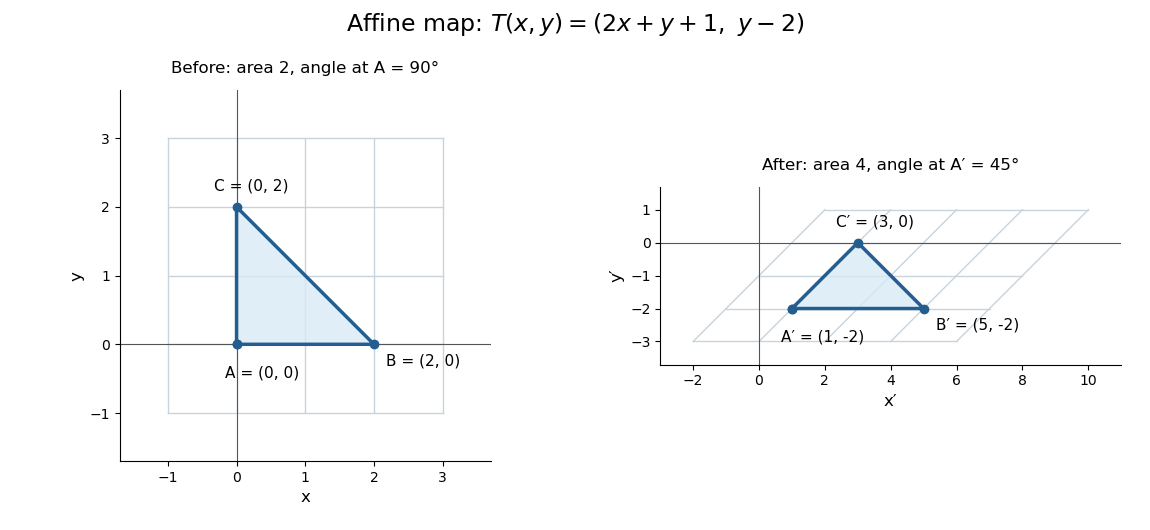

This map is not a linear map with respect to the displayed origins, because rather than zero. It also is not a Euclidean similarity: has length and has length , while the right angle at becomes . Its determinant is , so it doubles planar area. These metric changes explain why affine geometry studies straightness, incidence and weighted points rather than treating every transformation as an isometry.
The linear part is an invertible matrix, giving the concise inverse . More generally an affine map is bijective exactly when its linear part of an affine map is bijective. Between equal finite-dimensional spaces, this means an invertible matrix; the translation cannot repair a loss of rank of a linear map.
For coefficients with sum one, the defining identity follows from linearity:The translation appears once on both sides precisely because . In particular, midpoints map to midpoints, and a parameterized line segment , , maps to . A whole line has the same formula with ; its image is a line if , and a single point otherwise.
An affine map need not be injective. For , the direction belongs to the kernel of its linear part of an affine map. Consequently the whole line maps to , and every parallel line maps to . These are collapsed lines, not images with a surviving direction. Assertions that an affine map preserves distinct parallel lines require the appropriate noncollapse or injectivity hypothesis.
A Euclidean similarity is a map satisfying for a fixed . It has the form with orthogonal: after subtracting and dividing by , the map fixes zero and preserves distances, hence inner products by polarization, so it is a linear orthogonal map. It is a contraction if . Contracting Euclidean similarities define self-similar compact sets; the open set condition is a useful separation hypothesis for computing their Hausdorff dimension.
The map associated with an affine map ; it is independent of the translation . An affine Euclidean isometry has an orthogonal linear part, and an isometry between flat tori has a lift whose linear part carries one Euclidean lattice onto the other.
Articles by others on the same topic
There are currently no matching articles.