The Euler-Bernoulli beam equation models transverse linear bending waves in a slender beam. The normalized equation has and may be reduced by the Schrodinger factorization of the elastic beam equation. Prescribing displacement and curvature at an endpoint supplies two boundary traces for its fourth spatial derivative.
A rotational spring boundary condition for a beam lets an endpoint rotate while imposing a restoring torque proportional to that rotation relative to its support. Let be the spring stiffness, with zero rest angle. Its stored elastic energy is , where the small beam cross-section rotation is .
At a right endpoint whose transverse position is fixed, add this energy and the applied-couple potential to the bending energy. The coefficient of the free rotation variation isHere is beam flexural rigidity, and is defined by external virtual work . End moment and rotation are conjugate variables in the beam principle of virtual work.[ref]
The Concept of Stress, Generalized Stresses and Equilibrium by Tomasz Wierzbicki. §§3.4–3.5, equations3.46 and3.52–3.57
The spring term and the following example are independently derived. At the left endpoint, the bending boundary term has the opposite sign: with no applied end couple, .For an original fixture model, hold the left endpoint position fixed, restrain its rotation by the spring, and apply a downward end force at distance . The root moment magnitude is , giving root rotation . Bending relative to that rotated root contributes to the tip displacement; rigid root rotation contributes . ThusWith , , and , these contributions are and , giving total. Root rotation is radian, within the stipulated small-rotation model.
As increases without bound, the root approaches a clamped boundary condition. At zero stiffness this particular end-loaded arrangement becomes a rotational mechanism; it has no finite static deflection for nonzero . A small-couple fixture check can estimate from measured moment and angle. The resulting beam root rotational compliance is distinct from deformation of the beam material.
Beam root rotational compliance is the incremental rotation of a beam's attachment relative to its supporting base per increment of applied root torque. For a linear rotational restraint with stiffness ,The angle is measured in radians, so the compliance can be reported in . The root's transverse position is held fixed in this model. The rotational spring boundary condition for a beam implements this finite restraint; a clamped boundary condition is the zero-compliance limit. End moments and section rotations are conjugate quantities in beam virtual work.[ref]
For an original static derivation, apply a transverse tip force to a beam of length and constant beam flexural rigidity . The root moment has magnitude , giving . In the small-angle approximation, root rotation contributes to tip displacement. Bending relative to that rotated attachment gives the usual cantilever contribution, soThis derivation assumes a linear elastic beam, no root translation and an effectively rigid supporting base. The second term is fixture motion rather than a change in material Young's modulus.
For stipulated , , and , the root rotates through radian. Root motion contributes , while bending contributes . Attributing the entire to a perfectly clamped beam would infer instead of the stipulated value six.
A proposed measurement uses a known force and lever arm to apply a root moment, with optical markers on the attachment and on the supporting base to measure their relative angle. A separate displacement channel can detect unwanted root translation. Fit the small-load slope of angle against moment; using only the beam-tip displacement would mix attachment rotation with beam bending. Load reversal tests whether one linear compliance adequately describes the fixture or whether backlash and hysteresis require another model.
Beam cross-section rotation is the signed change in orientation of a material section in the bending plane. The Euler-Bernoulli beam equation assumes that sections remain plane and perpendicular to the deformed centreline. With a consistent angle convention, the section rotation therefore agrees with the centreline tangent angle; for a graph ,The last step is a small-angle approximation, with the angle measured in radians. This kinematic relation underlies the axial bending strain, rather than being an extra condition imposed by every support.[ref]
For an original geometric profile, take with . At , the slope is , while the exact tangent angle is radians. Replacing it by overestimates the angle by about 0.33 percent. This is a chosen shape illustrating the approximation, not a measured equilibrium profile.
The beam shear angle records a possible difference between centreline slope and section rotation in a model that permits transverse shear strain. The Euler-Bernoulli kinematics set that difference to zero; a short or shear-compliant specimen can require a different model. A simply supported beam leaves its end section rotation free, whereas a clamped boundary condition prescribes it. Neither zero transverse displacement alone nor zero endpoint bending moment requires zero rotation.
The beam shear angle is the small-angle difference between centreline slope and material-section beam cross-section rotation:With transverse coordinate and kinematics , , the engineering shear strain is . The Euler-Bernoulli beam equation imposes ; a shear-deformable model permits and to vary independently. The primary beam account distinguishes these kinematics and relates transverse force to the resulting shear measure.[ref]
Applied Mechanics of Solids by A. F. Bower. §8.7.2, Summary of beam theory, Timoshenko rotation and force/displacement relation
For an original local example, suppose shape measurements give , while section markers give radians in the same sign convention. Then , about degrees. Setting the section rotation equal to the observed slope would erase this measured discrepancy by assumption.
In a simple linear shear model, the transverse force resultant is , with effective beam shear rigidity . Here is the shear modulus, the material area, and a section correction coefficient. Stipulating , and gives and . The correction coefficient accounts for using a reduced section model; it is not universally fixed at .
A physical test must measure both the centreline shape and section orientation, for example by tracking markers during loading. Shape alone determines but cannot independently determine without section-rotation information or an additional mechanical model. The comparison also requires compatible spatial resolution and angular measurement calibration.
Effective beam shear rigidity is the coefficient relating a transverse shear-force resultant to the beam shear angle in a reduced linear beam model:Here is shear modulus, is material area and is a beam shear correction coefficient. The coefficient has units of force, whereas beam flexural rigidity has units . A shear-deformable beam permits section rotation to differ from centreline slope; Bower gives the corresponding force relation and explains the correction coefficient's dependence on section geometry and the approximation used.[ref]
Applied Mechanics of Solids by A. F. Bower. §8.7.2, Summary of beam theory, Timoshenko force relation and shear-coefficient paragraph
An original energy calculation explains one familiar correction. For a homogeneous rectangle of width , thickness and area , adopt the classical parabolic shear-stress approximationIt has resultant . Its shear elastic energy per unit beam length isEquating this to the reduced-model energy gives . Thus follows from this particular energy-matching approximation; it is not a universal material constant or an exact coefficient for every beam theory.
The effect on a three-point bending test can be derived from that reduced energy. For a simply supported beam under central force , the magnitude of shear force is on each half. Hence and its contribution to central displacement is . Combining it with the bending response givesThe shear contribution becomes relatively more important as the span decreases.
For stipulated , , and , the two contributions are and . Shear adds twelve percent of the bending deflection. A span series with a load cell and direct midspan displacement readout can distinguish cubic bending dependence from linear shear dependence, provided contact and fixture contributions are also controlled. Inferring from the response additionally requires the section geometry and correction model.
The beam shear correction coefficient adjusts a reduced beam model's shear response for the nonuniform shear stress over a material section. With shear modulus , area , transverse force resultant and generalized beam shear angle ,where is effective beam shear rigidity. Bower's primary account calls this the Timoshenko shear coefficient and explains that its value depends on geometry, Poisson's ratio and how the approximate theory is matched to the underlying solid.[ref]
Applied Mechanics of Solids by A. F. Bower. §8.7.2, Timoshenko force relation and following shear-coefficient paragraph
An original energy-matching derivation makes the correction precise for one approximation. Assume uniform and a chosen shear-stress field with resultant . The shear elastic energy per unit beam length and its reduced representation areThusThe Cauchy-Schwarz inequality gives , hence for this definition. Equality requires uniform stress. This bound belongs to the stated energy-matching definition rather than every convention called a shear correction coefficient.
For the parabolic rectangular stress approximation used in effective beam shear rigidity, the squared-stress integral is , giving . Choose , and . Then and radians. Omitting the correction gives , underestimating this generalized shear angle by one sixth.
The generalized angle also differs from the peak local shear strain. Under the same parabolic approximation, peak stress is , giving peak strain . The values describe different reductions of the same chosen stress field. Identifying from a bending test therefore requires the section model and displacement readout, not merely a material modulus. For a three-point bending test, the shear deflection contribution varies as , whereas bending varies as ; a span comparison can help separate them.
Beam flexural rigidity is the coefficient relating a slender beam's bending moment to its curvature in linear bending. For a homogeneous material with uniform Young's modulus over the material area,where is distance from the appropriate neutral axis. The magnitude relation is ; signs depend on the chosen moment and curvature conventions. Integrating the linear bending stress over the section gives this coefficient.[ref]
For an original rectangular example, choose width , bending thickness and . The second moment of area is , giving . Doubling only the thickness multiplies by eight. Rotating the original rectangle by ninety degrees about its length instead exchanges width and thickness: increases by even though material area and modulus are unchanged.
Thus a bending experiment measures a combination of material response and geometry. Extracting requires the correct bending axis and second moment of area; the three-point flexural test is one route. This beam coefficient has units , distinct from the plate coefficient called bending stiffness. If modulus varies across a section, the relevant stiffness requires a material-weighted area integral and the appropriate neutral axis, rather than an arbitrary average modulus multiplied by .
A simply supported beam is prevented from moving transversely at its two supports while its ends remain free to rotate. In the small-deflection Euler-Bernoulli beam equation, a uniform span with transverse displacement and positive beam flexural rigidity has the support boundary conditionsHere is Young's modulus and is the second moment of area about the bending axis. The second pair expresses zero applied endpoint bending moment, since in the convention used here. It does not set the endpoint beam cross-section rotation or slope to 0. A clamped boundary condition instead constrains both displacement and slope.
For an original derivation, apply a downward central point force and take positive downward. Assume small elastic deflections, constant and no axial preload. Symmetry and force balance give an upward reaction at each support. On the left half, the bending moment is , so . Integrate twice, using and the symmetry condition , to obtainThus the midspan compliance of a simply supported beam isThe endpoint slopes are and : they are generally nonzero. This support geometry and central-load formula are used to infer material stiffness from a three-point bending test.[ref]
The moment-free natural boundary condition for a beam also follows from the principle of virtual work. For a central load, the total potential energy is . An admissible virtual displacement satisfies , while its endpoint first derivatives remain free. Two integrations by parts produce the boundary contributionThe terms multiplying vanish because the endpoint displacements are prescribed. Arbitrary endpoint values of then require there. The free end rotation and zero end moment are conjugate parts of the same variational boundary condition.
Clamping both ends changes the central-load deflection to , one quarter of the simply supported value for the same . It introduces endpoint reaction moments; it does not merely rename the same support. The clamped-beam Green function provides the corresponding fourth-order boundary-value solution. The support conditions likewise determine the simply supported beam normal modes, so a static stiffness measurement and a vibration measurement must use the same mechanical support model when they are compared.
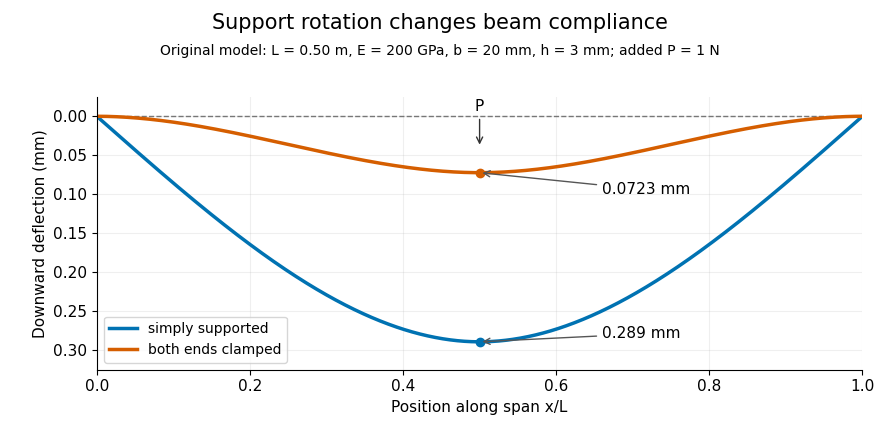
Original central-load beam profiles: allowing support rotation gives four times the midspan deflection of clamping both ends.
Details. 
A three-point bending test places a specimen on two separated supports and applies a central force. A load cell measures force, and a midspan displacement readout measures response. A direct plunger and extensometer can measure specimen deflection separately from machine crosshead displacement, as in the published Instron fixture arrangement.[ref]
Three Point Bend Test Fixtures by Instron. Principle of Operation and midspan deflectometer description
Fitting a proportional small-load segment estimates , where is the measured incremental midspan compliance. Record support spacing, load position and cross-section dimensions with that estimate.For stipulated , rectangular width , thickness and , the second moment of area is and . An incremental central load gives incremental deflection under the simply supported model, versus for the clamped model. Incremental readings remove an unchanged baseline deflection in this linear model; support settling, contact indentation and large rotations require separate interpretation.
A three-point flexural test loads a specimen through one central contact while two separated supports carry the reactions. In a small-deflection simply supported beam model, an incremental central force and the resulting midspan displacement determine the midspan compliance of a simply supported beam. With a known second moment of area, that response yields a flexural modulus.[ref]
Beam Displacements by David Roylance. Introduction; Example1 and equation7
The apparatus must distinguish specimen deflection from machine travel. The manufacturer's fixture description uses adjustable lower anvils and a central loading member; a direct midspan plunger can transmit deflection to an extensometer. A load cell supplies the force record.[ref] The crosshead displacement can also contain deformation of the frame and contacts.
For an original readout example, stipulate span , width and thickness , so . Suppose a linear loading interval gives direct midspan compliance , while machine travel gives . Applying the same beam relation to the two readouts givesThe apparent modulus is twenty percent lower. The numbers are chosen to isolate the displacement-channel effect; they do not characterize a particular fixture. Inferring a material Young's modulus further assumes the beam's linear, homogeneous bending model is adequate. Contact indentation, support motion and transverse shear strain can otherwise alter the measured compliance. The parent simply supported beam supplies the deflection derivation and support-comparison figure.
The moment-free natural boundary condition for a beam is the zero-end-moment condition obtained when an endpoint can rotate freely and no external couple is applied there. For positive beam flexural rigidity , it is . This differs from prescribing the endpoint beam cross-section rotation.
The simply supported beam gives the full principle of virtual work derivation. At its right support, the admissible virtual displacement obeys , but is arbitrary. The remaining bending boundary contribution is . Its vanishing for every permitted end rotation requires . Beam virtual work pairs end moments with rotation variations and forces with displacement variations.[ref]
An original modified boundary example shows why the missing external couple matters. Define a signed right-end couple by its external virtual work . The boundary coefficient then becomes , so the free-rotation condition is . With and , the endpoint second derivative is , not zero. This sign definition fixes the couple convention explicitly.
Clamping instead sets ; that restriction permits an unknown reaction moment rather than forcing it to vanish. Finite rotational restraint leads to a rotational spring boundary condition for a beam. These alternatives distinguish a prescribed motion from its conjugate natural load condition.
The midspan compliance of a simply supported beam is the incremental central deflection per incremental central load, with the support geometry fixed. For a uniform, small-deflection Euler-Bernoulli beam equation model without axial preload,Its units are length per force. The simply supported beam contains the derivation; the experimental use is to infer beam flexural rigidity or, with known geometry, Young's modulus.[ref]
Beam Displacements by David Roylance. Introduction and Example1, equation7
An original two-span example separates beam compliance from an assumed constant machine contribution. Suppose the same uniform specimen is tested over spans and . A machine-travel readout gives and . Assumewhere is unchanged between the tests. Subtracting the readings givesHence and . The inferred specimen compliances are and , with ratio . The raw readings have a different ratio because they include .
This beam compliance from two support spans relies on the unchanged-series-compliance assumption. Changing supports, contact indentation or shear contributions can invalidate it; two points fit its two coefficients without independently validating the model. A third span can test the cubic dependence. An incremental slope also differs from simply dividing a total displacement, including an initial offset, by the current force.
Beam compliance from two support spans separates a cubic span-dependent beam response from a span-independent contribution to the measured mechanical compliance. Assume the same uniform specimen, unchanged machine contribution and a small-deflection central-load model:Here is beam flexural rigidity and . The midspan compliance of a simply supported beam contains the basic numerical fit, while the beam source derives the cubic dependence.[ref]
Beam Displacements by David Roylance. Introduction; Example1, equation7
An original uncertainty example shows why distinct spans can still be too close. Let the actual model have , hence . Assign independent compliance standard uncertainties , and neglect span uncertainty for this example. Since the slope estimate is linear in the readings,Spans and give , about54percent of the actual coefficient. Using and instead gives about3.57percent with the same readout uncertainties. The close-span subtraction strongly amplifies those errors. At the larger relative uncertainty, simply treating as approximately linear is unreliable.
This conditioning of two-span beam compliance inference concerns measurement precision, separately from model adequacy. If shear adds a term proportional to , then has three unknown coefficients that two readings cannot identify. Changing contact or fixture compliance can likewise violate the assumed constant . Further spans and an independent deflection readout test those assumptions; two fitted points alone do not.
Conditioning of two-span beam compliance inference describes how perturbations in two measured compliances and support spans affect the inferred bending coefficient. In the model represents an unchanged series contribution and is beam flexural rigidity. The cubic beam term follows from the midspan compliance of a simply supported beam.[ref] The subtraction is sensitive when the spans are close, or when the beam-response difference is small compared with readout errors.
Let and temporarily treat the spans as exact. The sensitivity coefficients are and . Consequently,This is the standard measurement uncertainty propagation rule applied to a linear combination; the covariance term matters when the readings share errors.[ref]
For an original numerical comparison, stipulate , so , and independent standard uncertainties . Spans and give and , about 54 percent of . Increasing the second span to gives and , about 3.57 percent. The wider spacing makes the same compliance readout precision much more informative.
Span uncertainty enters through additional sensitivity coefficients:For uncorrelated span readings, their first-order contribution to is , before any compliance/span correlations are included. An identical additive readout offset cancels from , whereas a changing offset does not.
A practical span comparison holds the specimen, contacts, loading position and displacement channel as consistent as possible. Close spans amplify measurement noise; simply choosing distant spans can instead expose a failure of the assumed model. Shear produces a term proportional to , and changing contacts can change . A third span tests those assumptions. Finally, inversion to is strongly nonlinear near : the 54-percent case cannot be adequately summarized by a small symmetric relative uncertainty on .
A uniform elastic beam with endpoint conditions has normal modes for positive integers . Substitute into and impose the four endpoint conditions to obtain the displayed spectrum. Here is mass per unit length, is a second moment of area, and is beam flexural rigidity. frequencies proportional to distinguish flexural waves from the nondispersive ideal stretched string.
A prescribed initial beam profile may vanish at a pivot while having nonzero endpoint curvature. If the post-release pivot is moment-free, its bending moment condition is . The data then cannot have a classical solution with continuous curvature at the initial boundary corners. A finite-energy weak solution can still represent release from preparing end moments. For example has odd sine coefficients proportional to ; converges, giving finite bending energy. The displacement series takes the prescribed initial shape, but termwise endpoint second derivatives cannot be identified with its interior curvature limit. This conservative beam evolution does not have the immediate smoothing of a heat equation.
For a unit-length elastic beam with unit bending stiffness, the Green function of with at both endpoints is the displayed kernel. It is piecewise cubic and continuous through its second derivative, while . A constructive form is , with and . The right endpoint conditions determine these coefficients. Thus solves the clamped static beam problem.
The clamped-beam Green function is symmetric. Its explicit formula depends only on and . More generally, two integrations by parts give when at both endpoints. Applying this identity to two point-load responses shows that the displacement at one point caused by a unit force at a second equals the displacement at the second caused by a unit force at the first.
A straight slender elastic beam under axial compression loses stability when bending can decrease its total potential energy. With pinned ends a distance apart, its quadratic potential is . Stationarity gives , with at each end. The first nontrivial mode is , at . More generally , with an effective-length factor determined by endpoint constraints: for pinned-pinned, for fixed-free and for fixed-fixed. Real imperfections remove the perfectly sharp onset, and short columns can yield before this elastic instability.
For a pin-ended slender beam with unstressed profile , bending moment depends on curvature change: . An axial dead load gives in the small-slope model.
With and , the equilibrium branch connected to zero load has . The pole as approaches marks breakdown of the small-deflection model, not a physically infinite beam deflection.
Positive compression contributes negative quadratic potential energy , while positive bending stiffness contributes . A plane wave has , so sufficiently long waves grow exponentially. For displacement-fixed, moment-free endpoints at , the natural boundary conditions for a free endpoint on the slope give as well as . The modes are , and the first Euler buckling of an elastic filament threshold is . For truly clamped ends, , the threshold is instead , with first static mode . More generally,with the infimum taken over the specified endpoint class. At threshold there is a static zero mode and a marginal linear-in-time partner in the linear dynamics; above it the straight configuration is unstable.
Writing in the free Schrodinger equation gives and , hence . To encode initial velocity , choose the decaying primitive . A prescribed endpoint curvature becomes the time derivative of the imaginary boundary trace. This turns the normalized Euler-Bernoulli beam equation into a complex second-order boundary problem.
Articles by others on the same topic
There are currently no matching articles.