Linear elasticity describes small deformations using a stress that depends linearly on the infinitesimal strain tensor. If is the displacement field, thenFor an unstressed isotropic material, the constitutive equation iswhere are the Lamé parameters, is the Kronecker delta and repeated indices are summed. In particular, is the shear modulus.
The small-displacement-gradient approximation permits superposition: for the same linear material and linear boundary conditions, the sum of two displacement solutions responds to the sum of their applied loads. This makes it possible to calculate bending, vibration and elastic waves from common material coefficients. Small strain alone is not sufficient when rotations are large; a slender elastic rod can turn through a large angle while stretching very little, requiring geometrically nonlinear kinematics.
A stress concentration is a localized increase of stress caused by geometry or another disturbance of the load path. Holes, notches and abrupt section changes can make the largest local normal stress much greater than a stress calculated from the total force divided by a reference cross-sectional area. A stress concentration factor is meaningful only after both the stress component and its reference have been specified.
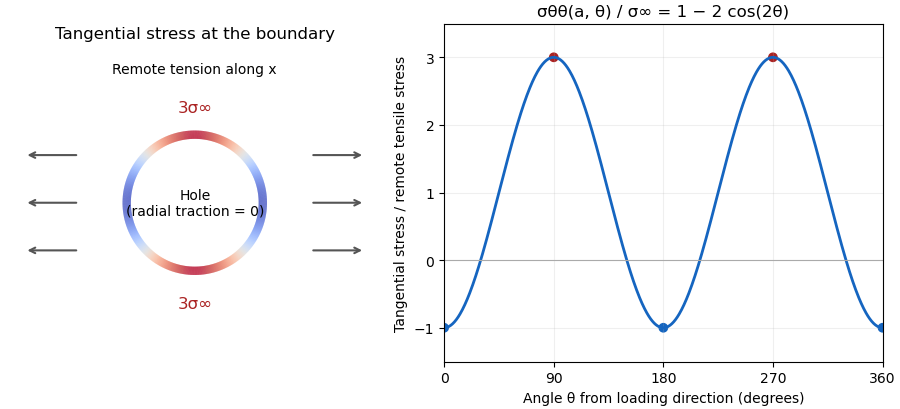
The Kirsch equations give an instructive exact result for a circular hole of radius in an infinite, isotropic linear elastic elastic plate under remote tensile stress in one direction, using a plane stress model. Measure the polar angle from the loading direction. At the hole boundary,At , the tangential normal stress reaches , giving relative to remote stress. At , it is . A traction-free hole therefore does not require every component of its stress tensor to vanish: it requires zero traction on the radial boundary.[ref]
For a finite plate, distinguish gross and net reference areas. A plate of width , thickness and central hole diameter transmits force through gross area and minimum net area . Defining and gives the exact conversionThis is a change of normalization, not a solution for the finite plate's stress field. For an original numerical example, take , , and . The reference stresses are and . If the local maximum is stipulated as , the same physical maximum gives and . Neither number changes the local stress by choosing a different denominator.
The distinction appears in real historical measurements. In 1939, C. Dumont loaded a perforated aluminum-alloy plate in out-of-plane bending and measured strain and deflection at two loads. The reported peak tangential stress was 1.59 times the computed net-section stress, but 1.85 times the computed stress for an unperforated plate under the same bending forces. These are bending results for that geometry, rather than the infinite-plate tensile factor three.[ref]
Modern demonstrations can combine a metal plate instrumented with strain gauges and a transparent polymer viewed in a polariscope. The latter uses stress-induced birefringence; its fringes respond to differences of principal stresses. The MIT laboratory compares local and remote strain measurements with qualitative photoelasticity observations around holes and a slot.[ref]
Isotropic Linear Elastic Stress Concentration by MIT Mechanical Engineering. §§6–7, Figures 6–9 and strain-gauge procedure
The elastic stress concentration factor is dimensionless. It differs from the stress intensity factor used to describe a sharp crack's singular field. Local yielding or a crack changes the mechanical problem; multiplying a remote stress by the elastic does not, by itself, establish a failure load.
The Kirsch equations describe the stress tensor around a traction-free circular hole in an infinite linear elastic plate under uniform remote tension. For remote stress along , hole radius and polar coordinates measured from that direction, put . In the classical isotropic plane stress model,The fields satisfy equilibrium and the prescribed boundary tractions. They can be obtained using an Airy stress function satisfying the biharmonic compatibility equation.[ref]
Stresses Around a Circular Hole by MIT Materials Science and Engineering. one-page handout, stress function, component equations and boundary conditions
At , , so whileThe tangential stress is at the top and bottom of the hole and at its sides. A traction-free boundary does not require every stress component to vanish: the outward boundary normal is radial, so radial normal and shear tractions must vanish.
For an original distance comparison along , the tangential stress is . At it is , already far below the edge value three. At large distance the polar components approach those of the original uniform Cartesian tension.
A finite-width plate, internal hole pressure, plasticity or out-of-plane bending changes the boundary-value problem. The stress concentration factor three is therefore specific to the stated remote-tension model. The MIT laboratory uses local strain measurements and photoelasticity to examine how actual geometries compare with ideal concentration fields.[ref]
Isotropic Linear Elastic Stress Concentration by MIT Mechanical Engineering. §4.1 and experimental §§6–7
A stress concentration factor compares a specified local peak stress with a defined nominal reference:It is dimensionless. Both the stress component and the reference geometry belong in its definition; a number quoted without them can be ambiguous. In the infinite circular-hole Kirsch equations, the maximum tangential tension is three times the remote uniaxial stress, so that particular reference gives .[ref]
Isotropic Linear Elastic Stress Concentration by MIT Mechanical Engineering. §4.1, circular-hole result and reference stress
For an original finite-plate normalization example, let width , thickness , central-hole diameter and tensile force . The gross and minimum-net reference stresses areIf the local peak is stipulated as , the same specimen has and . In general for these reference definitions. This conversion does not solve the finite plate's stress field or predict its peak.
The reference can also be a nominal bending stress or another stress appropriate to the applied loading. A factor obtained for axial tension cannot automatically be reused for a bending problem with different boundary conditions.
An elastic concentration factor is distinct from the crack-tip stress intensity factor, which has units of stress times square root of length. Nor does by itself supply fatigue life or a failure load: yielding, defects, residual stress and the loading history require additional analysis. The factor describes amplification within its stated elastic model.
Bending changes the curvature of an elastic beam, rod or sheet. In the elementary beam model, material on opposite sides of the neutral axis stretches and shortens. Their longitudinal normal stresses can balance to give zero resultant force while still transmitting a nonzero bending moment. A bent ruler illustrates why resistance to changing shape cannot be described by axial stretching alone.
For a homogeneous slender elastic beam in small-deflection pure bending, take along the beam and perpendicular to its centroidal neutral axis. Let be the signed centreline curvature. The plane-section kinematics and Hooke's law giveHere is Young's modulus, taken constant over the section. Choosing the positive bending moment as yieldsThus the second moment of area , rather than just the cross-sectional area, controls bending stress. The beam flexural rigidity is . Zero axial resultant requires , locating the neutral axis at the section centroid under these assumptions.[ref]
A four-point bending test makes the constant-moment region experimentally accessible. Two outer supports carry a specimen while two inner contacts apply the load. The Illinois teaching laboratory uses adjustable inner and outer spans on an Instron 4400 frame and records load and deflection electronically; it also tests notched specimens to examine stress concentration.[ref]
Bending Test at the University of Illinois Mechanical Testing Instructional Laboratory. Bending Test, apparatus and notched specimens
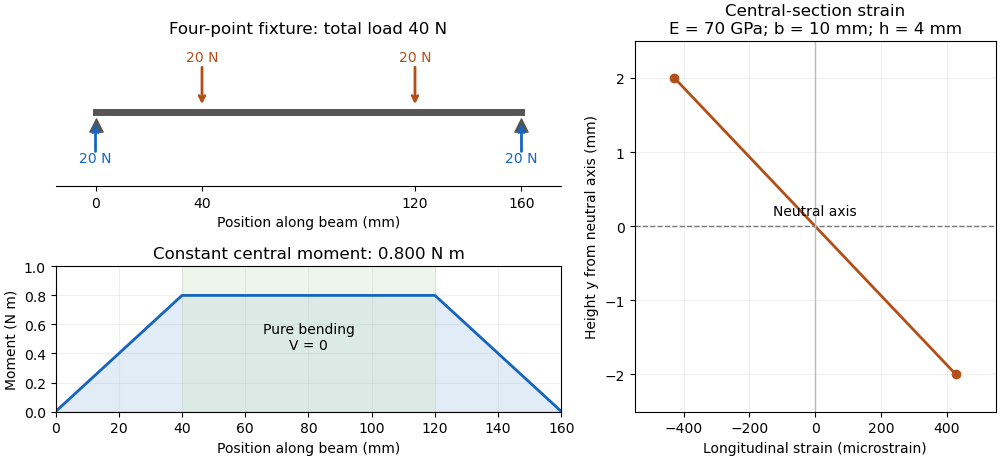
For an original symmetric loading example, place the outer supports at and apply total downward force equally at , with . Each support reaction is . Between the inner contacts the transverse shear force is zero and the bending moment is constant, . This central interval realizes the ideal beam conditions for pure bending away from contact disturbances. A three-point bending test instead has its maximum moment at the single central loading contact.
Choose , , , rectangular width and thickness . Then and . With stipulated , the model givesThese independently chosen numbers describe an assumed elastic specimen, rather than measurements of a particular material.
The same relation can infer a flexural modulus from a measured bending moment and curvature, provided the geometry and beam assumptions are adequate. Added axial force contributes a uniform longitudinal normal stress and can shift the zero-stress line. Short beams require attention to transverse shear strain; large rotations require a geometrically nonlinear description. The small-deflection Euler-Bernoulli beam equation and the more general Euler elastica cover different levels of that modeling.
Bending stress is the longitudinal normal stress associated with a bending moment in a beam. In a homogeneous slender elastic beam with small deformation, plane sections remaining plane give longitudinal strain relative to the neutral axis. Applying Hooke's law gives .[ref]
Choose the moment convention . ThenHere is the second moment of area, and the neutral axis passes through the section centroid when axial resultant is zero and is uniform. The sign tells which side is in tension; the magnitude grows linearly with distance from that axis.
For an original rectangular section with width and thickness , . A moment produces maximum surface magnitudeThe moment is when using millimetre section dimensions. At fixed and , doubling reduces this nominal surface stress fourfold, not merely twofold, because grows as .
These are beam-model stresses away from local load contacts and discontinuities. Added axial force contributes to the longitudinal stress; a notch can produce a stress concentration beyond the nominal distribution. For inhomogeneous sections the neutral-axis position must be obtained from the actual stiffness distribution rather than assumed from geometry alone.
Pure bending is a beam loading state with zero axial resultant , zero transverse shear force and a nonzero constant bending moment over the interval considered. Equal and opposite end couples provide an ideal realization. Zero net force on a section does not mean zero local stress: opposing longitudinal tensions and compressions can form a couple.
For a homogeneous slender elastic beam, small-deformation kinematics and Hooke's law giveHere is measured from the centroidal neutral axis, is the second moment of area, is Young's modulus and is curvature. Uniform , and produce uniform curvature. The geometric assumptions and moment sign convention are those of the elementary bending stress model.[ref]
For an original example, let and . Then . Across a interval the tangent direction changes by approximately radians. At from the neutral axis, the strain magnitude is . The small-slope sag relative to the interval's chord is .
The central region of a symmetric four-point flexural test is an experimental approximation: the external load contacts lie outside a constant-moment interval. Local contact disturbances remain near the loading noses, and transverse shear exists in the outer spans. Calling the central interval pure bending therefore specifies a region and a model; it does not claim that the entire fixture has zero force or shear.
A four-point flexural test bends a specimen using two outer supports and two inner loading contacts. For symmetric loading, the interval between the inner contacts has constant bending moment and zero transverse shear force, approximating pure bending away from contact disturbances. The Illinois laboratory uses adjustable spans and records force and deflection with a mechanical testing frame.[ref]
Bending Test at the University of Illinois Mechanical Testing Instructional Laboratory. Bending Test, fixtures and electronic readout
Let the support span be , the distance from each support to its nearest loading contact be , and the total downward applied force be . Each loading contact and each support carries force magnitude . Static equilibrium givesThe central constant-moment region has length . Specifying whether a force symbol means total force or force at each nose prevents a factor-of-two error.
For an original example, , and give reactions and central moment . A rectangular specimen with width and thickness has . The nominal maximum bending stress magnitude is .
The apparatus measures force and a chosen displacement; the beam model converts them into stress, strain or flexural modulus. Midpoint displacement and displacement at the inner loading contacts are generally different. Fixture motion can additionally include machine compliance and contact indentation. Record the displacement location and both spans along with specimen dimensions.[ref]
Unlike a central three-point load, this geometry provides a finite interval of maximum nominal moment. It tests a larger highly stressed region, so flaw distribution and where failure begins can matter when comparing results between fixtures.
For a infinitesimal strain tensor , commuting displacement derivatives gives the symmetric incompatibility tensor . Its six component equations are the Saint-Venant compatibility equations. They satisfy three differential identities because is symmetric while is antisymmetric. Thus there are three independent differential constraints, although keeping all six equations is a coordinate-symmetric way to state them. At a nonzero Fourier wavevector along the third axis the constrained components are , while arise from the three displacement components. On a simply connected region compatibility gives local integrability up to a rigid motion; on a multiply connected region circulation conditions must also be imposed.
For uniform twist and displacement , linear elasticity gives and . Their planar divergence vanishes by axial equilibrium. On a simply connected section there is therefore a stress function with and .
The mixed derivatives of imply . The lateral axial traction is the tangential derivative of , so a traction-free connected boundary makes constant; choose it to be zero. Finally the torque is , since its boundary term vanishes. Thus one scalar Poisson equation determines both the shear field and torsional stiffness. Multiply connected sections require additional constants and compatibility conditions on the separate boundary components.
In uniform torsion about the -axis, the axial displacement describes departure of a cross-section from a plane. It is determined up to an additive axial translation by , , where is the torsion stress function for a simply connected bar. For a circular section these derivatives vanish. For an ellipse they give , so a noncircular section generally warps. The stress-function Poisson equation is exactly the mixed-derivative compatibility condition for this axial displacement.
On , the torsion stress function for a simply connected bar is . Its Laplacian is and its boundary value is zero, proving the formula by uniqueness of the Poisson equation with Dirichlet data. Integration gives , hence the displayed stiffness .
The three principal stresses are . With defined as the shear yield stress, the Tresca yield criterion is . For its maximum is at , where . Equating that maximum to gives the displayed first-yield twist. The ends of the minor axis yield first; geometric distance from the bar axis alone does not determine stress in a noncircular section.
On a connected isotropic linear elastic body, assume and . Then is positive for every nonzero symmetric strain tensor. If two equilibria have the same body force and boundary traction, their difference satisfies zero loading. Multiplication of equilibrium by and the divergence theorem yield . Hence , and the kernel of the symmetric gradient consists of infinitesimal translations and rotations: .
The conclusion is uniqueness modulo these modes, not existence for arbitrary tractions. Existence additionally requires zero total resultant force and torque. On a disconnected body each connected component has its own rigid modes; fixing enough displacements removes those modes and can produce full uniqueness.
A linear map from symmetric three-dimensional infinitesimal strain tensors to symmetric stress tensors acts between two six-dimensional spaces. Choosing the minor index symmetries leaves independent constitutive coefficients. Symmetry of the two second-rank tensors alone does not force pair interchange. If a strain-energy density exists and stress is its derivative, equality of mixed second derivatives gives the major symmetry . The resulting symmetric six-by-six coefficient matrix has independent coefficients. This distinguishes minor tensor symmetry from the extra reciprocity supplied by an energy potential.
Write a quadratic small-strain energy as with homogeneous of degree two. If it were fully frame indifferent, the rotation would have zero energy. Quadratic homogeneity would then make every have zero energy. At , has determinant , yet zero energy. Thus a nondegenerate linear elasticity energy cannot also be used as a fully objective finite-deformation energy. Its invariance concerns infinitesimal rotations around the reference state.
Fix a positive shear modulus and let the other Lamé parameter tend to infinity in . If strain and stress converge to finite limits and differentiation commutes with the limit, taking the trace shows . Thus and for . Force balance becomes the displayed Stokes equation, with an elastic shear modulus in place of fluid dynamic viscosity. The vanishing volumetric strain is the linearization of elastic incompressibility .
In a homogeneous isotropic solid without body force, a radial displacement field satisfies . For nonzero , its volumetric strain is constant. Since Hooke's law gives , its stress tensor has constant trace. After plasticity in continuum mechanics has occurred, this conclusion applies to purely elastic increments during elastic unloading, and need not apply to the total residual stress.
The elasticity tensor relates stress to infinitesimal strain by . In conservative linear elasticity, the minor symmetries reflect symmetric stress and strain, while the major symmetry expresses the existence of an elastic energy density.
The uniaxial strain modulus relates longitudinal normal stress to longitudinal strain when both transverse normal strains vanish. For isotropic linear elasticity, solving the transverse compliance equations gives the transverse stresses and hence the displayed modulus in terms of Young's modulus and Poisson's ratio. It differs from Young's modulus, which applies when the transverse stresses vanish. Their difference is crucial for thin elastic layers bonded to rigid faces.
For a thin sheet of initial face area , compressed normally by force between frictionless plates, each lateral strain is . To first order the area of either broad face increases by ; total two-face area changes twice as much.
An axisymmetric small radial displacement gives radial strain and hoop strain . Radial force balance on an annular wedge gives . Under plane stress, isotropic Hooke's law gives and . Substitution into equilibrium gives the displayed displacement equation. Its power-law exponents are and , so . The hoop-stress solution is not based on treating a thick wall as a membrane.
For inner and outer radii , with internal and external pressures , the boundary tractions are and . The radial equilibrium of a thick elastic cylinder gives and . The radial compressive pressure is . Since hoop stress is monotone in when , its maximum absolute value is the larger of and . With negligible external pressure, its maximum is the tensile inner-wall value . The stress distribution itself is independent of elastic moduli in this linear homogeneous axisymmetric model; its associated displacement depends on them.
A stress tensor state with all traction components involving one normal direction zero. In an isotropic solid, its two remaining normal stresses obey and . The out-of-plane strain need not vanish: . Constraining the out-of-plane deformation instead would be a different boundary condition.
Under uniform compressive pressure , isotropic Hooke's law gives each normal strain as . The volume strain is three times this, so the bulk modulus iswhere is Young's modulus and is Poisson's ratio. The shear modulus is .
For stable three-dimensional isotropic linear elasticity, both and must be positive. With finite , these two positivity requirements giveFiniteness of alone does not establish the upper inequality: its positive sign is essential. The bounds come from positive strain energy density for both volumetric strain and deviatoric strain, rather than a prohibition on negative Poisson's ratio.
For example, and give and , both positive. A negative Poisson's ratio is compatible with stability. The limit at fixed sends the bulk modulus to infinity and represents an incompressible limit, rather than a finite positive-modulus point.
The proportional limit bounds the loading interval over which stress is proportional to strain. It does not by itself establish the last load that permits complete recovery of elastic deformation.
Apply the divergence theorem to and use momentum balance and stress symmetry to obtain the displayed mean stress identity. Applying the same theorem to the infinitesimal strain tensor gives . The acceleration term cannot be dropped during a transient.
For a uniform traction-free sphere, first-order self-gravity is . Static averaging gives . Homogeneous linear elasticity then gives . The boundary strain identity identifies , proving the displayed positive radius decrease. The local strain is not uniform, and the cancellation of the shear modulus concerns only the mean contraction.
For a homogeneous comparison elastic stiffness tensor , the elastic strain Green operator maps an elastic polarization to minus the induced infinitesimal strain tensor. In a bounded domain the induced displacement field has zero boundary data; in an infinite medium it is the decaying perturbation. The defining static elastic equilibrium equation is . The bounded-domain operator is self-adjoint, annihilates constant elastic polarizations, has zero mean output, and satisfies .
For a three-dimensional isotropic comparison material, the contraction of its elastic strain Green operator is the displayed distributional derivative. Its double trace is , because . Away from zero the contraction is ; the full distribution also includes . This contact term must not be discarded when computing hydrostatic strain.
When only the bulk modulus differs from an isotropic matrix, the elastic polarization is spherical: . The double trace of the isotropic elastic strain Green kernel makes the trace equation local, giving the displayed formula. Individual strain components still depend on a nonlocal potential of the spherical polarization, so the complete infinitesimal strain tensor is not generally a local multiple of its reference value.
Let ; its adjoint on symmetric stress tensors is . Then is the acoustic tensor. The directional elastic strain Green operator satisfies the resolvent identity , by the elementary inverse identity .
The elastic polarization is the excess stress relative to a homogeneous comparison elastic stiffness tensor. In heterogeneous linear elasticity, . The comparison static elastic equilibrium equation gives the integral equation , where is the reference strain under the same external loading.
The bulk modulus relates hydrostatic compressive pressure to fractional volume compression. In isotropic three-dimensional linear elasticity, the spherical part of the stress tensor is , so uniform dilation has strain energy density . Positive bulk modulus and positive shear modulus make the isotropic elastic stiffness tensor positive on nonzero symmetric strains.
For an isotropic linearly elastic solid, equal compressive principal stresses produce three equal normal strains . Adding them gives the displayed volume strain, or bulk modulus . It is a small-strain relation using the pressure change, not an arbitrary absolute pressure reference.
The pressure response to compression at fixed entropy, . Seismic compressions are commonly approximately adiabatic; a background density gradient follows the corresponding derivative only when composition and entropy assumptions also apply.
Antiplane shear has displacement normal to a plane and independent of that normal coordinate. In an isotropic linear elastic body, and , together with their symmetric partners, are the only nonzero stress tensor entries. Static balance without body force reduces to the Laplace equation for .
On an antiplane shear , the first strain invariant satisfy , . Restricting an isotropic objective strain energy density to this family determines only derivatives tangent to the family. It fixes and , but does not specify the whole Cauchy stress tensor. For example the neo-Hookean solid energy gives on this family. Even though the reference state is stress free, this is not generally a scalar multiple of .
For subsonic motion , an antiplane shear displacement satisfies . The displayed rescaling makes it a harmonic function of , so locally for a holomorphic function . Set . The Cauchy-Riemann equations then give . Keeping this potential normalization explicit avoids losing a factor of in the dynamic stress field. At sonic or supersonic speeds the elliptic harmonic reduction does not apply.
A harmonic conjugate satisfying and makes a holomorphic function. Its derivative packages the two antiplane shear stresses into the displayed complex field. On multiply connected domains a global potential additionally requires the appropriate periods to vanish; prescribed displacement jumps can instead be represented by branches of the potential.
For a crack on the real axis under applied shear traction , write for the additional complex stress potential for antiplane shear derivative. Reflection of the induced displacement gives . Traction-free crack faces therefore require ; intact portions have . This is a scalar Riemann-Hilbert problem. Endpoint regularity, single-valued displacement and the absence of additional remote loads fix its homogeneous terms.
For the moving semi-infinite crack, take the branch cut of on the negative real axis and ahead of the tip. With steadily moving antiplane shear, face tractions imply . The antisymmetric displacement response gives . Hence has jump . The Sokhotski–Plemelj theorem gives the displayed Cauchy integral, assuming convergence and no extra remote homogeneous loading. For it is purely imaginary, so . At fixed co-moving loading this ahead-of-tip stress is independent of speed; the displacement still has the factor .
For real , this analytic homogeneous field has real boundary values on both faces of the negative-axis crack, so it adds no face shear traction. Ahead of the tip it adds stress . Its stress tends to zero at infinity, but its primitive grows like , producing unbounded remote displacement and infinite total elastic energy. Thus merely requiring vanishing far stress does not uniquely fix the face-loaded crack solution. Excluding an added remote stress-intensity field, for example through the localized-load bounded-displacement far condition, removes this homogeneous ambiguity. Ordinary inverse-square-root tip stress remains allowed and has finite energy in any bounded neighbourhood of the tip.
For two semi-infinite cracks separated by a ligament, choose on the ligament. Its upper crack values are on the right and on the left. Multiplication by converts the Hilbert problem for an antiplane crack to an additive jump; the Sokhotski–Plemelj theorem gives the displayed solution, assuming convergence. A homogeneous term transfers an extra resultant through the ligament and has logarithmic displacement at infinity. The usual correction with no additional remote resultant excludes it. The far-field normalization is essential to uniqueness.
Choose at infinity, cut on the finite crack. Its upper crack value is , so has jump . The Sokhotski–Plemelj theorem gives the displayed Cauchy integral solution. It decays as for integrable weighted traction. A possible homogeneous term would give a logarithmic displacement period; it is removed for a dislocation-free finite crack with no extra remote loading.
An elastic stiffness tensor maps a small displacement gradient tensor to the stress tensor. Minor symmetries in each index pair ensure symmetric stress and dependence only on symmetric strain; major symmetry follows from an elastic energy and underlies reciprocity. Stability requires positive elastic energy on nonzero strains. In an isotropic material, , with Lamé parameters .
The two minor symmetries of the elastic stiffness tensor make it a map between six-dimensional spaces of symmetric strain and stress. An elastic energy gives major symmetry, so the matrix of this map is symmetric and has 21 independent entries. For a symmetry operation acting on strains with parity spaces of dimensions and , invariance eliminates the mixed block and leaves independent coefficients.
A rotation through about the third coordinate axis preserves the strain components and reverses . A symmetry-invariant elastic stiffness tensor cannot couple the two parity spaces. Its independent symmetric blocks therefore contain coefficients. A twofold axis alone does not impose invariance under every rotation about that axis.
A bending moment is an internal torque transmitted across a cut through a beam or elastic plate. For a slender linear elastic beam, up to sign convention, where is Young's modulus, the second moment of area, and the centreline curvature. The corresponding bending response of an elastic plate is described by its bending stiffness and curvature tensor.
The neutral axis is the line in the cross-section of an elastic beam where longitudinal bending strain vanishes. For a homogeneous beam in pure bending, zero resultant longitudinal force gives , so the neutral axis passes through the centroid. Fibres on its opposite sides are stretched and compressed. The second moment of area about this axis controls the relation between bending moment and curvature.
An elastic membrane is a thin deformable sheet whose transverse restoring force is supplied by in-plane tension. For uniform tension and mass per area , a two-dimensional small-displacement model has , where the pressure jump is defined from the lower fluid to the upper fluid. Fluid loading modifies its traveling modes through the acoustic wave on a tensioned massive membrane.
Two equal complex amplitudes with opposite transverse wavevector components sum to a cosine across a strip with edges . Identical phases satisfy the edge condition only for the odd transverse indices displayed. Equal magnitudes with opposite phase give the sine family; together the families form all Dirichlet strip modes , . The lowest axial phase velocity exceeds the unrestricted membrane wave speed, while its group velocity is smaller; neither should be substituted for the other.
Below the lowest strip cutoff, the axial wavevector is imaginary. A localized harmonic drive produces a displacement decaying as away from the source in the dominant lowest mode. Cross-sections still oscillate in time, but there is no far-field travelling axial wave. Several more rapidly decaying transverse modes can contribute near the source. For a symmetric central point drive, transverse modes vanishing at the centre are not excited.
The Euler-Bernoulli beam equation models transverse linear bending waves in a slender beam. The normalized equation has and may be reduced by the Schrodinger factorization of the elastic beam equation. Prescribing displacement and curvature at an endpoint supplies two boundary traces for its fourth spatial derivative.
A rotational spring boundary condition for a beam lets an endpoint rotate while imposing a restoring torque proportional to that rotation relative to its support. Let be the spring stiffness, with zero rest angle. Its stored elastic energy is , where the small beam cross-section rotation is .
At a right endpoint whose transverse position is fixed, add this energy and the applied-couple potential to the bending energy. The coefficient of the free rotation variation isHere is beam flexural rigidity, and is defined by external virtual work . End moment and rotation are conjugate variables in the beam principle of virtual work.[ref]
The Concept of Stress, Generalized Stresses and Equilibrium by Tomasz Wierzbicki. §§3.4–3.5, equations3.46 and3.52–3.57
The spring term and the following example are independently derived. At the left endpoint, the bending boundary term has the opposite sign: with no applied end couple, .For an original fixture model, hold the left endpoint position fixed, restrain its rotation by the spring, and apply a downward end force at distance . The root moment magnitude is , giving root rotation . Bending relative to that rotated root contributes to the tip displacement; rigid root rotation contributes . ThusWith , , and , these contributions are and , giving total. Root rotation is radian, within the stipulated small-rotation model.
As increases without bound, the root approaches a clamped boundary condition. At zero stiffness this particular end-loaded arrangement becomes a rotational mechanism; it has no finite static deflection for nonzero . A small-couple fixture check can estimate from measured moment and angle. The resulting beam root rotational compliance is distinct from deformation of the beam material.
Beam root rotational compliance is the incremental rotation of a beam's attachment relative to its supporting base per increment of applied root torque. For a linear rotational restraint with stiffness ,The angle is measured in radians, so the compliance can be reported in . The root's transverse position is held fixed in this model. The rotational spring boundary condition for a beam implements this finite restraint; a clamped boundary condition is the zero-compliance limit. End moments and section rotations are conjugate quantities in beam virtual work.[ref]
For an original static derivation, apply a transverse tip force to a beam of length and constant beam flexural rigidity . The root moment has magnitude , giving . In the small-angle approximation, root rotation contributes to tip displacement. Bending relative to that rotated attachment gives the usual cantilever contribution, soThis derivation assumes a linear elastic beam, no root translation and an effectively rigid supporting base. The second term is fixture motion rather than a change in material Young's modulus.
For stipulated , , and , the root rotates through radian. Root motion contributes , while bending contributes . Attributing the entire to a perfectly clamped beam would infer instead of the stipulated value six.
A proposed measurement uses a known force and lever arm to apply a root moment, with optical markers on the attachment and on the supporting base to measure their relative angle. A separate displacement channel can detect unwanted root translation. Fit the small-load slope of angle against moment; using only the beam-tip displacement would mix attachment rotation with beam bending. Load reversal tests whether one linear compliance adequately describes the fixture or whether backlash and hysteresis require another model.
Beam cross-section rotation is the signed change in orientation of a material section in the bending plane. The Euler-Bernoulli beam equation assumes that sections remain plane and perpendicular to the deformed centreline. With a consistent angle convention, the section rotation therefore agrees with the centreline tangent angle; for a graph ,The last step is a small-angle approximation, with the angle measured in radians. This kinematic relation underlies the axial bending strain, rather than being an extra condition imposed by every support.[ref]
For an original geometric profile, take with . At , the slope is , while the exact tangent angle is radians. Replacing it by overestimates the angle by about 0.33 percent. This is a chosen shape illustrating the approximation, not a measured equilibrium profile.
The beam shear angle records a possible difference between centreline slope and section rotation in a model that permits transverse shear strain. The Euler-Bernoulli kinematics set that difference to zero; a short or shear-compliant specimen can require a different model. A simply supported beam leaves its end section rotation free, whereas a clamped boundary condition prescribes it. Neither zero transverse displacement alone nor zero endpoint bending moment requires zero rotation.
The beam shear angle is the small-angle difference between centreline slope and material-section beam cross-section rotation:With transverse coordinate and kinematics , , the engineering shear strain is . The Euler-Bernoulli beam equation imposes ; a shear-deformable model permits and to vary independently. The primary beam account distinguishes these kinematics and relates transverse force to the resulting shear measure.[ref]
Applied Mechanics of Solids by A. F. Bower. §8.7.2, Summary of beam theory, Timoshenko rotation and force/displacement relation
For an original local example, suppose shape measurements give , while section markers give radians in the same sign convention. Then , about degrees. Setting the section rotation equal to the observed slope would erase this measured discrepancy by assumption.
In a simple linear shear model, the transverse force resultant is , with effective beam shear rigidity . Here is the shear modulus, the material area, and a section correction coefficient. Stipulating , and gives and . The correction coefficient accounts for using a reduced section model; it is not universally fixed at .
A physical test must measure both the centreline shape and section orientation, for example by tracking markers during loading. Shape alone determines but cannot independently determine without section-rotation information or an additional mechanical model. The comparison also requires compatible spatial resolution and angular measurement calibration.
Effective beam shear rigidity is the coefficient relating a transverse shear-force resultant to the beam shear angle in a reduced linear beam model:Here is shear modulus, is material area and is a beam shear correction coefficient. The coefficient has units of force, whereas beam flexural rigidity has units . A shear-deformable beam permits section rotation to differ from centreline slope; Bower gives the corresponding force relation and explains the correction coefficient's dependence on section geometry and the approximation used.[ref]
Applied Mechanics of Solids by A. F. Bower. §8.7.2, Summary of beam theory, Timoshenko force relation and shear-coefficient paragraph
An original energy calculation explains one familiar correction. For a homogeneous rectangle of width , thickness and area , adopt the classical parabolic shear-stress approximationIt has resultant . Its shear elastic energy per unit beam length isEquating this to the reduced-model energy gives . Thus follows from this particular energy-matching approximation; it is not a universal material constant or an exact coefficient for every beam theory.
The effect on a three-point bending test can be derived from that reduced energy. For a simply supported beam under central force , the magnitude of shear force is on each half. Hence and its contribution to central displacement is . Combining it with the bending response givesThe shear contribution becomes relatively more important as the span decreases.
For stipulated , , and , the two contributions are and . Shear adds twelve percent of the bending deflection. A span series with a load cell and direct midspan displacement readout can distinguish cubic bending dependence from linear shear dependence, provided contact and fixture contributions are also controlled. Inferring from the response additionally requires the section geometry and correction model.
The beam shear correction coefficient adjusts a reduced beam model's shear response for the nonuniform shear stress over a material section. With shear modulus , area , transverse force resultant and generalized beam shear angle ,where is effective beam shear rigidity. Bower's primary account calls this the Timoshenko shear coefficient and explains that its value depends on geometry, Poisson's ratio and how the approximate theory is matched to the underlying solid.[ref]
Applied Mechanics of Solids by A. F. Bower. §8.7.2, Timoshenko force relation and following shear-coefficient paragraph
An original energy-matching derivation makes the correction precise for one approximation. Assume uniform and a chosen shear-stress field with resultant . The shear elastic energy per unit beam length and its reduced representation areThusThe Cauchy-Schwarz inequality gives , hence for this definition. Equality requires uniform stress. This bound belongs to the stated energy-matching definition rather than every convention called a shear correction coefficient.
For the parabolic rectangular stress approximation used in effective beam shear rigidity, the squared-stress integral is , giving . Choose , and . Then and radians. Omitting the correction gives , underestimating this generalized shear angle by one sixth.
The generalized angle also differs from the peak local shear strain. Under the same parabolic approximation, peak stress is , giving peak strain . The values describe different reductions of the same chosen stress field. Identifying from a bending test therefore requires the section model and displacement readout, not merely a material modulus. For a three-point bending test, the shear deflection contribution varies as , whereas bending varies as ; a span comparison can help separate them.
Beam flexural rigidity is the coefficient relating a slender beam's bending moment to its curvature in linear bending. For a homogeneous material with uniform Young's modulus over the material area,where is distance from the appropriate neutral axis. The magnitude relation is ; signs depend on the chosen moment and curvature conventions. Integrating the linear bending stress over the section gives this coefficient.[ref]
For an original rectangular example, choose width , bending thickness and . The second moment of area is , giving . Doubling only the thickness multiplies by eight. Rotating the original rectangle by ninety degrees about its length instead exchanges width and thickness: increases by even though material area and modulus are unchanged.
Thus a bending experiment measures a combination of material response and geometry. Extracting requires the correct bending axis and second moment of area; the three-point flexural test is one route. This beam coefficient has units , distinct from the plate coefficient called bending stiffness. If modulus varies across a section, the relevant stiffness requires a material-weighted area integral and the appropriate neutral axis, rather than an arbitrary average modulus multiplied by .
A simply supported beam is prevented from moving transversely at its two supports while its ends remain free to rotate. In the small-deflection Euler-Bernoulli beam equation, a uniform span with transverse displacement and positive beam flexural rigidity has the support boundary conditionsHere is Young's modulus and is the second moment of area about the bending axis. The second pair expresses zero applied endpoint bending moment, since in the convention used here. It does not set the endpoint beam cross-section rotation or slope to 0. A clamped boundary condition instead constrains both displacement and slope.
For an original derivation, apply a downward central point force and take positive downward. Assume small elastic deflections, constant and no axial preload. Symmetry and force balance give an upward reaction at each support. On the left half, the bending moment is , so . Integrate twice, using and the symmetry condition , to obtainThus the midspan compliance of a simply supported beam isThe endpoint slopes are and : they are generally nonzero. This support geometry and central-load formula are used to infer material stiffness from a three-point bending test.[ref]
The moment-free natural boundary condition for a beam also follows from the principle of virtual work. For a central load, the total potential energy is . An admissible virtual displacement satisfies , while its endpoint first derivatives remain free. Two integrations by parts produce the boundary contributionThe terms multiplying vanish because the endpoint displacements are prescribed. Arbitrary endpoint values of then require there. The free end rotation and zero end moment are conjugate parts of the same variational boundary condition.
Clamping both ends changes the central-load deflection to , one quarter of the simply supported value for the same . It introduces endpoint reaction moments; it does not merely rename the same support. The clamped-beam Green function provides the corresponding fourth-order boundary-value solution. The support conditions likewise determine the simply supported beam normal modes, so a static stiffness measurement and a vibration measurement must use the same mechanical support model when they are compared.
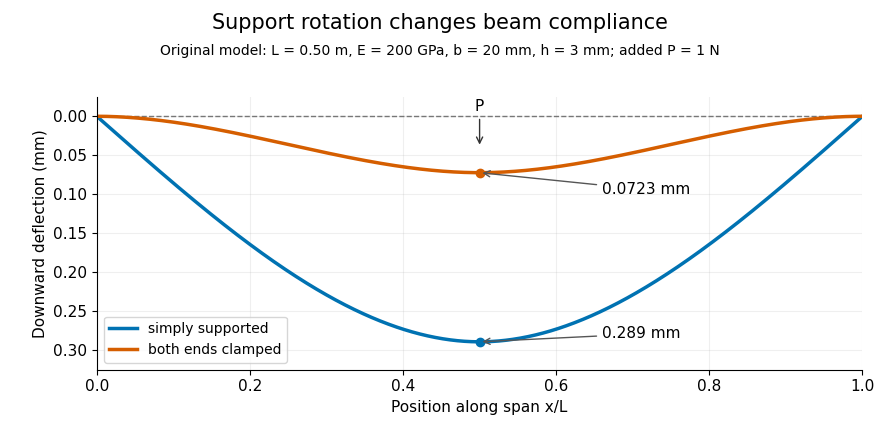
Original central-load beam profiles: allowing support rotation gives four times the midspan deflection of clamping both ends.
Details. A three-point bending test places a specimen on two separated supports and applies a central force. A load cell measures force, and a midspan displacement readout measures response. A direct plunger and extensometer can measure specimen deflection separately from machine crosshead displacement, as in the published Instron fixture arrangement.[ref]
Three Point Bend Test Fixtures by Instron. Principle of Operation and midspan deflectometer description
Fitting a proportional small-load segment estimates , where is the measured incremental midspan compliance. Record support spacing, load position and cross-section dimensions with that estimate.For stipulated , rectangular width , thickness and , the second moment of area is and . An incremental central load gives incremental deflection under the simply supported model, versus for the clamped model. Incremental readings remove an unchanged baseline deflection in this linear model; support settling, contact indentation and large rotations require separate interpretation.
A three-point flexural test loads a specimen through one central contact while two separated supports carry the reactions. In a small-deflection simply supported beam model, an incremental central force and the resulting midspan displacement determine the midspan compliance of a simply supported beam. With a known second moment of area, that response yields a flexural modulus.[ref]
Beam Displacements by David Roylance. Introduction; Example1 and equation7
The apparatus must distinguish specimen deflection from machine travel. The manufacturer's fixture description uses adjustable lower anvils and a central loading member; a direct midspan plunger can transmit deflection to an extensometer. A load cell supplies the force record.[ref] The crosshead displacement can also contain deformation of the frame and contacts.
For an original readout example, stipulate span , width and thickness , so . Suppose a linear loading interval gives direct midspan compliance , while machine travel gives . Applying the same beam relation to the two readouts givesThe apparent modulus is twenty percent lower. The numbers are chosen to isolate the displacement-channel effect; they do not characterize a particular fixture. Inferring a material Young's modulus further assumes the beam's linear, homogeneous bending model is adequate. Contact indentation, support motion and transverse shear strain can otherwise alter the measured compliance. The parent simply supported beam supplies the deflection derivation and support-comparison figure.
The moment-free natural boundary condition for a beam is the zero-end-moment condition obtained when an endpoint can rotate freely and no external couple is applied there. For positive beam flexural rigidity , it is . This differs from prescribing the endpoint beam cross-section rotation.
The simply supported beam gives the full principle of virtual work derivation. At its right support, the admissible virtual displacement obeys , but is arbitrary. The remaining bending boundary contribution is . Its vanishing for every permitted end rotation requires . Beam virtual work pairs end moments with rotation variations and forces with displacement variations.[ref]
An original modified boundary example shows why the missing external couple matters. Define a signed right-end couple by its external virtual work . The boundary coefficient then becomes , so the free-rotation condition is . With and , the endpoint second derivative is , not zero. This sign definition fixes the couple convention explicitly.
Clamping instead sets ; that restriction permits an unknown reaction moment rather than forcing it to vanish. Finite rotational restraint leads to a rotational spring boundary condition for a beam. These alternatives distinguish a prescribed motion from its conjugate natural load condition.
The midspan compliance of a simply supported beam is the incremental central deflection per incremental central load, with the support geometry fixed. For a uniform, small-deflection Euler-Bernoulli beam equation model without axial preload,Its units are length per force. The simply supported beam contains the derivation; the experimental use is to infer beam flexural rigidity or, with known geometry, Young's modulus.[ref]
Beam Displacements by David Roylance. Introduction and Example1, equation7
An original two-span example separates beam compliance from an assumed constant machine contribution. Suppose the same uniform specimen is tested over spans and . A machine-travel readout gives and . Assumewhere is unchanged between the tests. Subtracting the readings givesHence and . The inferred specimen compliances are and , with ratio . The raw readings have a different ratio because they include .
This beam compliance from two support spans relies on the unchanged-series-compliance assumption. Changing supports, contact indentation or shear contributions can invalidate it; two points fit its two coefficients without independently validating the model. A third span can test the cubic dependence. An incremental slope also differs from simply dividing a total displacement, including an initial offset, by the current force.
Beam compliance from two support spans separates a cubic span-dependent beam response from a span-independent contribution to the measured mechanical compliance. Assume the same uniform specimen, unchanged machine contribution and a small-deflection central-load model:Here is beam flexural rigidity and . The midspan compliance of a simply supported beam contains the basic numerical fit, while the beam source derives the cubic dependence.[ref]
Beam Displacements by David Roylance. Introduction; Example1, equation7
An original uncertainty example shows why distinct spans can still be too close. Let the actual model have , hence . Assign independent compliance standard uncertainties , and neglect span uncertainty for this example. Since the slope estimate is linear in the readings,Spans and give , about54percent of the actual coefficient. Using and instead gives about3.57percent with the same readout uncertainties. The close-span subtraction strongly amplifies those errors. At the larger relative uncertainty, simply treating as approximately linear is unreliable.
This conditioning of two-span beam compliance inference concerns measurement precision, separately from model adequacy. If shear adds a term proportional to , then has three unknown coefficients that two readings cannot identify. Changing contact or fixture compliance can likewise violate the assumed constant . Further spans and an independent deflection readout test those assumptions; two fitted points alone do not.
Conditioning of two-span beam compliance inference describes how perturbations in two measured compliances and support spans affect the inferred bending coefficient. In the model represents an unchanged series contribution and is beam flexural rigidity. The cubic beam term follows from the midspan compliance of a simply supported beam.[ref] The subtraction is sensitive when the spans are close, or when the beam-response difference is small compared with readout errors.
Let and temporarily treat the spans as exact. The sensitivity coefficients are and . Consequently,This is the standard measurement uncertainty propagation rule applied to a linear combination; the covariance term matters when the readings share errors.[ref]
For an original numerical comparison, stipulate , so , and independent standard uncertainties . Spans and give and , about 54 percent of . Increasing the second span to gives and , about 3.57 percent. The wider spacing makes the same compliance readout precision much more informative.
Span uncertainty enters through additional sensitivity coefficients:For uncorrelated span readings, their first-order contribution to is , before any compliance/span correlations are included. An identical additive readout offset cancels from , whereas a changing offset does not.
A practical span comparison holds the specimen, contacts, loading position and displacement channel as consistent as possible. Close spans amplify measurement noise; simply choosing distant spans can instead expose a failure of the assumed model. Shear produces a term proportional to , and changing contacts can change . A third span tests those assumptions. Finally, inversion to is strongly nonlinear near : the 54-percent case cannot be adequately summarized by a small symmetric relative uncertainty on .
A uniform elastic beam with endpoint conditions has normal modes for positive integers . Substitute into and impose the four endpoint conditions to obtain the displayed spectrum. Here is mass per unit length, is a second moment of area, and is beam flexural rigidity. frequencies proportional to distinguish flexural waves from the nondispersive ideal stretched string.
A prescribed initial beam profile may vanish at a pivot while having nonzero endpoint curvature. If the post-release pivot is moment-free, its bending moment condition is . The data then cannot have a classical solution with continuous curvature at the initial boundary corners. A finite-energy weak solution can still represent release from preparing end moments. For example has odd sine coefficients proportional to ; converges, giving finite bending energy. The displacement series takes the prescribed initial shape, but termwise endpoint second derivatives cannot be identified with its interior curvature limit. This conservative beam evolution does not have the immediate smoothing of a heat equation.
For a unit-length elastic beam with unit bending stiffness, the Green function of with at both endpoints is the displayed kernel. It is piecewise cubic and continuous through its second derivative, while . A constructive form is , with and . The right endpoint conditions determine these coefficients. Thus solves the clamped static beam problem.
The clamped-beam Green function is symmetric. Its explicit formula depends only on and . More generally, two integrations by parts give when at both endpoints. Applying this identity to two point-load responses shows that the displacement at one point caused by a unit force at a second equals the displacement at the second caused by a unit force at the first.
A straight slender elastic beam under axial compression loses stability when bending can decrease its total potential energy. With pinned ends a distance apart, its quadratic potential is . Stationarity gives , with at each end. The first nontrivial mode is , at . More generally , with an effective-length factor determined by endpoint constraints: for pinned-pinned, for fixed-free and for fixed-fixed. Real imperfections remove the perfectly sharp onset, and short columns can yield before this elastic instability.
For a pin-ended slender beam with unstressed profile , bending moment depends on curvature change: . An axial dead load gives in the small-slope model.
With and , the equilibrium branch connected to zero load has . The pole as approaches marks breakdown of the small-deflection model, not a physically infinite beam deflection.
Positive compression contributes negative quadratic potential energy , while positive bending stiffness contributes . A plane wave has , so sufficiently long waves grow exponentially. For displacement-fixed, moment-free endpoints at , the natural boundary conditions for a free endpoint on the slope give as well as . The modes are , and the first Euler buckling of an elastic filament threshold is . For truly clamped ends, , the threshold is instead , with first static mode . More generally,with the infimum taken over the specified endpoint class. At threshold there is a static zero mode and a marginal linear-in-time partner in the linear dynamics; above it the straight configuration is unstable.
Writing in the free Schrodinger equation gives and , hence . To encode initial velocity , choose the decaying primitive . A prescribed endpoint curvature becomes the time derivative of the imaginary boundary trace. This turns the normalized Euler-Bernoulli beam equation into a complex second-order boundary problem.
The second moment of area of a cross-section about an axis is , where is the perpendicular distance from that axis. Its dimensions are length to the fourth power. For a circular section of radius , polar integration gives . A slender rod with Young's modulus has filament bending modulus : the axial strain caused by curvature is , and integrating the linear elasticity energy density over the section gives per unit length.
The polar second moment of a planar area about a perpendicular axis is the integral of squared distance from that axis over area. It has units and equals the sum of second moments about two perpendicular in-plane axes through the same origin. For a disk of radius , . It is geometric, not a mass moment of inertia; a uniform cylinder has axial mass moment .
For a rectangular cross-section of horizontal width and vertical thickness , the second moment of area about its horizontal centroid axis is . Thus increasing vertical thickness is especially effective at reducing the curvature caused by a given bending moment.
Poisson's ratio is minus the transverse strain divided by longitudinal strain under uniaxial loading in isotropic linear elasticity.
Young's modulus is the ratio of axial stress to axial strain in uniaxial linear elasticity. For an isotropic plate, the bending rigidity is , with thickness and Poisson's ratio .
A tensile modulus experiment asks how much a specimen stretches under an axial force, while allowing its sides to contract freely. For initial cross-sectional area and an extensometer spanning initial gauge length , define engineering stress and engineering strain . In the proportional range,The ratio agrees with this derivative when the line passes through the unloaded origin. A fitted offset should not be mistaken for a material property. Young's modulus has units of pressure: . By contrast, the spring constant of a uniform tensile specimen of length is , with units . Two rods made of the same material can therefore have very different spring constants while sharing Young's modulus.
The normalization removes a useful geometrical ambiguity: doubling doubles the extension at a given force, whereas doubling halves it. For a round specimen ; for a rectangular one , using initial diameter , width and thickness . Diameter error matters twice at first order: . Specify material direction, temperature and loading rate when comparing Young's modulus. Lateral restraint changes the stress state and can prevent this experiment from measuring the uniaxial modulus.
The name commemorates Thomas Young, whose formulation of a measure of elasticity is recorded by the Royal Society. This attribution alone does not establish priority for every modern definition or experimental method.[ref]
Young; Thomas (1773–1829); physician, physicist and Egyptologist by Royal Society. Royal Society person record NA7947, Activity: formulation of a measure of elasticity called Young's Modulus
A flexural modulus is a stiffness inferred from a bending experiment using a specified stress–strain or force–deflection model. It has units of pressure. In a homogeneous, isotropic, linearly elastic slender beam with negligible shear and fixture deformation, it agrees with the Young's modulus entering . It is not the flexural strength or the load at fracture.
For a simply supported uniform beam in a symmetric four-point flexural test, let outer span be , loading contacts lie at and , and be their total force. Integration of the small-deflection Euler-Bernoulli beam equation gives midpoint deflection magnitudeEquivalently, with measured linear slope ,The formula uses midpoint displacement relative to the supports, not automatically the testing machine's crosshead displacement. The underlying moment-curvature law is the beam relation derived by Roylance; actual test conversion additionally requires the fixture spans and specimen geometry.[ref][ref]
For an original rectangular example, choose , , and , so . A corrected midpoint slope gives . This is an inferred model value from stipulated inputs, not a tabulated property of a named material.
If measured displacement includes an extra compliance , the measured compliance is . Ignoring positive fixture compliance reduces the apparent inferred modulus. Transverse shear, anisotropy, nonlinear response and time-dependent material behavior can also make flexural and tensile measurements differ. A reported value should therefore identify geometry, slope convention, displacement measurement and loading conditions.
A chord modulus is the slope of the line connecting two specified points on a stress-strain curve:Instron's glossary defines the calculation by selecting a starting strain and an ending strain and taking the slope between their curve points.[ref]
Modulus of Elasticity in the Instron glossary. Calculating Different Types of Modulus, Chord Modulus
Report the endpoints and strain definition with the value. A linear regression through every observation between them is generally a different estimator.For an original branch , subtraction and factorization giveWith , , and , the endpoint stresses are and , so . The secant modulus from the unloaded origin to the second point is instead . For this quadratic branch, the chord happens to equal the tangent modulus at the midpoint strain; this midpoint equality does not hold for every nonlinear curve.
More generally, the fundamental theorem of calculus gives, for a smooth branch,Thus a chord samples the response across a finite interval. Shrinking that interval can approach a tangent modulus, but measurement noise becomes more consequential when divided by a small strain difference.
For engineering stress and local engineering strain measured with an extensometer,An original specimen with and gauge length gives when force changes from to and local extension changes from to . A constant readout offset cancels in each difference when those same physical states are used; scale errors and machine compliance do not generally cancel. Specify temperature, loading direction and history, since a chord across different branches need not describe one material response.
The secant modulus at a specified point of a stress-strain curve is the slope of the line from the declared unloaded origin to that point:It depends on the chosen point when the curve is nonlinear. Mississippi State University's solid-mechanics laboratory material defines it geometrically in this way.[ref]
Secant Modulus in the Mississippi State University Virtual Laboratory for Solid Mechanics. Strength and Stiffness Characteristics, Secant Modulus definition and diagram at pointA
Specify both the strain measure and the origin when reporting a secant modulus.For an original branch , with and ,At , stress is , the secant modulus is and the tangent modulus is . The first slope relates accumulated stress and strain; the second predicts a small further increment. In linear elasticity through the unloaded origin they both equal Young's modulus.
The relation is especially clear for a smooth curve with . The fundamental theorem of calculus givesThus the secant modulus averages the local tangent slopes over that interval. A chord modulus instead joins two specified states, with slope ; its first state need not be the unloaded origin.
For a tensile measurement using initial cross-sectional area and local gauge length , engineering stress and engineering strain givewhere extension is measured from the appropriate unloaded state. An original , , and yields . A local extensometer avoids attributing all machine compliance to specimen extension. Retain the loading history, temperature and target stress or strain: a secant from an arbitrary preload and an unloading slope are different measurements, particularly after plastic deformation.
The tangent modulus is the local slope of a specified uniaxial stress-strain curve:It converts a small additional strain near into the corresponding first-order change of stress. For nonlinear elastic deformation, this slope can vary with the operating point.[ref]
Elastic Modulus in the Princeton Materials and Mechanics glossary. Elastic Modulus entry, final definition and derivative formula
In uniaxial linear elasticity, , so the tangent modulus equals the constant Young's modulus.[ref]Development of Constitutive Equations for Continuum, Beams and Plates by Tomasz Wierzbicki. Lecture4, p4-1, equation4.1; p4-2, uniaxial-tension assumptions
For an original nonlinear branch, stipulateThen . At , the stress is and the tangent modulus is . The secant modulus from the stipulated unloaded origin is instead . The two slopes answer different questions: the secant compares total stress and strain, while the tangent predicts a small further increment.
For , the tangent predicts . The exact change in the chosen polynomial is because the omitted term is . This is a linear approximation whose error decreases quadratically with the increment, not a claim that the nonlinear material obeys Hooke's law globally.
To estimate a tangent modulus experimentally, specify the stress and strain measures, temperature, loading history and loading rate. For engineering stress and engineering strain from a local extensometer,Fit a local window about the chosen operating point and check how the estimate changes with that window. For an original , and local slope , this gives . Differentiation amplifies measurement noise, and crosshead displacement can include machine compliance. Where plastic deformation or history-dependent response occurs, identify the loading branch: its local slope need not equal the unloading slope or an elastic material constant.
A small arc of a rotating thin hoop needs inward force per length . Its circumferential tension supplies this through curvature, giving tension and tensile stress . Hooke's law converts that stress to circumferential strain, which equals fractional radius change. Small strain, a slender cross-section and uniaxial linear elasticity are required; the cross-sectional area cancels at leading order.
MIT's Spring 2004 laboratory assignment Properties of Heat Treated Steel gives a concrete tensile testing protocol. Record transducer channels and calibration factors; measure specimen diameter and length, and the extensometer gauge length with its locking pin inserted. Zero the load cell, pin the threaded grips into their adapters, and attach the extensometer centrally. Apply the specified seating load, record actuator position, then acquire readings every second while moving at about . The handout derives engineering stress from load cell force, engineering strain from extensometer deformation, and Young's modulus by linear regression below the proportional limit; it warns that actuator-derived strain includes apparatus deformation.[ref]
Properties of Heat Treated Steel by Massachusetts Institute of Technology. Laboratory assignment 10, printed pp. 2–3: Procedure for Tension Tests; Calculations
For a modulus-focused measurement, select a load window after seating, hold temperature and loading rate consistent, and record force, local extension and crosshead displacement together. Fit within that window and calculate . Inspect the regression residuals for curvature; repeat at a lower maximum load and include unloading to check elastic deformation. These are diagnostic additions to the cited protocol, whose full test continues through failure. The handout's seating load is specific to its specimens and apparatus, rather than a universal preload.
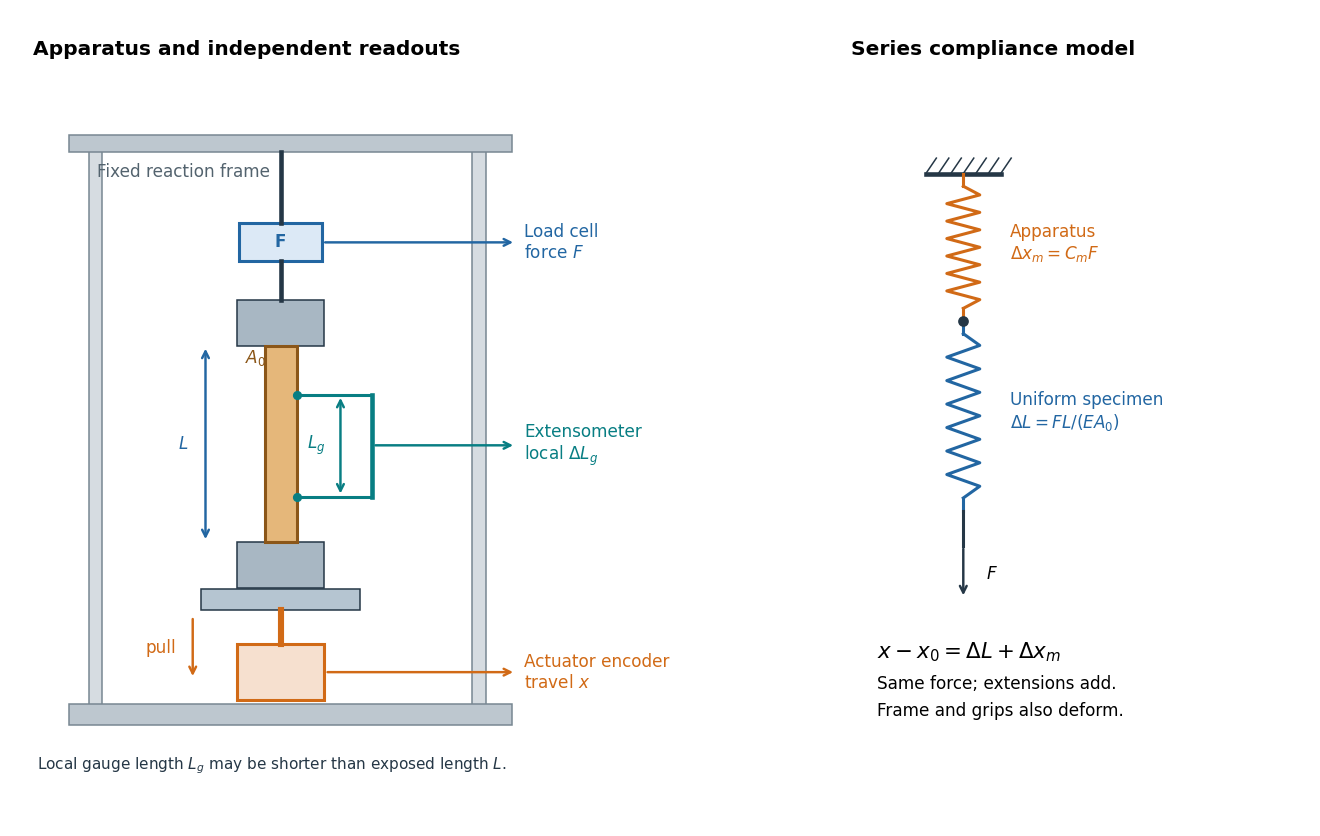
An extensometer measures the change between its contact points; crosshead displacement measures travel of the machine's moving member. The manufacturer Instron explicitly distinguishes local strain from travel that includes machine deformation and machine compliance.[ref]
Static Axial Clip-On Extensometers by Instron. FAQs: How does a clip-on extensometer work?; When should I use a clip-on extensometer instead of crosshead displacement?
The gauge length can be shorter than the uniform length between grips. Thus even a perfectly rigid machine generally has : the local instrument sees only its own segment. Do not divide one channel's extension by the other channel's reference length.Grips must transmit axial force without slip. Misalignment adds bending moment and makes opposite sides experience different axial strains; an instrument on just one side may then report a biased modulus. A changing extension offset, hysteresis between loading and unloading, or load-dependent fitted slope is evidence to investigate seating, slip or material response. A straight line over a short interval alone does not identify which is responsible.
Machine compliance is the extra load-path displacement per applied force attributed to the apparatus in a specified measurement model. Its units are , the reciprocal units of a spring constant. Here includes the frame, load cell, adapters and grips insofar as their deformation contributes to the recorded crosshead displacement . It is a property of that configuration and readout, rather than a universal constant of the testing machine.
Assume a uniform specimen with initial length , constant and Young's modulus , small axial elastic deformation, quasistatic loading, no slip, and a linear, length-independent apparatus response over the chosen force window. Equilibrium makes the same force act through specimen and apparatus, while their extensions add. The two springs in series therefore giveThe offset describes the displacement origin after seating; the slope describes total compliance. Fitting an intercept avoids forcing an arbitrary zero through the origin, but cannot repair slip or a curved response.
If all of is incorrectly attributed to specimen extension, the inferred modulus isFor positive , this is too small. The fractional bias is most serious for a short, thick, stiff specimen because its own compliance is small. A local extensometer instead has in this ideal model, excluding deformation outside its contacts.
A shaped specimen requires more care. With varying initial cross-sectional area and uniform , its axial compliance is in the one-dimensional approximation. Shoulder and end deformation must be included explicitly or remain identical between tests and be absorbed into an effective intercept. Changing only the extensometer gauge length on an unchanged specimen does not change its total compliance and cannot perform a two-length machine compliance separation.
Prepare two uniform specimens with the same material, direction and , but different deforming lengths . Keep grip engagement, adapters, loading window and measurement configuration equivalent. Determine separately by linear regression with its own displacement intercept. Subtracting the two series equations eliminates the common machine compliance:This is an inverse problem: one length supplies only one equation for two unknowns, while two distinct lengths separate the length-dependent specimen contribution from the constant contribution. In a graph of compliance against length, the slope is and the vertical intercept is . It is the compliance, not , that is linear in .
The dimensional analysis is revealing: , so . For , the ideal model requires . A negative fitted challenges the common-intercept assumptions or the measurements. Two lengths determine two parameters exactly, so they cannot test the assumed straight line; three or more lengths allow regression residuals to reveal departures. Nearly equal lengths amplify slope errors through the small difference . If the actual apparatus compliances differ by , the inferred length slope becomes .
The following values are stipulated arithmetic inputs, not measurements of a material. Take and lengths , . At forces , stipulate crosshead displacementsThe two different initial offsets deliberately test the use of intercepts. Linear regression of gives , andTheir reciprocal spring constants are and . The compliance-versus-length slope isso the recovered Young's modulus and machine compliance areThe corresponding apparatus spring constant is .
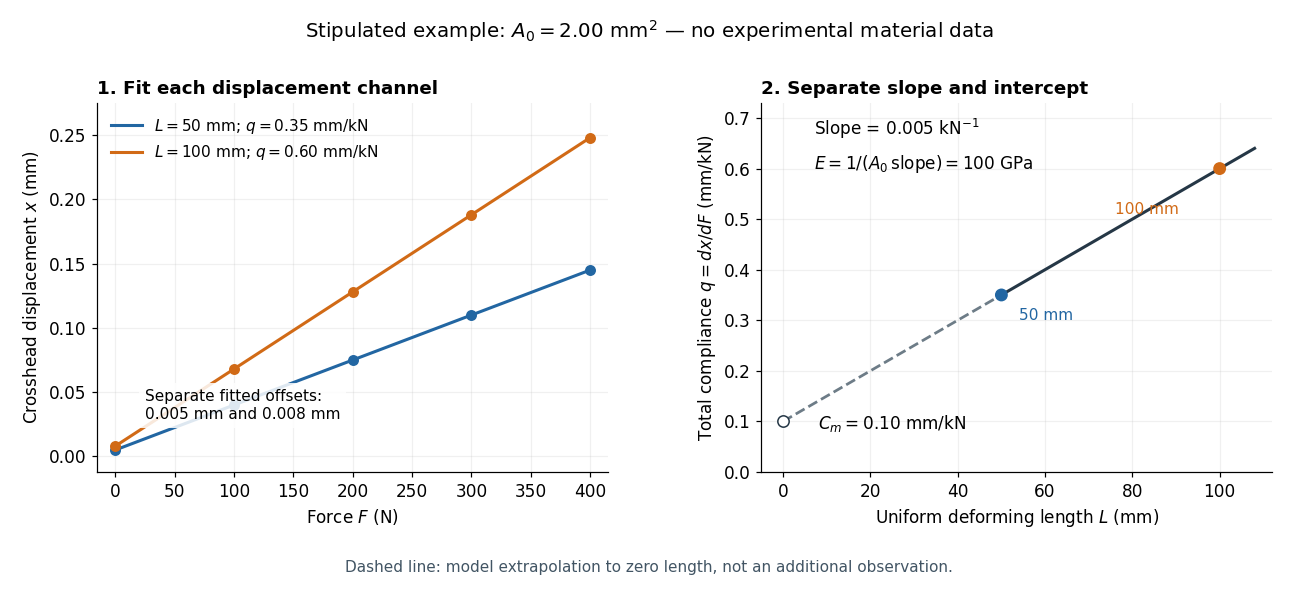
Stipulated displacement fits separate length-dependent compliance from apparatus compliance
. Original calculated example, not experimental material data. Left: independent linear displacement fits at lengths 50 and 100 millimetres retain their different offsets. Right: the line through the two compliance values has slope 1/(EA0) and intercept Cm. The dashed segment extrapolates the model to zero length; it is not a third observation. Details.Check the reconstruction at . The machine contribution is , and the two specimen contributions are and . Adding the respective offsets gives the stipulated and . An extensometer spanning on either ideal uniform specimen would instead read extension: engineering strain , at engineering stress . Their ratio is again . Ignoring machine compliance gives apparent moduli and even after removing the offsets. No yield point or real material identity is implied by these stipulated linear inputs.
Linearity and reversibility answer different questions. The proportional limit ends the interval in which axial stress is proportional to axial strain. Elastic deformation means that deformation is recovered after unloading; a nonlinear response can still be elastic. Conversely, a short straight portion of a loading curve does not by itself demonstrate recovery.
To check recovery, unload and examine the local extensometer strain relative to its initial value, allowing for instrument resolution, drift and any time dependence. A residual extension can indicate plasticity in continuum mechanics, but grip slip can produce a residual in crosshead displacement without the same local residual. Compare the channels before assigning the effect to the specimen. Yield point concerns the onset of irreversible deformation; a specified offset proof stress is an operational convention rather than Young's modulus. For example, a offset proof stress is the intersection of the loading curve with , using the correctly referenced strain. Report the fitted stress/strain window and the unloading evidence alongside the modulus, so that apparatus seating, departure from linearity and onset of plasticity in continuum mechanics remain distinguishable.
Fracture toughness measures resistance to crack advance under specified loading and environmental conditions. In linear elasticity, is the critical stress intensity factor. For opening-mode loading, a valid plane strain measurement is denoted , with units , commonly . It differs from a tensile yield strength: a crack changes the near-tip stress concentration.
For a fixed geometry with , the threshold givesFor example, , and give in this idealized geometry. The crack-tip plastic zone must remain small for the elastic intensity description to apply; extensive plasticity in continuum mechanics requires a different characterization.[ref]
A thin elastic plate model may instead prescribe a critical front curvature . Such a model parameter cannot be substituted numerically for without a relation specific to that fracture model.
Crack growth becomes energetically possible when the energy release rate reaches its critical value. For fixed crack geometry this gives a brittle-failure stress scaling as .
For linear antiplane elasticity with body forces and Dirichlet data proportional to time, uniqueness gives at any fixed crack length . The minimized elastic-plus-load potential and its energy release rate scale quadratically. The local Griffith fracture criterion laws are , and , with positive toughness .
If is finite and continuous near the initial length, it is bounded there by . Continuity of the crack path keeps it in that neighborhood for a positive interval. Choose the interval short enough that ; complementarity then forces zero growth throughout it. This proves a positive initial waiting time without assuming the crack is stationary in advance.
The decrease in potential energy per increment of crack area under specified loading constraints. Its critical value is a crack-growth threshold, not energy stored per specimen volume.
Use antiplane energy and normalize the tip singularity as plus a less singular term. The energy release rate is the small-circle flux . Here , and . Integrating over gives the displayed coefficient. The full three-dimensional antiplane stress has squared Frobenius norm , so its leading norm ahead of the tip is . These constants depend on the normalization of the stress intensity factor.
The threshold energy release rate for propagation of a specified crack under specified environmental and loading conditions.
A requirement that a crack penetrate a pressure boundary and produce a detectable leak before unstable fracture. A simple screening comparison uses critical crack size versus wall thickness, but the result depends on crack geometry and on whether stress or pressure is held fixed.
A conservative material-screening upper bound obtained by requiring wall penetration before fast fracture even at a stated yield-limited stress. Substituting a thickness-dependent pressure stress instead yields a different fixed-pressure inequality; the two comparisons must not be conflated.
The reduction in a mechanical system's potential energy per incremental crack area under specified loading conditions. In small-scale-yielding linear elasticity, mode-I plane strain gives with . The critical value includes the dissipative processes associated with crack advance.
A region of irreversible deformation near a crack tip where an elastic singular-field extrapolation would exceed the material's local yielding response. Its size depends on loading and constraint. Plastic work and blunting can raise resistance to crack extension.
An amplitude characterizing a near-tip linear-elastic crack field for a specified loading mode. The mode-I opening factor scales as the displayed expression for a suitable crack geometry factor . It is not itself the local stress, and large-scale plasticity can invalidate a linear-elastic characterization.
Articles were limited to the first 100 out of 164 total.
Articles by others on the same topic



Linear elasticity is a foundational concept in the field of mechanics of materials and structural analysis that describes how solid materials deform under applied loads. It assumes that the relationship between stress (internal forces) and strain (deformation) in a material is linear and reversible within the elastic limit of the material. This means that if the applied load is removed, the material will return to its original shape without permanent deformation.