Continuum mechanics describes the motion and deformation of matter through fields such as mass density, velocity field and stress. Its continuum approximation replaces individual atoms or grains by small material regions: each region must contain many constituents while remaining small compared with the scale of the phenomenon. A rubber strip being stretched and water flowing down a pipe can therefore be studied with the same local principles of mass conservation, momentum conservation and energy conservation.
The distinction between materials enters through a constitutive equation: a solid can sustain a static shear stress, whereas an ordinary fluid keeps deforming under one. Combining a constitutive equation with the Cauchy momentum equation and appropriate boundary conditions predicts measurable quantities such as a beam's displacement or a pipe's volume flux. The separation between universal balances and material-specific response is what makes the subject useful across elasticity, plasticity in continuum mechanics and fluid mechanics.
Plastic deformation is the part of a body's deformation that remains after the applied stress has been removed. Bend a metal wire gently and it springs back through elastic deformation; bend it far enough and its unloaded shape changes. In small-strain plasticity in continuum mechanics, the total strain is separated as , where the superscripts denote elastic and plastic parts.
In a crystal, dislocation glide can produce plastic deformation without all the chemical bonds across a plane breaking simultaneously. Repeated plastic deformation can increase the required yield stress through work hardening. A loading-and-unloading tensile testing experiment distinguishes the recoverable extension from the residual extension; the area of a closed stress versus strain curve measures net supplied mechanical work per unit initial volume in the small-strain description. It equals dissipation when the material's internal state also returns to its starting value. This distinction is essential when shaping a component permanently while keeping its service loads within the elastic range.
A slender flexible body modeled by a moving curve that transmits tension while its bending stiffness is neglected. For a uniform stretched string with constant tension and linear mass density , small transverse oscillations obey ; see the wave equation on a string.
For a body occupying , the rate of change of equals the body forces and surface tractions. With the Cauchy stress tensor, the local form is .
Contact mechanics studies how touching bodies deform, transmit forces and separate. Even a ball that appears to touch a flat surface at one point develops a finite contact patch: local elastic deformation spreads the load into a nonuniform pressure distribution. Hertzian contact is a useful ideal model when the surfaces are smooth, the contact patch is small and adhesion and friction can be neglected.
The contact patch is part of the solution, rather than a prescribed loaded area. In nonadhesive contact the nonpenetration constraint prevents overlap, and the normal contact force can push but cannot pull; unilateral contact complementarity joins those requirements. Pressing a spherical probe into a specimen while recording force and indentation tests the contact law and can determine a reduced elastic modulus. Surface roughness, plastic deformation and adhesion require additional modeling, especially when interpreting a measured pull-off force.
The center of pressure summarizes where a distributed normal pressure acts. On a planar contact region in , take a nonnegative pressure field and positive total normal force . Its center of pressure is the pressure-weighted positionIt is a continuous weighted mean, rather than necessarily the point of largest pressure. For discrete normal forces at , replace the integrals by sums. The resulting convex combination places the center of pressure inside the contacts' convex hull, or support polygon.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure (CoP) and Zero-moment point (ZMP), The special case of flat terrain
This definition preserves the torque as well as the resultant normal force. About the origin in the contact plane,A single vertical force applied at gives the same torque. Thus its line of action passes through the center of pressure. Conversely, force-and-torque measurements reconstruct the point throughThe origin and sign convention are part of these equations; moving the moment reference above the contact plane requires the corresponding torque translation.
For an original discrete example, four vertical reactions of , , and act at the successive corners , , and in metres. Their total normal force is , with and . Hence the center of pressure is . A rigid plate on four load cells provides a simple force platform implementation: calibrate the force channels and positions, then test known vertical loads at known locations. Subtracting the unloaded plate's own force and moment removes its contribution when reconstructing the added load. This is a proposed measurement test, not experimental data.
A continuous example shows the inverse problem hidden by this useful compression. On a rectangle of length and width , put and choose profiles independent of :Both profiles are positive on . The added polynomial has zero integral and zero first weighted integral:Thus both profiles give and the same center of pressure , while their peak pressures are and . These are pressure distributions with identical resultant force and center of pressure. For , and , both give despite different local loads. A force platform alone therefore does not identify every local pressure.
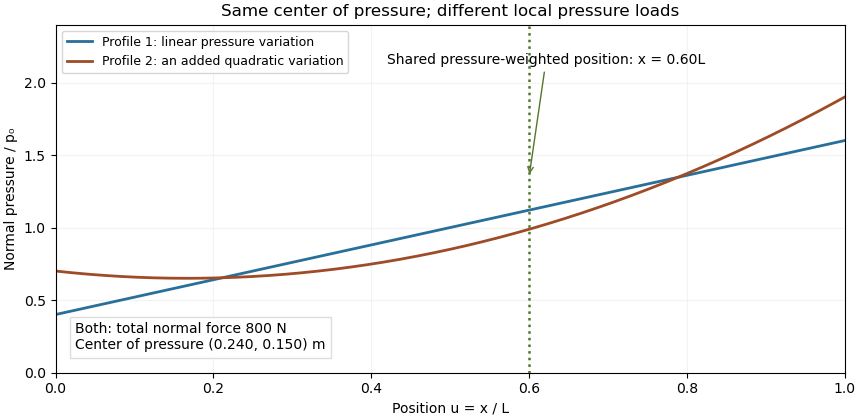
Two limits matter. If , the normal-pressure center of pressure is undefined. At fixed , an absolute moment error changes the reconstructed by , so fixed absolute measurement uncertainty is amplified as a contact unloads. Also, tangential contact forces can leave a residual contact torque at the center of pressure: with full resultant ,Selecting the normal-pressure centroid does not force this yaw torque to vanish.
Under the gravity-only, resting assumptions of support polygon, the center of pressure coincides with the horizontal center of mass projection. During motion it need not. For a planar model driven only by gravity and ground contact forces, at fixed center of mass height and with constant angular momentum about that centre, force and torque balance give . The acceleration term explains why the center of pressure is a contact-force measurement rather than a general substitute for center of mass position.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, equations cop and zmp and their stated constant-height/angular-momentum assumptions
In terrestrial robot locomotion, the center of pressure is the ground point summarizing the normal load shared by the active contacts. With contact positions and nonnegative normal reactions , its coordinates are the weighted averages and , provided the total normal force is positive. It lies in the current support polygon, but is a contact-force quantity rather than the robot's center of mass position.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure (CoP) and Zero-moment point (ZMP), flat-terrain definition
Force-sensor coordinates matter when reconstructing this point. Suppose a sensor origin lies height above a horizontal contact plane, with parallel coordinate axes. If it reports force and moment , the plane point is located at relative to that origin. Moment translation givesThe ground-plane transformation of a measured contact wrench must therefore precede interpreting moment/force ratios as a contact location.
For an original sensor example, take , force , and measured roll/pitch moments . The reconstructed point is . Ignoring the origin height would instead give . Those millimetre differences are coordinate effects, not a change in the physical pressure distribution.
During motion, the contact point need not equal the horizontal projection of the center of mass. The source's constant-height, negligible-angular-momentum-rate model relates their difference to horizontal acceleration; those assumptions must be established before using that simplified relation.[ref] A robot-foot experiment can compare known applied loads with the sensor's translated force/moment measurements. When approaches zero, reconstruction becomes sensitive to moment error; at zero normal load the normal-pressure point is undefined. A residual yaw couple may remain, as explained in residual contact torque at the center of pressure.
A ground-plane transformation of a measured contact wrench combines a change of coordinate axes with a change of the point about which moments are reported. A six-component wrench is incomplete without both pieces of metadata. Drake's primary SpatialForce reference explicitly tracks the application point and expressed-in frame separately from the stored force and torque values.[ref]
SpatialForce class in Drake documentation. Detailed Description; Shift and ShiftInPlace
Let rotate sensor-frame components into ground-frame components, and let be the ground-frame vector from ground origin to sensor origin . For measured force and moment about , the equivalent result about isThe plus sign uses the stated vector from the new origin to the old one. A shift expressed with the opposite vector uses the opposite sign. The offset and force must be expressed in the same axes before taking the cross product.
For a planar normal-pressure reconstruction with , computeThe special parallel-axis height correction in center of pressure is recovered with and .
For an original rotated-sensor example, use a 90-degree rotation about , sensor readings and , and . Rotation gives and . The translated moment is , yielding . The yaw moment remaining at that point is , so translating to the centroid does not erase the entire wrench.
A bench check applies known loads at known ground locations and repeats after changing sensor orientation. Geometry, tare loads, units and axis signs must all be included. A correct rotation with the wrong moment origin can still give an incorrect pressure location; a small normal load also amplifies reconstruction uncertainty.
The center of pressure locates the resultant of a distributed fluid pressure load relative to its moment. On a planar surface carrying parallel pressure forces, the first-moment ratio in center of pressure applies. On an airfoil, pressure variation and its resultant can change with the flow state, so the point is not a permanently fixed geometric centre. NASA's primary account explicitly distinguishes a moving center of pressure from retaining a force and pitching moment about an aerodynamic center.[ref]
Center of Pressure by NASA Glenn Research Center. Center of Pressure, Angle of Attack, and Aerodynamic Force sections
For an original hydrostatic plate example, take a vertical rectangle of width , extending from the free surface to depth in a constant-density fluid. If the same atmospheric pressure acts on its other face, the net gauge pressure at depth is . This hydrostatic relation follows from vertical force balance.[ref]
The Feynman Lectures on Physics, Volume II by Richard Feynman and others. Chapter 40, §40–1, Hydrostatics
The resultant and its depth areFor , , and , the net force is at depth . The area centroid is only one metre below the surface; the increasing pressure shifts the load's centroid downward.A tank demonstration can infer the resultant line from the force and hinge moment on a small plate while changing the water depth. The plate's own gravitational moment and the pressure on both faces must be included. This tests a specified pressure-load model, not a general claim that the point always lies below every geometric centre.
For aerodynamic net loads, differences of pressures on opposite faces can have both signs. The convex-hull property proved for nonnegative contact pressure then need not apply, and a small resultant with a finite moment makes its location ill-conditioned. A curved surface or a general wrench may also require a residual couple rather than a single force that removes every component of torque. The resultant convention and moment reference are therefore part of the definition.
A residual contact torque at the center of pressure is the moment left after translating a planar contact's resultant force to its normal-pressure centroid. Let the resultant wrench at an origin in be force and moment , with . Put , where and . Translation givesThe two horizontal moment components vanish, but the yaw component need not. The zero-moment-point construction for flat robot contact removes moments perpendicular to the surface normal; it does not assert that every component is zero.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, An aside: Zero-moment point derivation
A useful invariant makes the limitation exact. Since ,If this scalar is nonzero, no change of the moment origin can eliminate the entire moment vector. Replacing the whole contact by only one force at the center of pressure would discard that information.
For an original two-contact example, put equal normal loads of at and metres. Add tangential forces at the positive position and at the negative position. The total force is , the pressure centroid is the origin, and the opposing tangential forces give a pure yaw couple of . A friction coefficient of at least permits the stipulated tangential magnitudes at these loads.
A normal-load-only reconstruction would identify the correct centroid while missing the couple. A sensor measuring all force and moment components can distinguish the two situations. The origin, surface orientation and axis signs must be retained when comparing measurements. Near zero normal load, the centroid reconstruction itself becomes singular, independently of whether a tangential moment remains.
Pressure distributions with identical resultant force and center of pressure demonstrate that a pressure centroid is not a reconstruction of a pressure field. A normal-load measurement and its two first spatial moments constrain onlyA perturbation preserving all three integrals leaves the resultant and center of pressure unchanged. It is physically admissible only when the perturbed field remains nonnegative under the nonadhesive pressure model. The polynomial profiles in the parent article give one smooth example; the following construction shows that even a peak-pressure bound is missing.
Take a rectangular region of length and width , centered about its midpoint, and fix a normal load . A uniform field has pressure and centroid . Instead place the entire load uniformly on a smaller centered square of side , with zero pressure outside that square. Its pressure isSymmetry fixes the same centroid, and integration still gives total force . Yet its peak is , which has no upper bound as shrinks. Smooth symmetric concentrated profiles can provide the same conclusion if a continuous pressure field is required.
For an original numerical example, let , , and . Uniform pressure is . Concentrating the same load on a centered square gives while preserving the measured point . Both satisfy the stated nonnegative-field moment constraints.
Consequently a force/moment sensor cannot infer local peaks from the centroid alone. Local contact pressure from additional spatial measurements needs more data or justified material/contact assumptions, such as a constitutive model and known geometry. The source's normal-force centroid definition explains exactly which resultant information was retained.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure definition
The examples are inverse-problem constructions; they are not claims that arbitrary pressure maps can be realized by the same elastic surfaces.Local contact pressure from additional spatial measurements requires more information than total normal force and two first moments. One explicit reconstruction model partitions the contact into cells of known areas and centroids , assuming uniform pressure within each cell. Writing givesThese are three linear measurements of the cell loads. They need not determine every , as the nonuniqueness argument in pressure distributions with identical resultant force and center of pressure shows. The primary centroid definition specifies precisely which force/moment information is retained.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure definition
For an original four-cell example, use equal cells centered at successive positions with . Loads give and centroid . Adding to these loads changes neither the sum nor either first moment. Nonnegative loads permit . The alternative therefore gives the same global measurements.
An independently calibrated measurement of the first cell load resolves this one missing degree of freedom under the four-cell model. If it reads , the global moment equations recover the original other three loads. Their cell pressures are . Measuring all four cells instead provides redundant data for checking total load and the assumed geometry.
The local sensor output must actually represent a known cell-integrated force, or have a validated response model; a point sample cannot automatically be treated as an area average. Calibration errors, cell cross-coupling and imperfect coverage become additional measurement inputs. Spatial pressure-map resolution below a sensor cell remains limited even when every cell average is known: unmeasured within-cell peaks are not recovered by simply drawing a finer image. Constitutive or smoothness assumptions can add information, but must be identified as assumptions rather than extra measurements.
Spatial pressure-map resolution below a sensor cell concerns which variations of a contact pressure field can actually be distinguished by spatial measurements. A smaller display pixel does not imply a smaller independently measured contact region. The response of a pressure sensor, its sampling positions and any imposed reconstruction assumptions must be specified.
For an original ideal array model, cell of known area reports an area-average pressure,It determines that cell’s load , but not every value inside it. For a more general linear response, with known sensitivity . The null space of a spatial pressure measurement consists of perturbations whose weighted integrals vanish for all measured channels. Nonnegative fields that differ by such a perturbation remain indistinguishable in that model.
Consider square cells of side aligned with , and compare fields independent of :Every cell contains one full cosine period, so both fields give every channel the identical value . Yet varies between and . With and , a perfectly uniform field and a field spanning – produce the same ideal map. On an aligned finite rectangular array, the added cosine also has zero first moment within each cell, so even the global resultant and center of pressure agree. This is an inverse-problem construction, not a claim that both profiles arise from the same elastic contact geometry.
Cell averaging has a calculable spatial response. For a one-dimensional centered interval of width , averaging a complex wave multiplies its value at the interval center byThe first zero at explains the erased cosine above. Sampling introduces further ambiguity; even translating this ideal array cannot recover a component erased by its aperture at every position.
A regularity assumption can supply a conditional bound. If has a validated spatial Lipschitz constant over a square cell, its center value differs from its area average by at mostEvery point in the cell is at most half the diagonal from its center, so integrating the Lipschitz inequality proves this bound. For and , it gives about . The array readings alone do not establish that slope bound.
Interpolation chooses a finer representation from the measured values. SciPy explicitly describes its array zoom operation as spline interpolation; it does not describe collecting new pressure data.[ref] A proposed apparatus test scans a known small indenter across a sensor array at controlled total load, comparing independent load measurements with channel responses. The indenter’s actual contact area, load spreading, sensor cross-coupling and repeatability must be measured before inferring a spatial response. Additional smaller-aperture measurements or justified mechanical constraints can improve identifiability; a smoother image alone supplies neither.
The null space of a spatial pressure measurement consists of changes to a contact pressure field that leave every measured channel unchanged. For a linear response model on a contact region , writeThen . Two fields have identical outputs precisely when their difference lies in this kernel of a linear map. The sensitivity kernels , their support and the admissible class of pressure fields are part of the model.
For an ideal area-average sensor, inside cell and zero elsewhere. A positive and negative perturbation within one cell can cancel in its integral while remaining invisible to the other cells. This is the mechanism behind spatial pressure-map resolution below a sensor cell. It is a nonuniqueness of the observations, even if their numerical values are exact.
An original finite model divides each of two equal-area sensor cells into two equal halves with constant pressures . The observed averages areThis matrix has rank two and a two-dimensional null space spanned by and . Thus the fieldsboth produce . Their peak pressures differ by . Adding an independent measurement of determines the first pair, but still leaves the second pair’s difference undetermined. An extra channel helps only if it adds an independent constraint on the missing directions.
The linear null space is not itself a set of physical pressure fields: its perturbations can have either sign. For a nonadhesive contact, require as well. With the uniform field above, perturbations are admissible for . Positivity restricts the ambiguity without removing it. In contrast, a zero area-average reading together with a nonnegative pressure assumption forces pressure to vanish almost everywhere in that cell under the ideal model.
For a chosen finite basis of pressure fields, a singular value decomposition identifies the matrix null space. SciPy’s pinned implementation constructs its basis from right singular vectors and uses a relative singular-value cutoff to determine effective numerical rank.[ref]
SciPy 1.16.2 documentation. scipy.linalg.null_space, pinned v1.16.2 scipy/linalg/_decomp_svd.py, docstring and implementation lines 333–403
A numerical cutoff and an exact zero singular value are different notions. Near-null directions of a pressure sensor array have small nonzero responses and can amplify measurement error: a dimensionless singular value of turns a channel-error component into a coefficient error when inverted without regularization.A proposed apparatus check applies controlled local loads to estimate the sensitivity kernels, then compares fields with similar predicted channel outputs using independent spatial measurements. Contact area, load spreading and cross-coupling must enter that comparison. A reconstruction algorithm may select one smooth or nonnegative solution, but the selected structure is additional modeling information; it is not automatically an independently observed subcell pressure map.
Near-null directions of a pressure sensor array are changes of a modeled pressure field that produce small, rather than exactly zero, changes in the sensor outputs. They distinguish an ill-conditioned reconstruction from the exact ambiguity in the null space of a spatial pressure measurement. A formally invertible response can still contain very little usable information about some pressure patterns.
Choose a finite basis for the pressure field and a linear response , where contains pressure coefficients, the readings, and measurement error. With common pressure units for the coefficients and readings, letbe a singular value decomposition. A change changes the noiseless readings by . Inverting that component divides the measurement error by . If the errors have covariance , the standard deviation of the reconstructed coefficient along is . An exact zero gives no inverse; a small nonzero value gives noise amplification.
An original two-region example has uniform pressures and sensor matrixBoth sensors mostly measure the same average. Write and . Then and . Uniform pressures give readings ; the markedly different pair gives only . The matrix is invertible, but these outputs differ by just in one channel.
If each channel has independent standard uncertainty, the direct contrast estimate is , with standard deviation about . The matrix’s smallest singular value is approximately , consistent with roughly uncertainty in the unit-length contrast direction. Nonnegative pressure constraints can restrict the admissible answers, but do not turn these noisy readings into precise contrast information.
Numerical rank depends on a chosen tolerance. SciPy’s pinned null-space implementation compares singular values with a relative cutoff and returns right singular vectors beyond the retained rank.[ref]
SciPy 1.16.2 documentation. v1.16.2 scipy/linalg/_decomp_svd.py, null_space, docstring and lines 395–403
A floating-point cutoff detects numerical scale; a physical decision about usable information must also consider sensor noise, response uncertainty and the chosen pressure basis. Rescaling a coefficient can change a raw singular value without changing the apparatus.A noise-whitened pressure sensing matrix accounts for unequal or correlated measurement errors before comparing response strength. For positive-definite error covariance , analyze together with the same coefficient units and normalization. A duplicate noisy channel does not provide the same information as an independent measurement of the weak contrast.
Tikhonov regularization can limit amplification by using factors instead of . Relative to the true noiseless coefficient, this introduces attenuation . For and , that factor is about : the weak component is nearly suppressed. A smoother map can therefore have less noise while omitting real contrast. A proposed validation applies independently known pressure patterns that excite both average and contrast directions, repeats the measurements, and reports the error covariance and response-model uncertainty alongside reconstruction results.
A noise-whitened pressure sensing matrix measures how a contact pressure pattern changes sensor outputs relative to their joint noise, rather than their raw numerical size. For a linear measurement modelassume the error covariance is positive definite. Choose an invertible matrix satisfying . ThenThe transformed errors have identity covariance. This is the whitening transformation documented in the primary SciPy covariance interface; its example obtains approximately identity sample covariance from simulated observations.[ref]
A Cholesky decomposition supplies . Compute and by solving triangular systems rather than forming an inverse unnecessarily. The least-squares residual becomesThus an output change is significant according to its noise covariance, not merely the Euclidean length of the raw readings. The original pressure basis and its units must still be stated; whitening rows does not remove arbitrary column rescalings.
For an original two-channel example, use numerical pressure values in kilopascals andThe separate standard deviations are and with correlation . A residual whitens to , giving squared length about . The residual instead whitens to , giving squared length . Treating the channels as independent would assign both residuals squared standardized length two. The positively correlated noise makes opposite-sign discrepancies much less plausible than a shared shift.
A simple repeated-measurement model illustrates the information consequence. If two sensors measure the same scalar pressure with equal standard deviation and correlation , their mean has variance . At the standard deviation is about , rather than the independent-channel value . Adding an almost duplicate channel therefore supplies little improvement for that common pressure.
The pressure-map information matrix is . In a full-column-rank linear Gaussian model with known , the unconstrained weighted least-squares estimate has covariance . Small singular values of identify near-null directions of a pressure sensor array after accounting for noise. Alternative whiteners differ by an orthogonal row transformation and give the same information matrix; an individual whitened row need not represent one physical sensing cell.
A proposed array characterization applies repeatable known pressure patterns, estimates the channel covariance from repeated residuals, and checks the covariance on independent repeats after whitening. Drift and response-model uncertainty must be included if they belong to the intended error model. If is singular, a simple inverse whitening is unavailable: exact zero-noise constraints and redundant stochastic directions need separate treatment. A visually smooth pressure reconstruction does not establish that its weak directions were measured precisely.
A pressure-map information matrix quantifies which coefficients of a modeled contact pressure field are constrained by a sensor array, relative to its measurement noise. For with fixed positive-definite error covariance , defineHere is the noise-whitened pressure sensing matrix. Whitening removes the output-noise covariance from the residual metric; the primary SciPy covariance interface documents this transformation and demonstrates near-identity covariance on simulated observations.[ref]
The matrix is positive semidefinite because . Its null space is exactly the null space of : an unobserved pressure change remains unobserved after invertible row whitening. With independent Gaussian errors of known covariance, the log likelihood is a constant minus . Differentiating twice with respect to gives negative Hessian , identifying it as the Fisher information for this stated model.
If has full column rank, weighted least squares givesThis covariance follows by substituting and multiplying the error matrices. It concerns the unconstrained linear estimator with known response and covariance, not every reconstruction algorithm. Nonnegativity constraints, regularization and uncertain sensitivity kernels require additional treatment.
An original two-cell example begins with one average-pressure measurement, , with standard error. In numerical kilopascal coordinates,Its eigenvalues are and zero: the mean is observed, but the pressure difference is not. A second independent copy doubles the information matrix while leaving the difference unobserved. More repeats of the same mixture improve precision only in the already measured direction.
Instead add a direct measurement of the first cell with the same independent error. NowThe inferred first-cell pressure has standard deviation and the second . Their errors are negatively correlated because the second pressure is reconstructed by subtracting the first from twice the measured mean.
A rank-one update of pressure-map information follows when an independent new channel has sensitivity row and error variance : its added information is . A channel aligned with a weak pressure direction can therefore be more useful than another precise copy of a strong direction. Correlated new errors cannot be added by that independent-channel formula.
A proposed characterization uses repeatable known loading patterns to estimate , independent repeats to estimate , and withheld patterns to test predicted reconstruction covariance. State the pressure basis and units: rescaling a coefficient changes the numerical information entries. A sharp reconstructed image or a large matrix determinant alone does not establish that the underlying response model or noise assumptions are correct.
A rank-one update of pressure-map information describes the extra constraint supplied by one independent scalar pressure measurement. Suppose the existing pressure-map information matrix is , and a new sensor reports with known variance , independent of the existing errors. Adding its squared residual to the weighted least squares objective givesThe added matrix has rank one when . It is positive semidefinite because its quadratic form is . Thus the new observation cannot reduce information in any direction under this fixed linear map and noise model. The noise normalization is the same whitening transformation used to express a correlated residual metric as an ordinary squared norm.[ref]
The update can remove a missing direction only if the new channel actually sees it. More precisely,This follows because a sum of two nonnegative quadratic forms is zero exactly when both are zero. Repeating an existing mixture improves its precision but cannot identify a pressure contrast that all mixtures annihilate.
When is positive definite, write . The Sherman–Morrison formula yields the updated estimator covariance matrixMultiplication by verifies the identity directly. For a particular quantity , its variance falls by . A small noise level is valuable only together with a useful sensitivity direction.
For an original calculation in kilopascal coordinates, let , and . ThenThe variance of the sum drops from to . The negative off-diagonal entry means the two inferred coefficients now have negatively correlated errors; it does not mean either individual variance is negative.
A correlated-channel update of pressure-map information needs the new channel's residual after predicting it from old channel noise. Simply adding double-counts information when a common amplifier or reference contributes correlated errors. A proposed array experiment uses repeated known loads to estimate sensitivity and noise separately, adds one channel, and compares withheld-load errors with . Agreement tests the full assumed model, including independence and unchanged sensor response, rather than the matrix identity alone.
Unilateral contact permits bodies to separate while preventing them from passing through each other. In an ideal rigid, nonadhesive model, the supporting normal contact force can push but cannot pull. It is therefore different from a permanently attached support: an upward pull may lift a body away instead of producing a downward support reaction.
Let be the signed normal gap, positive when the bodies are separated, and the outward compressive normal contact force. The nonpenetration constraint and absence of adhesion give the unilateral contact complementarity conditionsAn open gap requires , while requires a closed gap. The pair is also allowed: touching does not by itself imply a loaded contact.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Time-stepping LCP: Normal force, nonnegative gap and normal reaction and their complementarity product
Tangential friction requires an additional relation such as Coulomb friction; it is not specified by the normal-gap conditions.The equation of motion is still needed to determine the reaction. Consider a block of mass on a fixed horizontal floor, initially at rest at , with an upward applied force through its center of mass. With upward positive, Newton's second law isIf the contact remains closed, would require . That is feasible for . For , a negative normal reaction would violate unilateral contact, so the contact opens with and . At a closed contact with zero normal velocity, the appropriate acceleration-level contact complementarity iswhich yieldsThese acceleration conditions are being applied at a closed, initially stationary contact; they are not a rule forbidding downward acceleration during separated free flight.
For an original numerical example, let and . Pulling upward with leaves a normal reaction of . At , the reaction is zero and the initial upward acceleration is . At , both the reaction and the initial acceleration vanish, while touching remains possible.
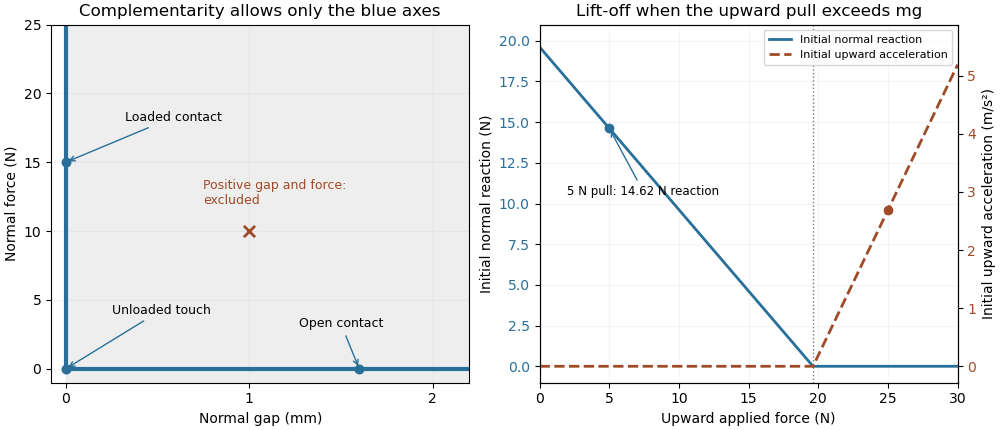
Unilateral contact allows a closed unloaded contact and releases a support when a tensile reaction would be required
. Original ideal-model illustration. The left panel shows allowed gap/reaction pairs; the right shows the initial reaction and acceleration for a stationary 2 kg block as an upward pull is increased. The two panels illustrate geometry and force balance respectively; they are not measured loading data. Details.A simple apparatus test places the block on a calibrated load cell and applies the upward pull through a spring balance, keeping the pull vertical through the center of mass to avoid an extra overturning torque. The support reading should decrease with the pull while contact persists, then vanish at lift-off. Recording the gap as well distinguishes an unloaded touch from a genuinely open contact. Real support elastic deformation and adhesion must be accounted for before treating that apparatus as the ideal rigid, nonadhesive model.
A penalty approximation of unilateral contact replaces perfect rigidity by a chosen stiff response, for exampleHere a small negative gap represents an allowed modeled overlap relative to undeformed reference surfaces. It is not an exact solution of . For the supported load above and chosen penalty stiffness , equilibrium requires . Increasing reduces that overlap at the same load. The penalty method and the ideal constraint are different approximations of the contact response.
Finally, impact requires a rule for the velocity change. The position-level inequalities alone do not decide whether an approaching body sticks or rebounds. A coefficient of restitution or another specified impact law determines that behavior, and the impulsive contact force is summarized by its impulse. Tedrake's particular time-stepping formulation identifies its block collisions as perfectly inelastic; that is a feature of the stated model, not a consequence of the three gap/reaction inequalities alone.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Time-stepping LCP dynamics for block collision, perfectly inelastic collision hint
A penalty approximation of unilateral contact allows a small modeled overlap and uses a stiff restoring force instead of enforcing an exact rigid nonpenetration constraint. With signed gap , positive in separation, a simple nonadhesive law isAn open or just-touching contact has zero force in this spring law; a sustained compressive load requires negative . Thus it approximates unilateral contact rather than satisfying its rigid gap condition exactly. Tedrake's primary compliant-contact treatment uses stiff springs and damping to resist penetration and explains the resulting numerical stiffness.[ref]
For an original gravity-supported example, a mass with no other vertical load has . With , its static overlap is . Increasing by a factor of 100 reduces that overlap to , but also makes the contact dynamics faster.
While the contact stays compressed, linearization about equilibrium givesThe normal contact penalty time scale is therefore proportional to . For the first stiffness above, ; after increasing stiffness it is ten times larger. At fixed numerical step size, a smaller overlap error need not mean a more accurate trajectory.
For example, the Forward Euler method applied to this undamped oscillator has amplification factors , whose magnitudes exceed one for every positive step. Merely shrinking the step does not make that method asymptotically stable for indefinite undamped oscillation, although it can reduce error on a finite interval. A suitable integration method, damping model and convergence check must be chosen. The source notes specifically identify stiff differential equations as a challenge for compliant contact simulation.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Compliant Contact Models, numerical integration discussion
A penalty stiffness is a chosen model parameter, not automatically the actual material stiffness. Impact dissipation and tangential friction still need their own constitutive choices; a purely elastic normal spring does not imply a perfectly inelastic collision.
The normal contact penalty time scale describes the fast dynamics introduced by a stiff normal-contact approximation. For a compressed linear penalty spring with stiffness acting on a point mass , small oscillations about equilibrium satisfy . Their angular frequency, reference time and period areThe reference time is not the full oscillation period. Rescaling time by gives , so a numerical step is controlled by its dimensionless size , not just its duration in seconds. The primary compliant-contact treatment highlights the numerical stiffness caused by such springs.[ref]
A modeling and numerical budget interact. Limiting equilibrium overlap under a specified maximum supported load to requires in this linear model. For an original choice and , choose . At ,A chosen resolution target of twenty steps per contact oscillation would set . This is a resolution target, not a universal accuracy or stability theorem for every integrator.
Increasing the stiffness by a factor of 100 reduces the same-load overlap by 100 but reduces these times by only ten. Keeping the old step then gives roughly two samples per new oscillation instead of twenty. The parent penalty approximation of unilateral contact also shows why the Forward Euler method's undamped-oscillator instability cannot be cured merely by calling the step small.
For a multibody contact, the effective mass in a normal-contact penalty mode replaces an arbitrary total body mass. Additional damping and nonlinear force laws can introduce other time scales. A convergence study should therefore check force histories and contact events as well as maximum overlap; smaller geometric penetration alone does not establish a more accurate simulation.
The effective mass in a normal-contact penalty mode is the inertia seen by one specified relative normal displacement, rather than automatically the total mass of either body. A contact away from a center of mass can excite rotation as well as translation, changing that inertia and the normal contact penalty time scale.
Use independent generalized velocities , a positive-definite mass matrix , and a normal gap whose local velocity is . A scalar normal force produces generalized force . The primary multibody formulation gives this contact-Jacobian velocity/force pairing explicitly.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Contact modeling: contact Jacobian and equation with generalized force J-transpose times lambda
At a frozen configuration, the part of gap acceleration caused by that force isIf the scalar is positive, defineThe definition uses a physical normal gap measured in metres and a matching normal force measured in newtons. Arbitrarily rescaling the gap coordinate changes the associated inertia. Constraints must first be accounted for by independent coordinates or the appropriate constrained response.A short normal impulse gives , hence . This supplies a direct interpretation: less effective mass means a larger relative normal-velocity change for the same impulse. At a fixed local configuration, a compressed linear penalty spring of stiffness gives the small-motion estimateIt omits changing contact geometry, other driving forces and damping; the source separately explains why stiff compliant contact challenges numerical integration.[ref]
For two freely translating particles, the relative gap sees , so . This is the reduced mass. Equal particles give ; replacing one by a fixed wall gives instead.
For a planar rigid body above a fixed plane, let its mass be , rotational moment of inertia about its center be , and the contact normal be vertical. A contact a horizontal distance from the center hasFor , and , . At the center it is . With , the off-center angular frequency is , compared with at the center. Using the full mass in both cases misses this rotational response.
Several simultaneous contacts require more than separate scalar replacements. Their matrix generally has off-diagonal terms: a force at one contact changes another contact’s acceleration. With frozen geometry and positive diagonal stiffness matrix , compressed gap perturbations satisfy ; its nonzero modal squared frequencies are those of the symmetric matrix . Coupled normal-contact penalty modes can therefore be faster than estimates treating each contact independently. A proposed verification applies a small known impulse or displacement perturbation at a stated configuration and checks relative contact motion, followed by a timestep convergence study.
Coupled normal-contact penalty modes are small oscillations generated by several simultaneously compressed penalty contacts acting through shared body inertia. A displacement at one contact can accelerate another because both load the same translating or rotating bodies. Separate scalar effective mass in a normal-contact penalty mode estimates do not generally give the coupled frequencies.
Freeze a contact configuration, use independent generalized displacement perturbations , positive-definite mass matrix , and gap perturbations . Let be a positive diagonal matrix of normal penalty stiffnesses. After subtracting equilibrium loads, the restoring generalized force is , soThe contact-Jacobian force/velocity pairing and stiff compliant-contact model come from the primary multibody formulation; the local modal reduction here follows by substitution.[ref]
Although need not be symmetric, it is similar to the symmetric positive-semidefinite matrix . Set to obtainIts positive eigenvalues are squared angular frequencies. A zero eigenvalue may describe redundant gap coordinates outside the realizable displacement subspace; it should not automatically be interpreted as an extra physical oscillation. Free generalized motions satisfying are a separate possibility.
For an original planar example, a rigid bar has vertical translation , small rotation , mass , center-of-mass moment of inertia , and two vertical contacts at horizontal offsets . ThenWith equal contact stiffness , the equal-gap mode is vertical translation and the opposite-gap mode is rocking. Their angular frequencies areTake , , and . Then has diagonal entries and off-diagonal entries . Its eigenvalues are and , giving and . Treating the contacts independently would assign each and miss the faster rocking mode.
Contact-mode timestep stability depends on the largest active frequency and on the integrator. For the undamped central-difference recurrence, one mode has amplification equationThe distinct oscillatory roots lie on the unit circle for ; the endpoints need separate treatment. The example therefore requires for this linear stability condition. Resolving the waveform accurately normally requires a smaller step. This is not a stability rule for every integration method.
The derivation applies while both contacts remain compressed and geometry is locally constant. A sufficiently large rocking amplitude can unload one contact, changing the active model. A proposed check preloads both supports, applies small symmetric and antisymmetric perturbations, and compares measured or simulated frequencies with the two predictions. Repeat with smaller amplitudes and smaller timesteps to separate linearization error, contact opening and numerical error.
Contact-mode timestep stability concerns whether a numerical integrator introduces growing errors when advancing the fast dynamics of an active penalty contact. It depends on the integration rule and the local modal frequencies, not just the size of the modeled overlap. The primary compliant-contact treatment identifies stiff contact springs as a source of numerically stiff differential equations.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Compliant Contact Models, stiff-spring and numerical integration discussion
Freeze the active contacts and linearize about a compressed equilibrium. An undamped mode has . For step , put . The Forward Euler method updates displacement and velocity with matrixwhose eigenvalues are . Their magnitudes are whenever . Thus the method has no nonzero stable step for indefinite integration of this undamped oscillator, although smaller steps reduce its error on a fixed finite interval.
The central-difference recurrence instead givesFor its two distinct amplification roots lie on the unit circle. At the repeated root is , and solutions can include , so the strict bound matters. A collection of frozen undamped modes therefore requires for this oscillatory stability condition. In coupled normal-contact penalty modes, comes from the coupled system rather than an arbitrary total-mass estimate.
Stability still allows substantial contact-mode numerical phase error. For central differences the phase per step is , giving numerical angular frequency . At and , is stable but the numerical frequency is about , high. A timing-sensitive contact event can consequently drift even when oscillation amplitudes do not grow.
Implicit schemes illustrate another tradeoff. For the Backward Euler method, the amplification factors are and have magnitude . At , each step reduces the oscillatory amplitude by about , despite the continuous undamped system conserving energy. The trapezoidal rule instead has factorswith phase . The same example gives , low. Unconditional stability for this linear model does not imply correct timing at a large step.
A practical error check therefore compares both amplitude and phase while reducing . For instance, a small target dimensionless step gives much smaller phase error than one, but the acceptable value depends on the observable and time span; it is not a universal accuracy certificate.
The frozen-mode argument has a defined scope. Contact opening changes the active stiffness, nonlinear force laws change tangent stiffness, and damping introduces additional eigenvalue scales. An integrator can satisfy the local oscillator bound while missing an intervening collision or contact release. A proposed test starts with a small compressed-contact perturbation, checks frequencies and energy behavior, then repeats across a known contact-opening event with decreasing steps. Record force histories and event times as well as penetration, so numerical damping or phase drift is not mistaken for a material response.
Contact-mode numerical phase error is the difference between the oscillation phase produced by a time integrator and the phase of the modeled contact dynamics. It can grow while the numerical solution remains bounded. Contact-mode timestep stability controls a different property; stable integration alone does not ensure accurate force timing or contact-event timing. The physical motivation is the fast oscillation introduced by a stiff compliant contact model.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Compliant Contact Models, stiff-spring and numerical integration discussion
For a frozen undamped contact mode , central differences givePut and use . On the stable branch ,The numerical frequency exceeds the modeled frequency. A Taylor series givesFor the trapezoidal rule, its amplification-factor phase instead givesThat scheme preserves modal amplitude in this undamped linear setting while lagging in phase. These formulas isolate a single mode with fixed frequency and consistent initialization; general nonlinear contacts require additional analysis.
Accumulated contact-mode phase drift after a duration is at time-grid points. For an original example, let and . With , the central-difference frequency is about , producing of phase lead. The step satisfies the strict stability inequality, yet the phase lead exceeds half a cycle.
Reducing to gives about of lead over the same duration. At it is about , approximately one quarter as large, matching the leading second-order error. For a small desired phase budget , the central-difference expansion suggestsWith , this estimate is about , much smaller than the stability boundary. Check the exact frequency formula when the small-step expansion is not sufficiently accurate.
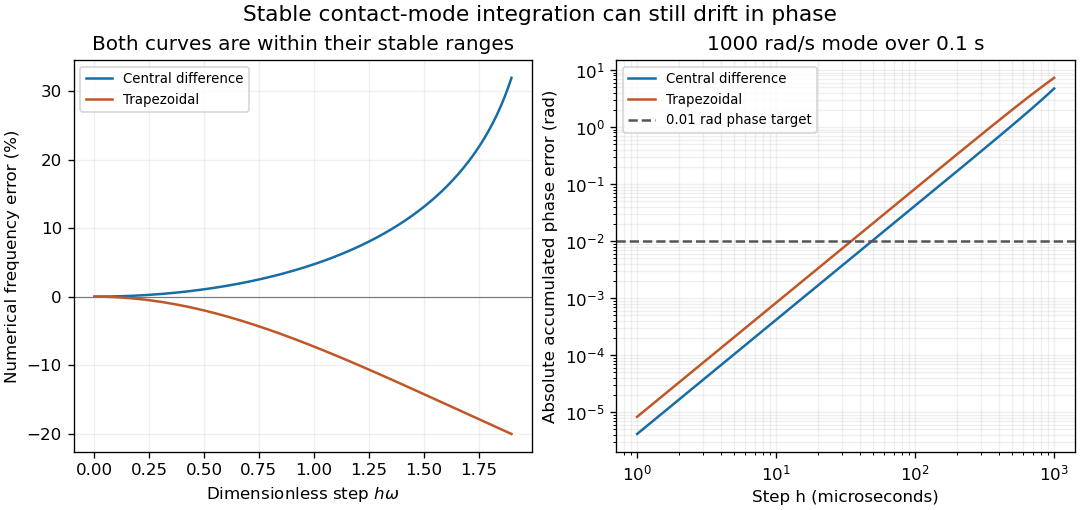
Stable contact-mode timesteps can accumulate substantial numerical phase error
. Exact frequency errors for central differences and the trapezoidal rule, and the resulting absolute phase errors for a fixed 1000 rad/s mode integrated over 0.1 s. The horizontal line is an illustrative 0.01 rad phase budget. These are analytical linear-mode predictions, not contact measurements. Details.In a contact experiment or simulation, a shifted oscillation phase changes when force maxima and gap crossings are predicted. Damping, changing tangent stiffness and a contact opening can invalidate the fixed-frequency model, so the phase estimate is not by itself an event-time error certificate. A proposed convergence check compares force histories, dominant frequency and event times at successively halved steps, while keeping contact geometry and constitutive parameters fixed. Agreement in maximum penetration alone can miss a phase error that accumulates over many cycles.
Accumulated contact-mode phase drift is the phase difference that builds over many timesteps when a numerical contact mode oscillates at a slightly incorrect frequency. A small error per step can matter after many cycles even when the amplitude remains bounded. The fast oscillations arise naturally in stiff compliant-contact models, whose numerical integration difficulty is described in the primary multibody notes.[ref]
For a fixed undamped mode of angular frequency , step , and numerical phase advance per step, after steps the unwrapped phase error isUnwrapped phase counts complete cycles; reducing it modulo would hide a missed or added cycle. This expression assumes the same fixed mode and a uniform step throughout the comparison.
For central differences, on . Expanding givesFor the trapezoidal rule, instead givesBoth are second-order phase errors at fixed duration, but their signs and leading coefficients differ. Halving approximately quarters the accumulated phase error; doubling the simulated duration approximately doubles it when the mode remains unchanged.
For an original example, choose , and , so and . Central differences give and a phase lead about , or . The relative frequency error is only about , yet the phase lead has become readily visible. The leading-order estimate is .
An approximate phase budget for central differences suggestsWith the preceding mode and duration and , it gives . Taking gives an exact phase lead about . This is far below the oscillator stability boundary; contact-mode timestep stability and timing accuracy impose different requirements.
The associated timing shift is approximately for a fixed phase feature of a nearly sinusoidal mode with small drift. It is not a general contact-event error bound: a changing amplitude, a grazing zero, changing tangent stiffness or an active-contact transition can invalidate that approximation. A variable-step method also needs its actual update analysis; summing uniform-step formulas without checking how successive maps compose is not automatically exact.
A proposed convergence test records a small compressed-contact oscillation over a stated duration, compares unwrapped numerical and reference phases, and repeats with half the step and twice the duration. Compare the force waveform and event times as well as the maximum penetration. Material damping changes the physical response, while numerical phase drift changes the timing of that modeled response; they should be tested separately.
For a nonadhesive obstacle, is the signed separation and its outward normal contact force. Nonpenetration gives , absence of adhesion gives , and reaction is possible only at contact, giving . In a small-slope taut-string model, and force balance gives for downward applied load . The three conditions then become , , . Multiplication by admissible displacement differences and integration gives the associated variational inequality, connecting a local contact law to constrained energy minimization.
Acceleration-level contact complementarity decides whether a smooth, closed contact with zero normal velocity must carry a compressive reaction or begin to separate. At and , the normal conditions areThey do not constrain the sign of acceleration at a positive gap, and they do not resolve an impact with negative incoming normal velocity. The distinction between smooth constrained dynamics and time-stepped contact/impact models is explicit in the primary dynamics treatment.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, constrained equations and Time-stepping LCP: Normal force
For a frictionless multibody model with generalized velocity , invertible mass matrix and contact Jacobian defined by , writewhere is the free normal acceleration and . The normal reactions then solve the linear complementarity problemThe matrix couples contacts: choosing each reaction from a separate scalar formula generally fails when it changes acceleration at the other contacts. This formulation assumes the displayed velocity-coordinate kinematics and active closed contacts; additional friction forces modify the dynamics.
For an original coupled example, take free normal acceleration andThe reaction gives zero normal acceleration at both contacts. Ignoring the off-diagonal coupling would instead choose at each; inserted into the full system, that produces of outward acceleration at both loaded contacts and violates complementarity. Positive reaction and positive separating acceleration cannot coexist in this smooth active-contact model.
Because these are acceleration-level conditions, a numerical trajectory can still accumulate position or velocity drift. They must be paired with an integration/contact-update procedure that maintains the assumed state. During separated free flight, a negative acceleration can be perfectly admissible until the next contact event. At impact, an impulse and an appropriate velocity-level law are needed instead of applying the smooth equations across a discontinuity.
For a body lying above an obstacle with height , its normal displacement graph must obey the displayed inequality. Equality allows contact and strict inequality means separation. This is a unilateral mechanical constraint: motion away from the obstacle is allowed, but motion through it is forbidden. In nonadhesive frictionless contact the associated normal contact force can push the body outwards but cannot pull it into the obstacle.
An elastic beam above a smooth obstacle cannot penetrate it, and a nonadhesive obstacle can only push. The displayed constraints express this when is an upward distributed normal contact force; concentrated point forces must also be nonnegative. In the small-slope Euler-Bernoulli beam equation,Integrating across a contact point with no applied couple gives jump conditions and , provided the tension is continuous. For a flat obstacle, no distributed load and zero tension, an open contact interval has ; its entire normal contact force can therefore be concentrated at its endpoints.
The reduced elastic modulus combines the elastic compliance of two contacting isotropic bodies:Here is each body's Young's modulus and its Poisson's ratio. Both bodies deform under the same contact load, so their contributions to the indentation add. The factors involving Poisson's ratio account for the lateral constraint inherent in the local contact geometry.[ref]
CompuTiX Hertz contact documentation. Hertz theory, Resulting force: effective modulus of the two bodies
For identical materials, ; against an effectively rigid probe, for the specimen. Thus even with a rigid probe, an indentation fit does not directly return Young's modulus. This matters when comparing Hertzian contact measurements with tensile testing, which imposes a different pattern of stress.
Hertzian contact is the small-contact solution for smooth bodies obeying linear elasticity, with friction and adhesion neglected. For a sphere of radius pressed into a flat surface by indentation , the contact radius and compressive normal contact force satisfyThe reduced elastic modulus includes both bodies. The contact pressure is largest at the centre and falls to zero at the edge:These formulas describe an ideal contact patch, rather than a uniformly loaded disk.[ref]
The increasing contact area explains the nonlinear load law even though the material itself obeys linear elasticity. In a probe experiment, should be proportional to in the Hertzian regime. Systematic departures can signal adhesion, plastic deformation, a thin specimen or a contact patch too large for the assumed local geometry.
A dimensionless measure comparing adhesive interaction range with elastic deformation in sphere contact. Small values favour the DMT contact approximation, while large values favour the JKR limit.
An adhesive sphere-on-flat contact approximation combining Hertzian contact deformation with an attractive force outside the contact area. It is most appropriate for sufficiently stiff, small-radius contacts with a small Tabor parameter; a fitted reduced modulus is not automatically the sample Young's modulus.
Adhesion is attraction between different surfaces that can keep them attached after a compressive contact load is removed. It can arise from intermolecular forces or other interfacial interactions; a liquid bridge can also contribute a capillary force. The work needed to reversibly separate a unit area is an interfacial energy, whereas the measured pull-off force depends additionally on geometry and elastic deformation.
Pressing a spherical probe onto a specimen and then retracting it provides a direct test. Contact may persist while the apparatus reads a tensile force; detachment occurs only when that adhesive contact becomes unstable. Hertzian contact cannot describe this tensile branch because it neglects adhesion. Surface contamination, roughness and humidity can change a measurement even when the bulk Young's modulus stays fixed. This makes preparation of the interface as important as calibration of the force probe when comparing adhesive response.
Unwanted sticking that prevents intended relative motion. In surface micromachining, a receding liquid meniscus can pull a compliant released beam onto the substrate; adhesion can then keep it there. Avoiding a liquid-vapor drying interface addresses one route to stiction, but does not remove contact adhesion during use.
The tensile force magnitude needed to detach contacting surfaces during retraction. A force-probe measurement reads it from the force minimum relative to the noncontact baseline; roughness, capillary forces and contact geometry affect its interpretation.
The normal contact force is the component of a contact force perpendicular to the local contact surface. If is the outward unit normal vector, a nonadhesive support exerts with ; the remaining tangential component is associated with friction. Over an extended patch, the resultant follows by integrating the local contact pressure and allowing for changes in normal vector.
For a block at rest on a horizontal table with no other vertical loads, Newton's second law gives . On a stationary incline it gives , while in an accelerating lift changes with the lift's acceleration. Thus the normal contact force is a response required by the mechanical constraint, not an independently fixed multiple of mass. If maintaining contact would require a negative in a nonadhesive model, the bodies separate.
solid stress is stress carried by solid constituents of a tissue or material. Compressive solid stress, interstitial fluid pressure and elastic stiffness are distinct quantities that can coexist in a tumour.
The continuum approximation describes a material using fields such as mass density, velocity field and stress, rather than following its individual molecules. Its averaging volumes must contain enough microscopic constituents to define bulk properties while remaining small relative to the distances over which those properties change appreciably. It supplies the model underlying much of fluid mechanics and elasticity.
Anisotropy means that a physical property depends on direction. A strip cut along the fibres of a long-fibre composite can resist stretching much more strongly than a strip cut across them. The directional difference can come from the crystal structure of a constituent or from the arrangement of otherwise isotropic constituents.
For thermal conduction, a thermal conductivity tensor relates the temperature gradient to the heat flux. Along its principal directions the conductivities can differ, and in a general direction the heat flux need not be parallel to the negative temperature gradient. Anisotropic elasticity similarly requires a tensor-valued constitutive equation rather than a single Young's modulus. Measuring a specimen in several orientations therefore reveals information that one axial measurement cannot; averaging over randomly oriented constituents can reduce macroscopic anisotropy, but the result depends on the actual orientation distribution.
Isotropy is invariance under rotations, so no spatial direction is preferred. For a three-dimensional second-rank conductivity tensor, invariance under every rotation forces . Isotropy of each constituent does not imply isotropy of an arranged composite microstructure. Statistical isotropy concerns the rotational invariance of its probability law.
A composite material contains distinguishable constituent phases whose arrangement contributes to the bulk properties. In a fibre-reinforced example, strong fibres carry much of the axial load while a composite matrix holds them together and transmits shear stress between them. Carbon-fibre-reinforced polymer combines carbon fibres with a polymer composite matrix; glass fibres provide another reinforcement.
The constituent proportions alone do not determine the result. Aligned fibres produce anisotropy, whereas changing their orientations changes which directions are reinforced.[ref]
Fibre reinforced composites (UNSW tutorial). Continuous and discontinuous fibres; strength along aligned fibres and weaker response in other directions
In an ideal long-fibre composite, the longitudinal rule of mixtures estimates the axial Young's modulus. A comparison of tensile testing along and across the fibres exposes the importance of geometry and fibre-matrix load transfer. The same idea of combining phase properties with geometry appears in effective conductivity, although the relevant constitutive equations differ.The isostress rule of mixtures estimates a composite material’s Young's modulus by assuming that its constituent phases carry the same axial stress. For two phases with positive Young's moduli and volume fractions , the effective modulus is their weighted harmonic mean:This is the one-dimensional equal-stress specialization of the Reuss elastic approximation, rather than the equal-strain assumption of the longitudinal rule of mixtures.[ref]
Mechanics of Composite Materials by Bill Clyne and Boban Tanovic. Load Transfer, What about the Transverse Stiffness?, Figure 2
To derive it, put two ideal elastic segments in series, with the same sectional area , lengths , and a common axial force . Force balance gives in each segment. Under one-dimensional linear elasticity, . Since the extensions add,Equal sectional areas make the length fraction equal to the volume fraction . Dividing by the common stress proves the formula.
For an illustrative pair , and ,At , the segment strains are and , so the mean strain is . The softer phase supplies most of the extension despite occupying only one fifth of the volume. Placing the same proportions in ideal parallel load paths with equal strain instead gives . Geometry has changed the result substantially.
The series derivation is exact within its one-dimensional model, with bonded segments and no bending or additional transverse constraints. It is not an exact prediction for every real fibre-reinforced composite material loaded across its fibres: stress and strain vary around the actual reinforcement geometry. The primary teaching resource explicitly distinguishes the equal-stress slab estimate from the more complicated transverse response.[ref]
Mechanics of Composite Materials by Bill Clyne and Boban Tanovic. What about the Transverse Stiffness?, limitations of the slab model
The composite matrix in a composite material is its continuous surrounding phase, distinguished from embedded fibres or particles. It holds the reinforcement together and transfers load through interfacial stresses; it can also protect the reinforcement from damage or the environment.
For a fibre-reinforced polymer, the polymer is the composite matrix even if the fibres carry much of the axial load. Matrix stiffness, interfacial adhesion and failure therefore affect the whole specimen. This materials meaning differs from a rectangular array of numbers in linear algebra.
A carbon fibre is a slender reinforcement made predominantly of carbon, used to carry tension along its length. Its axial Young's modulus, tensile strength and mass density are especially useful when comparing how much elastic load a lightweight component can carry. A fibre's measured tensile strength also depends on defects and the length tested, so one strength value does not characterize every specimen.
Embedding carbon fibres in a polymer produces carbon-fibre-reinforced polymer. The composite matrix supports the fibre arrangement and permits fibre-matrix load transfer; the axial performance of an aligned assembly does not imply equal transverse performance. Tensile testing of single fibres measures the reinforcement response, while testing composite strips at different orientations measures how that response survives assembly into a composite material.
A glass fibre is a thin strand of glass used as a reinforcement. When embedded in a composite matrix, many glass fibres can carry axial tension while the surrounding material maintains their positions and transfers load between them. The reinforcement is effective only if the interface transmits the required shear stress; an unbonded fibre can slide without carrying the expected load.
Continuous aligned glass fibres reinforce one direction strongly, whereas short fibres with varied orientations distribute reinforcement over more directions.[ref]
Fibre reinforced composites (UNSW tutorial). Classification into continuous aligned, discontinuous random and discontinuous aligned reinforcement
Even if the glass itself is approximately isotropic, a composite material containing aligned glass fibres is generally anisotropic. Comparing specimens with equal fibre volume fraction but different orientations separates the effects of constituent quantity and arrangement.A long-fibre composite contains reinforcing fibres whose lengths are large enough that end regions do not dominate their load-carrying response. In a well-bonded continuous aligned specimen pulled along the fibres, the fibres and composite matrix undergo approximately the same axial strain. Their different Young's moduli then produce different axial stresses, and adding their forces gives the longitudinal rule of mixtures.
Load enters a fibre through shear stress at its interface with the composite matrix. Near a free fibre end the axial stress must rise from zero, so a short fibre can spend much of its length below its useful load. The critical fibre length expresses the associated scale in a simple strength-transfer model. Whether a fibre is mechanically long therefore depends on its diameter, the interface and the required stress, rather than on an absolute length in millimetres. Changing fibre direction still changes the response: long reinforcement does not remove anisotropy.
Fibre-matrix load transfer describes how interfacial shear stress transfers axial force between a reinforcing fibre and its surrounding composite matrix. For a cylindrical fibre of diameter , axial force balance gives when is the appropriately signed interfacial shear stress.
The fibre stress is therefore small near a free end and builds over a transfer length. Short fibres may never reach their tensile strength before the interface slips or the matrix yields. The critical fibre length quantifies this competition in a simplified constant-shear model.
The critical fibre length is the minimum embedded fibre length needed to develop a specified tensile stress in a simple interfacial-load-transfer model. For diameter , fibre strength and constant limiting interfacial shear stress ,Each half of the fibre builds axial force from its end through interfacial shear; balancing that transferred force against the strength load gives the formula. It is a model-dependent criterion, not a universal length of the material. Nonuniform shear, imperfect bonding and fibre orientation modify actual composite behavior.
The fibre volume fraction is the fraction of a composite material's total volume occupied by reinforcing fibres:For a specimen with only fibres and a composite matrix, their fractions sum to one. Voids require a third fraction; they must not be silently counted as composite matrix. The fibre volume fraction is different from the fibre mass fraction because the constituents can have different mass densities.
For a void-free material, a measured fibre mass fraction giveswhere and are the constituent mass densities. For example, masses in the ratio and mass densities in the ratio give , not . Inserting into the longitudinal rule of mixtures estimates axial Young's modulus; orientation and fibre-matrix load transfer remain separate requirements.
A hybrid fibre composite contains two or more types of reinforcing fibre in a common composite matrix. Combining carbon fibres and glass fibres, for example, provides another design choice besides changing the amount or orientation of a single reinforcement. The word hybrid specifies the combination of reinforcements, not a guarantee that every mechanical property improves.
For continuous, parallel fibres, perfect bonding and elastic axial loading, equal strain gives the extension of the longitudinal rule of mixturesHere the are constituent fractions by volume and the are axial Young's moduli. This estimate describes the initial elastic response. It does not by itself predict tensile strength: when one fibre population breaks, its load is redistributed through the composite matrix, changing the stress carried by the surviving population.
The longitudinal rule of mixtures estimates the axial Young's modulus of continuous aligned fibres in a composite matrix:The model assumes perfect bonding, small elastic strain, no voids and loading parallel to the fibres. Equal extension over a common initial length gives equal axial strain in both phases. Adding their forces gives the average axial stress , which proves the formula. It is the axial Voigt elastic approximation.
For example, , and give . These are illustrative inputs, not universal constituent values. The formula makes reinforcement efficient because the stiffer constituent carries the larger stress at the common strain. Loading across the fibres changes the compatibility and traction conditions, so the same formula is not a general transverse-modulus law. Fibre waviness or poor fibre-matrix load transfer can also invalidate the ideal axial estimate.
Carbon-fibre-reinforced polymer is a composite material in which carbon fibres reinforce a polymer composite matrix. The fibres carry axial tension efficiently, while the composite matrix maintains their arrangement and transfers load through interfacial shear stress. A component's response therefore depends on fibre direction, fibre volume fraction and bonding as well as the constituent properties.
For continuous aligned reinforcement, the longitudinal rule of mixtures predicts the initial axial Young's modulus. A stack with fibres in several directions trades some axial performance for reinforcement in those directions. Such an arrangement can reduce in-plane anisotropy, but does not automatically make the through-thickness response identical. Comparing tensile testing along the fibres, across them and through the assembled layers reveals different possible failure mechanisms, including fibre fracture and loss of fibre-matrix load transfer.
An elastic laminate has planar perfectly bonded layers with a common normal. Its piecewise constant strains differ by , while its normal traction is common to every layer. For positive elastic stiffness tensors, these conditions and the mean strain uniquely determine the layer strains: the difference of two solutions has zero mean and zero total elastic work, and positivity forces it to vanish.
The effective elastic energy is the minimum averaged strain energy density under prescribed affine boundary displacement. For differentiable stable elastic response without body force, varying the prescribed mean strain gives . The result follows by integration by parts, because the interior variation with zero boundary data does no work against an equilibrated stress tensor.
Take a positive comparison elastic stiffness tensor , excess energies , and a phasewise constant elastic polarization. The lower conjugate inequality majorizes the local energy by a quadratic-plus-linear function. Minimizing that function over compatible strains gives the displayed bound, where . Stationarity in gives , with . Without this stationarity, dual strains must not be identified with the comparison solution's phase means.
The Reuss elastic approximation assumes uniform stress. The local strain is the derivative of the convex conjugate ; its mean is . Under invertible differentiable duality, this mean determines . For positive linear elasticity, . Uniform stress is generally not accompanied by a compatible local displacement field, so this approximation is distinguished from an exact heterogeneous solution.
The Voigt elastic approximation assumes uniform strain. Differentiating its averaged strain energy density gives the averaged local stress. For linear elasticity the predicted elastic stiffness tensor is . The uniform strain is an admissible affine displacement trial field, so this gives an upper elastic energy bound for convex local energy.
For symmetric stress in static elastic equilibrium without body force, write and . The difference between microscopic and macroscopic work is . It vanishes for affine boundary displacement, uniform boundary traction, or matching periodic displacement fluctuations and opposite tractions on paired faces.
The volume fraction of a constituent is its occupied volume divided by total sample volume. Fractions sum to one for a partition into phases. In a statistically homogeneous medium the phase fraction also equals the probability that a typical point lies in that phase, under the appropriate spatial or ensemble averaging assumptions.
The indicator correlation gives the probability of specified phases at two points. Statistical homogeneity makes it depend on separation; isotropy makes it depend only on its length. In particular , so the connected correlation at zero separation is .
Effective conductivity describes the averaged response of a microscopic conductivity field to a macroscopic temperature or electric-potential gradient. Here the positive conductivity flux is ; physical heat flux has the opposite sign. For periodic media it is computed by cell correctors, and can be a tensor even for isotropic constituents.
A self-consistent conductivity approximation sets the homogeneous comparison effective conductivity equal to the predicted response. For a uniformly oriented two-dimensional polycrystal with principal conductivities , the comparison formula gives , so its positive solution is . This is an approximation defined by a fixed-point closure; exactness requires additional geometric or statistical hypotheses.
For a scalar reference , choose a trial polarization and solve with zero Dirichlet data. The trial functional isA reference above all phase conductivities gives ; one below all of them gives . If the reference equals a phase conductivity, admissible polarization vanishes in that phase and the inverse is taken only on the contrast subspace.
For uniformly distributed rotations of a two-dimensional conductivity tensor with positive principal values , the Hashin-Shtrikman conductivity variational principle with isotropic comparison yields . Averaging a rotated diagonal tensor replaces it by half its trace times the identity. Since , the admissible comparison endpoints give within the statistically isotropic polycrystal model.
These are the optimal volume-fraction bounds for three-dimensional statistically isotropic two-phase conductivity with . Constant phase polarization trial fields reduce the variational principle to a scalar quadratic optimization. The upper trial functional is minimized; the lower one is maximized.
An affine trial temperature in the minimum-energy principle gives the upper tensor bound by the volume-averaged local conductivity. For an isotropic two-phase composite, . The same uniform-field variational idea supplies the familiar corresponding elastic upper bound.
For isotropic phases with planar interfaces normal to , normal conductivity is the weighted harmonic mean and tangential conductivity is the weighted arithmetic mean . Continuity of normal flux and tangential temperature gradient gives the two averages directly.
Conductivity homogenization replaces rapidly varying positive coefficients in a divergence-form elliptic equation by a macroscopic effective conductivity. Periodic media admit cell problems; statistically homogeneous media can instead be described by ensemble averages. The small-scale assumptions and boundary regime must be specified.
For with positive one-periodic fast coefficient, a periodic two-scale expansion has leading term independent of the fast variable. The first corrector satisfies . Its zero-mean derivative requires . Averaging the next equation gives . Thus the leading equation has the local harmonic-mean transport coefficient and the arithmetic-mean source. Positivity is what makes the secular drift incompatible with periodicity.
Relative to a uniform reference conductivity , this polarization is the excess positive conductivity flux. The equation becomes . For a prescribed mean gradient , averaging gives . This sign convention differs from the physical heat-flux sign.
The exciting field excludes an inclusion's own singular dipole field. Other inclusions and periodic images supply the regular correction at its centre . The angular mean of a self-dipole gradient on a concentric sphere vanishes, while the mean-value property recovers the regular field at the centre. Consequently a spherical average can recover the exciting field, even though the total pointwise field is not constant on that sphere.
A sphere of conductivity in a host under a uniform incident gradient has interior gradient . Outside a sphere of radius , its potential correction is . Its polarization is inside and zero outside. Temperature and normal-flux continuity determine these coefficients.
Well-separated shrinking spheres respond independently at leading order, so their polarization contributions add according to volume fraction. Clusters kept at fixed relative internal separation can have a different leading response; the dilute limit alone does not guarantee independent-sphere polarizability.
Matching the far dipole of a spherical composite with the sum of isolated spherical-inclusion dipoles gives this approximation. Its dilute expansion is . The rational expression is a useful closure, not the exact conductivity of every spherical-inclusion microstructure.
If the first exciting-field correction at inclusion is , its revised polarization is . Averaging weights it by and gives the displayed second-reflection approximation. Further dipole reflections and finite-size multipoles are neglected.
The periodic zero-mean corrector adjusts a unit imposed gradient so microscopic flux is divergence-free. For bounded uniformly elliptic coefficients, the weak problem has a unique solution modulo constants. The averaged flux is . For symmetric coefficients this also gives a symmetric positive-definite effective tensor.
A periodic expansion with separates the macroscopic variable from the cell variable. Its leading cell equation forces to be independent of , the next equation gives , and averaging the order-one flux equation yields the homogenized divergence equation. Bulk correctors generally require boundary-layer adjustments at a physical Dirichlet boundary.
A bulk cell expansion generally leaves an oscillatory Dirichlet mismatch. A boundary corrector can solve the homogeneous oscillatory conductivity equation with boundary data cancelling that mismatch. It restores the prescribed physical boundary trace while leaving the leading bulk cell formula unchanged. Estimates depend on boundary regularity and on the coefficient assumptions.
Plasticity in continuum mechanics models permanent deformation after loading passes a material's yield criterion. It supplements the balances of continuum mechanics with an evolution law for plastic strain, and often with internal variables representing work hardening. This separates the recoverable elastic response from changes that remain after unloading.
In one-dimensional small-strain loading, . Unloading without further plastic deformation follows slope , the Young's modulus, and leaves residual strain when returns to zero. A tensile testing experiment with repeated unloading makes this distinction visible. A yield surface generalizes the threshold to multiaxial stress; a flow rule determines the direction of further plastic strain. The threshold and flow rule are separate ingredients, so a yield criterion alone cannot predict a component's permanent shape.
A yield criterion specifies the admissible elastic stress region, possibly depending on internal hardening variables . Plastic loading occurs on its boundary. The Tresca yield criterion uses maximum principal-stress difference, while the Von Mises yield criterion uses a quadratic deviatoric-stress invariant. Thus a numerical stress difference must be compared to a yield stress using the convention of the selected criterion.
In small-strain elastoplasticity, total infinitesimal strain tensor splits into an elastic part and a generally irreversible plastic part. The elastic constitutive equation determines stress from , while a yield condition and a plastic flow law determine the evolution of . Removing external load need not remove plastic strain, so using Hooke's law on total strain after yielding is insufficient.
A plastic flow rule prescribes the direction and rate of plastic straining once a yield condition is active. In a plastic-potential model its direction is the stress gradient of , multiplied by a nonnegative plastic multiplier. An associated flow rule takes equal to the yield function. The stress-strain split, loading conditions and hardening evolution are needed along with this equation to close an elastoplastic model.
Reduction of an applied load with purely elastic strain increments while accumulated plastic strain is fixed. The superposition principle applies to the increment, so the current stress equals the previous stress plus the linear elasticity response to the load change. The resulting stress must still satisfy the yield surface constraint; reverse yielding ends the purely elastic stage.
Renewed plastic deformation during unloading or reversed loading when the stress reaches the opposite part of the yield surface. For the spherical elastoplastic cavity with maximum pressure , elastic unloading first reaches the opposite Tresca yield criterion at the cavity wall after a pressure decrease . Purely elastic return to zero pressure is possible when , with equality reaching the yield surface exactly at the endpoint.
The Tresca yield criterion bounds the largest resolved shear stress, expressed through the principal stresses. In spherical symmetry, the two tangential principal stresses coincide, so . Here is a shear yield stress; the corresponding uniaxial yield strength is .
Necking is localization of tensile deformation into a narrowing part of a specimen. A thinner cross-section carries greater local stress at the same axial force, encouraging further thinning. Work hardening opposes this feedback by increasing the stress required for additional plastic deformation.
For a uniformly extending specimen whose plastic flow approximately conserves volume, write with logarithmic length change . Its load is , where is axial Cauchy stress tensor. ThenThe maximum-load condition is . This ideal estimate assumes uniform uniaxial deformation up to onset and neglects rate effects and damage. In tensile testing, recording both axial force and local specimen diameter distinguishes the start of localization from the later fracture; the maximum engineering stress need not be the maximum local Cauchy stress tensor.
Cold working is permanent shaping by plastic deformation at a temperature low enough that substantial concurrent recrystallization does not erase the deformed microstructure. The relevant comparison is with the material's thermal response, rather than with a universal room-temperature boundary. Drawing wire and rolling sheet are examples of imposing large controlled shape changes.
In a crystalline metal, cold working changes the dislocation population and can create preferred crystal orientations. Dislocation interactions can increase resistance to further deformation through work hardening, while uneven deformation can leave residual stress. A practical comparison measures the stress-strain curve before and after a fixed amount of shaping, then unloads to identify the permanent strain. Subsequent heating can modify the stored microstructure through recovery or recrystallization, so processing history is part of specifying a specimen rather than a detail recoverable from its chemical composition alone.
Work hardening is an increase in resistance to further plastic deformation caused by earlier deformation. A useful macroscopic test loads a metal beyond yield, unloads it and reloads in the same direction: further plastic flow then requires a larger stress. In a constitutive equation, this history is represented by evolving internal variables rather than by the current elastic strain alone.[ref]
Applied Mechanics of Solids by A. F. Bower. §3.7.5, reloading experiment and evolution of the yield surface
In a crystal, multiplication and interaction of dislocations can make later dislocation glide more difficult. Forest hardening and latent hardening describe particular aspects of that obstacle formation. Increased resistance to plastic flow is not the same as a large change in Young's modulus: the elastic unloading slope and the load required to restart permanent deformation measure different properties. Work hardening can delay necking by compensating for the shrinking loaded area.
Latent hardening is increased resistance on one crystal slip system caused by plastic slip on another slip system. The word latent emphasizes that the affected system need not have been active during the earlier loading. It is therefore a statement about interactions between deformation mechanisms, rather than simply about the total amount of deformation.
A simple crystal-plasticity model writes , where is the critical resolved shear stress for system and is slip on system . Off-diagonal coefficients represent cross-system hardening, while diagonal coefficients describe self-hardening.[ref] Changing loading direction after predeformation can activate previously less-favoured slip systems and reveal this history dependence. Predicting the next system to move therefore requires both resolved stress geometry and the evolving resistances.
Forest hardening is resistance to dislocation glide caused by dislocations that cut across a glide plane. An advancing dislocation must negotiate their intersections, form or break junctions, or bow between obstacles. The resulting obstacle network is called a forest because it obstructs motion across the plane, even though it is made of line defects rather than solid inclusions.
The mechanism connects dislocation density with work hardening: a shorter spacing between effective obstacles generally demands greater applied shear stress. It also explains why different slip systems need not evolve independently; slip on one system changes the obstacles encountered by another, contributing to latent hardening. Comparing a specimen before and after controlled plastic deformation tests the increase in flow resistance, while microstructural observation tests whether an assumed obstacle mechanism is plausible. Not every change of yield stress is forest hardening; other microstructural changes can also strengthen a material.
A yield point marks the onset of permanent deformation according to a stated experimental criterion. In a tensile testing experiment, low loads can produce recoverable extension, while higher loads leave a residual extension after unloading. A sharp transition may be visible in the stress-strain curve, but many specimens change gradually from mainly elastic to increasingly plastic response.
When no unambiguous sharp point exists, an offset proof stress gives an operational definition: draw a line parallel to the initial elastic slope and displaced by a specified engineering strain, then identify its intersection with the loading curve. The chosen offset must be reported. The yield point is distinct from both the limit of exact proportionality and the tensile strength at maximum load. This matters because a small measurable departure from linear response does not by itself establish a particular amount of permanent plastic strain.
An offset proof stress is defined by the intersection of a loading curve with a line parallel to its initial linear elasticity response but shifted by a specified engineering strain. A 0.2 percent convention uses the line , with Young's modulus .
The Von Mises yield criterion depends only on the second invariant of deviatoric stress. With shear yield stress , its surface is ; the uniaxial yield stress is . An associated flow rule gives plastic strain rate proportional to , up to a positive normalization of the plastic multiplier.
Plastic strain rate is normal to the yield surface in the work-conjugate stress variables. With symmetric stress variations, the pairing is ; in two dimensions its off-diagonal contribution is . This factor is essential when changing to reduced stress coordinates.
Perfect plasticity idealizes a material whose yield surface does not evolve as plastic deformation accumulates. In one-dimensional elastic-perfectly plastic loading, while ; continued plastic extension can occur at the fixed yield stress . Unloading can still be elastic, so perfect plasticity does not mean that the elastic response is absent.
This model isolates permanent flow from work hardening and is useful in limiting-load calculations. A rigid-perfectly plastic model makes the additional approximation of neglecting elastic strain, as in classical slip-line field theory. A real specimen may harden, soften, damage or show rate dependence, so the constant threshold is an idealization rather than a universal property of metals. It is also a local material law: decreasing cross-sectional area can change the measured axial force even when the local flow stress is constant.
A spherical cavity of fixed reference radius in an infinite solid with perfect plasticity, the Tresca yield criterion, and zero far-field stress first yields under internal pressure . In the plastic region , radial force balance and give . Matching to the outer linear elasticity solution, where , gives the displayed plastic-front radius. These are small-strain reference-geometry formulae.
In antiplane perfect plasticity, velocity and shear stresses depend only on . Force balance is , the fixed yield surface is , and the associated flow rule is with . Differentiating the yield equation in each coordinate and combining it with equilibrium shows that are constant along characteristic curves tangent to . For example . Nonzero regular yield gradient is needed for a characteristic direction.
Articles were limited to the first 100 out of 593 total.
Articles by others on the same topic

Continuum mechanics is a branch of mechanics that deals with the behavior of materials modeled as continuous mass rather than as discrete particles. It provides a framework for understanding how materials deform and respond to forces when they are subjected to stress, temperature changes, or other influences.



