None of the three variants is an optimal search algorithm in general. The following single search tree supplies counterexamples for all three. Its heuristic function is nonnegative, admissible and even a consistent heuristic.
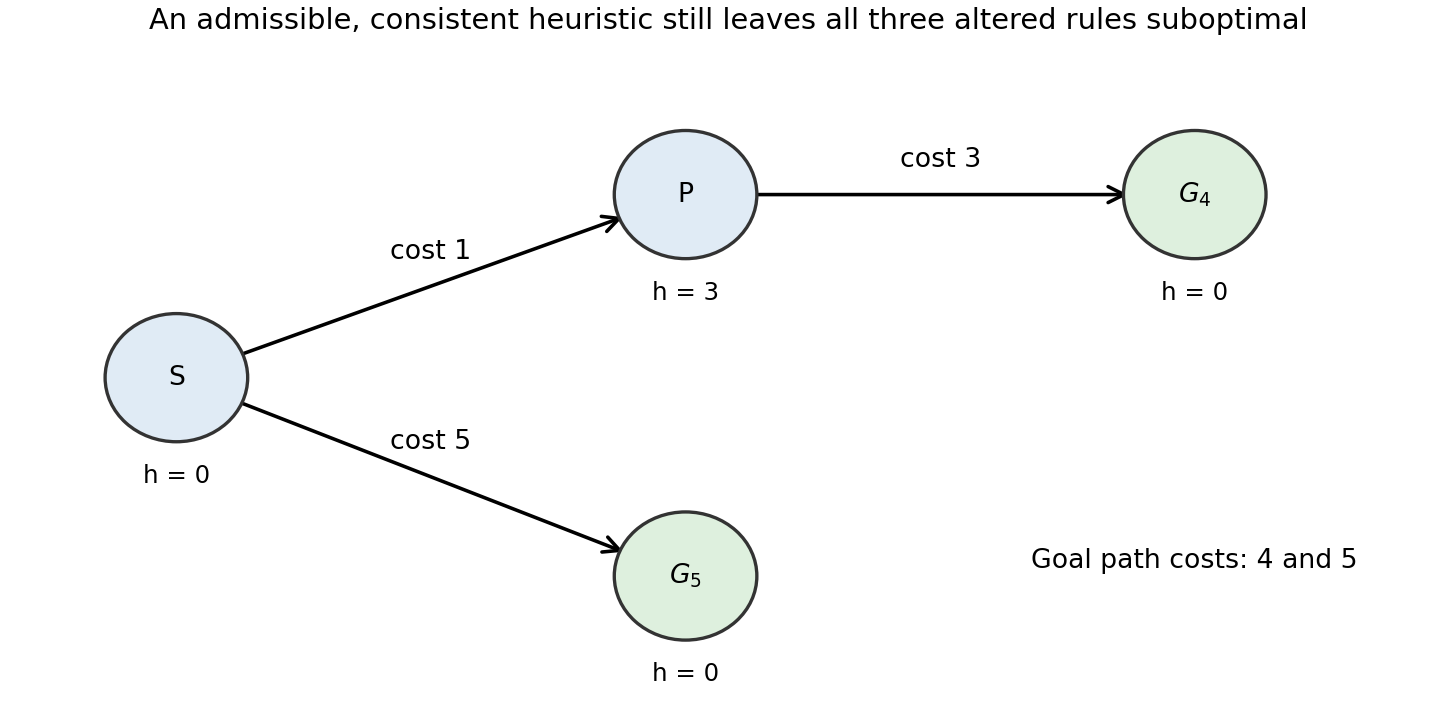

The least-cost goal is , reached at cost ; the other goal costs . Assign , , and zero to both goals. For the first variant, expanding generates and immediately returns it, before can be expanded. A goal test at generation therefore returns cost .
For priority , the root's children have priorities for and for . Expanding generates with priority . The algorithm next selects , again returning cost .
For priority , the root's children instead have priorities for and for . The suboptimal goal is selected immediately. The example uses no tie-breaking assumption. In contrast, ordinary A-star search with its goal test on selection compares the genuine estimated total costs and returns .
Articles by others on the same topic
There are currently no matching articles.