Delay stability of proportional integrator control
ID: delay-stability-of-proportional-integrator-control

For the constant-coefficient model with and , the zero equilibrium point is asymptotically stable if and only if . For positive , perturbations are measured by the supremum norm of the initial history of delayed feedback; in the stable regime, every continuous history produces a solution tending to zero. At equality, nondecaying sinusoids prevent asymptotic stability. For , growing oscillatory solutions exist. These statements concern this ideal linear time-invariant system, rather than an arbitrary controlled plant. The corresponding linear equation and its threshold are developed in Cain and Reynolds, section 6.4, pages 174–177.
Substitute the exponential function , allowing a complex number . The characteristic equation isFor positive feedback delay this is not a characteristic polynomial: it has infinitely many roots. A root's real part determines growth or decay of its exponential mode, and its imaginary part determines the angular frequency. To find the first boundary, set with and use Euler's formula:The smallest positive crossing is and . Thus at the complex conjugate roots are . In fact, with the matching initial history of delayed feedback,solves the delay differential equation exactly: a quarter-cycle feedback delay turns the past displacement into precisely the current derivative. Its cycle lasts . The amplitude is arbitrary; this linear model does not select a finite-amplitude oscillation.
The roots cross toward growth as feedback delay increases. Differentiating the characteristic equation at fixed givesThis calculation identifies the direction of the first destabilization. The full threshold also requires ruling out earlier unstable roots: if with and , the characteristic equation implies and , hence . A real nonnegative root is impossible because there. This supplies the geometric reason the threshold is a quarter-cycle rather than an arbitrary fitting constant.
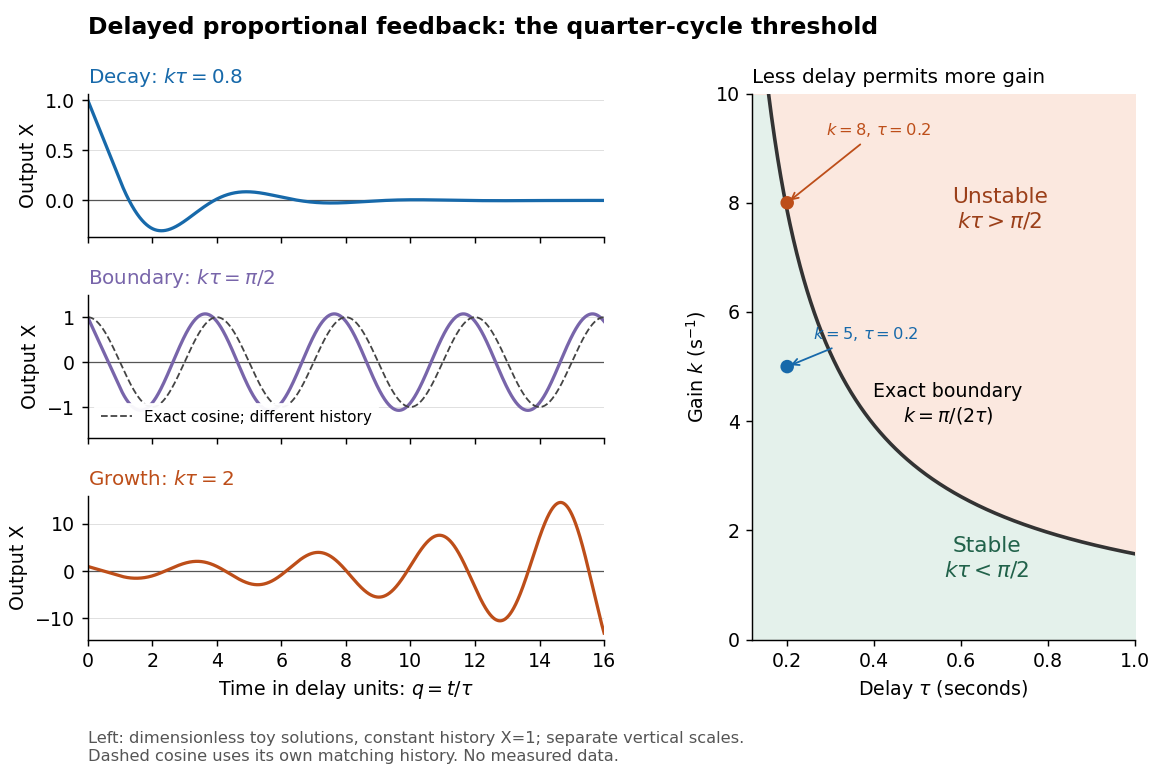
Feedback delay separates decay, persistent oscillation, and growth
. Left: numerical solutions with the same constant initial history of delayed feedback on , plotted against for , , and . The middle trajectory includes a transient because this history is not a pure sinusoid; the dashed curve is a separate exact solution with history . Each row has its own vertical scale. Right: the exact boundary for positive feedback gain and feedback delay. Toy responses are not measured data. The generator uses the classical fourth-order Runge-Kutta method with linear interpolation of delayed values and , checked against a separately evaluated exact finite sum and two coarser steps. Details.
The tradeoff is concrete. Without feedback delay, increasing shortens the exponential decay time constant . With known , the same proportional control must satisfy . For , the threshold is : is stable and is unstable. A design close to the boundary leaves little room for additional feedback delay; reducing or reducing measurement latency increases that room. The zero-delay time constant is only a comparison scale, not the decay time of the delayed response. Frank discusses the gain–delay compromise in Control Theory Tutorial, section 13.4 and figure 13.3.
New to topics? Read the docs here!