A linear time-invariant system combines two properties. Linearity means that the output from a linear combination of inputs is the same linear combination of their outputs. Time invariance means that shifting an input by an integer delay shifts its output by exactly that delay. The operation has no preference for a particular time origin.
For discrete time, write the unit impulse as at and zero otherwise, a Kronecker delta. Its response is the impulse response. A finite input can be decomposed into shifted impulses, givingThe superposition principle supplies the sum and time invariance supplies the shifted copies of . Infinite sums need convergence assumptions; for a bounded input and an impulse response with absolute summability, the discrete convolution converges absolutely. For a physical system with stored initial energy, this construction describes the response with zero initial state; a separate free response accounts for nonzero initial conditions.
The gain is reuse. Measure or calculate one impulse response, and the convolution predicts the response to every allowed signal without solving a new dynamical problem each time. Alternatively, the frequency response predicts how each oscillatory component changes. [ref]
https://ocw.mit.edu/courses/res-6-007-signals-and-systems-spring-2011/0400ba59406d52d94c079d99928156ee_MITRES_6_007S11_lec04.pdf. Oppenheim, lecture 4: convolution from shifted impulses
.The frequency response gives the change in complex amplitude of a sustained oscillation under a linear time-invariant system. If the impulse response is finite or has absolute summability, substituting into its discrete convolution yieldsThus is the amplitude gain and its complex argument is the phase change. Real sinusoids follow by taking real or imaginary parts. Here is radians per sample; for cycles per sample. A physical sampling rate converts that normalized frequency into cycles per second.
For a trailing moving average,with removable singularities evaluated from the finite sum. In particular . For and , the five roots of unity sum to zero, so the oscillation is canceled. At small positive frequencies in the first pass region, the real sine ratio is positive and the phase factor gives a delay of samples.
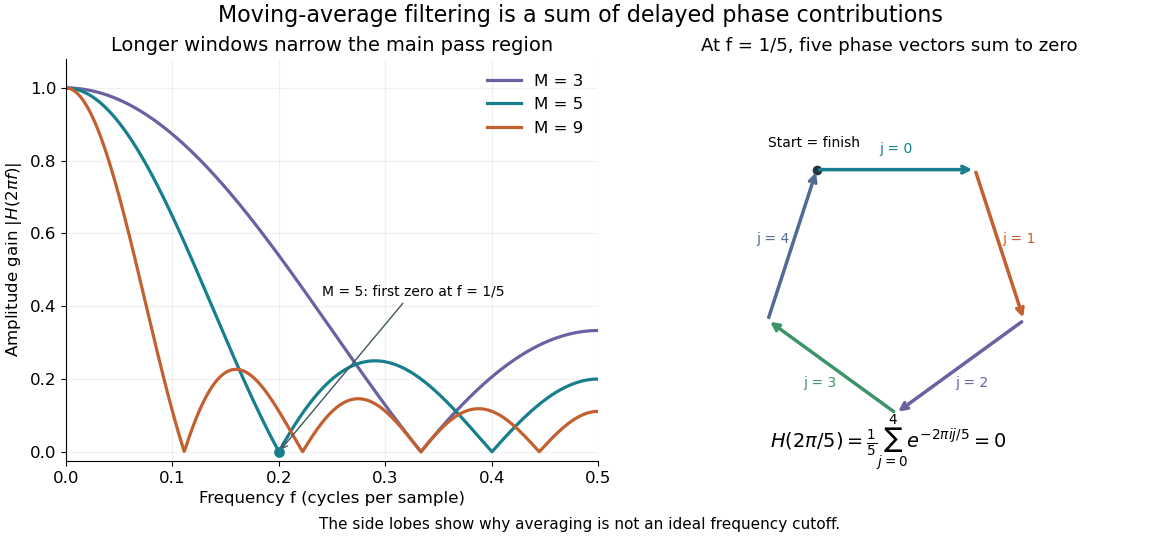
Increasing moves the first zero to , narrowing the main region of large gain. It does not create an ideal low-frequency cutoff: later side lobes transmit some higher-frequency components, and suppressing a component is only helpful when that component is unwanted. The frequency plot is the same operation as the delayed-sample average; the five-vector diagram explains one exact zero geometrically.
An antiresonance is a suppression of a specified measured response through cancellation of contributions, often between normal modes. It does not generally mean that the entire system is motionless. In an ideal undamped two-oscillator system, the directly driven oscillator can have zero displacement while its partner still moves.
Articles by others on the same topic


A Linear Time-Invariant (LTI) system is a mathematical model that describes a specific type of dynamic system in the fields of engineering and signal processing. An LTI system is characterized by two main properties: linearity and time invariance. ### 1. Linearity: A system is linear if it satisfies the principles of superposition.