Noncommuting rotations about fixed axes
ID: noncommuting-rotations-about-fixed-axes

Use a fixed right-handed Cartesian basis in three dimensions and active rotations in three dimensions through radians. The right-hand rule gives the following rotation matrices about the positive and axes:For the vector , the two orders giveBoth outputs have Euclidean norm , but they point in different directions. Each arrow below is a vector from the origin; the curved paths track its endpoint during each rotation in three dimensions.
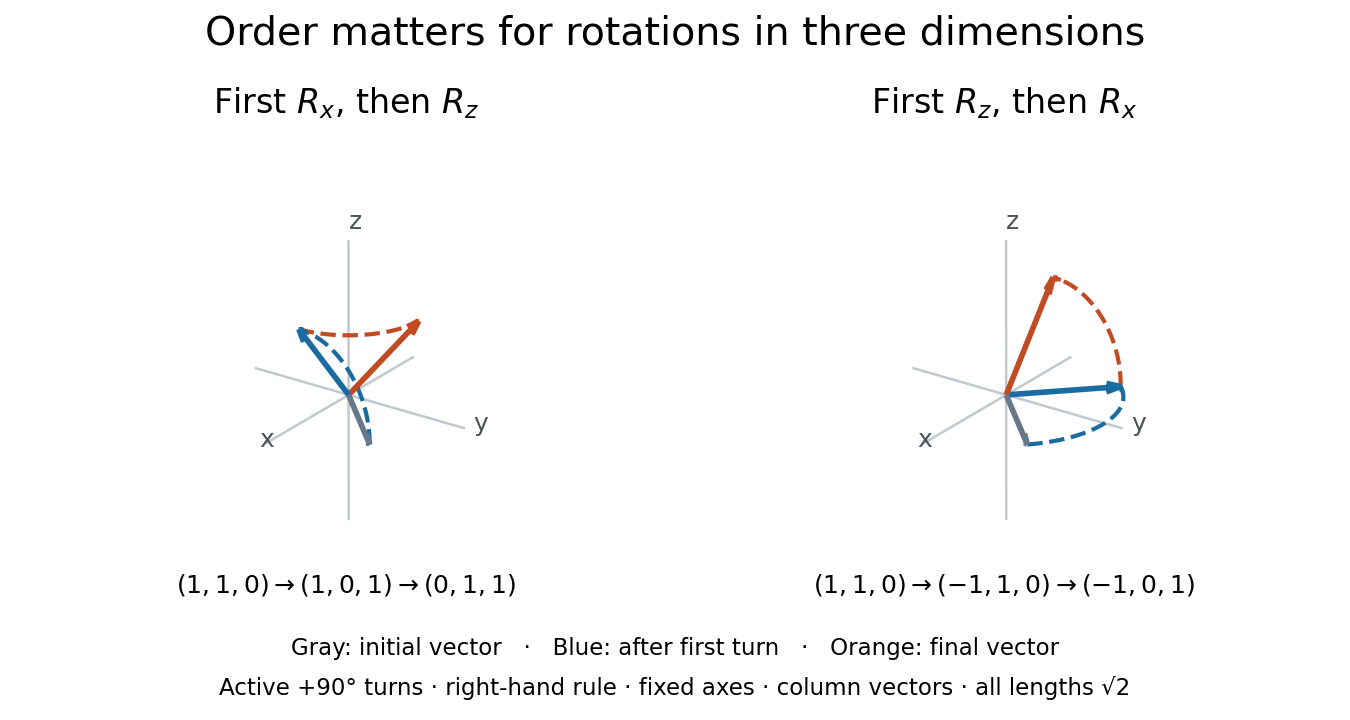
Active rotations in three dimensions about fixed axes: the order changes the final vector
. Details. 
The axes in this example remain fixed throughout. A command to turn about an object's own current axis describes a different operation because that axis can move after the first turn. With an object's orthonormal basis represented by columns of , a fixed-axis rotation matrix acts by , whereas the corresponding rotation expressed in the object's own basis acts by .[ref]
New to topics? Read the docs here!