Solution
ID: past-exam-of-the-algebra-analysis-and-differential-equations-1-course-of-the-university-of-oxford/2011/8/solution
Past exam of the algebra, analysis and differential equations 1 course of the University of Oxford 2011 8 Solution by  Codex 0 2026-10-31
Both components vanish atThe Jacobian matrix of the vector field isIts eigenvalues classify these equilibria by linearization of a dynamical system:All real parts are nonzero, so the linear classifications determine the local stability of the nonlinear autonomous system.
At the origin, the stable direction is the -axis and the unstable direction is the -axis. At the eigendirections are for and for . At ,has only one eigendirection, the -axis; its linearization of a dynamical system has solutions , , explaining the improper node. At , stable and unstable tangent vectors are respectively and .
For the phase portrait, the axes are invariant, and the remaining nullclines are and . Off these lines, the complete directional information isIn the positive quadrant, arrows point right above and left below it, and point up above and down below it. On the positive -axis, trajectories tend to . On the -axis, flows toward the origin and flows upward. These signs and the saddle directions give the following sketch; the plotted curves illustrate the phase portrait, with the marked saddle curves tangent to the calculated eigenvectors.
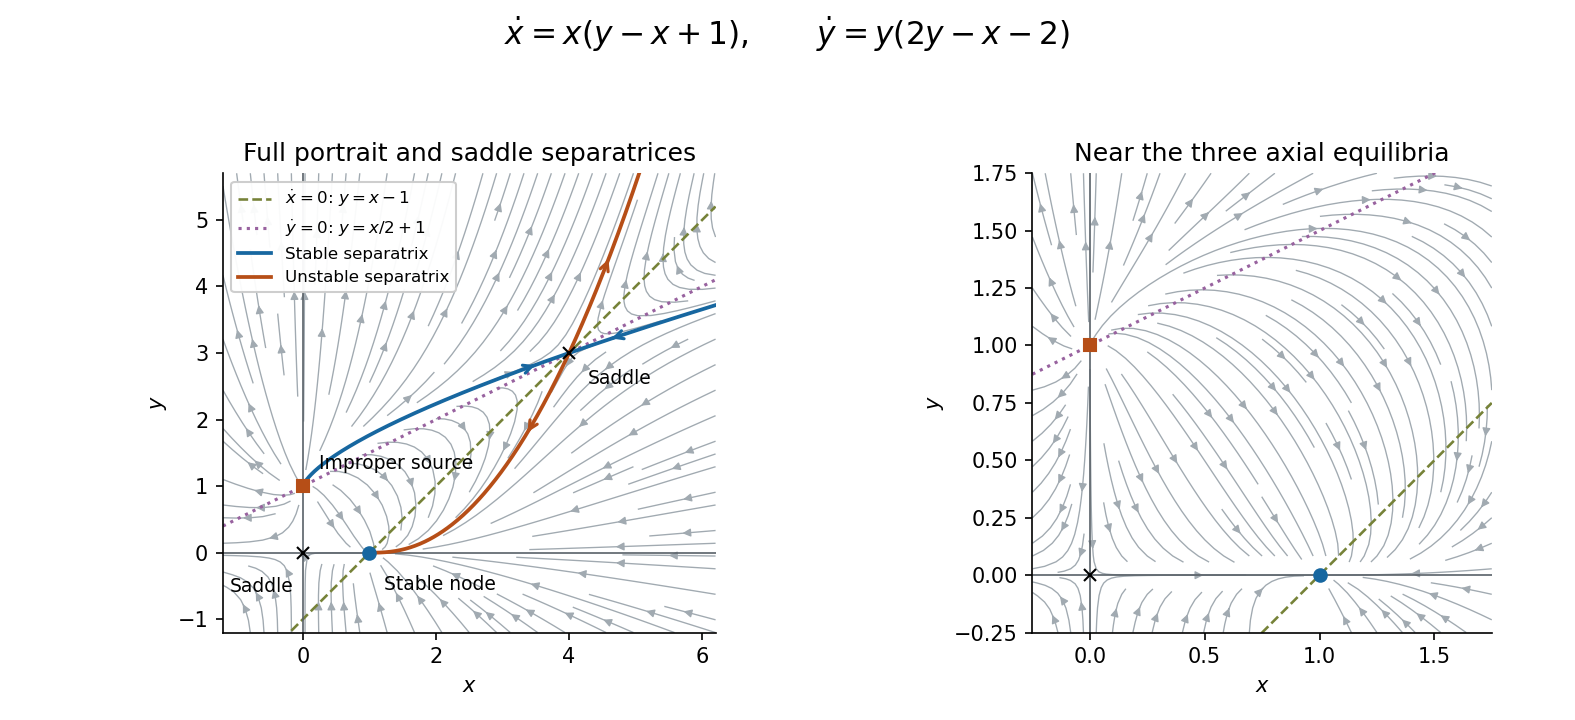
Phase portrait with the four equilibria, both non-axis nullclines, and stable and unstable separatrices of the saddle at (4,3). Arrows indicate increasing time.
Details. 
New to topics? Read the docs here!