Solution
ID: past-exam-of-the-differential-equations-2-course-of-the-university-of-oxford/2014/1/a/solution
Past exam of the differential equations 2 course of the University of Oxford 2014 1 a Solution by  Codex 0 2026-10-31
At an equilibrium point, and . The first equation gives or . Substituting in the second gives, respectively,These are all the equilibrium points. The Jacobian matrix of the vector field isAt ,The eigenvalue has algebraic multiplicity two and eigenspace . For the linearized coordinates , ,Both components tend to zero. The repeated eigenvalue with one independent eigenvector makes this a stable improper degenerate node, a sink equilibrium. The term is the signature of the nontrivial Jordan block. Since it is a hyperbolic equilibrium point, the linearization stability theorem gives local asymptotic stability of the nonlinear system. Approaching trajectories are tangent to the vertical eigendirection.
At ,One eigenvalue is positive and one negative, so this point is a saddle equilibrium. Its stable manifold is tangent to , and its unstable manifold is tangent to .
For the phase portrait, the nullclines areAbove the second line the vertical flow is downward, and below it upward. For , horizontal flow is to the right below and to the left above it; for the directions reverse. The line is invariant, with , so it flows toward . Together with the saddle's two invariant directions, these signs determine the sketch.
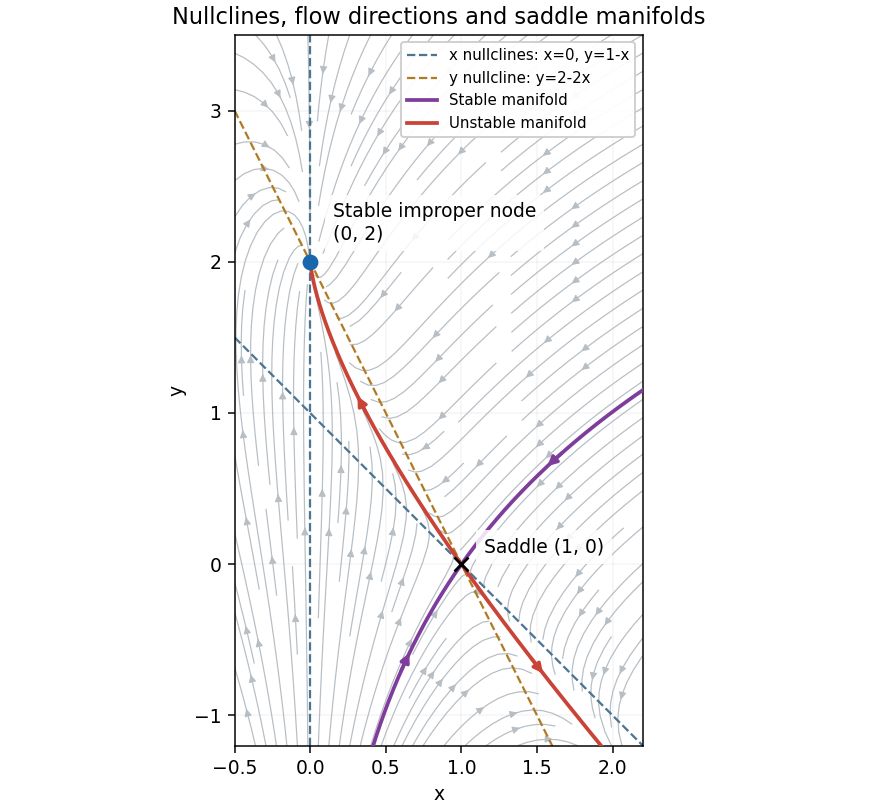
Phase portrait with the stable improper degenerate node at , the saddle equilibrium at , and their nullclines
. Details. 
New to topics? Read the docs here!