Steady-state tracking error
ID: steady-state-tracking-error

The steady-state tracking error iswhen this finite limit exists. A finite steady-state tracking error does not require the reference signal, the plant output, or the control input to become constant: all can grow while their difference settles. If the tracking error grows without bound or keeps oscillating, report that behavior rather than assigning a finite steady-state tracking error. Eventual accuracy and asymptotic stability are different questions.
For the first-order low-pass filter introduced in reference signal, assume exact measurement, constant control disturbance , and no actuator saturation or feedback delay. Under proportional control with , a constant reference signal givesThe decaying homogeneous solution has rate , so this equilibrium point is approached from any finite initial condition. A nonzero tracking error is needed to maintain the control input that balances the model's tendency to relax toward . This differs from the accumulating controlled plant , for which proportional control already tracks a constant reference signal exactly when . The presence or absence of a step offset depends on both the controlled plant and the controller.
For a ramp reference signal , the same proportional control givesIts long-time particular solution grows with slope when . Thus the controlled plant and homogeneous closed-loop response are stable, but the tracking error has no finite steady-state tracking error. A changing goal requires a different performance test from a fixed destination.
Now use proportional-integral control , , with . For the same controlled plant, differentiate the error equation on intervals where the inputs are smooth:The characteristic polynomial has both roots of a polynomial in the open left half-plane: real roots have negative sum and positive product, and a nonreal complex conjugate pair has negative real part. This proves decay of the homogeneous error for this model. It does not prove stability of an arbitrary controlled plant controlled by positive gains. At a reference jump, use the original ordinary differential equations to set the new initial conditions, rather than treating the reference as smooth at that jump.
With a constant reference signal and constant control disturbance, proportional-integral control therefore gives . At its equilibrium point, , , and . The stored integral maintains the required command while the current tracking error vanishes. For a ramp reference signal, however, the forcing above is , andThe tracking error settles even though the accumulated integral and the required control input grow. This finite offset is the error needed to keep increasing that command. For with , the forcing is and even this proportional-integral control leaves a tracking error growing with slope . Integral action is therefore a precise mechanism for selected input classes, not a promise of perfect tracking for every reference signal. [ref]
https://www.fbswiki.org/wiki/index.php/PID_Control. Åström and Murray, Feedback Systems, Chapter 11: integral action and actuator limits
Here are completely explicit synthetic examples with , , and no sensor bias. Choose , per percentage point, percentage point per degree, and percentage points per degree-second. Thus is dimensionless, and . In the following formulas, denotes the numerical time in seconds and denote numerical temperature rises in degrees. For the unit-step reference signal , proportional control and proportional-integral control respectively giveFor the ramp reference signal , the corresponding solutions areThe control inputs here are numerical heater-command percentage points. Substitution into and into the controller equations checks these solutions without invoking an unverified limiting rule. The proportional control step offset is degrees; the proportional-integral control step offset is zero. The proportional control ramp error grows; the proportional-integral control ramp offset is degrees, exactly .
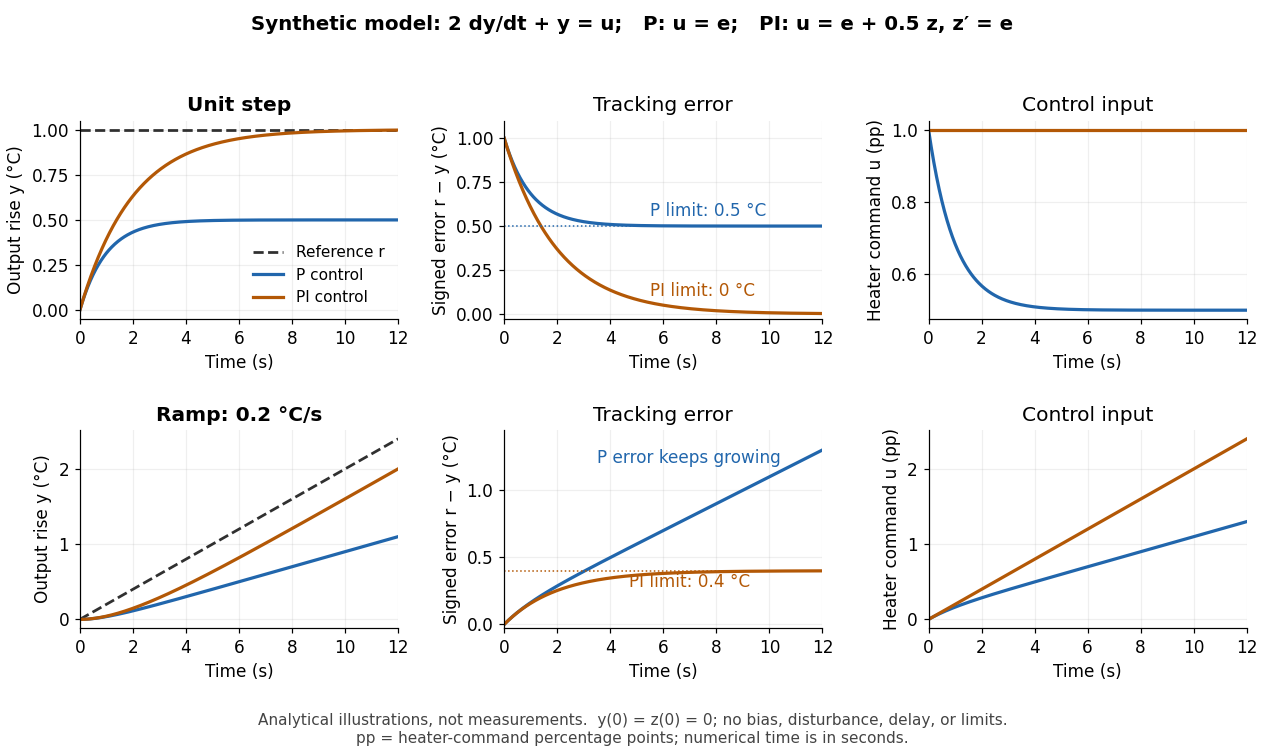
Synthetic step and ramp tracking of one stable first-order low-pass filter
. Original analytical model curves, not measurements or fits to the temperature laboratory. Columns compare plant output with reference signal, signed tracking error, and control input; rows use a unit step and a ramp of degrees per second. Both designs have decaying homogeneous responses. Proportional-integral control removes the step offset but leaves the ramp offset degrees; proportional control has an increasing ramp error. Heater-command percentage points and output degrees use separate axes. Details.
The conclusions have specific limits. With constant sensor bias , stable proportional-integral control for a feasible constant reference signal drives the measured tracking error to zero but leaves the physical discrepancy . Under proportional control, the measured offset instead becomes . If actuator saturation prevents the required control input, zero step offset is not achievable by these formulas. A changing control disturbance contributes to the error equation, while feedback delay can change stability; neither is covered by the constant-disturbance result. These restrictions are what make steady-state tracking error useful: it identifies the input, measurement convention, and model for which an accuracy claim is actually justified.
New to topics? Read the docs here!