Integral action adds memory of the tracking error to a controller: . A persistent tracking error keeps changing , so an equilibrium point with constant must have . The accumulated value can remain nonzero after the tracking error has vanished, maintaining the control input needed to cancel a constant control disturbance. Convergence still requires a stable feedback control design. [ref]
Proportional-integral control is the proportional and integral part of a PID controller, with the derivative term omitted. Proportional-integral control combines proportional control with integral action. For the ideal controlled plant, a constant reference signal, exact measurement and a constant control disturbance, the ordinary differential equations giveThe characteristic polynomial is . Positive and imply asymptotic stability of the equilibrium point: real roots of a polynomial have negative sum and positive product, hence are both negative; a nonreal complex conjugate pair has real part . This is a short stability check for this ideal controlled plant, rather than a rule for every dynamical system.
At the equilibrium point, , , and . For and , the stored value supplies even though the tracking error is zero. This separates the eventual accuracy from the transient response: integral action cancels the lasting offset but can make the plant output pass beyond the goal. The authors discuss practical limits on integral action in Åström and Murray, Feedback Systems, Chapter 11.
For , , and , the characteristic polynomial is . The initial conditions are and , givingThe tracking error changes sign at . Since , the largest plant output occurs at and is , about above the reference signal.
For a separate comparison, start the control disturbance at . For , write . The exact responses areThe proportional control response tends to , while the proportional-integral control response returns to . At , the values are approximately and . The added term in the proportional-integral control response eventually vanishes, exposing how memory removes a constant control disturbance's lasting effect.
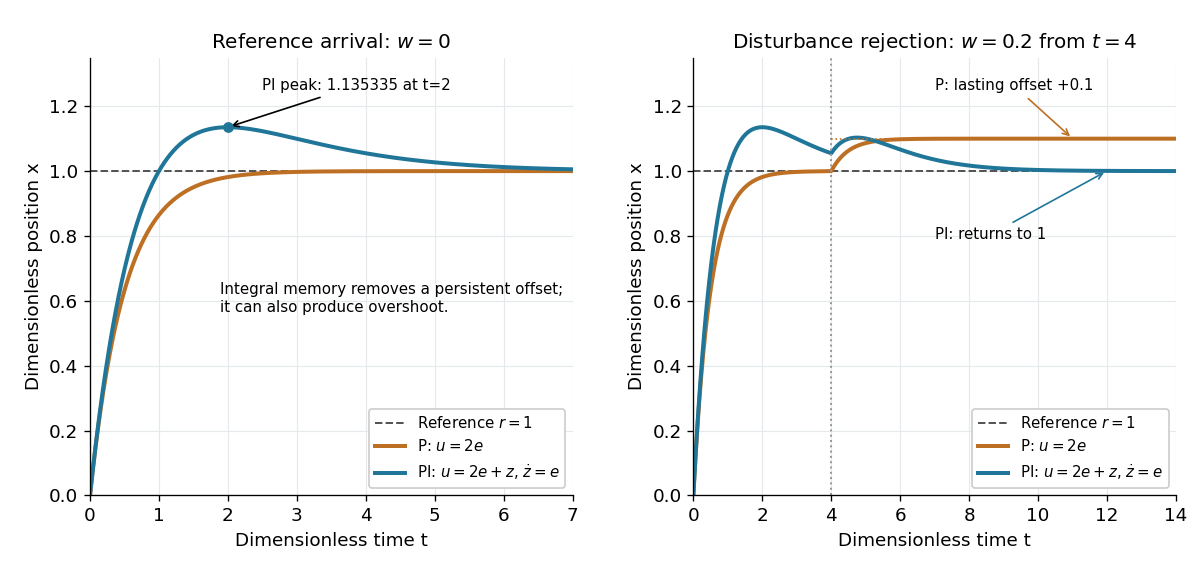
Proportional control and integral action: arrival and disturbance rejection
. Left: the ideal controlled plant has reference signal and no control disturbance; proportional-integral control reaches a peak at . Right: a control disturbance begins at ; proportional control settles at , while proportional-integral control returns to . The generator uses the classical fourth-order Runge-Kutta method with step , splits the computation at , and checks both full responses and the stored memory against their exact formulas. All coordinates are dimensionless quantities. Details.
Articles by others on the same topic
There are currently no matching articles.