Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Equivariant branching lemma
Axial isotropy of rolls and hexagons 2026-10-14
Write the translation group action as . Modulo lattice translations, the stabilizer subgroup of , with nonzero real , is the sixfold rotation group. Its fixed-point subspace of a group action is the real line . The stabilizer subgroup of , with nonzero real , consists of the circle together with a half-turn; its fixed-point subspace of a group action is the real line . The equivariant branching lemma therefore supplies generic branches of both axial types.
The full symmetry group of a cube acts as all signed permutation matrices. The stabilizer subgroups of , and have orders eight, four and six, respectively, and their fixed-point subspaces of a group action are the lines through those vectors. The three group orbits have sizes six, twelve and eight. They therefore give distinct axial types for the equivariant branching lemma. More generally the fixed-space dimension of a vector stabilizer subgroup equals the number of distinct nonzero absolute coordinate values, so these are precisely its one-dimensional types.
// Destination: dynamical-systems.bigb
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 58 2 Solution Created 2026-10-03 Updated 2026-10-14
Use a real physical field, so the three positive wavevectors are accompanied by their complex-conjugate modes. Modulo lattice translations, the effective symmetry group is . Its translation group action isA rotation cyclically permutes the amplitudes; a half-turn acts by simultaneous complex conjugation. Together these generate the sixfold rotation group. These formulas specify the group action independently of the choice of orientation of the three wavevectors.
For a nonzero real hexagon , its stabilizer subgroup is the rotation group . A translation fixes it only when all three phase factors equal one. Cyclic permutation forces a fixed vector to have equal components, and the half-turn forces those components to be real. Therefore . For a roll with nonzero real , the stabilizer subgroup consists of the translations and the half-turn, with . It is , isomorphic to as an abstract group even though spatial reflections are absent. The circle eliminates from its fixed-point subspace of a group action, and the half-turn makes real. ThusIf unreduced physical translations are used, the full lattice kernel is included in both stabilizer subgroups. The real representation on the six critical components is absolutely irreducible: translations distinguish the three Fourier pairs, rotations permute them, and the half-turn rules out a complex scalar in the commutant. The equivariant branching lemma consequently supplies generic steady branches of both axial types at a transverse crossing of the common linear eigenvalue. It guarantees existence, not stability or exhaustiveness of the possible branches.
Translation equivariance severely restricts the monomials in . Through cubic order they are , , , and : each has the same translation weight as , using . The half-turn forces their coefficients to be real; the rotation gives the two cyclic counterpart equations. A spatial reflection would interchange and require equal cross-couplings, but it is not a symmetry here. After a real amplitude rescaling makes the generic nonzero quadratic coefficient one, the rotational hexagon amplitude equations arewith the other two equations obtained by cyclic permutation. All four coefficients are real; records the absence of spatial reflection. The normalization assumes the resonant quadratic coefficient is nonzero; its vanishing would be an additional degeneracy.
For the roll, . The radial eigenvalue is and the phase of the active mode is a neutral translation. The transverse variables have matrixIts two real eigenvalues, each occurring twice in the full real linearization, are . Define and . Strict attraction modulo translation is therefore equivalent toIndeed the larger transverse eigenvalue is negative precisely when , and squaring is legitimate only after requiring . If , that inequality is impossible. Equality is also insufficient because of the additional positive term . Any nonzero roll that exists with already has a positive radial eigenvalue; the degenerate case has no ordinary isolated nonzero roll branch.
For hexagons put . A nonzero real amplitude satisfies , or when . Separate real and imaginary disturbances. The real Jacobian matrix is cyclic, with diagonal and off-diagonal entries . Its eigenvalues areThe imaginary Jacobian matrix has every entry equal to , giving eigenvalues . The two zero modes translate the hexagonal pattern. Thus the general strict stability conditions for any nonzero root areThese conditions state orbital stability transverse to translations, not asymptotic convergence to one prescribed spatial phase. Equalities require a nonlinear bifurcation calculation.
When , both are positive. The upper positive hexagon branch is radially stable after its saddle-node bifurcation at , ; it remains stable until . At this second threshold the pair crosses the imaginary axis with nonzero frequency if . The crossing is transverse, since and the derivative of with respect to is two there. Hence, subject to the usual nonzero cubic coefficient, this is a Hopf bifurcation:For the same threshold has two zero real eigenvalues, so it is not a Hopf bifurcation.
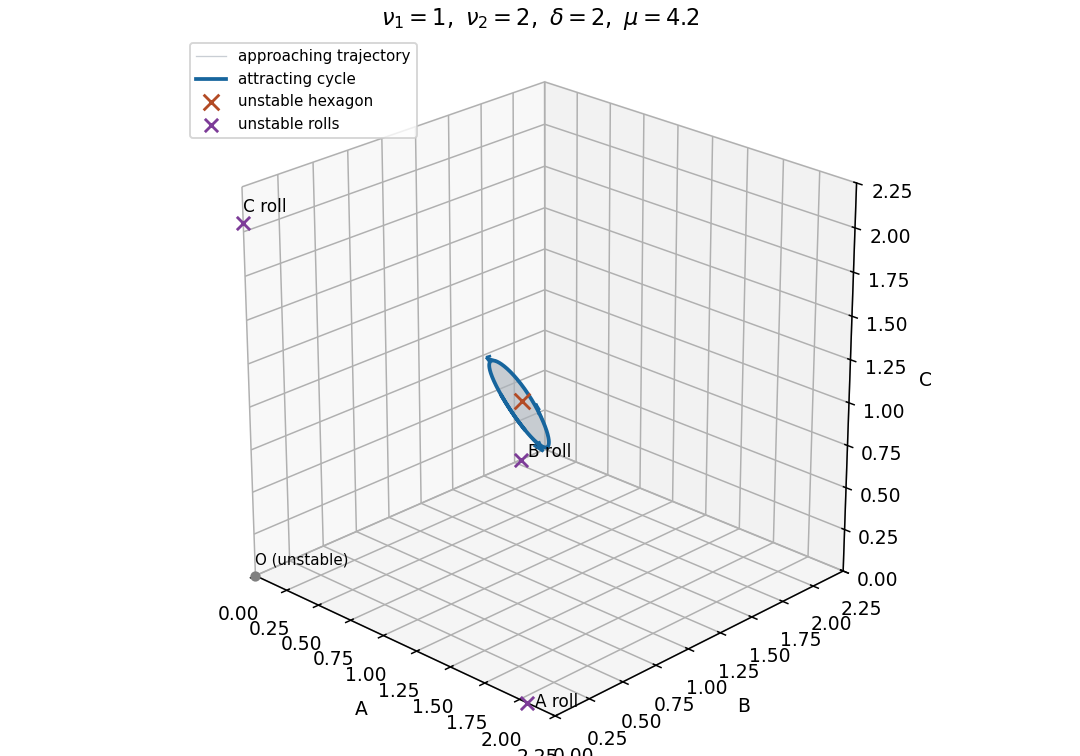
A possible phase portrait when neither steady branch is stable has an attracting periodic oscillation surrounding the unstable hexagon, with the three amplitudes waxing and waning cyclically. This is realized, for example, by , , just above . Rolls are unstable for every positive because . At the hexagon Hopf point , the real spectrum is . Evaluation of the cubic Hopf normal form with a unit-norm critical eigenvector gives , so this example has a supercritical Hopf bifurcation and an attracting small limit cycle in the real invariant subspace. The figure shows such a cycle at and an approaching trajectory; the positive octant is forward invariant because an amplitude's derivative at zero is the product of the other two. This is a possible portrait, rather than a claim that every parameter set with unstable rolls and hexagons has the same attractor. Stability asserted for the periodic orbit here is within the stipulated real subspace.

Past exam of the mathematics course of the University of Cambridge 2004 iii Paper 60 1 b Solution Created 2026-10-03 Updated 2026-10-14
Suppose is sufficiently smooth and equivariant, , and the group representation on the critical space is absolutely irreducible. Its linearization is then . Assume and . The equivariant branching lemma states that each isotropy subgroup with has a local nontrivial branch of equilibria with that isotropy, apart from the common origin. Conjugate isotropy subgroups give symmetry-related branches, so branch types are counted up to conjugacy.
To see the scalar mechanism, write the fixed-point subspace of a group action as and restrict . Equivariance makes the fixed-point subspace of a group action invariant. Since , write ; and . The implicit function theorem solves near zero. For small nonzero , the stabilizer subgroup is exactly that of . A normalizer element reversing makes odd and even; the generic branch is then a pitchfork bifurcation. The lemma ensures existence, not dynamical stability, and does not exclude further branches of smaller isotropy.
Past exam of the mathematics course of the University of Cambridge 2004 iii Paper 60 1 d Solution Created 2026-10-03 Updated 2026-10-14
Choose three representative vectors, with nonzero coordinate scale suppressed. Their stabilizer subgroups and fixed-point subspaces of a group action areHere exchanges the first two coordinates and exchanges the last two. On the first line the stabilizer subgroup is every signed permutation of the two zero coordinates; fixing it forces those coordinates to vanish. On the second line it exchanges the equal coordinates and independently reflects the zero coordinate, forcing . On the third line all coordinate permutations fix the vector, forcing .
The three subgroups have different orders and hence cannot be conjugate. Their group orbits contain respectively six face-axis, twelve edge-axis and eight vertex-axis directions. Each fixed-point subspace of a group action is one-dimensional, so the equivariant branching lemma guarantees three distinct symmetry types of bifurcating equilibria. The axial isotropy types of the full cube symmetry group are precisely these: a vector with several distinct nonzero absolute coordinate values has a separate freely variable coordinate block for each such value in the fixed-point subspace of a group action of its stabilizer subgroup, giving dimension greater than one.
Past exam of the mathematics course of the University of Cambridge 2007 iii Paper 85 3 a Solution Created 2026-10-03 Updated 2026-10-14
Let a finite or compact group act linearly on a real space , and let be a smooth equivariant dynamical system: . Assume . The representation is an absolutely irreducible real representation when its complexification is irreducible; equivalently, every real linear operator commuting with is a scalar multiple of the identity. Consequently the linearization at the trivial branch is . A generic steady-state crossing has and , with stable noncritical directions removed by a centre manifold if this is a reduction of a larger system.
The isotropy group of a vector is . For a subgroup , its fixed-point subspace of a group action is . Its normaliser isThe normaliser preserves , and describes its residual symmetry. A steady-state axial subgroup is an actual isotropy subgroup with .
The equivariant branching lemma states that, under the smoothness, equivariance, absolute irreducibility, and transverse scalar-eigenvalue crossing hypotheses above, each conjugacy class of axial isotropy subgroup gives a branch of nonzero equilibria in its fixed-point line through . The generic leading nonlinear coefficient determines which parameter side the branch occupies and whether it is transcritical-like or pitchfork-like; the theorem does not assert that these branches are stable or exhaust every possible branch. The usual nondegeneracy condition excludes a vanishing leading nonlinear coefficient. Conjugate subgroups produce symmetry-related copies of a branch, rather than new isotropy types.
To explain the dynamical role of the fixed-point subspaces of a group action, if is fixed by , then for every . Thus the vector field is tangent to that subspace, and uniqueness makes it flow invariant. On a fixed-point line one solves a scalar equilibrium equation and determines radial stability. Stability in the full space additionally requires all transverse eigenvalues to be stable. Higher-dimensional fixed-point spaces support their own restricted dynamics and may contain symmetry-constrained connecting orbits.
Finally, the normalizer action determines axial branch parity: if contains an element acting as on the fixed line, its scalar vector field must be odd, so a generic cubic term gives a pitchfork bifurcation. If that residual sign reversal is absent, a quadratic term is permitted and can give a transcritical-like branch. This is why fixed-space dimension alone does not determine either the branch type or its full stability.
Past exam of the mathematics course of the University of Cambridge 2007 iii Paper 85 3 b Solution Created 2026-10-03 Updated 2026-10-14
Use the natural dihedral group generators and , and orient the unfolding parameter so the trivial equilibrium loses stability as increases through zero. Rotation equivariance requires a monomial in to have , while reflection makes its coefficient real. These constraints give the dihedral steady-state normal form. The reflection axes have angles and one-dimensional fixed-point subspaces of a group action; their equilibria are the branches guaranteed by the equivariant branching lemma.
For , a generic quadratic anisotropy dominates:In polar coordinates, and . At a nonzero equilibrium, and . There are three symmetry-related equilibria on each parameter side, on opposite half-axes as the sign of changes. The radial and angular eigenvalues are and , respectively. Hence all three nonzero branches are saddles in the full plane, even though radial stability exchanges at the crossing. The origin is a sink for and a source for . The reflection normaliser has no residual sign reversal in this odd dihedral case, so these are transcritical-like branches, not symmetry-forced pitchforks.
For , both relevant nonlinearities are cubic:There are two conjugacy classes of reflection isotropy: the coordinate axes, with , and the diagonals, with . Generically and . Each class has a pitchfork bifurcation, with four symmetry-related equilibria when its squared radius is positive:These formulas give all generic existence and stability cases. If , both classes emerge for ; the class with consists of stable nodes and the other of saddles. If , both classes exist for ; the class with consists of saddles and the other of sources. If , one class exists on each side and both consist of saddles. Equality is nongeneric and requires higher-order terms. Unlike the odd dihedral cases, the residual normaliser quotient contains a sign reversal, enforcing exact paired pitchfork branches.
For , cubic radial saturation occurs before the first angular anisotropy:For generic , ten equilibria lie on the reflection half-axes whenever , divided into two distinct five-point group orbits. Their radii and eigenvalues areIf , they emerge for : the five with are stable nodes and the other five are saddles. If , they exist for : the five with are saddles and the others are sources. The leading amplitude scaling is pitchfork-like, but the quartic term distinguishes opposite half-axes and generally gives different corrections to their radii; there is no exact sign-reversal symmetry on an individual fixed line. Thus has quadratic saddle branches, has two cubic axial branch types, and has cubic radial branches whose angular stability splits at quartic order.
Past exam of the mathematics course of the University of Cambridge 2008 iii Paper 78 3 b Solution Created 2026-10-03 Updated 2026-10-14
For the Equivariant branching lemma, assume a generic steady-state crossing after parameter normalization, and nonzero leading nonlinear coefficient on each axial line. The lemma gives an equilibrium branch for each axial subgroup with a one-dimensional real fixed-point subspace of a group action.
For , . Conjugation by supplies the other two coordinate axes. For , . Sign reflections supply all the equal-magnitude diagonals. These isotropy types are not conjugate: their subgroup orders are and . Thus there are two distinct primary axial branch types: coordinate-axis states and equal-magnitude diagonal states.
The global sign reversal belongs to the group and makes the restricted scalar equations odd, so generically each has the form , with . Its two nonzero solutions satisfy on the appropriate parameter side. Symmetry-related solutions belong to the same branch type; their existence does not imply stability or that both types lie on the same side of the crossing.
Past exam of the mathematics course of the University of Cambridge 2008 iii Paper 78 3 d Solution Created 2026-10-03 Updated 2026-10-14
Seek an equilibrium in the invariant coordinate plane with . Put and . The two nonzero-component equations areSubtracting gives , so positive require . With , the solutions areThey are actual additional equilibria when has the sign of ; the signs of are independently free, and cyclic permutation supplies the other two coordinate planes. For example, , gives and . Thus additional two-coordinate equilibria do exist for suitable opposite-sign cross-couplings. The inequality is necessary for this type, but without the positivity conditions on the displayed denominator it need not be sufficient for every coefficient choice.
The isotropy of a generic such point is just , whose fixed-point subspace is two-dimensional. The Equivariant branching lemma guarantees axial branches with one-dimensional fixed spaces; it does not rule out these lower-symmetry branches. Their existence therefore gives no contradiction.
At fixed , letting cross zero with sends , : the new pair of opposite- branches meets an axis equilibrium. Its eigenvalue is , so this is a secondary symmetry-forced pitchfork bifurcation. Similarly, as crosses zero with , the branches meet the axis, whose eigenvalue is . The cubic formula gives near the first crossing, and near the second. Reflections force the two signs of the newly nonzero coordinate, while cyclic symmetry gives the corresponding pitchforks on the other axes. The simultaneous case is degenerate and is not a generic single-parameter pitchfork.