Write the position in the rotating basis as . Differentiating with respect to time in the inertial frame,Here is the relative velocity measured in the rotating reference frame. ConsequentlyThis is the vector differentiation rule for a rotating reference frame with a common origin: the extra term accounts for the changing basis, not a translational motion of that origin.
The PDF gives initial position and initial rotating-frame velocity zero. Use those values; the TeX erroneously places dots over the position coordinates.
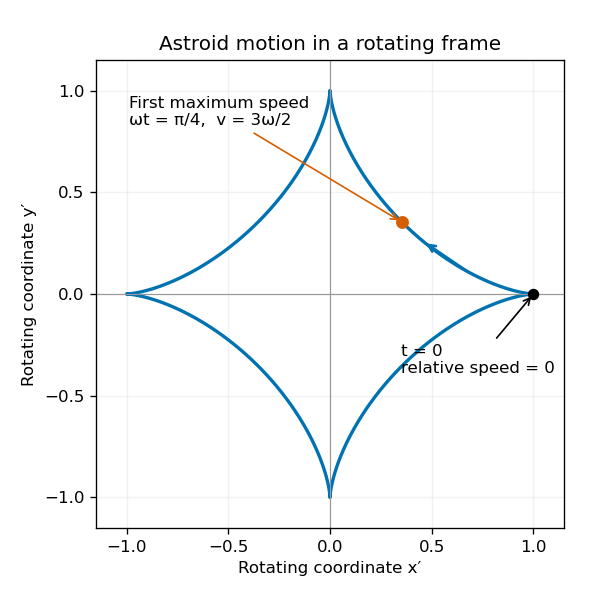
For rotation about the third axis, the supplied acceleration relation and Newton's second law give the equations of motion in a rotating frameThus . Set to combine the planar equations:The two characteristic roots are and . From and ,The triple-angle formulas therefore give the particularly simple astroid motion of a harmonic oscillator in a rotating frameThe orbit satisfies ; the zero speed at each cusp is consistent with the smooth time-parametrized motion.
Its rotating-frame speed isHence, for , the first maximum occurs at , andThe maximum repeats periodically. For a signed negative angular frequency, use and ; at the particle remains at rest.
Articles by others on the same topic
There are currently no matching articles.