Use the meridian of a knot and Seifert longitude of the unknot on its boundary torus. The unknot's knot exterior is a solid torus whose disk-bounding curve is . A genus-one Heegaard diagram is thereforeHere the horizontal coordinate is and the vertical coordinate is . The drawing uses a small translate of to avoid intersections on the edge of the square; opposite edges are identified. The algebraic intersection number of curves on an oriented surface has absolute value five.
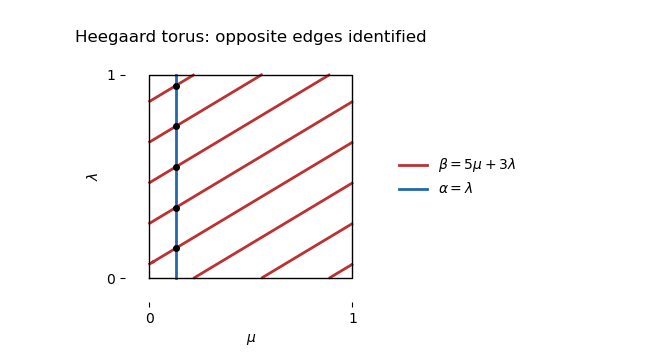

Starting with , attach a three-dimensional two-handle along , using its surface framing, and cap the resulting sphere with a three-handle. This gives the solid torus on that side. Attach a two-handle along , again using the surface framing, and cap its sphere with a three-handle. The second solid torus has its disk-bounding curve identified with , so the resulting oriented lens space is precisely the specified Dehn filling.
The solid torus supplied by the side has fundamental group generated by the image of , while is trivial. The two-handle imposes . The three-handles do not change the fundamental group, so
The elliptization theorem says that a closed oriented three-manifold with finite fundamental group has spherical geometry. When the fundamental group is a cyclic group, it is a lens space. Consequently the candidates are with , using the same surgery orientation convention throughout.
The oriented classification of lens spaces says that and are related by an orientation-preserving homeomorphism exactly when . Since , , and modulo five, the complete list isThese are three distinct oriented homeomorphism classes. Reversing orientation interchanges and ; the class containing and admits an orientation-reversing homeomorphism. The elliptization theorem and the stated oriented classification of lens spaces are the general classification results used here.
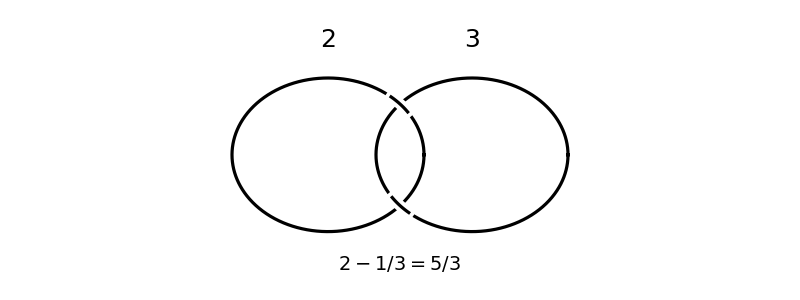
Surgery diagrams and continued-fraction coefficients
. Details. 
The slam-dunk move eliminates a meridional component with coefficient and replaces the other coefficient by . Eliminating the component with coefficient three givesThus this Dehn surgery on a framed link becomes Dehn filling on the unknot, with the required orientation. As a check, its surgery linking matrix iswhose determinant is five.
Articles by others on the same topic
There are currently no matching articles.