Given a polar axis, the equatorial plane passes through the sphere's centre and is perpendicular to that axis. In spherical coordinates with polar angle , it is the plane . For motion in a spherically symmetric gravitational field, conservation of angular momentum permits rotation of axes so that a nonradial orbit lies in such a plane. This is a choice of orientation, rather than an additional physical restriction on a spherically symmetric problem.
For a sphere of radius and a genuine plane at perpendicular distance from its centre, the intersection is a circle of radius when , a single point when , and empty when . The circle centre is the orthogonal projection of the sphere centre onto the plane. Decomposing a radius into its perpendicular component of length and its planar component of length proves the formula by the Pythagorean theorem.
For two spheres with distinct centres, the plane whose points have equal squared-distance-minus-radius-squared values for the two spheres. Subtracting the sphere equations gives its linear equation; every common point lies in it. The plane remains defined even when the spherical surfaces do not meet.
For two spheres with distinct centres , radii and , subtracting their equations gives a plane perpendicular to . Its projection of is the displayed centre, and the circle radius squared is . A nondegenerate circle exists exactly when ; equality gives tangency. Coincident equal spheres are not a circle and are excluded by .
Two distinct spheres are externally tangent when their center distance equals the sum of their radii. They are internally tangent when it equals the absolute difference of their radii. At the point of contact they have the same tangent plane.
For a sphere with a chosen polar axis, its equator is the great circle in the plane through its center perpendicular to that axis. On the unit sphere in spherical coordinates it is . Like every great circle, it is a geodesic.
A great circle passing through a chosen pair of antipodal poles, or the pole-to-pole half of that circle at fixed longitude. In spherical coordinates, a fixed azimuth selects such a half-circle. Meridians are special cases of a meridian of a surface of revolution and are geodesics of the sphere.
The solid ball inside a radius- sphere has volume . One derivation integrates concentric shell area: . The sphere itself is the boundary surface; its area is , a different dimensional quantity.
A spherical wedge is the portion of a solid sphere between two meridional half-planes meeting at a dihedral angle , with . Put the common axis along and its azimuthal bisector along . For radius , use spherical coordinates , , . Its volume is .
For constant mass density, reflection symmetries put the centre of mass on the bisector. The first moment isDividing by volume gives . It decreases from the limiting value for an infinitesimal wedge to zero for a full sphere.
The curved boundary is a spherical lune. Its outward vector area is . Indeed, its component has the same angular integrals as the first moment, multiplied by ; the other components cancel by symmetry. Its scalar surface area is , which is generally different from the magnitude of its vector area.
Two spheres with centres and positive radii intersect in a nondegenerate circle exactly under the displayed strict triangle inequalities. Put . Subtracting and gives its plane,The circle centre is , where , and its squared radius is . This is positive exactly under the strict inequalities. Equality gives internal or external tangency; coincident equal spheres have an entire sphere in common rather than a unique intersection circle.
A spherical shell is the region between two concentric spheres. A thin mass shell at radius , thickness and mass density has mass to first order. Decomposing a spherical body into such shells makes the spherical shell theorem applicable to its gravitational potential energy.
The Cartesian product has one cell in each of dimensions , counting the two middle cells separately when . For positive , its integral cohomology ring has generators of degrees , with and . The class is a product orientation class. This follows from the Künneth theorem.
For positive , quotient by . This is a free double covering space action. Its closed manifold quotient is orientable exactly when is even, because the product mapping degree is . If , the product is simply connected and the quotient has fundamental group . For , the quotient has integral cohomology groups in degrees , in degrees , and zero elsewhere. Every positive-degree cup product is zero. These conclusions follow from Poincare duality, the Euler characteristic under a finite covering, and the universal coefficient theorem for cohomology.
Surface area is the two-dimensional measure induced on the unit sphere in three dimensions. It is invariant under orthogonal rotations. It is not the restriction of ambient three-dimensional Lebesgue measure, under which the sphere has measure zero. Normalizing by the sphere area gives a probability measure.
On a sphere centred at the origin, an antipodal pair is the unordered pair . The antipodal map exchanges its two points.
For distinct points and , the distance-ratio locus is a sphere with center and radius . Completing the square proves this formula. It encloses but excludes , because their distances to the center are and . It is the zero-potential locus of two opposite-sign point charges with magnitude ratio . Equal magnitudes instead give a plane.
A hemisphere is either half of a sphere cut by a plane through its center. Its curved surface has area . Closing that surface with its equatorial disk encloses a half-ball of volume . The curved surface and enclosed solid have distinct roles in surface-cost and volume calculations.
For a closed hemisphere of radius , take a rectangular parallelepiped with a face on the flat base, base half-widths and height . Its curved-boundary constraint is and its volume is . A Lagrange multiplier gives , yielding the displayed maximum. The full edge lengths are .
This bound remains valid when arbitrary orientations are allowed. Write a cuboid's half-edge lengths as , its center components in its orthonormal edge basis as , and the vertical unit-vector components as . Containment above the base plane requires . Hence for at least one : otherwise every contributing term would be strictly smaller than its required bound. Its farthest vertex has squared distanceContainment in the sphere bounds the right side by . The arithmetic-geometric mean inequality then gives , so the full volume cannot exceed the displayed value. The constructed cuboid attains it. With strict containment and no boundary contact, the same value is a supremum.
For a nonzero vector , the open hemisphere of with direction is . Its boundary is excluded, so opposite open hemispheres are disjoint.
Choose points of such that every of their position vectors are linearly independent. Any equatorial hyperplane then contains at most points. If , at least one of each opposite pair of open hemispheres contains points. Such configurations exist: take distinct real parameters and normalize ; the Vandermonde determinant proves the required independence. This weaker one-of-two guarantee already suffices for the topological lower bound in Lovász theorem on Kneser graphs.
For integers with and , there are labelled points of such that every open hemisphere contains at least of them. The normalized vectors for increasing give a signed moment curve construction. A nonzero polynomial of polynomial degree at most cannot have enough sign changes for fewer than positive alternating sample values. Zero sample values can be perturbed negatively by a Lagrange interpolation polynomial. Labels allow repeated positions when .
A great circle is the intersection of a sphere with a plane through its centre. Its shorter arcs are geodesics of the round sphere; celestial meridians and the equator are examples.
For great circles on a sphere, with no coincident circles or triple intersection, the number of open regions is . The first circle gives two regions. Each subsequent circle meets the previous circles at distinct points and is divided into that many arcs, each splitting a previous region. Summing the increments proves the formula. If the circles are , each region has one fixed sign vector . Conversely a realized strict sign vector has a connected region: its cone is an intersection of open half-spaces, and radial projection of line segments connects any two points.
The gnomonic projection sends the visible open hemisphere of a sphere to a tangent plane by central rays. Work on the unit sphere. Choose a unit vector towards the tangent point and a plane , where . Choose an orthonormal basis perpendicular to . A point with projects toThe positivity condition ensures that the forward ray meets the chosen plane. For the plane is tangent to the unit sphere; changing rescales the image.
A great circle lies in a plane through the origin. Its projected arc lies in the straight line where that plane meets the image plane. This makes the gnomonic projection useful for drawing shortest spherical routes. For the northern hemisphere, take and : the map is . The inverse sends to . As a point approaches the bounding great circle , its image escapes to infinity. The opposite hemisphere needs a separate chart; using the same formula there would identify antipodal points.
The three-sphere is the unit sphere in four-dimensional Euclidean space:Identifying with realizes it as .
A solid angle measures how much of the surrounding directions a region occupies, as seen from a specified point . Draw a sphere of radius centered at and mark where those directions meet its surface. If the marked patch has surface area , thenA Euclidean similarity scales both and by the same factor, so the chosen radius does not affect the answer. On the unit two-sphere, the numerical value is simply the patch's surface area. Unlike an angle drawn in one plane, a solid angle measures coverage in two angular directions.
For example, the full sphere has surface area and hence solid angle steradians. A hemisphere occupies steradians. Three mutually perpendicular coordinate planes divide the directions into eight congruent pieces, so each octant occupies steradians. A solid angle of one steradian therefore covers of all directions, rather than one full turn.
This makes a geometric question answer a collection question. For an ideal point emitter with isotropy, equal solid angles carry equal radiant flux. A detector accepting directions of total solid angle intercepts the fraction of that emitted radiant flux, before losses. With direction-dependent radiant intensity , the accepted radiant flux is instead . The solid angle of a disk below gives an exact example where the familiar inverse-square law is only a distant-source approximation.
A steradian is the solid angle subtended at a sphere's center by a patch of surface area . The whole sphere subtends . In the SI, the steradian has unit one; retaining its symbol identifies a solid angle, just as radians identify an angle. A dimensionless quantity still needs its physical meaning specified.[ref]
A right circular cone with vertex selects all directions within a half-opening angle of its axis. Here is measured from the axis to a boundary direction, so the full opening in a meridian plane is . For , interpret the selected directions as a spherical cap; for , this is a region larger than a hemisphere.
The spherical coordinate system gives the area element on the sphere. Dividing by and integrating over the cap yieldsThe factor matters: a thin angular strip near a pole contains fewer directions than an equally wide strip near the equator. Treating equal intervals of both spherical coordinates as equal solid angles would overcount the polar directions.
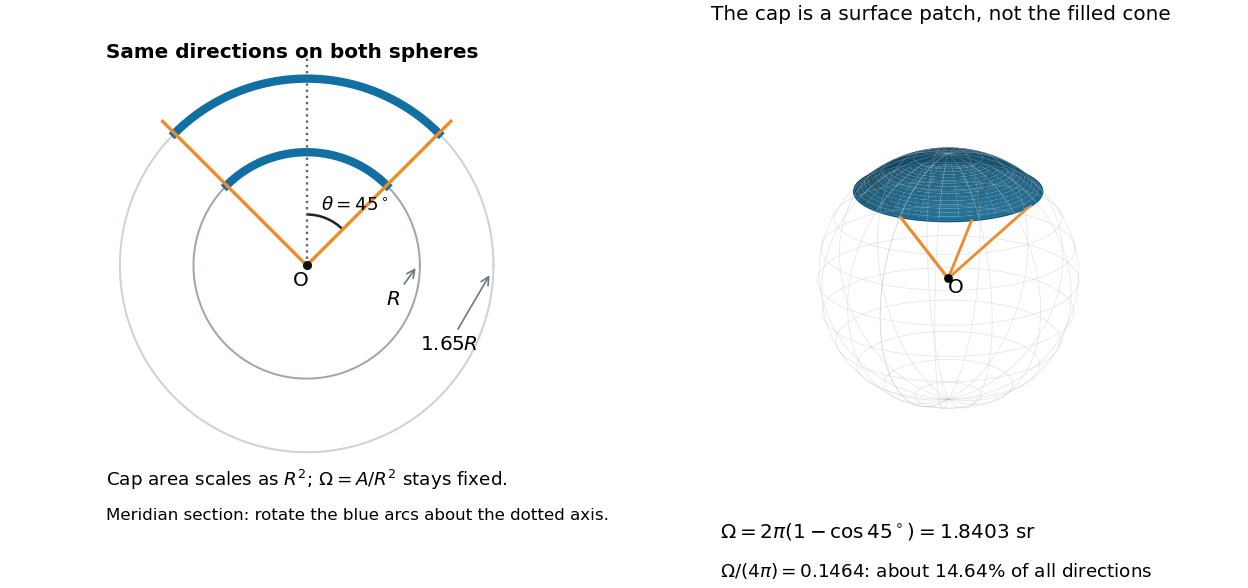
At , the solid angle is steradians, or about of all directions. At it is steradians, and at it is steradians. For a small measured in radians, the Taylor series gives the small-angle approximation . Doubling a narrow half-opening angle therefore approximately quadruples its coverage.
Consider a flat circular disk of radius , with its center a perpendicular distance from the viewpoint . The line from to its center is normal to the disk. Its rim defines a right circular cone with and . The solid angle of a circular cone immediately givesFor , this is the same half-opening example: about steradians. Both the radius and distance enter; doubling both leaves the solid angle unchanged.
A useful local version applies to a small surface patch of area , at distance from . If is the angle between its unit normal and the line to , its unsigned geometric contribution isThe numerator is the projected area. For a visible patch, perpendicular projection followed by radial projection onto a small piece of a sphere gives this formula. Integrating counts the directions once provided no direction encounters multiple counted patches. For an opaque detector, use its unoccluded face. At grazing view, the projected area tends to zero.
For this on-axis disk, a ring of radius has and . Its polar coordinates gives , so the same answer follows directly from the surface integral:The changing distance and obliquity are both already accounted for; an extra detector-wide cosine factor would count the projection twice.
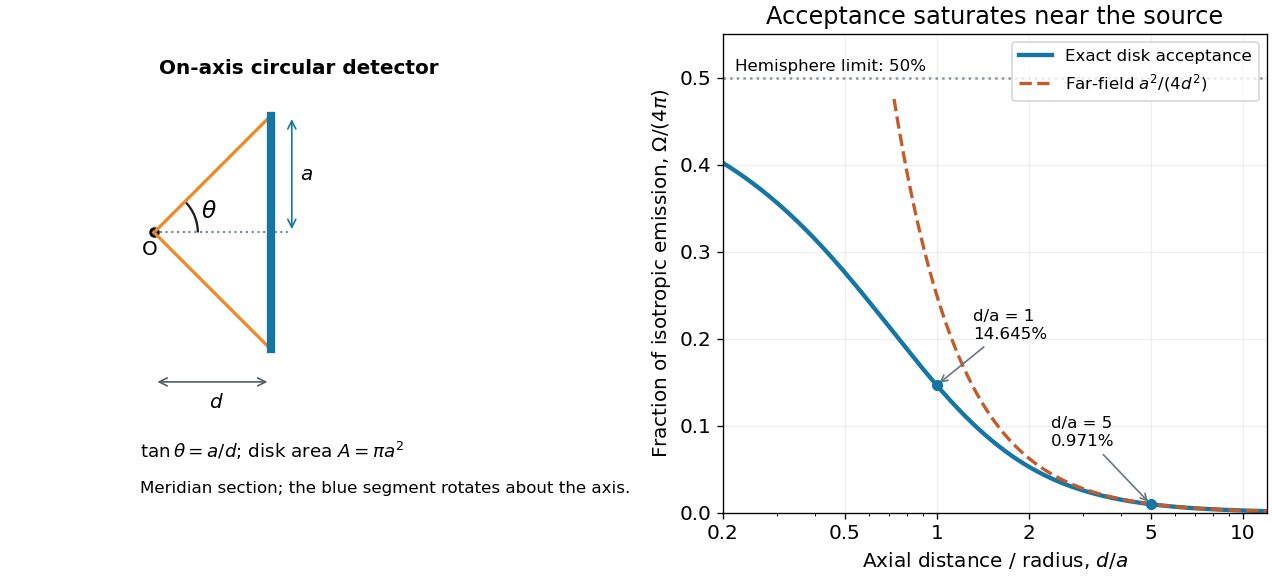
For , the Taylor series of givesThus the accepted fraction of an ideal point emitter's isotropic output is approximately , where . This is the geometry behind the inverse-square law for a small detector. At fixed , however, taking gives , so the accepted fraction approaches rather than diverging.
For a chosen numerical example, let and . The exact solid angle is approximately steradians, giving an acceptance fraction . An ideal point emitter with isotropy and total radiant flux would therefore send about onto the disk. The distant-source approximation gives , about high. This calculation assumes unobstructed propagation and counts incident radiant flux; photon absorption, detector response, and any optical attenuator require separate factors.
The normalized angular average is over the unit sphere, with solid angle measure . Rotational symmetry gives , , and . The constants follow by contracting indices and using . These identities extract photon angular temperature moments. For normalized spherical harmonics, ; their angular average instead has an extra factor .
Articles by others on the same topic

The term "Sphere" can refer to different concepts depending on the context. Here are some common interpretations: 1. **Geometric Shape**: A sphere is a three-dimensional geometric object that is perfectly round, where all points on its surface are equidistant from its center. It is defined in mathematics and is commonly represented in equations such as \(x^2 + y^2 + z^2 = r^2\), where \(r\) is the radius of the sphere.


