The Critical Path Method (CPM) is a project management technique used to determine the longest sequence of dependent tasks or activities that must be completed on time for a project to finish by its due date. The critical path identifies which tasks are critical, meaning that any delay in these tasks will directly impact the overall project completion time. Key aspects of the Critical Path Method include: 1. **Activities and Dependencies**: Each task in a project is identified along with its duration and dependencies on prior tasks.
Articles by others on the same topic

The critical path method calculates an earliest schedule, a latest schedule for a chosen finish time, and each activity's task float. A critical path is a start-to-finish graph path whose total duration is greatest. There can be several such graph paths, and every one constrains completion. In the six-activity project scheduling example, the critical graph path is A-C-D-F, of duration .
Add a zero-duration source before every initial activity and a zero-duration sink after every terminal activity. Give each edge weight , including zero weight on edges leaving . This produces a weighted graph in which a graph path's weight counts every activity on it exactly once. The possible source-to-sink graph paths in our example, omitting the dummy endpoints, are A-B-D-F with weight 8, A-C-D-F with weight 10, and E-F with weight 4.
Every feasible schedule must accommodate each of these sequential chains. Consequently,This bound applies to all source-to-sink graph paths, not just the one we happen to inspect. The critical path method attains the bound by setting each activity's earliest start to the maximum of its predecessors' earliest finish times:Evaluate this recurrence in a topological order, obtained by topological sorting. Each satisfies every incoming optimization constraint, so these times form a feasible solution. The same recurrence calculates the greatest weight of a graph path from to ; hence the feasible finish matches the lower bound. This is dynamic programming on a Directed acyclic graph, rather than an enumeration of all graph paths. See Paul Johnson, Scheduling and longest paths, longest-path algorithm. The linear programming formulation and its certificate are developed in project scheduling duality and unit-flow certificate for project duration.
For our project scheduling example, , , and the two merges giveF finishes at 10. All six activities are completed, even though E is absent from the critical graph path. Recording which predecessor attains each maximum lets us trace a critical graph path backward from the sink; retaining tied choices exposes multiple critical graph paths.
Now fix the project start at zero and the finish at . The latest starts come from a backward pass in reverse topological order:Every activity must finish by the earliest of its successors' latest starts, explaining the minimum here. This gives , , , , , and . These latest times themselves form a feasible solution finishing at 10. The backward calculation depends on the chosen finish time; a later deadline would give different latest times and task floats. The forward and backward passes are described in Olivier de Weck, MIT ESD.36 Lecture 2, slides 22–29.
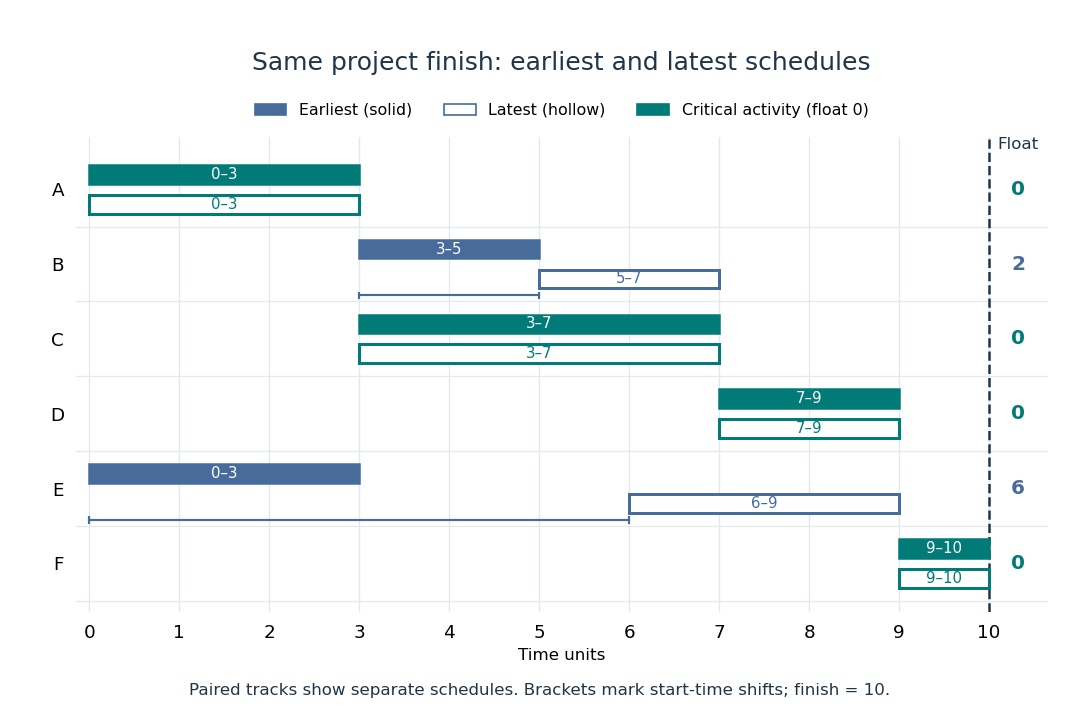
Earliest solid and latest hollow activity bars for the critical path method, with task floats of 2 for B and 6 for E
. Details. Changing a duration can change which graph paths are critical. If B's duration becomes 4, A-B-D-F and A-C-D-F both take 10: there are two critical graph paths. Shortening C alone then cannot reduce the finish time, because the chain through B still takes 10. If B's duration instead becomes 5, the earliest starts of D and F become 8 and 10, and the finish becomes 11. A-B-D-F is now the unique critical graph path; C has task float 1 relative to that new optimal finish. These calculations show why the critical path method is useful for understanding where a duration change matters, even in a project containing many parallel activities.

