Continuous-time frequency response
ID: continuous-time-frequency-response

The continuous-time frequency response is the frequency response of a continuous-time linear time-invariant system. From zero initial state, a BIBO stable system driven by a sustained sinusoid approaches the steady responseAny decaying initial or switching transient is separate. The modulus is the amplitude gain; the complex argument is the shift in oscillation phase. Thus evaluating a transfer function at measures both how much of an oscillation passes through and how far it lags.
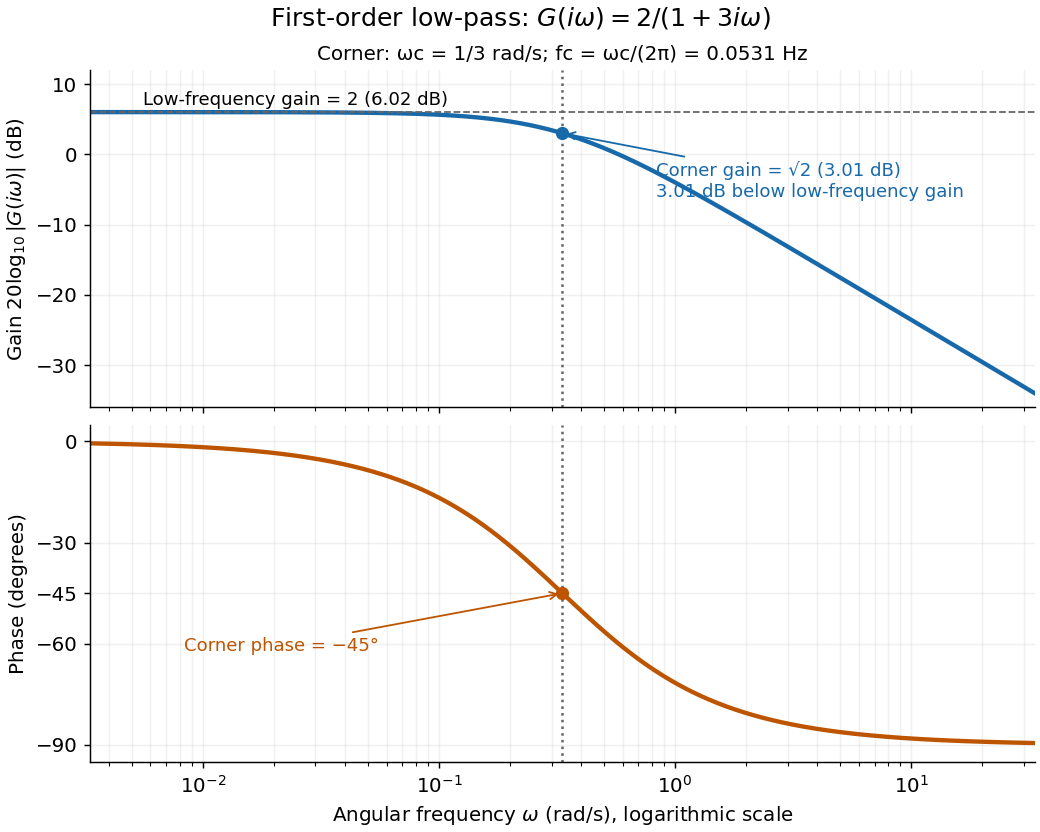
For the first-order low-pass filter, with , direct complex number arithmetic givesThe phase uses the inverse tangent branch between and . Low angular frequencies have gain close to and little lag. High angular frequencies have gain approximately and lag approaching . This is why the model is a first-order low-pass filter: it suppresses fast variation compared with slow variation. Rowell relates frequency response gain and phase to poles and then introduces Bode plots in MIT 2.004, lecture 32, sections 1 and 2.
At the corner angular frequency,For and , , the gain is , and the lag is degrees. The angular frequency is measured in radians per second; ordinary frequency is measured in hertz (cycles per second), with . Consequently the same corner is , not .

New to topics? Read the docs here!