Small rotation commutator
ID: small-rotation-commutator

Use the cross-product Lie algebra convention , , , so . Put and , using the matrix exponential. The finite group commutator isHere and big O notation refers to any fixed matrix norm. Active rotation matrices act on column vectors from right to left: first rotate about by , then about by , then about by , and finally about by . Swapping and replaces the product by its inverse and changes the leading Lie bracket to .
Writing and , direct matrix multiplication givesFor radians, , whereas . Thus the residual is a positive rotation about to leading order; at finite it also has smaller components. The Lie bracket captures the leading effect of the four moves rather than their entire finite motion. See Etingof, Section 7.2, Proposition 7.11.
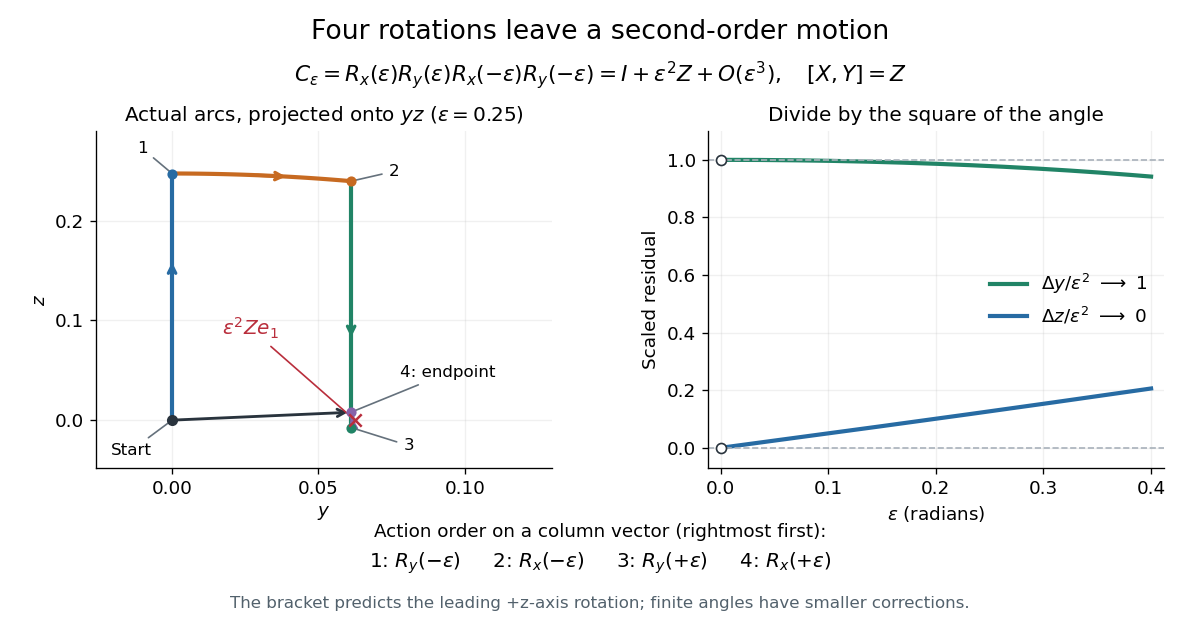

The left panel projects the actual four arcs onto the -plane for ; the start and endpoint are close but distinct. The right panel divides the residual coordinates by , making the limit visible. This is a numerical picture of in the SO(3) Lie algebra.
New to topics? Read the docs here!