Basically, a "representation" means associating each group element as an invertible matrices, i.e. a matrix in (possibly some subset of) , that has the same properties as the group.
Or in other words, associating to the more abstract notion of a group more concrete objects with which we are familiar (e.g. a matrix).
This is basically what everyone does (or should do!) when starting to study Lie groups: we start looking at matrix Lie groups, which are very concrete.
Or more precisely, mapping each group element to a linear map over some vector field (which can be represented by a matrix infinite dimension), in a way that respects the group operations:
As shown at Physics from Symmetry by Jakob Schwichtenberg (2015)
- page 51, a representation is not unique, we can even use matrices of different dimensions to represent the same group
- 3.6 classifies the representations of . There is only one possibility per dimension!
- 3.7 "The Lorentz Group O(1,3)" mentions that even for a "simple" group such as the Lorentz group, not all representations can be described in terms of matrices, and that we can construct such representations with the help of Lie group theory, and that they have fundamental physical application
Bibliography:
- www.youtube.com/watch?v=9rDzaKASMTM "RT1: Representation Theory Basics" by MathDoctorBob (2011). Too much theory, give me the motivation!
- www.quantamagazine.org/the-useless-perspective-that-transformed-mathematics-20200609 The "Useless" Perspective That Transformed Mathematics by Quanta Magazine (2020). Maybe there is something in there amidst the "the reader might not know what a matrix is" stuff.
Articles by others on the same topic

Representation theory describes abstract symmetries by linear maps on vector spaces. A group representation assigns an invertible linear map to each group element, respecting multiplication. The payoff is that a symmetry problem becomes a problem about matrices, invariant subspaces, and eigenvalues. Decomposing the action can reveal combinations of variables that a symmetric system cannot mix.
Take the cyclic group , with . On three real coordinates, let send to :This permutation representation does more than relabel a list: it acts linearly on every possible assignment of values to the three positions. The vector stays fixed. The vector subspace is also preserved, since a permutation does not change the sum.
Every vector separates uniquely into these two types:For example, . The first term belongs to a trivial representation; the second is a contrast with zero coordinate sum. This is a direct sum decomposition . The symmetry preserves the mean and rotates the contrasts.
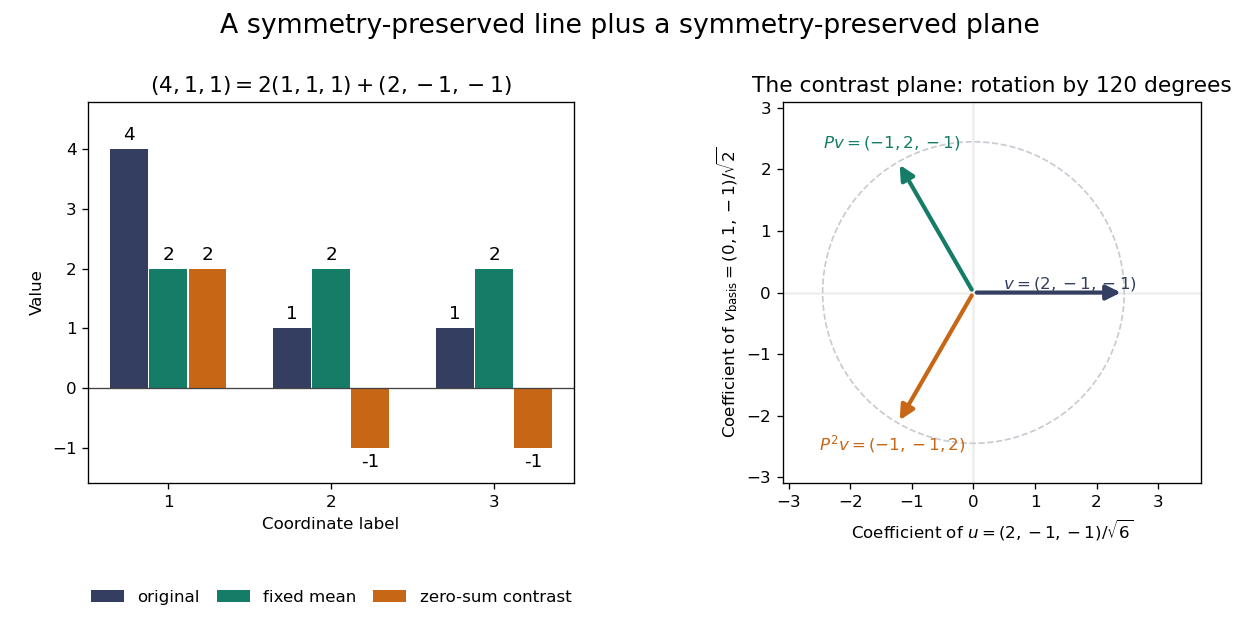
Three-coordinate cyclic symmetry preserves the mean and rotates the zero-sum contrasts by 120 degrees
. Details. The rotation is literal after choosing the orthonormal basis , of . In this basis,It is a rotation through degrees, and three applications return to the starting point. There is no nonzero invariant real line, because this rotation has no real eigenvector. Thus the two-dimensional action is an irreducible representation over the real numbers. Over the complex numbers it instead splits into two eigenlines with eigenvalues and . The coefficient field is part of an irreducibility claim.
Why would this decomposition matter for a physical calculation? Consider three equal masses with scalar displacements and the symmetric quadratic coupling energyThe equations of motion are , whereis a graph Laplacian and is the all-ones matrix. The constant vector has eigenvalue zero: translating all coordinates equally costs no coupling energy. On , vanishes and , so both independent contrast directions have angular frequency . A three-coordinate coupled problem reduces to a free mean and two identical harmonic oscillators.
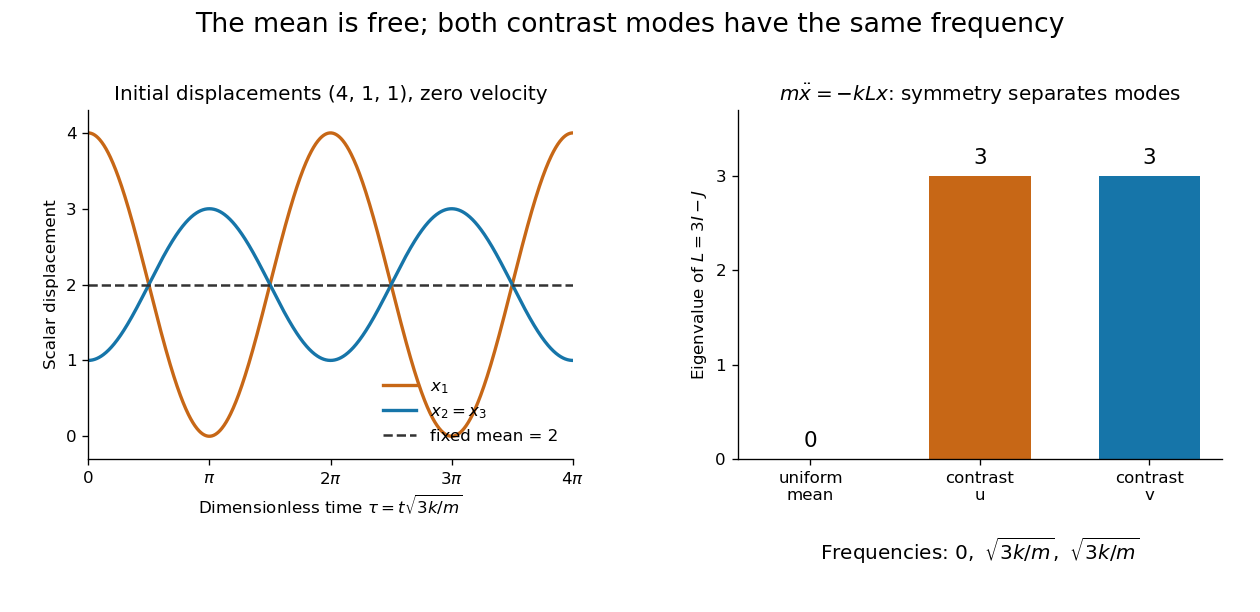
Equal pair couplings leave the mean fixed and make two independent zero-sum modes oscillate at the same frequency
. Details. For initial displacement and initial velocity zero, the exact solution is . The fixed mean and oscillating contrast can be read directly from the decomposition. More generally, a linear operator commuting with the group action carries its fixed-vector subspace into itself; with an invariant inner product, it preserves the corresponding orthogonal complement too.
For a finite group, averaging over the action constructs an invariant inner product over the real numbers or complex numbers. The resulting invariant complements explain Maschke's theorem: a finite-dimensional group representation decomposes into irreducible representations. Characters compress the action into traces and help identify those pieces. The assumptions matter; in modular representation theory the coefficient field can have characteristic dividing the group order, and such decompositions can fail. Chapter 4 of Pavel Etingof and coauthors' notes develops these mechanisms. [ref]
https://math.mit.edu/~etingof/reprbook.pdf. Etingof and coauthors: Introduction to representation theory
.


Representation theory is a branch of mathematics that studies how algebraic structures can be represented through linear transformations of vector spaces. More specifically, it often focuses on the representation of groups, algebras, and other abstract entities in terms of matrices and linear operators. ### Key Concepts 1. **Group Representations**: A group representation is a homomorphism from a group \( G \) to the general linear group \( GL(V) \), where \( V \) is a vector space.