A cut vertex, also called an articulation point, is a vertex of an undirected graph whose deletion increases the number of connected components of a graph. Write for that count, including isolated vertices, and for the graph obtained by removing and every incident edge. Then the test is , even when the original graph is disconnected. By contrast, deleting a bridge in a graph removes just one edge and keeps both endpoint vertices. These are different failure models. [ref]
https://algs4.cs.princeton.edu/41graph/. Sedgewick and Wayne, Algorithms, §4.1: bridges and articulation points
First take two triangles in a graph, and , sharing only the vertex . This simple graph hasHere abbreviates the unordered pair . Removing leaves the two connected components of a graph and , so . Removing any other vertex leaves a connected graph. Thus is the only cut vertex. Every edge lies on a triangle in a graph, so deleting any single edge still leaves a graph path between its endpoints along the other two edges. There are no bridges in a graph.
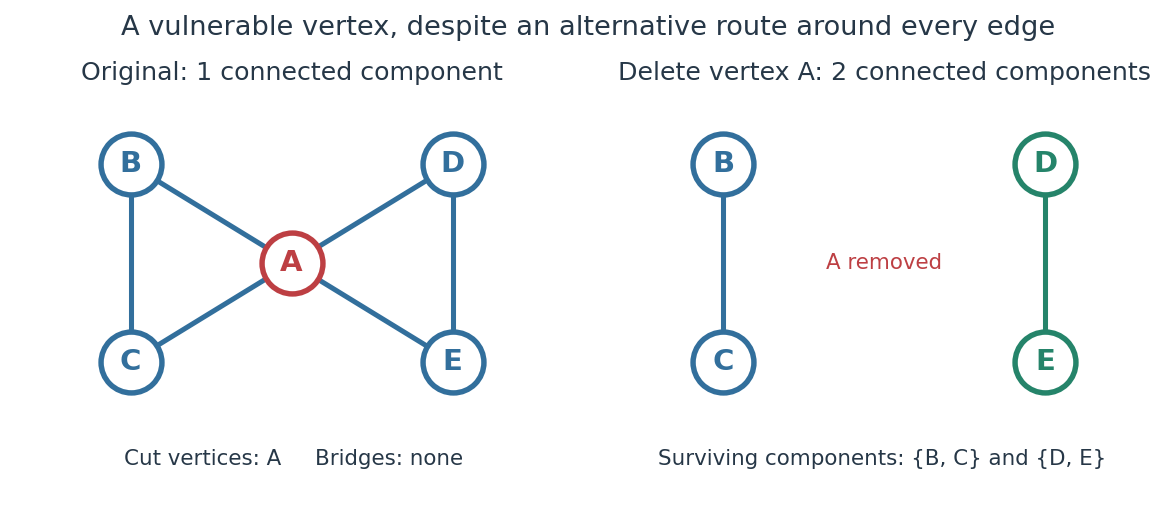
The generator computes the adjacency lists and checks every vertex deletion, giving the following complete table:
| Deleted vertex | Original graph neighbours of | |
|---|---|---|
Now take two disjoint triangles in a graph, and , joined by the edge :Deleting only preserves all six vertices and leaves connected components of a graph and : is the only bridge in a graph. Deleting also removes and , leaving connected components of a graph and . Deleting instead leaves and . Thus are exactly the cut vertices.
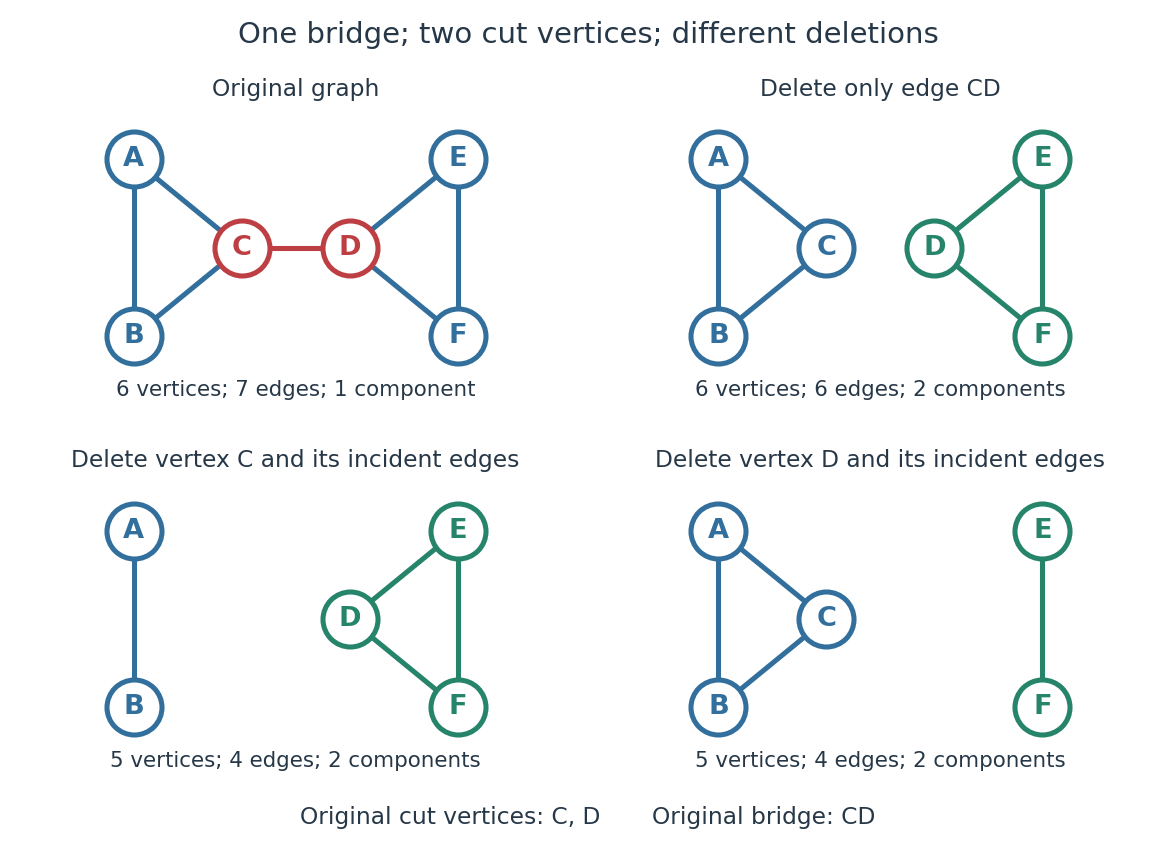


Again the adjacency lists and all vertex deletion counts are computed directly:
| Deleted vertex | Original graph neighbours of | |
|---|---|---|
For a disconnected example, adjoin an isolated vertex to the first graph. Now , deleting gives , and deleting gives . The original graph was already disconnected, but is still a cut vertex; is not. The empty graph has count zero, so deleting the only vertex of a one-vertex graph does not create a cut vertex. Nor is either endpoint of a single isolated edge a cut vertex, although that edge is a bridge in a graph.
In a communications network, a cut vertex models a router whose failure separates surviving routers. The shared- example shows why having an alternative graph path around each individual edge does not protect against failure of the common router. An additional edge from to removes this particular vulnerability: after deleting , still join the two sides. A bridge in a graph instead models a vulnerable link. This distinction tells us whether to add another cable between existing devices or a route avoiding an indispensable device; it describes connectivity, rather than traffic capacity or failure probabilities.
The beautiful structural consequence is that a graph splits into biconnected components joined at cut vertices. Within each nontrivial robust piece, a single vertex failure cannot separate the other vertices; between pieces, the shared cut vertices reveal the bottlenecks. Also, a Hamiltonian graph has no cut vertex: deleting any vertex from its Hamilton cycle leaves a Hamiltonian path through all remaining vertices.
Historically, Tarjan's June 1972 paper developed depth-first search as a tool for finding biconnected components in time linear in the numbers of vertices and edges. [ref]
https://epubs.siam.org/doi/10.1137/0201010. Robert Tarjan, Depth-First Search and Linear Graph Algorithms, SIAM Journal on Computing 1(2), 146–160 (1972)
In his 1983 recollection, Tarjan credited Hopcroft with the original linear-time biconnected component algorithm during their collaboration beginning in summer 1970, and described the published version as a refinement. The historical lesson is how a carefully organized traversal turns many separate deletion experiments into one computation. [ref]https://garfield.library.upenn.edu/classics1983/A1983QY47200001.pdf. Robert E. Tarjan, Citation Classic recollection (1983)
A biconnected component is a maximal connected subgraph with no cut vertex of its own. We use the block convention that also includes each bridge in a graph with its two endpoint vertices, and each isolated vertex, as a biconnected component. A biconnected component with at least three vertices stays connected after any single vertex deletion. Distinct biconnected components share at most one vertex; the vertices belonging to more than one biconnected component are exactly the cut vertices. The shared- example has two biconnected components, its two triangles in a graph. The joined- example has three: , the bridge in a graph with its endpoints, and . The edges partition into these pieces, while the shared cut vertices occur in several pieces. [ref]
https://algs4.cs.princeton.edu/41graph/. Sedgewick and Wayne, Algorithms, §4.1, biconnected components exercises
The DFS discovery time of a vertex is its first-visit number in depth-first search, assigned by an increasing counter. Discovery edges form a rooted tree in each connected component of a graph. For the joined- example, starting at and visiting graph neighbours in lexicographic order gives first visits , numbered ; its discovery edges are . These numbers encode the chosen traversal, not an invariant of the graph.
For a finite simple graph that is an undirected graph, the DFS lowpoint of is the smallest DFS discovery time reachable by following zero or more discovery edges down its rooted tree, then at most one non-discovery edge to an ancestor. Staying at is allowed. Ignore the reverse traversal of the discovery edge to the parent in a rooted tree: it is the same edge, not an escape route. Start with . On returning from a child in a rooted tree , replace by . For a non-discovery edge from to an earlier ancestor , replace it by . This summarizes how far upward the explored branch can reconnect. [ref]
https://sites.cs.ucsb.edu/~gilbert/cs240a/notes/TarjanDFS.pdf. Tarjan (1972), §3, LOWPT recurrence, pp. 151–153
The cut vertex criterion has a separate case for each root of a tree in the discovery forest:
- A nonroot vertex is a cut vertex exactly when some child in a rooted tree satisfies .
- A root of a tree is a cut vertex exactly when it has at least two children in a rooted tree, counting discovery edges, rather than all graph neighbours.
- A discovery edge is a bridge in a graph exactly when . A non-discovery edge is never a bridge in a graph.
Why does equality matter? If , the branch below can reconnect to , so the discovery edge lies on a graph cycle and is not a bridge in a graph. Deleting the vertex destroys that reconnection too. If has a parent in a rooted tree, the branch is then separated from that parent in a rooted tree, explaining the non-strict cut vertex test. For a root of a tree, there is no earlier side to separate from; distinct discovery branches cannot have an edge between them, since depth-first search would have explored them as one branch. This gives the two-children in a rooted tree rule. These are proof outlines of the criteria. [ref]
https://algs4.cs.princeton.edu/41graph/Biconnected.java.html. Sedgewick and Wayne, Biconnected.java: discovery, lowpoint and root tests
[ref]In the joined- example with DFS discovery times , the DFS lowpoints in label order are . For and its child in a rooted tree , : is a bridge in a graph, and is a cut vertex. For and its child in a rooted tree , : is a cut vertex, although is not a bridge in a graph. The root of a tree has only one child in a rooted tree, , so it is not a cut vertex. In the shared- example, the root of a tree has two children in a rooted tree, and , and is a cut vertex, while every DFS lowpoint is and no edge passes the strict bridge in a graph test.
Restart depth-first search at every undiscovered vertex to cover a disconnected graph, applying the root of a tree rule separately in each connected component of a graph. With adjacency lists and constant-cost label operations, computing all DFS lowpoints, cut vertices and bridges in a graph has time complexity in Big O notation, because each vertex is discovered once and each edge is inspected twice. The simple parent-skipping rule assumes a simple graph. In a multigraph, skip only the actual parent edge, identified individually: a parallel edge to the same parent in a rooted tree is a valid reconnection and can prevent the first edge from being a bridge in a graph. The criteria here concern undirected graphs; a directed graph requires a different connectivity analysis.
Articles by others on the same topic
There are currently no matching articles.