The equilibrium equations are . For the fixed points are the origin, four axis points , and four diagonal points with independent signs and . The hypothesis ensures that is real. The Jacobian matrix has diagonal entries , and off-diagonal entries .
At the origin both eigenvalues are , so it is a stable node. At each axis point the eigenvalues are . At each diagonal point they are , along the radial and transverse diagonal directions respectively. ThusThe axes and diagonals are invariant lines. For the axis saddle points have stable directions transverse to their axes and unstable directions along them; the diagonal points are unstable nodes. For these roles switch: the diagonal saddle points have stable transverse directions and unstable radial directions, and the axis points are unstable nodes. Their stable manifolds separate trajectories attracted to the origin from outward-escaping trajectories. Symmetry gives the other quadrants.
For , the entire unit circle consists of equilibria. In polar coordinates and : every ray inside the circle moves toward the origin, and every ray outside moves outward. The circle has neutral tangential and unstable radial directions; its points are not isolated saddle points or unstable nodes.
All three phase portraits are shown below. The potential satisfies and , ruling out nonconstant periodic orbits. Blue curves show the saddle stable separatrices, integrated backwards from their local stable directions. The flow arrows and invariant lines, together with the equilibrium classification, specify the topology of the sketches.
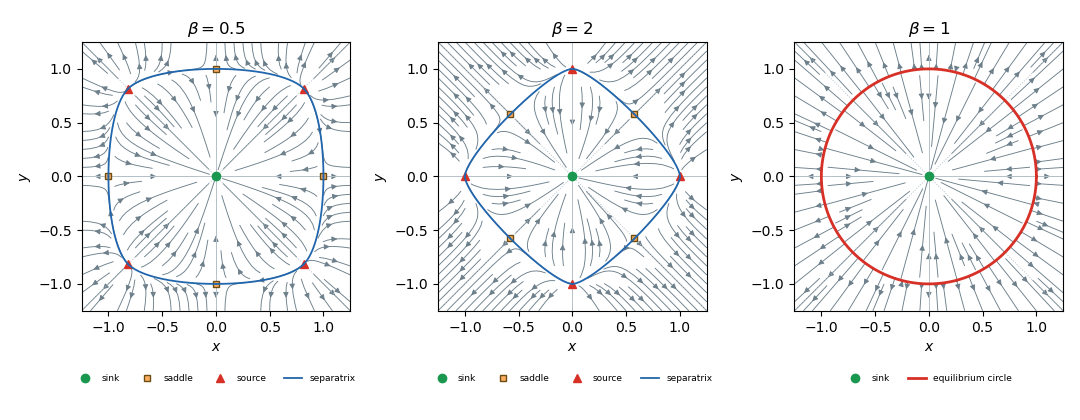
Phase portraits and equilibrium branches
. For , put and use the positive-definite Lyapunov function . Its derivative isFor set . The brace divided by is , where , and . Since , . Completing the square gives its maximumHence . If , this sublevel region is positively invariant: decreases, and . The exponential bound makes . The trajectory is bounded in a compact ellipse, so smoothness of the vector field also guarantees existence for every positive time. ThereforeFor the displayed strict inequality has no solutions; negative gives the same ellipse as . Taking the union of the nonempty ellipses is valid because each point needs only one Lyapunov certificate.
At the certified disk has squared radius . Along , the limiting threshold as is , which is strictly larger, since their difference is for . Choose strictly between these thresholds and then a sufficiently large finite . This point is certified by that ellipse but lies outside the disk. Thus the union gives a strictly larger certified region. It need not equal the whole basin of attraction.
Articles by others on the same topic
There are currently no matching articles.