Differentiate the planar rotation matrix at angle zero:The even and odd powers in the matrix exponential therefore giveThis exact formula gives the whole one-parameter subgroup. Taking means unit angular velocity: at , sends to , a counterclockwise quarter-turn. At , it equals ; at , it returns to . Choosing reaches the quarter-turn at . Changing the generator changes the speed, while preserving the circular path.
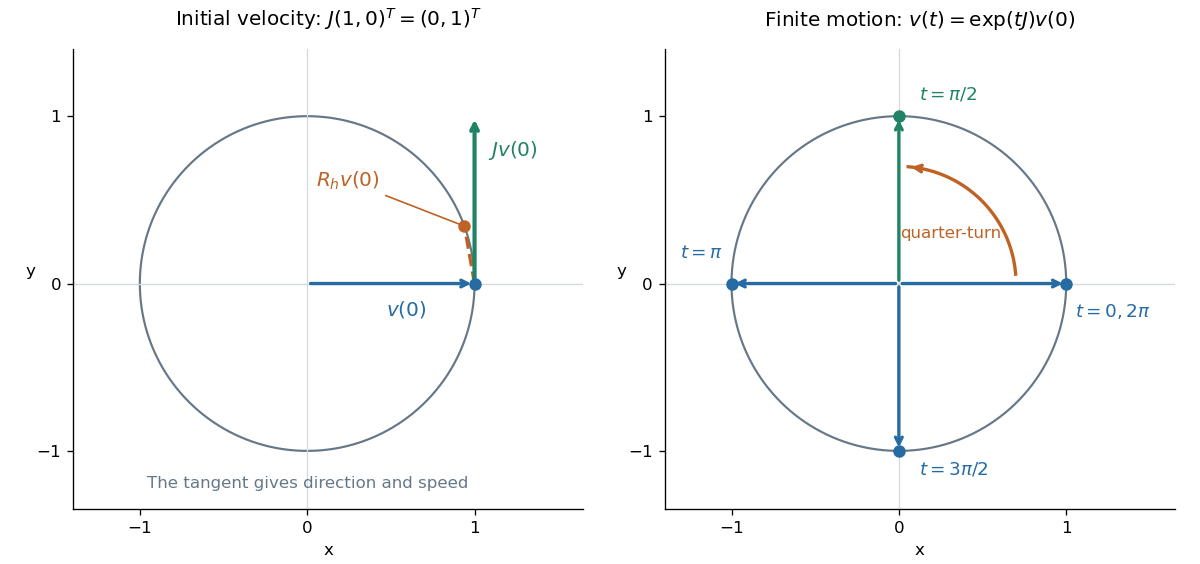

For a moving vector , the ordinary differential equation says its velocity is perpendicular to its position. The beautiful compression is that one constant matrix specifies every angle of this endless family of rotations.
Articles by others on the same topic
There are currently no matching articles.