The Inverse Function Theorem is a fundamental result in differential calculus that provides conditions under which a function has a differentiable inverse. It states the following: ### Statement of the Theorem: Let \( f: U \to \mathbb{R}^n \) be a function defined on an open set \( U \subseteq \mathbb{R}^n \). If: 1. \( f \) is continuously differentiable in \( U \), 2.
Articles by others on the same topic

The inverse function theorem answers a practical question: can nearby outputs be used to recover nearby inputs uniquely and smoothly? Its useful surprise is that a nonlinear function can be tested using its linear derivative. If the first-order changes preserve all input directions, then, on a sufficiently small region, the nonlinear map can also be reversed. This is the basis for treating a nonlinear map as a coordinate transformation.
Precisely, let be continuously differentiable on an open subset of Euclidean space, let , and put . If is an invertible linear map, there are open neighbourhoods of and of such that is a bijection with a continuously differentiable inverse function . Thus this restriction is a diffeomorphism. In coordinates the test is , using the Jacobian determinant. The derivative of a local inverse map is obtained by inverting the Jacobian matrix, at the corresponding input. [ref]
For a one-dimensional example, has . Near , the inverse function is , and the inverse function rule gives . But has no inverse function on the whole real line, since and give the same output. The theorem supplies a local restriction, not global injectivity. At zero, the derivative test fails; the nonnegative branch still has a square root inverse, but that inverse has no finite derivative at zero. [ref]
https://www.jirka.org/ra/html/sec_ift.html. Jiří Lebl, Basic Analysis: the one-dimensional theorem and the square-root example
Here is a two-dimensional example with an invertible derivative everywhere and infinitely repeated outputs:The exponential function turns into a positive radius, while is the angle in polar coordinates. Restricting, for example, to and produces the reversible patch pictured below. On its image, with Cartesian coordinates and , the inverse function isThe arctangent selects the angle near zero. Without an angle restriction, for every integer , so there is no single global inverse function. This map is a local diffeomorphism but is not injective.
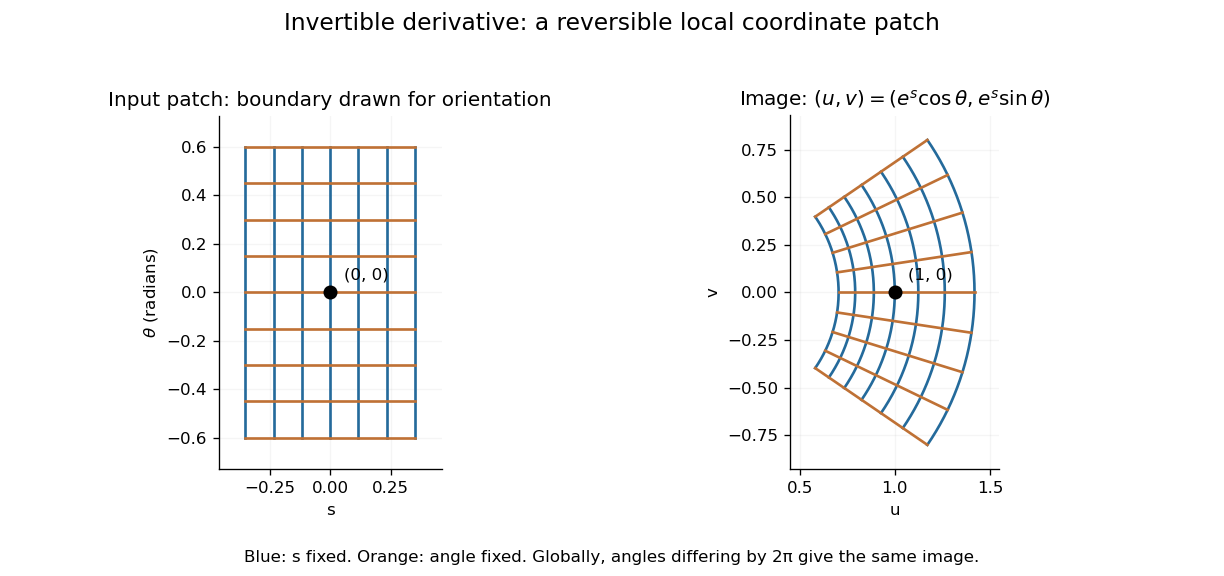
A small rectangular coordinate patch maps reversibly to a curved sector, despite global angle repetition
. Details. 
The short proof idea is to correct a guessed input using the inverse linear response. With , solving is equivalent to finding a fixed point ofAt , the derivative vanishes. Continuity makes a contraction mapping on a sufficiently small closed ball, which it maps into itself when is sufficiently close to . The contraction mapping theorem then gives existence and uniqueness there. Establishing the smooth dependence on completes the inverse theorem. This explains why the nonlinearity can be tolerated: its correction has a small local slope.[ref]
8.5 Inverse and implicit function theorems. §8.5: the contraction argument