Calibrated Einstein-de Haas torsion response
ID: calibrated-einstein-de-haas-torsion-response

An original reduced model makes the calibration explicit. Let the torsion pendulum have restoring torque , with torsion constant , and viscous damping torque , with . Allow an unwanted axial torque :Here is the undamped natural angular frequency and the quality factor. The forced harmonic oscillator response must be included before a twist can be interpreted as a torque.
Using the complex amplitude convention and similarly for and , differentiation multiplies by . Substitution givesThis is the torque-to-twist transfer function. With and real positive , the twist amplitude isFor , the twist phase relative to is . At it is zero, although the reaction torque leads by . A phase measured at the mirror is not automatically the phase of the applied torque.
A fixed-amplitude reference torque measures directly. The Einstein-de Haas effect instead contains an extra factor when stays fixed. Consequently its twist amplitude peaks exactly at in this model, whereas the fixed-torque peak is at when . To verify the first statement, divide the squared denominator of by : the quantity to minimize is , minimized at . Both response curves tend to zero at high frequency; only the magnetomechanical curve also tends to zero at zero frequency.
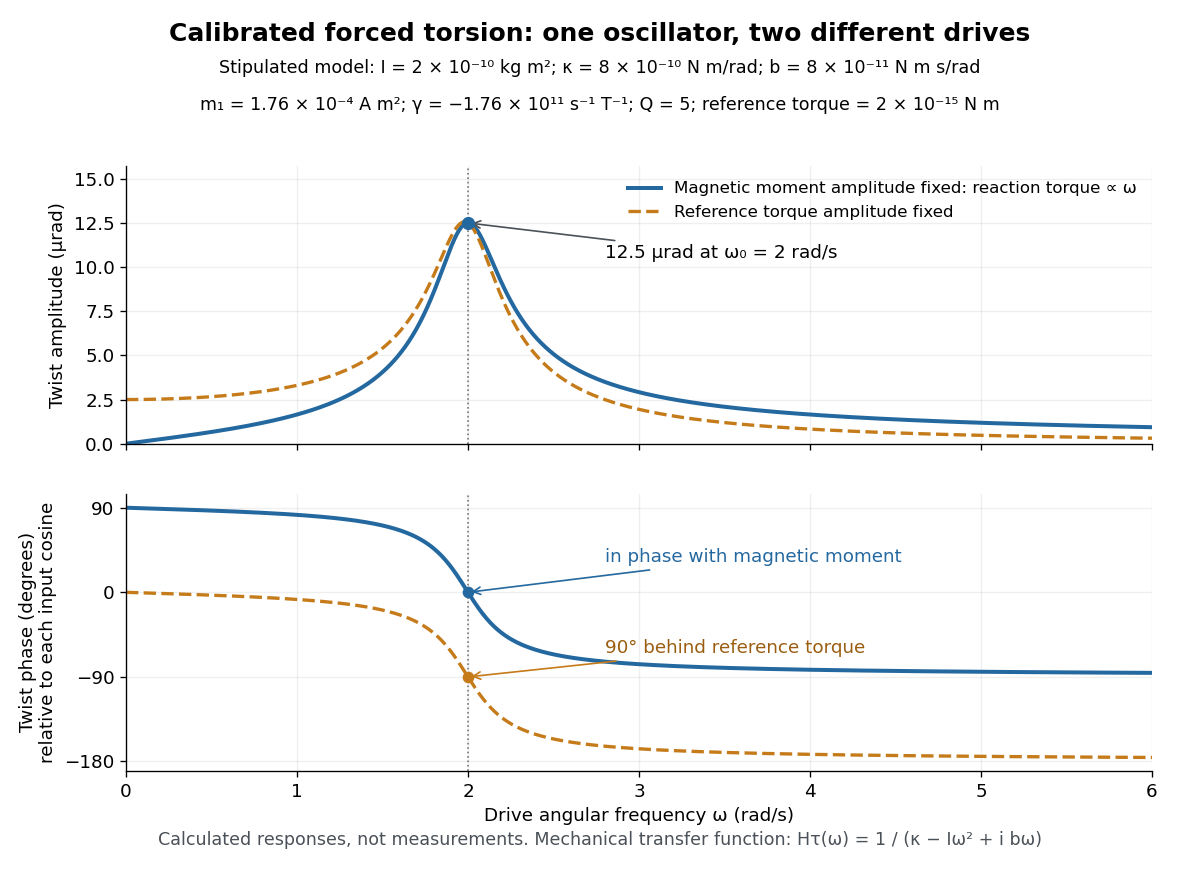
Calibrated forced torsion: distinguish the mechanical response from the magnetic drive
. Original calculated curves, not historical measurements or fitted data. A constant reference torque and a constant-amplitude magnetic dipole moment share the same mechanical transfer function. The lower plot uses each input's own cosine as its phase reference. Markers at show equal twist amplitudes but different phases. Details.
For a fully stipulated example, choose , , , , and . These teaching inputs give , , reaction torque amplitude at , andAn optical lever at distance gives small-displacement spot amplitude ; its full peak-to-peak width is . For a fast reversal from to , the same inputs give and initial , provided the external angular impulse is negligible.
One independent mechanical calibration adds known moment of inertia , keeping unchanged. If are the undamped oscillation periods before and after adding it, thenFor in the stipulated example, and , recovering the chosen and . Real damped periods require a damping correction: a free decay has angular envelope and oscillation angular frequency . Measuring that decay determines . Calibrating the optical scale, mechanical response and change of magnetic dipole moment separately is what makes the inferred gyromagnetic ratio meaningful.
New to topics? Read the docs here!