Damping dissipates the energy of an oscillation, reducing its amplitude. A linearly damped string applies this mechanism to each normal mode.
Why can stronger damping make a return to equilibrium slower? A weak brake lets a spring exchange potential energy with kinetic energy many times; a very strong brake makes the final motion creep. Critical damping marks the boundary between these behaviours. The distinction depends on the force law: the classification below concerns a single damped harmonic oscillator with viscous damping, rather than every mechanism that removes energy.
Let be displacement from equilibrium, the moving mass, the spring constant, and the constant coefficient of viscous damping. With no driving force, Newton's second law givesThe two initial conditions specify displacement and velocity. Define the undamped eigenfrequency as an angular frequency and the damping ratio as . The ordinary differential equation becomes . A constant weight in a vertical spring merely shifts equilibrium; it is already absorbed in the definition of .[ref]
For example, the ideal parameters and give and critical damping at . Values give damping ratios , respectively. These are model choices, not measured values. For release from rest with , set and ; then , where primes now denote derivatives with respect to .
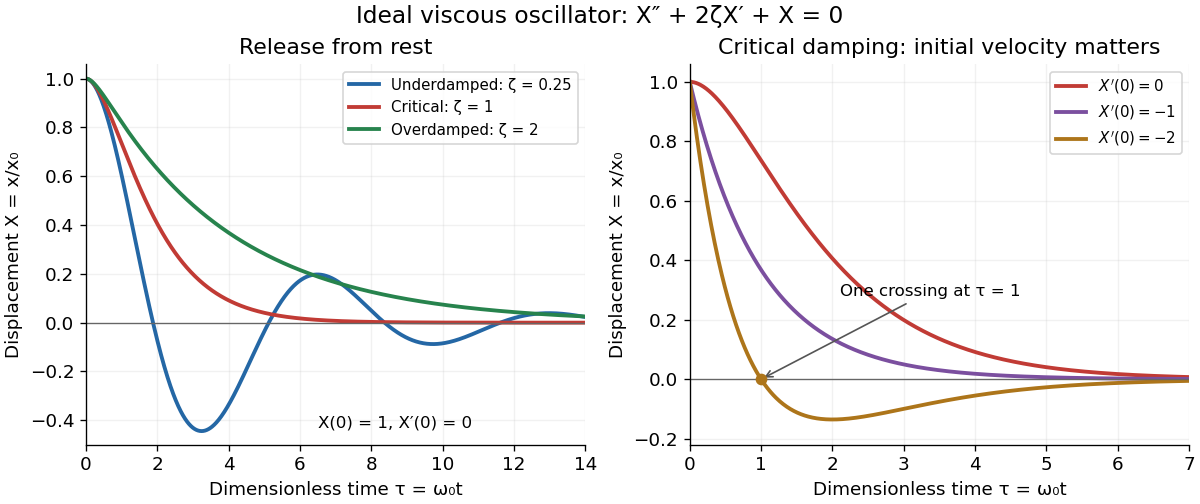
Ideal viscous oscillator responses: release from rest in three damping regimes, and the effect of initial velocity at critical damping
. Details. The left panel uses identical initial conditions , . Underdamping produces repeated crossings of equilibrium; critical damping and overdamping give positive decreasing responses. The right panel keeps critical damping but changes initial velocity: gives one crossing, although there is no oscillation. Both panels are exact model predictions.
antidamping is a velocity-proportional term that supplies rather than removes mechanical energy. For the displayed damped harmonic oscillator with negative damping coefficient, . causality of a driven solution and its long-time stability are different properties.
Critical damping is the repeated-root case of the viscous damping model: its two characteristic roots coincide at . The solution with arbitrary initial conditions isThe extra factor is essential: one exponential function alone cannot fit arbitrary initial displacement and velocity when the characteristic equation has a double polynomial root. Substitution, or taking the limit of the underdamped formula as its angular frequency tends to zero, gives the displayed expression.
The precise fastest-return statement is this: hold , , and fixed, and compare all . Every response decreases positively toward equilibrium; the critically damped responseis smaller than every overdamped response at each . It therefore reaches and stays within any specified band , , sooner than those responses. Exact arrival at rest takes infinite time. This is a comparison among nonoscillatory regimes for these particular initial conditions, not a universal minimum of every possible settling-time criterion.
One short comparison argument uses . Its initial conditions are zero and . For release from rest, at ; the causal Green function of a damped oscillator is positive at positive time for . Its convolution with gives : increasing damping beyond the critical value increases the remaining displacement.
There is no repeated oscillation at critical damping, but there can be overshoot once. For , the factor in square brackets crosses zero precisely when , atFor example, gives , crossing equilibrium at as shown above. An overdamped response can also cross once for suitable initial conditions. Conversely, specially chosen initial conditions can remove its slow exponential decay entirely. Thus the generic slow-root argument must not be applied to a response whose slow-root coefficient is zero.
A mass-spring-damper subject to a constant load obeys at critical damping. With and ,For , the displacement exceeds its final value at a positive time exactly when . Thus a critically damped step response released from rest is non-overshooting, but critical damping alone does not forbid overshoot from arbitrary initial momentum. For a vertical scale with downward coordinate, and , making the threshold .
Viscous damping means a force proportional to, and opposite to, velocity: with . Its coefficient has units , equivalently . The name describes a force law; eddy-current damping can approximate the same law without a viscous fluid. Constant , and produce a linear ordinary differential equation, allowing superposition of responses. Kinetic friction with approximately constant magnitude and quadratic drag obey different laws, so their decay need not have the exponential decay or critical threshold derived here.
The damping ratio is the dimensionless ratio . Substituting the exponential function into the viscous damping model gives the characteristic equation and its characteristic roots:For , underdamping gives a pair of complex conjugate roots with negative real part. For , critical damping gives the repeated negative real root. For , overdamping gives two distinct negative real roots. At the roots are purely imaginary and the harmonic oscillator is undamped; this boundary case has no energy loss. With , negative would inject energy and lies outside the dissipative model.
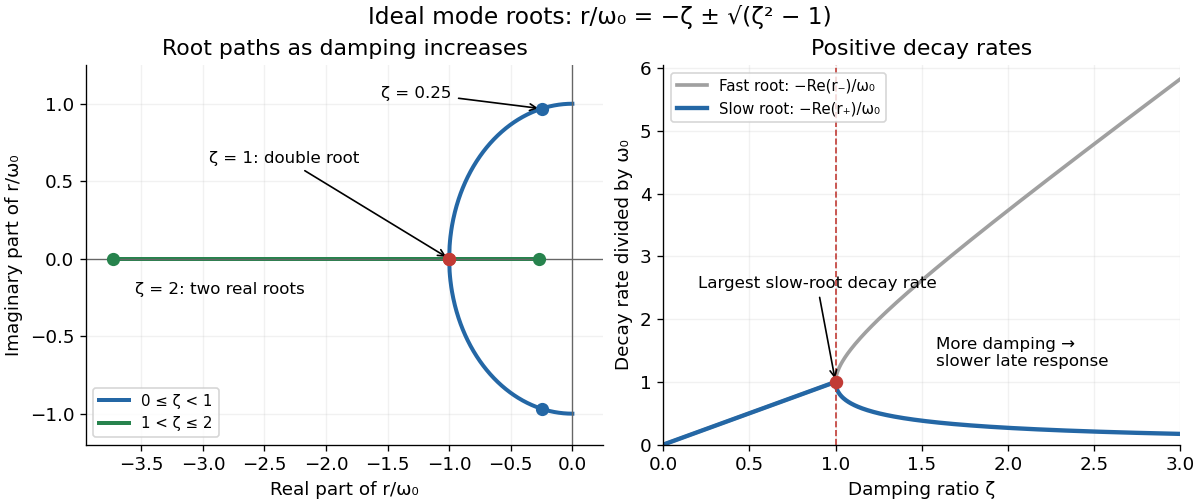
Characteristic roots of an ideal viscous oscillator and their dimensionless decay rates as the damping ratio varies
. Details. The left panel locates in the complex plane; the imaginary part gives the damped angular frequency, while the negative real part gives the exponential decay rate. The right panel shows the positive rates . Beyond critical damping, one root moves toward zero, explaining slow late motion for generic initial conditions. The repeated-root solution also has a polynomial prefactor, so these rates alone do not describe its complete response.
For a constant-force-amplitude displacement response, the frequency-domain magnitude has a nonzero-frequency peak only for damping ratio . The free time-domain motion remains underdamped for all . Thus an oscillator can have complex characteristic roots but no nonzero-frequency displacement resonance peak. The distinction depends on the measured response and drive convention, not merely on the existence of damping.
For the damped harmonic oscillator, the mechanical energy is the sum of kinetic energy and spring potential energy:Thus is the power transferred out of the oscillator's mechanical energy. For , the rate vanishes instantaneously at a turning point, despite nonzero stored potential energy; it is not a constant loss per unit time. In eddy-current damping the loss becomes Joule heating. [ref]
For an underdamped response, advancing one oscillation period multiplies both displacement and velocity by , so . This exact cycle relation does not imply that instantaneous energy is a pure exponential function throughout each cycle.
For , define the damped angular frequency . The initial value problem has solutionEvery nonzero underdamped response crosses equilibrium repeatedly. Its oscillation period is , not . The amplitude envelope decays as , but the actual displacement also changes sign. The envelope coefficient need not equal : initial velocity fixes the oscillation phase as well as that coefficient.
For with , put . The initial conditions and giveThus the turning points have the times and displacements in the title. For release from , the first positive maximum is , sufficient to test whether the body reaches a fixed positive stop before that first maximum. Every later positive maximum is smaller.
For , let be the real characteristic roots. The response with the specified initial conditions isThe generic late response is governed by , the root nearer zero. For very large damping ratio, : an increasingly strong brake delays the return to equilibrium. This approximation comes from balancing the spring and viscous damping terms after the fast transient. Choosing makes and leaves only the faster root; that exception requires different initial velocities as varies.
An experimentally useful question is whether the disappearing oscillation follows viscous damping, and whether increasing the brake changes rather than or . A published teaching protocol uses a cart on an air track, attached between two springs, with ceramic magnets providing eddy-current damping and an ultrasonic motion sensor recording position against time. Replace the magnets with equal masses in the baseline trial so the moving mass stays fixed. Obtain each spring constant from the slope of applied force versus extension, then use . Time many baseline cycles to check . Compare one-magnet and two-magnet free decays; the protocol calls for a fit of the full trace including its offset. [ref]
The following additional controls make the inference testable. Level the air track and hold its air supply fixed. Check the ultrasonic motion sensor at several stationary flag positions against a ruler, including the full planned travel range; record the offset and scale correction. Check elapsed acquisition time against an independent clock, and choose a sampling rate that resolves many samples within the shortest expected oscillation period. Record the resting equilibrium before and after each run. Release the cart from a small measured displacement with minimal initial velocity, with the driving apparatus inactive. Repeat at several release sizes and magnet settings while keeping the springs and total mass unchanged. These are proposed calibration and repeatability checks, not reported measurements from the source.
For underdamping, fit the recorded position to by nonlinear regression. The readout to inspect is a sequence of alternating extrema about with shrinking amplitudes, and the deviations of the fitted curve from the recorded points. The model predictsCompare the right-hand side, determined independently from mass and spring constants, with the fitted left-hand side. A good fit supports a constant-coefficient single normal mode over the observed range; it does not establish a universal microscopic force law. The published protocol denotes the decay rate by and the velocity-proportional coefficient by ; here they are and , respectively.
At critical damping or overdamping, fit the corresponding nonoscillatory response including its offset and both initial conditions, rather than forcing a damped cosine onto the data. Adjusting the brake can explore the transition, but the cited protocol does not establish that its one-magnet or two-magnet settings attain critical damping. A near-critical trace over a short interval can be hard to distinguish from neighbouring damping ratios.
Important limitations are finite sensor range, missed or reflected acoustic wave pulses, measurement noise near equilibrium, nonzero release velocity, and position-dependent magnetic braking. Changing the release size tests for quadratic drag or nonlinear spring response; inspecting deviations near turning points can expose kinetic friction. Slow drift of the offset can imitate a long overdamped tail. Report uncertainties in fitted rates and independently measured ; absence of a visible crossing only bounds the behaviour within the instrument's sensitivity and recording interval. No numerical experimental results are asserted here.
An air track supports a cart on a cushion of air to reduce contact friction. It provides a nearly one-dimensional platform for a damped harmonic oscillator; residual drag remains part of the baseline damping.
An ultrasonic motion sensor estimates distance from the return delay of an acoustic wave pulse reflected by a target. The teaching setup places a flat flag on the cart facing the detector above the air track, and specifies a minimum range of about for its detector. That apparatus-specific limit should not be assumed for every sensor model. [ref]
For underdamping, let be successive same-sign extrema of displacement relative to equilibrium, one full oscillation period apart. The logarithmic decrement isComparing extrema full cycles apart instead gives . Adjacent extrema of opposite sign are only half a cycle apart and give half this decrement. This distinction matters when inferring a damping ratio. Near critical damping, a full second same-sign extremum may be too small to resolve above measurement noise; a full-trace fit with uncertainty is then more informative than a peak ratio.
A linearly damped oscillator has , with and . After one damped period , both displacement and velocity are multiplied by . Their quadratic mechanical energy is therefore multiplied exactly by , regardless of the starting phase. In particular successive same-direction equilibrium crossings have this ratio even though potential energy is zero at each. A cosine phase maximum is not exactly a displacement turning point when damping is nonzero.
Eddy-current damping is electromagnetic damping in which motion of an electrical conductor through a magnetic field induces circulating electric currents, producing an opposing force and Joule heating. In the cart experiment it approximates viscous damping over the fitted range; spatial variation of the magnetic field or changes in velocity can limit that approximation.


