LIGO displacement readout and control
ID: ligo-displacement-readout-and-control

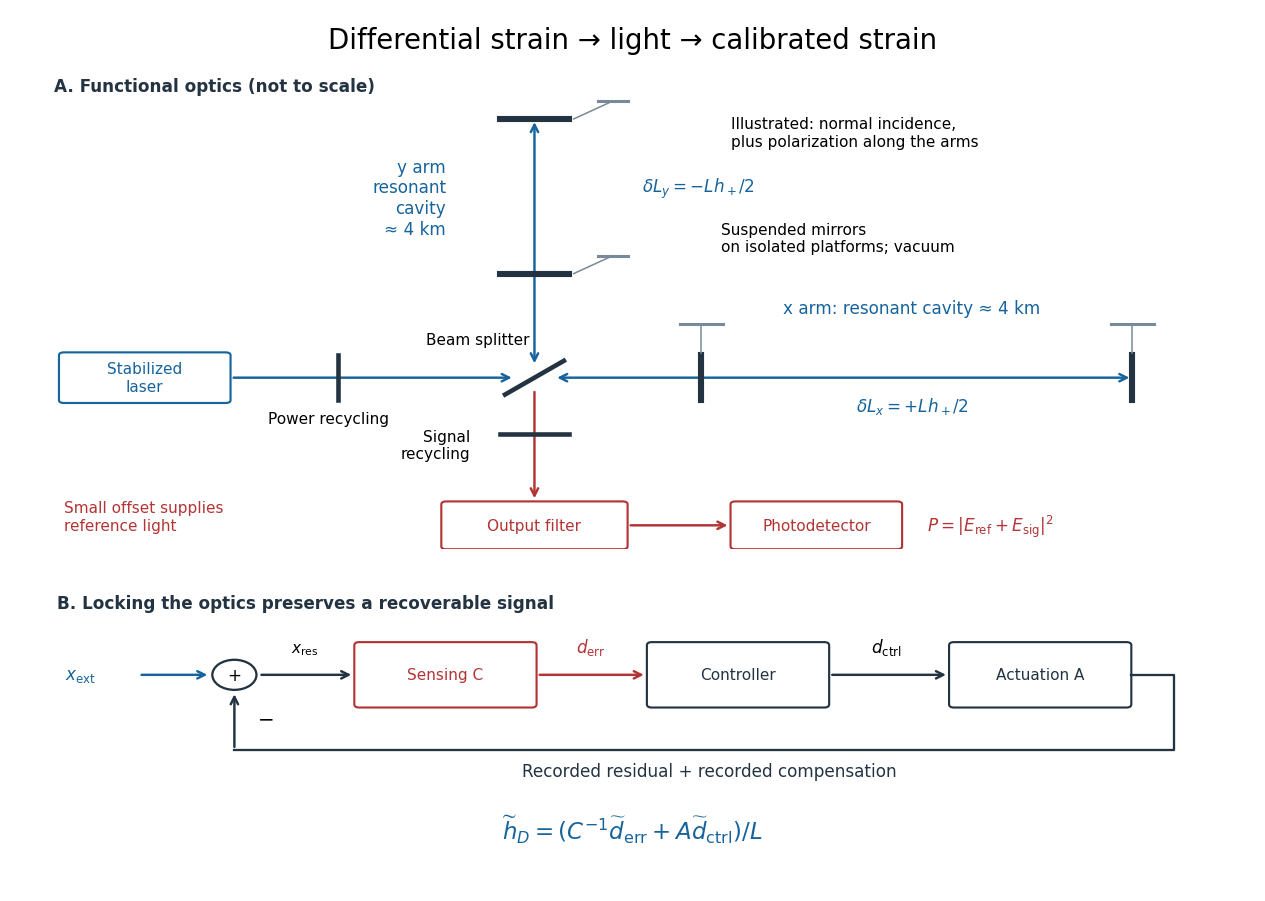
An ideal single-round-trip Michelson interferometer converts differential length into phase difference . If its dark-port power scale is and its static phase offset is , thenExactly at a dark fringe, , power is quadratic in small displacement and loses its sign. A deliberate offset supplies an optical reference field: interference with the small signal field produces a linear term. Equivalently, contains . The photodetector measures power, not a signed displacement directly.
Advanced LIGO uses this DC homodyne principle with a small differential arm offset and an output mode cleaner. Its feedback control maintains optical resonance and alignment, using actuation distributed over the suspension stages.[ref]
Advanced LIGO by J. Aasi and others. 2.3 Gravitational wave readout; 4.4.2 Quadruple pendulum design; 4.8 Interferometer sensing and control
The simple formula above omits resonant storage: arm and recycling cavities give a frequency-dependent optical gain and delay, so no constant pass-count multiplier describes the entire observing band.To see why a locked detector can still measure a disturbance, use a linear feedback control model. Let be the external differential displacement, the residual readout, the recorded control command, the sensing response and the actuation response. With the convention , reconstruction givesHere tildes denote Fourier transforms; has readout units per metre and metres per command unit. Feedback suppresses residual motion but records the compensating command. Omitting that command would suppress the reconstructed low-frequency signal too. In the actual GW150914 experiment, a modulated auxiliary laser exerted calibrated radiation pressure on a mirror to measure the response; periodic excitations monitored calibration.[ref]
Calibration of the Advanced LIGO detectors for the discovery of the binary black-hole merger GW150914 by B. P. Abbott and others. II Control loop, equations (1)–(4); IV Photon calibrator; VII Time-dependent systematic errors

New to topics? Read the docs here!