Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Arc-length parametrization
Curve parameter 2026-10-14
A curve parameter labels the points visited by a parametric curve . Choosing time as the parameter determines its velocity; an arc-length parametrization instead measures accumulated arc length. A regular monotone reparametrization changes the labels and speed while preserving the route and its arc length.
Past exam of the geometry of surfaces course of the University of Oxford 2023 3 d Solution 2026-10-25
Use the unit normal from part (c), and orient by increasing . Write for its unit tangent vector. The signed geodesic curvature convention used below iswhere is arc length. The second equality follows by differentiating : the term parallel to disappears in the scalar triple product. It makes the correction for a parameter which is not arc-length parametrization explicit.
Put , , , and . The speed is the constant . At ,soTaking its dot product with yields . ThereforeThe screw motion of part (b) makes this independent of . Thus is a geodesic precisely when is an integer multiple of . Reversing the direction of traversal or the unit normal changes the sign of signed geodesic curvature; its magnitude is the absolute value of the displayed expression. The signed convention is needed in part (e).
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 66 4 a Solution Created 2026-10-03 Updated 2026-10-14
A subdivision curve should support subdivision curve interrogation rather than merely supply successively larger control polygons. Its interface should provide the parameter interval, orientation and open/closed status; endpoint and limit-point evaluation to a prescribed accuracy; and tangent vector or derivative evaluation where defined. It should be possible to split a parameter interval, commonly at its midpoint, into equivalent restricted curve definitions while retaining all neighboring controls needed by the refinement rule.
For geometric algorithms, request a certified bounding volume for each restricted curve, such as a convex hull or an axis-aligned bounding box, and the minimum and maximum of a plane's linear function over that bound. Request also a certified flatness bound: the maximum distance of the restricted limit curve from its endpoint chord, together with its spatial extent. These allow safe rejection, adaptive drawing and accuracy control. A positive, constant-reproducing subdivision mask often makes a control-point convex hull a valid bound. With negative mask coefficients this must be proved separately or replaced by a padded bound; it cannot simply be assumed.
Further useful enquiries include roots of a scalar function along the curve, closest-point searches, arc length, and inversion of an arc-length parametrization. They can be implemented through evaluation, differentiation, certified bounds and recursive subdivision. Evaluation, restriction, enclosure and error bounds are the essential primitives needed for reliable clipping and rendering; an unqualified control-polygon approximation is insufficient.
Past exam of the mathematics course of the University of Cambridge 2008 ib Paper 4 12G i Solution Created 2026-09-24 Updated 2026-10-14
The coordinate curves are assumed to be geodesics as geometric curves; use their arc-length parametrization in the geodesic equations. On , choose increasing arc length , so and . The transverse equation becomesThus . On , similarly , , and the transverse equation gives . Hence the geodesic coordinate grid identities are
Past exam of the mathematics course of the University of Cambridge 2017 ia Paper 3 11B a Solution Created 2026-09-24 Updated 2026-10-05
For an arc-length parametrization, the unit tangent vector is , with . Its derivative is perpendicular to . The curvature of a space curve is ; where , its principal normal vector is , so . The binormal vector completes the positively oriented Frenet frame.
Differentiate to get . AlsoThus has only an component. Define the torsion of a space curve by , giving .
Next, , and differentiating the other inner products gives and . Hence the Frenet-Serret formulas areThese statements require enough smoothness, for example a curve with positive curvature on the interval under discussion. If , the unit tangent vector is still defined, but the standard principal normal vector, binormal vector and torsion of a space curve need not be; their existence cannot be inferred just from smoothness of the curve.
Past exam of the mathematics course of the University of Cambridge 2018 ii Paper 2 25I a Solution Created 2026-09-24 Updated 2026-10-03
Fix and defineBecause is a regular curve, . The inverse function theorem gives a smooth inverse onto the corresponding interval. For ,Thus the arc-length parametrization exists.
Past exam of the mathematics course of the University of Cambridge 2020 ii Paper 2 25I c Solution Created 2026-09-24 Updated 2026-10-14
For , the closed curveis embedded on a torus and satisfiesAfter arc-length parametrization, it meets all the requirements of part (b). Its bending and twisting vary around the two waves, so neither curvature nor torsion is constant.
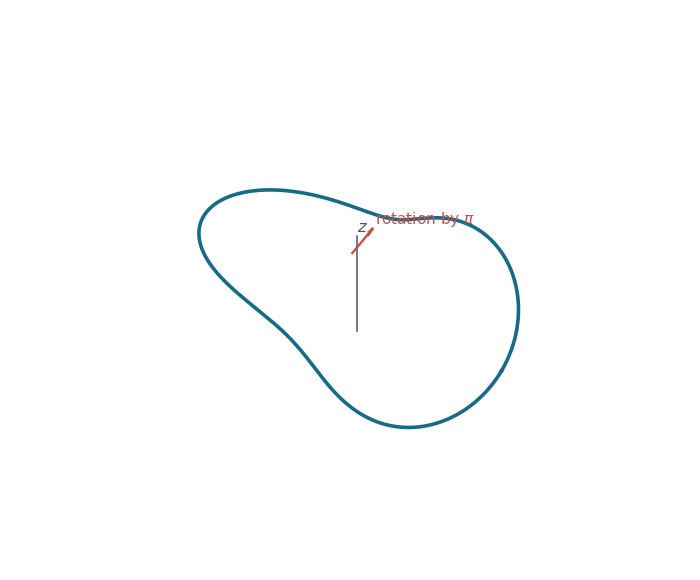
A symmetric closed curve and its reflections
. Details. 
Past exam of the mathematics course of the University of Cambridge 2024 ia Paper 3 4B Solution Created 2026-09-23 Updated 2026-09-25
For a regular curve, the curvature and torsion definition givesIt measures the rate at which the unit tangent turns per unit arclength.
HereThus , , and . HenceThe arc-length parametrization from is , so the curvature remains the constant for . Therefore the total curvature is
The curve is a unit circle traversed once. Its curvature is one and its length is , so without further calculationThe helical curve devotes part of its unit tangent to the constant vertical direction. Its tangent therefore turns more slowly on the unit sphere than the tangent to the planar circle, which explains the smaller total curvature.
Past exam of the mathematics course of the University of Cambridge 2025 ii Paper 2 26I a Solution Created 2026-09-24 Updated 2026-09-25
Fix and defineRegularity gives , so is strictly increasing and has a smooth inverse on its image. The reparametrized curve satisfiesThus every regular curve has an arc-length parametrization.
For a unit-speed curve with nonzero curvature, letIts torsion isequivalentlyIf the curve lies in an affine plane, all three derivative vectors lie in the parallel two-dimensional vector plane, so their determinant is zero. Hence wherever torsion is defined.
Length functional. On the unit sphere, write the position vector in spherical coordinates asIts two coordinate tangent vectors satisfy , and . Consequently the induced Riemannian metric is . On a segment for which increases and ,Segments where is not monotone require another parameter or a subdivision. Endpoint turning points can be handled by a limit.
First integral. With , there is no explicit dependence. The Euler-Lagrange equation therefore says thatis constant. For , put and solve:The radicand must be nonnegative along the chosen segment. The printed expression with both limits fixed at describes a longitude difference between endpoints; a formula for needs the variable upper limit and the additive constant shown here. The case gives a meridian with constant longitude. The equator is also a stationary route, although it cannot be parameterized using changing .
Integration and geometric meaning. Put , so andFor a nonconstant segment , and writing , the integral becomesRearranging, and absorbing phase and sign into two constants, givesMultiplying by shows that the corresponding Cartesian coordinates satisfy . Thus every such stationary route lies in a plane through the sphere's center: it is a great circle, the geodesic of the sphere. The meridians and equator are the limiting or separately parameterized cases of the same description.
Rome to Singapore. Use exactly the approximate coordinates supplied in the question: at departure and at arrival. Inserting them into the preceding relation determinesIndeed the right side is one at Rome and zero at Singapore. This corresponds to , . In latitude , the route is : it starts at north with an initially eastward heading and then curves southward to the equator. The first-integral expression in has an integrable endpoint singularity at departure, where has a turning point; the longitude parameter is regular there.
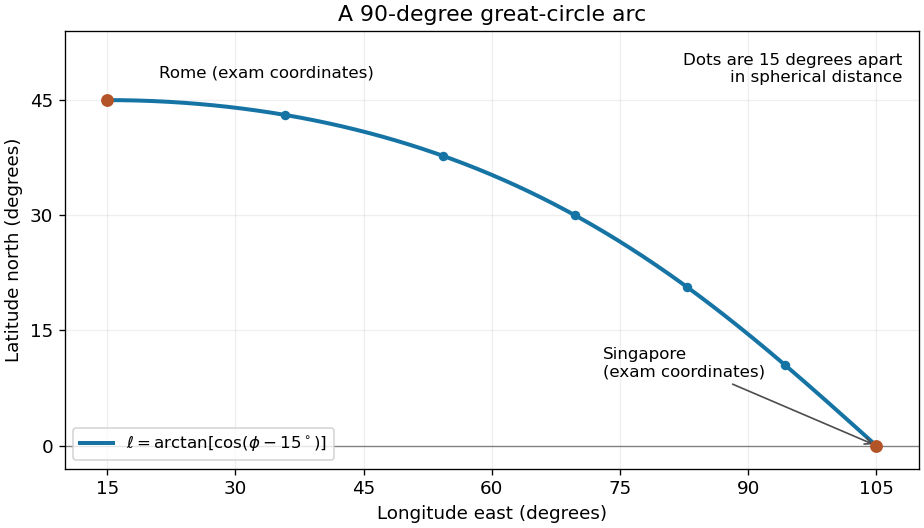
Shortest spherical route for the approximate Rome and Singapore coordinates in the question
. Latitude versus longitude for the derived great circle, with endpoints at 45 degrees north and 15 degrees east, and zero degrees north and 105 degrees east. The quarter-circle parameter increases uniformly in spherical distance. Details.
For an explicit regular arc-length parametrization, let and . Their dot product is . HenceBoth and equal one. The shorter great circle arc is the global shortest path: for any unit-speed curve from , its central angle satisfies by the Cauchy-Schwarz inequality, since the tangential projection of has length . Integrating gives length at least the endpoint angle , which this route attains. For a sphere of radius , the corresponding shortest distance is .