A geodesic is a curve whose tangent vector is parallel along itself under the Levi-Civita connection. With an affine parameter it has zero covariant acceleration:This is the Riemannian manifold version of moving straight ahead with constant speed. Its coordinate form is the geodesic equation. In Euclidean space it becomes , giving straight lines. On an embedded surface with its induced metric, the ordinary acceleration of such a curve is normal to the surface: all acceleration is used to follow the surface, rather than to turn within it.
On a unit round sphere, the great circle has , which is normal to the sphere. Two points at and can be joined along that circle by the short arc of length or the long arc of length . Each admits a constant-speed geodesic parametrization, yet only the short arc realizes their great-circle distance.
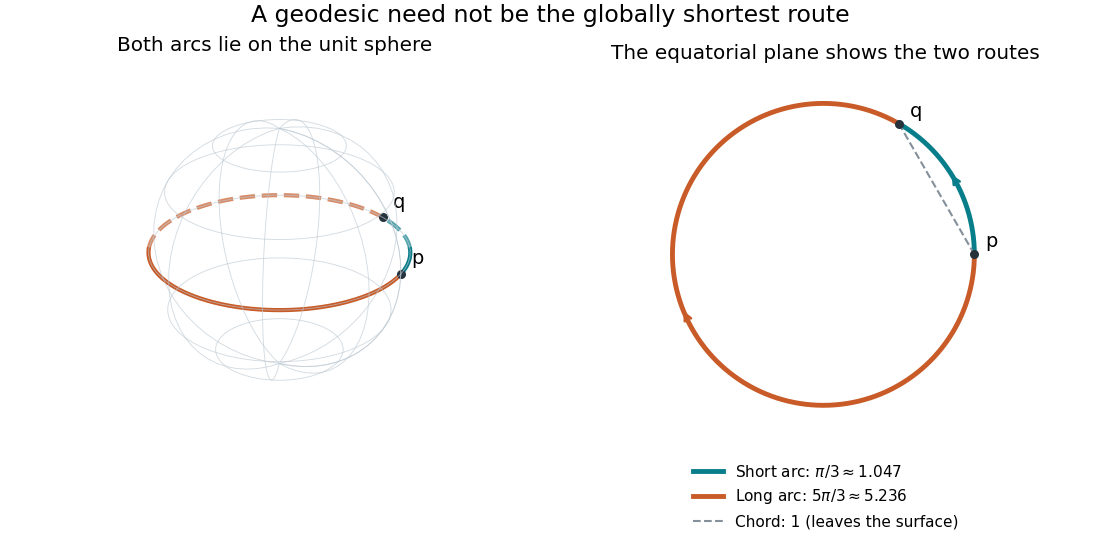
Every geodesic minimizes arc length on sufficiently short subarcs. A long segment can cease to be globally minimizing, as the sphere example shows; the first loss from a starting point is described by the cut locus. Thus “locally straight” and “shortest route between these endpoints” are distinct assertions. On a circular cylinder, different winding gives the same distinction, made explicit by Riemannian distance on a circular cylinder.
This provides a useful division of work. The geodesic equation predicts a path from an initial point and tangent vector; comparing arc lengths decides which candidate solves a global shortest-route problem. Variations of energy of a curve give the equation as an Euler-Lagrange equation, offering a proof outline and a connection with classical mechanics. [ref]
https://www.math.ucla.edu/~petersen/RG.pdf. Peter Petersen, Riemannian Geometry, chapter 5: geodesics, distance and first variation
.Suppose reflection in a plane is an isometry of a smooth surface, and its intersection with the plane is a regular curve. That curve is a geodesic when parametrized by arclength. At any intersection point, reflection fixes both the point and every tangent vector to the intersection. It carries the geodesic with these initial data to one with the same data. Local uniqueness of the geodesic equations forces it to remain in the fixed plane. This is the one-dimensional instance of fixed-point sets of Riemannian isometries being totally geodesic.
Two points along a geodesic are conjugate when a nonzero Jacobi field along it vanishes at both points. This detects singularity of the geodesic exponential map and governs loss of local length minimization.
The velocity of a geodesic can be extended to one smooth ambient vector field on a sufficiently short neighbourhood of any parameter value. If its initial velocity is zero, uniqueness of the geodesic equation makes it locally constant, and the zero field works. Otherwise one coordinate has nonzero velocity; the inverse function theorem supplies coordinates straightening the small embedded arc to . The coordinate field is the required extension. Shrinking the interval is essential: arbitrary fields along self-intersecting curves need not have one ambient extension.
For a surface metric with , an affinely parametrized geodesic has constant energy . Put . The Euler-Lagrange equations give . Thus has derivative zero, proving the displayed additional quadratic integral. This separation structure is a geometric example of Liouville integrability.
A spacelike geodesic has positive tangent norm in signature and satisfies the geodesic equation with an affine parameter. Metric compatibility preserves that norm along the curve. In Minkowski spacetime these are straight lines whose spatial tangent is larger in magnitude than the time component; their two ends approach spacelike infinity in a conformal completion.
A nonconstant geodesic whose position and tangent velocity repeat after a positive time. On a flat torus it is a straight line modulo the lattice, closing when its displacement is a Euclidean lattice vector. A primitive closed geodesic traverses its image without being an iterate of a shorter periodic geodesic.
A primitive closed geodesic is a closed geodesic with its smallest positive period, rather than a repeated traversal of a shorter periodic geodesic. A degree- lift of a primitive base geodesic is still primitive upstairs when its monodromy permutation has a cycle of exact length : no smaller number of traversals returns to the starting sheet.
A surface homeomorphic to a cylinder with strictly negative Gaussian curvature has at most one closed geodesic image. Geodesic disks, monogons and bigons are excluded by Gauss-Bonnet theorem; distinct essential simple geodesics would bound an annulus whose curvature integral must vanish. Repeated traversals count as the same image.
A pregeodesic is a curve whose tangent obeys for some scalar . A change of parameter makes it a geodesic with an affine parameter. A varying speed along a geodesic changes its parameter, not its image.
A null pregeodesic has a null tangent and can be parametrized as a null geodesic. In a two-dimensional Lorentzian metric, the acceleration of a regular null curve is orthogonal to its tangent and therefore proportional to it.
A subset of a Riemannian manifold is geodesically convex when any two of its points can be joined by a minimizing geodesic segment lying in the subset. In the hyperbolic plane the joining geodesic segment is unique. Thus in the Beltrami-Klein model, geodesically convex subsets correspond to Euclidean convex sets.
A geodesic segment is the restriction of a geodesic to a compact parameter interval. In the hyperbolic plane, two points determine a unique geodesic segment, which minimizes the hyperbolic distance between them.
On the unit sphere with one point deleted, a distinct nonantipodal pair has a length minimizer exactly when its shorter great circle arc avoids the deleted point. Antipodal pairs admit an avoiding semicircle. If the unique shorter arc crosses the puncture, smooth detours approach its length without attaining it.
A geodesic variation of a given geodesic is a smooth family with , whose curves at fixed are affinely parametrized geodesics. Differentiating its geodesic equation and using the torsion-free Levi-Civita connection gives the Jacobi field equation for .
For a geodesic variation , the deviation vector describes infinitesimal separation at equal parameter values. With , commuting parameter derivatives give . A torsion-free connection then gives . For an affinely parametrized variation, geodesic deviation states with the convention .
Given a Jacobi field with initial values and , vary the initial point along a curve with tangent and the initial velocity with covariant derivative . The resulting geodesic variation has the same Jacobi initial values and therefore the same field by uniqueness of the linear equation. Smooth dependence on initial conditions gives a common parameter interval around any fixed compact geodesic segment, even on an incomplete manifold.
A geodesic triangle is bounded by three geodesic segments. On a surface its angle excess is the integral of the Gaussian curvature over the triangle.
It is the three-sided instance of a geodesic polygon.
For a tangent vector field along a curve on an embedded surface, the surface covariant derivative is the tangential projection of its ordinary derivative:It is the covariant derivative induced by the surface metric.
The orthogonal projector onto the tangent plane of a surface with unit normal vector . It removes the normal component of a vector and defines the surface gradient .
On a sphere of radius , , , and . For a constant vector , . These identities simplify dipolar surface diffusion and interfacial transport.
For an embedded surface with unit normal vector , the surface gradient is . It projects the ambient gradient onto the tangent space and is independent of how is extended normally off the surface.
Let be the tangential surface gradient on a sphere of radius . For smooth scalar fields, set . Its radial curl detects only :To prove this, use the radial curl formula . The radial component never enters it. The terms cancel as by symmetry of second derivatives, while the terms give the unit-sphere Laplace-Beltrami operator. Taking the dot product with the position vector gives the displayed version. This tangential gradient decomposition does not assert that the whole vector field is solenoidal.
On the graph of a function , assume is differentiable, its planar gradient is nonzero, and speed is measured by the three-dimensional Euclidean norm. The upward unit normal vector is . Projecting the downward vertical vector onto the tangent plane gives . By the Cauchy-Schwarz inequality, normalizing this projected vector produces the tangent direction with greatest height decrease at the prescribed speed, giving the displayed velocity. Its vertical component is , and its horizontal direction is parallel to . Consequently its planar paths agree with negative gradient flow up to a change of time, although the speeds differ. Where , every tangent direction has zero first-order height change and this normalized formula is undefined.
The surface divergence of an ambient vector field is the tangential trace . For a tangent vector field it is the intrinsic divergence. For it gives the sum of the two principal curvatures; a sphere with outward normal has .
For a smooth tangent vector field on a compact orientable surface with smooth boundary and outward conormal of a surface boundary, the integral of its surface divergence is its boundary flux. Extend the unit normal vector to a unit field . The curl of a cross product gives on the surface: there and by unit length. Apply Stokes theorem and use to obtain the formula.
For in a Riemannian manifold and sufficiently close to zero in , let be the geodesic with and . The exponential map isEquivalently, wherever both sides are defined.
For the Riemannian exponential map , uniqueness of the geodesic equation gives . Differentiation at yields . Smooth ODE dependence and the inverse function theorem therefore make a diffeomorphism on a neighborhood of zero, producing geodesic normal coordinates. This is a local assertion and requires no geodesic completeness.
A convex normal neighbourhood is an open set whose points have unique smoothly varying joining geodesics, with the joining geodesic contained in the set. The corresponding star-shaped restriction of each exponential map is a diffeomorphism onto the neighbourhood. Hence its differential is invertible and no such joining geodesic admits a nonzero Jacobi field vanishing at both endpoints. Every point of a Riemannian manifold has arbitrarily small such neighbourhoods. This is stronger than merely requiring the existence of a minimizing geodesic in the set.
The geodesic flow sends a tangent vector to the velocity at time of the unique geodesic with initial velocity . Smooth dependence of solutions of the geodesic equation makes it a smooth flow on the tangent bundle wherever defined.
A perpendicular Jacobi field on a Riemannian surface has scalar equation . For strictly negative curvature on a closed manifold, the displayed derivative is uniformly positive definite, so the quadratic-form criterion for an Anosov flow makes the geodesic flow Anosov. When , the stable and unstable lines in the canonical frame are respectively and , with factors and .
A smooth real function on the unit tangent bundle determines this unit-speed smooth flow. Its base velocity is , so its generator never vanishes. In the canonical frame its divergence in Liouville volume of a surface geodesic flow is . The special case where depends only on the base is a magnetic flow; when it is a Gaussian thermostat.
Write a tangent variation of a surface thermostat as in the canonical frame. The commutators and give and the stated transverse equation. Near the vertical projective direction, obeys .
At unit speed on a Riemannian surface, the right-hand side is . This removes the velocity-parallel component of the forcing, so differentiating gives zero. The dynamics need not preserve the ordinary Liouville volume of a surface geodesic flow.
For , the canonical fields preserve Liouville volume of a surface geodesic flow, so the divergence is . For a Gaussian thermostat, and , giving the stated sign. If , then the density makes this divergence zero.
A unit-speed curve with defines the magnetic flow. The vertical term rotates the velocity while the horizontal part transports it along the base. Since , the divergence of in Liouville volume vanishes. The associated two-form on the unit tangent bundle is , whose kernel is the magnetic flow direction.
On a connected closed oriented surface, a magnetic Anosov flow with preserves a smooth contact form only when . To see the obstruction, take and . An invariant contact form can be normalized to evaluate to one on ; its differential is a constant multiple of , since smooth invariant functions are constant. Averaging closed one-forms forces that multiple to be , so the contact form differs from by a closed form. Its fibre-average decomposition gives . The degree-zero/one kernel theorem gives and , forcing whether vanishes or not. For , the canonical form is invariant and contact.
The metric defines this globally smooth Hamiltonian on the cotangent bundle. With and , its Hamiltonian vector field projects to affinely parametrized geodesics. The momentum is , and its conserved value is half the squared speed.
The domain of is the star-shaped open setSmooth dependence for ordinary differential equations makes smooth on its open domain in .
For and , geodesics are straight lines until they hit the missing origin. Thus , and is not in the image of because its unique straight segment from passes through the origin.
A normal neighbourhood of is the diffeomorphic image under of a star-shaped neighbourhood of in . In a sufficiently small normal ball, radial geodesics from uniquely minimize length.
In a normal neighbourhood with star-shaped, define . Away from , the Gauss lemma gives for . Thus and this unit vector field is tangent to unit-speed radial geodesics. The function is not smooth at , but is smooth and extends by zero. On a sufficiently small normal ball, equals the Riemannian distance from .
// Target: riemannian-geometry.bigb
The unit radial vector field is on the punctured normal neighbourhood, where is the radial distance in a normal neighbourhood. Along with , it satisfies . The scaled radial field is smooth at the centre and vanishes there. These conventions have different associated radial functions.
// Target: riemannian-geometry.bigb
The injectivity radius at is the largest radius on which is a diffeomorphism from the tangent-space ball onto its image. The injectivity radius of a compact Riemannian manifold is the positive infimum of these pointwise radii.
Choose an orthonormal basis of and use its linear coordinates on a neighborhood of zero on which is a diffeomorphism. Transporting these coordinates through gives geodesic normal coordinates centered at .
In geodesic normal coordinates at , radial geodesics have coordinates . The geodesic equation at gives for every . The Levi-Civita connection is torsion free, making these coefficients symmetric in ; the polarization identity then gives . This does not imply vanishing curvature, which depends on derivatives of the coefficients.
A geodesic sphere is a level set of Riemannian distance from a point. For sufficiently small positive , it is the exponential map image of the radius- tangent sphere, a smooth compact hypersurface. The Gauss lemma makes its tangent space orthogonal to the radial direction. Larger distance spheres need not be smooth at the cut locus.
A chart centered at on a star-shaped coordinate domain is a geodesic normal chart exactly when andfor every and . This is the geodesic equation for every radial curve .
Choose an orthonormal basis of and put . Away from the centre and cut locus,defines geodesic polar coordinates centred at .
Before the cut locus, define on the tangent space of a distance sphere. This is the negative of the shape operator with outward normal under the convention . A nonsingular matrix of radial Jacobi fields satisfies and , yielding the displayed matrix Riccati equation. Taking its trace gives , where . This is the local differential identity behind the Bishop-Gromov inequality.
For smaller than the normal-coordinate radius, the geodesic circle on a Riemannian surface consists of points at distance from . The exponential map restricted to the radius- circle in gives its smooth embedded parameterization. Outside the injectivity range a distance sphere need not be smooth.
Fix on a Riemannian surface. For sufficiently small , the geodesic circles of radius centered at and at every sufficiently nearby distinct meet transversally at exactly two points. In a strongly convex normal neighbourhood, write and . First variation givesThe quotient of the bracketed function by extends smoothly and has two simple zeros at zero. The implicit function theorem, uniformly over unit , preserves these two zeros and excludes others. The nonzero angular derivatives prove transversality. The distinct-centre hypothesis is essential: coincident circles are not transverse.
The radial direction is orthogonal to the angular directions under the exponential map. On a surface this makes the first fundamental form in geodesic polar coordinateswith as .
If , , , , and for , thenSubtract a smaller multiple of the sine solution and use the monotonicity of its Wronskian with .
A geodesic is maximal when it has no geodesic extension to a strictly larger interval. Every initial position and velocity determine a unique maximal geodesic through the geodesic equation.
An extendible geodesic is a geodesic segment that can be continued beyond at least one endpoint within the same manifold after retaining an affine parameter. An artificial truncation at a regular event is extendible even when its continuation eventually reaches a singularity.
A Riemannian manifold is geodesically complete when every maximal geodesic is defined for every real affine parameter, equivalently when every exponential map is defined on its entire tangent space.
Pointwise domination of Riemannian metrics gives domination of their distances. A Cauchy sequence for the larger distance is Cauchy for the complete smaller one. Smooth positive metrics induce the same manifold topology, so its limit is also a limit in the larger distance. The Hopf-Rinow theorem turns metric completeness into geodesic completeness. Mere positivity of the second metric, without domination, is insufficient.
Suppose these sets exhaust a manifold, and its Riemannian metric is Euclidean beyond some radius in the end coordinates. A finite-time geodesic has fixed speed and cannot increase its exterior radius faster than that speed. It remains in one compact core enlargement, with velocity in a compact disk bundle. The geodesic equation therefore continues beyond every finite parameter endpoint. The compactness hypothesis is substantive: the open exterior of a closed Euclidean ball, with empty core, is incomplete at its inner boundary despite having a Euclidean metric at infinity.
A Riemannian manifold is geodesically incomplete when some maximal geodesic has a finite endpoint in its affine-parameter interval.
Let be a smooth surface. Suppose its Gaussian curvature tends to infinity in absolute value along every maximal geodesic with a finite affine-parameter endpoint. Then is an inextendible embedded surface: a smooth extension would let some geodesic reach the extension boundary in finite time while its curvature remained locally bounded.
The surface of revolutionis geodesically incomplete: a meridian reaches the missing origin in finite length. Its Gaussian curvature, computed using the curvatures of a parametrized surface of revolution, iswhich tends to infinity as . Every finite-time endpoint of a constant-speed geodesic must approach the origin, the only finite point in the ambient closure missing from , so this surface satisfies the curvature-blowup criterion.
For a connected finite-dimensional Riemannian manifold, completeness of the Riemannian distance, geodesic completeness, and compactness of every closed bounded subset are equivalent. These conditions imply that any two points are joined by a minimizing geodesic. Pairwise existence of minimizing geodesics alone does not imply completeness: an open Euclidean ball is incomplete, yet the line segment between any two of its points stays in the ball and minimizes length.
If the Riemannian exponential map at one point of a connected finite-dimensional Riemannian manifold is defined on all of , every point can be joined to by a minimizing geodesic. The distance splitting through a small geodesic sphere selects a radial direction attaining . If this equality stopped before the target, repeat the splitting at its last point. A broken minimizing path cannot have a corner, so the new segment continues the same geodesic, contradicting maximality. This is the minimizing-geodesic lemma used in the radial continuation proof of Hopf-Rinow.
// Target: riemannian-geometry.bigb
Assume geodesic completeness. Minimize the distance to a target over a small compact geodesic sphere about the initial point. The distance splitting through a small geodesic sphere gives an initial direction satisfying . If this equality stops before the target, repeat the splitting at the last equality point. The resulting broken path minimizes, so its corner must smooth into the same continuing geodesic, a contradiction. This supplies a minimizing geodesic to every target. Every closed metric ball is then the image under the Riemannian exponential map of a closed tangent ball, hence compact. A Cauchy sequence has a convergent subsequence in such a ball and therefore converges, proving metric completeness without presupposing a global minimizing curve.
This is a globally minimizing geodesic, a Riemannian specialization of the general geometric line notion.
A connected noncompact manifold is disconnected at infinity when the complement of some compact subset has at least two unbounded connected components. Equivalently, it has at least two ends.
The relevant general concept is an End; having several ends is a property of the space, not a synonym for one end.
A connected complete Riemannian manifold that is disconnected at infinity contains a line in a Riemannian manifold. Choose points escaping in two components outside a fixed compact set and join them by minimizing geodesics. Each segment crosses the compact set. Parametrize from a crossing point; both parameter endpoints tend to infinity in opposite directions. Compactness of the unit tangent vectors over the crossing set gives a subsequence converging to an entire geodesic. Every finite subsegment is minimizing by continuity of distance, so the limit is a line.
If two embedded surfaces are tangent along a curve, their tangent planes agree there. The curve's ambient acceleration is normal to one surface exactly when it is normal to the other, so it is a geodesic of one exactly when it is a geodesic of the other.
A circular helix on a circular cylinder has radial ambient acceleration and is therefore a geodesic. Any surface tangent to the cylinder along that helix has the same curve as a geodesic.
Articles by others on the same topic


A geodesic is the shortest path between two points on a curved surface or in a curved space. In mathematics and physics, this concept is often applied in differential geometry and general relativity. - **In Geometry**: On a sphere, for example, geodesics are represented by great circles (like the equator or the lines of longitude).