A tangent vector at a point of a smooth manifold without boundary records an instantaneous velocity through . Its base point is part of the data; measuring its length additionally requires a Riemannian metric. Intrinsically, a smooth curve with defines its tangent vector by how every local smooth function changes along it:This is a derivation at a point. Two smooth curves through represent the same tangent vector if these derivatives agree for every such smooth function; equivalently, their coordinate velocity vectors agree in one manifold chart. The chain rule makes that agreement independent of the chosen manifold chart. [ref]
For an embedded submanifold of Euclidean space, the intrinsic tangent vector is represented by the ordinary derivative , with its base point retained. A drawn arrow starting at represents that tangent vector; its endpoint need not lie on the embedded submanifold. Nor is a tangent vector required to be a unit tangent vector: a stationary smooth curve gives the zero vector, which belongs to the tangent space but has no direction to normalize.
Here are explicit calculations. In , and have different routes but the same tangent vector at . For , both give . For a circle of radius , has tangent vector at : changing changes the speed or reverses travel without changing the circle.
A reparametrization with gives, by the chain rule, . A regular change of curve parameter has . The singular choice instead givesBoth describe the same parabola, whose tangent line at the origin is still the horizontal axis. The zero velocity diagnoses this singular change of curve parameter, whose inverse is not differentiable at zero; it does not show that the geometric tangent line is absent. The regular curve supplies its nonzero direction.
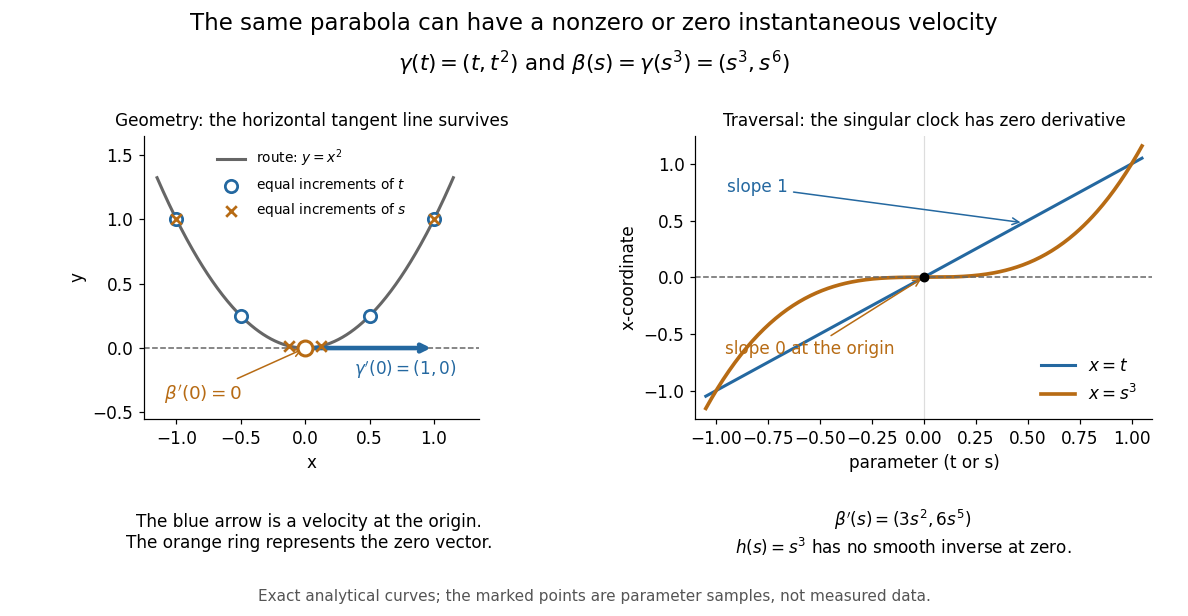
The diagram is an analytical illustration of these exact parametric curves, with equal parameter increments marked on each route. It separates geometry from traversal: the tangent line depends on the route, while a velocity vector also depends on how the curve parameter advances.
At on a smooth manifold, a derivation at that point is a real-linear map on germs of smooth functions with . It defines a tangent vector. The local factorization gives , so the coordinate derivations form a basis of the tangent space.
At a fixed point of an -dimensional smooth manifold without boundary, the tangent space is the real vector space of all tangent vectors at . In manifold charts and , a tangent vector has componentsThe coordinate basis transforms inversely, so the tangent vector is unchanged. This invertible Jacobian matrix also preserves vector addition and scalar multiplication, giving a vector space of dimension independently of coordinates. [ref]
https://www.math.toronto.edu/mein/teaching/LectureNotes/Man.pdf. Eckhard Meinrenken, Differentiable Manifolds, §1.5: tangent spaces and coordinate bases
For example, at in , use the alternative manifold chart , . The Jacobian matrix sends to . Indeed, the smooth curve gives . Conversely, and , so . The numbers change; their action on every smooth function does not.
For an embedded submanifold , the tangent space can be identified with the vector subspaceA proof outline explains why every coordinate vector is possible: in a manifold chart , lift the short straight path using . Its tangent vector has components . For a regular local parametrization , the same chain rule gives , where . This is the tangent space from a local parametrization.
For the sphere , differentiating that equation gives . Conversely, for any nonzero with , the smooth curvelies on the sphere and has ; use a constant smooth curve for . Thus , not merely a subset of that plane. At this vector subspace is , while the affine tangent plane drawn through is .
This also explains a mechanical constraint without requiring a force calculation. In the ideal mathematical model of a particle confined to a stationary sphere, its allowed velocities at are exactly : the radial component must vanish, but either independent tangential direction is available. For a general stationary holonomic constraint with independent equations, the regular level set theorem gives . These are instantaneous kinematic possibilities; they do not determine the actual subsequent motion. On a general smooth manifold, tangent spaces at different base points cannot be identified canonically; an affine connection supplies parallel transport when such comparisons are needed.
If the zero set of a differentiable function is a submanifold, the chain rule always places its tangent space inside . Equality follows from the full-rank hypotheses of the regular level set theorem, but may fail for a singular defining function even when the zero set itself is smooth. For , , the zero set is the single point . Its tangent space is zero, while has kernel . One should therefore check the constraint qualification before using the kernel formula.
For an embedded regular surface and , the affine tangent plane isIt is a set of points through , whereas the tangent space is a vector space of displacements with zero vector. Some texts also call that two-dimensional tangent space the tangent plane; here the translation by distinguishes the two uses. For a regular parametric surface with ,where the partial derivatives are evaluated at . Regularity means that these tangent vectors are linearly independent, equivalently . Their cross product is a normal vector. [ref]
https://www.math.uga.edu/sites/default/files/inline-files/ShifrinDiffGeo.pdf. Theodore Shifrin, Differential Geometry: A First Course in Curves and Surfaces, Chapter 2, §1: regular parametrizations and tangent planes
For an implicit regular surface , require a smooth function with . ThenDifferentiating proves that every surface velocity lies in the displayed kernel of a linear map; the implicit function theorem gives a local graph with two independent coordinates, proving equality. The gradient is the normal vector with respect to the ambient dot product. [ref]
For the sphere , , and the affine tangent plane has equation . At the unit sphere's north pole , compare the plane with the displacement tangent space . The regular parametric surface , for , gives and , confirming the same answer.
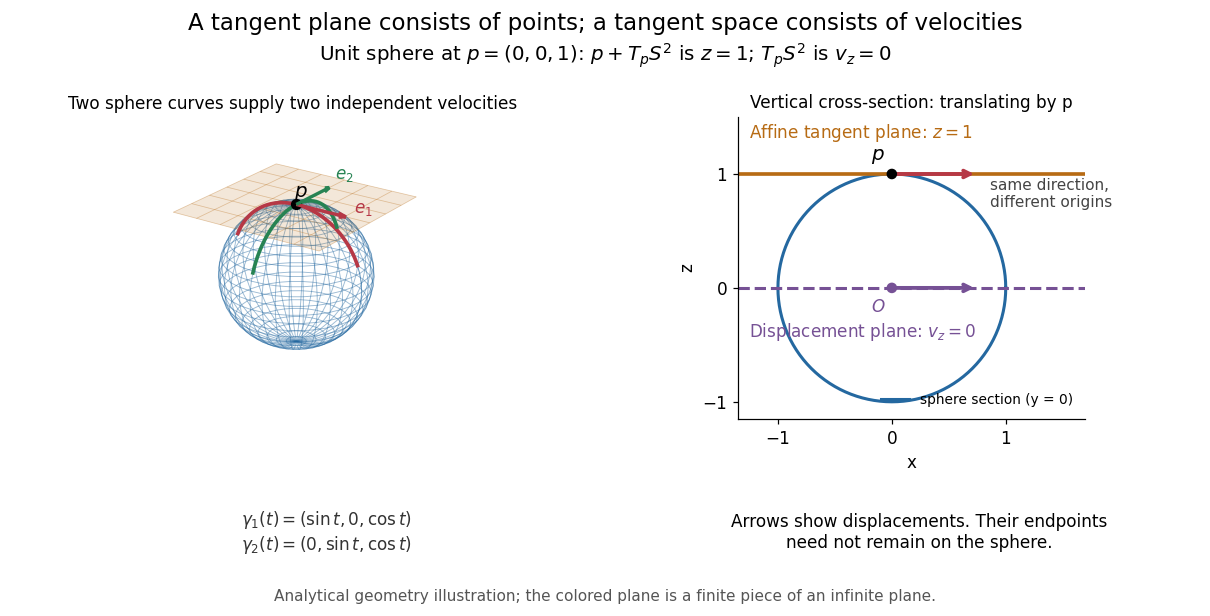
This analytical illustration shows a unit sphere and a vertical cross-section. The smooth curves and give the two displayed tangent vectors at . The straight point for any nonzero is outside the sphere when , since . A tangent plane therefore captures first-order motion, not an exact patch of the regular surface.
The same idea makes local approximation useful. For the graph of a function with a smooth function, the affine tangent plane is . [ref]
https://openstax.org/books/calculus-volume-3/pages/4-4-tangent-planes-and-linear-approximations. Gilbert Strang and Edwin Herman, OpenStax Calculus Volume 3, §4.4: tangent planes and linear approximations
With continuous second partial derivatives, the vertical error is in Big O notation. On the unit sphere near its north pole, : the tangent plane loses quadratic bending while preserving all first-order velocities.A failed regularity test needs interpretation. Replacing the sphere equation by makes everywhere on the same perfectly regular sphere, so this defining smooth function cannot recover its tangent plane. Similarly, the usual spherical parametric surface loses matrix rank at the poles, while the graph parametrization above remains regular there. A vanishing gradient or degenerate parametrization invalidates that calculation; it alone does not prove that the underlying geometry has no tangent plane.
For a level set , the tangent plane formula requires both that belongs to the surface and that its gradient is nonzero. Evaluating the gradient at an off-surface point instead gives a plane tangent to the level set through that different point. For example has , so the gradient plane there cannot be a tangent plane to . Holding the first two coordinates fixed gives the on-surface point and its plane .
A tangent vector is a linear map on germs of smooth functions satisfying . In a manifold chart, first-order expansion shows . Thus the coordinate derivations form a basis, and the dimension equals the manifold dimension. Composition of germs with a smooth map defines its differential of a smooth map without choosing charts.
The cotangent space at is the dual vector space . Its elements are covectors on the tangent space. In a manifold chart , the basis is dual to . Under a coordinate change to , the coefficients of obey . The disjoint union of these spaces is the cotangent bundle.
A Riemannian metric induces a dual inner product on each cotangent space. On decomposable covectors define and extend bilinearly. Increasing wedges of an orthonormal coframe form an orthonormal basis. This positive-definite inner product is the one used to define the Hodge star operator.
If is a local parametrization with , thenThe derivative has rank , so this is a -dimensional vector subspace. A change of parametrization composes with an invertible coordinate-change derivative, leaving its image unchanged.
For an embedded smooth manifold , if , , and , then . In a local graph representation , write and use continuity of .
A manifold chart with coordinates induces a smooth local frame of the tangent bundle, with tangent vectors forming a basis of each tangent space. Their Lie brackets of vector fields vanish because mixed partial derivatives of smooth functions commute. Under a change of coordinates they transform by the chain rule: , with coefficients given by the Jacobian matrix.
For a regular curve with nonzero velocity vector, its unit tangent vector isThe Euclidean norm in the denominator removes the traversal speed, leaving a unit vector that records direction. A positive change of traversal speed leaves this direction unchanged; reversing the direction of travel reverses . In arc length coordinates, .
For the parabola , the velocity vector is and the speed is . At , . The tangent vector and the unit tangent vector point in the same direction, but only the latter has Euclidean norm one. The principal normal vector is a further choice based on how this direction changes, where the curvature is nonzero. [ref]
Articles by others on the same topic



A tangent vector is a mathematical concept from differential geometry and calculus that describes a vector that is tangent to a curve or surface at a certain point. Here are some key points about tangent vectors: 1. **Geometric Interpretation**: At any given point on a curve in a multidimensional space, the tangent vector represents the direction in which the curve is moving at that point.