The gear mesh tangent stiffness is the local derivative of total mesh force with respect to a specified relative approach, with contact position and other state variables held fixed:It predicts a sufficiently small incremental force . Unlike a reference-based secant stiffness , it describes the local response rather than the whole loading interval.
For away from any gear tooth engagement threshold,Only members of the gear mesh active-contact set contribute. With , and gaps and , the gear mesh tangent stiffness is before the second contact and after it. At approach , an additional gives more force within the same branch.
The ideal transition at has distinct left and right derivatives. A centered finite difference with any sufficiently small positive giveswhere numerical displacements are expressed in micrometres. The value is the mean of the two branch slopes; it does not establish a unique derivative at the corner, even as shrinks.
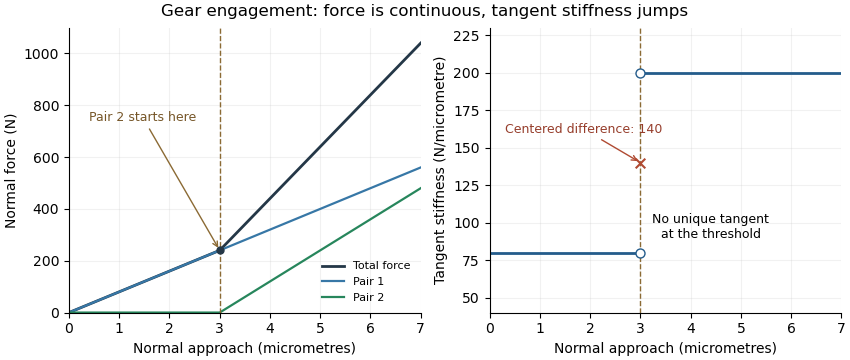
Original unilateral-contact model: continuous force, a gear tooth engagement threshold, and distinct one-sided gear mesh tangent stiffness values
. Details. 
The measured displacement channel also matters. If a contact stiffness is in series with support stiffness , their mechanical compliances add, givingA measurement spanning the whole assembly would therefore not isolate the contact stiffness.
For a perturbation experiment, report the mean load, mesh position, displacement endpoints and whether the increment crosses a contact transition. A primary NASA analysis used a coupled tooth-stiffness/dynamic-load calculation; the derivative above explains a local quasistatic limit, rather than replacing that dynamical model.[ref]
Articles by others on the same topic
There are currently no matching articles.