Gear tooth load sharing is the division of transmitted mesh load among simultaneously contacting tooth pairs. Gear contact ratio determines how engagement intervals overlap, but it does not by itself specify each pair's force. Tooth and support deformation, profile geometry and operating speed affect that distribution. A primary dynamic analysis explicitly coupled tooth stiffness with calculated dynamic loads rather than assigning a fixed full load to every active pair.[ref]
An illuminating quasistatic model treats active pairs as parallel springs with a common normal approach . With pair stiffnesses and no gaps, , soThe stiffness sum is gear mesh stiffness, and is a gear tooth load fraction. If two active pairs have stiffness100 and150N/µm under total normal load1000N, their common approach is4µm and loads are400 and600N. Equal sharing requires equal effective stiffness in this particular model.
Include a geometric gap by writing . If the second pair has a2µm gap, the same1000N total load gives with measured in micrometres. The result is , and . At only100N, the first pair alone compresses1µm, leaving the second pair out of contact.
For an ideal spur gear mesh with transverse contact ratio between1 and2, the fraction of a tooth-entry cycle having two pairs in contact is . A ratio1.635 therefore gives about63.5% two-pair contact and36.5% single-pair contact. This is geometric timing, not a guarantee of equal forces in the overlapping part. A gear friction work per engagement calculation must use each pair's own load history; dynamic motion can require more than the quasistatic spring approximation.
The gear tooth load fraction is the fraction of a stated total mesh force carried by tooth pair at a particular contact position or time:For nonnegative forces resolved in the same direction, and . A normal-force fraction must not mix one pair's normal load with another convention's tangential total. At zero total load the ratio is undefined.
An original quasistatic model treats engaged pairs as parallel springs with the same normal approach . If and every pair has zero initial gap, thenTwo pairs with stiffnesses and under total load approach by and carry and . Their fractions are and , rather than one half each. Counting two geometrically overlapping contacts does not establish equal gear tooth load sharing.
An initial gap changes the model toA pair below its gear tooth engagement threshold carries no load in this unilateral model. Changing total load can change both the active pairs and their fractions, even if all the individual stiffnesses remain constant. Gear contact ratio specifies geometric overlap; load fractions require deformation and engagement information.
The fractions also prevent double counting. If total load is , assigning that full load to both of two pairs gives an impossible sum of within this model. A gear friction work per engagement calculation must use each pair's own before summing its dissipation.
Dynamic motion can alter the quasistatic distribution. A 1986 NASA analysis calculated tooth stiffness and loads as contact position and speed varied, using a coupled stiffness/load iteration.[ref]
Predicted Effect of Dynamic Load on Pitting Fatigue Life for Low-Contact-Ratio Spur Gears by David G. Lewicki. Summary and Introduction, printed p. 1, stiffness model, iteration and varying contact-position loads
Fractions inferred from the simple spring model should therefore be identified as model results, rather than universal operating values.A gear tooth engagement threshold is the relative approach or total load at which a previously separated tooth pair starts carrying compressive contact force in a stated model. Geometric overlap from the gear contact ratio does not guarantee that every potentially overlapping pair already carries load. Gaps, errors and deformation affect the gear mesh active-contact set.
For an original unilateral linear-spring model, writewith , common approach and initial gap . Pair begins to carry load as rises above . The corresponding total-load threshold isThis threshold includes the forces already carried by earlier contacts. It is not generally obtained by multiplying pair 's own stiffness by its gap.
Take , , and . The second pair begins at total load . At , approach is and the second pair remains unloaded. At ,gives , forces and , and gear tooth load fractions and .
At the ideal threshold itself, the new contact contributes zero force but changes the one-sided gear mesh tangent stiffness. The force is continuous while its slope can jump. Finite contact geometry and nonlinear local Hertzian contact can smooth or alter this elementary linear-spring picture.
A controlled quasistatic test can increase total mesh load at approximately fixed contact position while measuring relative displacement and individual tooth-root strain. A change in response slope suggests a contact transition, but support motion and measurement resolution must be considered before assigning it uniquely to a tooth pair. Primary dynamic gear analysis couples tooth stiffness and calculated loads as contact position changes, underscoring that engagement cannot be inferred from tooth count alone.[ref]
The gear mesh active-contact set identifies the tooth pairs that carry positive compressive normal force in a specified contact model. It is not simply the set of geometrically overlapping teeth from the gear contact ratio. A pair touching at zero force is excluded under the positive-force convention used here.
For unilateral linear contacts,Here is the initial gap, the pair stiffness, and the common approach. For a proposed nonempty set , force balance givesA gear contact-set consistency check then verifies for included pairs and for excluded ones. Solving the linear equation without this check can retain a negative force or omit a contact that should engage.
An original three-pair example uses stiffnesses and gaps . At total load , the set gives approach and forces . This set is consistent.
At , keeping only those two contacts would give approach , beyond the third gap. Including all three instead givesand forces approximately , which sum to . The third gear tooth engagement threshold occurs at total load .
Within a fixed active set, gear mesh tangent stiffness is the sum of its pair stiffnesses. At a transition, force can remain continuous while that derivative changes. For positive total load the scalar force law is strictly increasing after the first contact, giving a unique approach in this model; the unloaded state need not specify one unique separation.
Real deformation, local contact nonlinearity and dynamics can require more than one common-approach coordinate. A primary NASA analysis coupled tooth stiffness with dynamic-load calculations over contact position and speed.[ref]
Predicted Effect of Dynamic Load on Pitting Fatigue Life for Low-Contact-Ratio Spur Gears by David G. Lewicki. Summary and Introduction, printed p. 1, stiffness–load iteration and contact-position dependence
The active-set calculation is an explicit quasistatic model, not a substitute for that fuller mechanical description.A gear contact-set consistency check verifies that a proposed solution satisfies force balance and the unilateral contact conditions used to define a gear mesh active-contact set. Solving an equation for selected contacts is insufficient if an omitted tooth should be loaded or an included tooth would require tension.
For the model , choose a trial active set and solveThe check then requires positive for included pairs and for excluded pairs. Recomputing every contact with the unilateral law gives the force residualA consistent exact solution has together with the inclusion inequalities.
An original example has stiffnesses and gaps . At , a trial set containing only the first two pairs gives . It balances those selected forces but exceeds the third gap by . The omitted contact would carry , giving . Including all three gives the consistent approach .
Conversely, including all three at applied load gives the un-clipped solution and a third force . Rejecting that tensile contact and solving with the first two gives and forces .
Numerical tolerances should keep their units and roles clear. A displacement tolerance near a gear tooth engagement threshold is not the same quantity as a force-residual tolerance. At an exact zero-force touch, either a geometric-touch flag or the positive-force active convention may be useful, but the reported convention must be stated. The one-sided gear mesh tangent stiffness can differ across that boundary.
Primary dynamic gear analysis couples tooth stiffness and calculated loads as contact position changes.[ref]
Predicted Effect of Dynamic Load on Pitting Fatigue Life for Low-Contact-Ratio Spur Gears by David G. Lewicki. Summary and Introduction, printed p. 1
The scalar check above validates internal consistency of its quasistatic model; it does not establish that the model includes every deformation or dynamic effect in a real mesh.Gear mesh stiffness describes the force response of the engaged tooth contacts to a specified relative approach along the mesh direction. In the linear parallel-contact model underlying gear tooth load sharing, all active pairs have the same approach andThe sum assumes compatible displacement coordinates. Adding a bending stiffness, a torsional stiffness and a normal contact stiffness without transforming their coordinates would be dimensionally and mechanically inconsistent.
For an original example, two zero-gap pairs with and give . A load produces normal approach. If only the first pair is engaged, the same ideal stiffness model instead gives .
With gaps or nonlinear response, specify whether the reported value is secant stiffness from a reference or the local gear mesh tangent stiffness . Supposewhere is measured in micrometres and the result in newtons. The second pair starts carrying load at , corresponding to . At , approach is , so the origin-based secant stiffness is about while tangent stiffness is . At the ideal corner itself, a unique two-sided derivative does not exist.
A small-perturbation experiment can hold contact position and mean load approximately fixed, apply a controlled force increment and measure the corresponding relative displacement. Shaft and support mechanical compliance must be separated or included explicitly in the reported system response. Rotating the mesh changes contact position, so one scalar does not necessarily describe a whole cycle.
This matters dynamically: changes in gear mesh stiffness can alter oscillatory response and gear tooth load fractions. The primary NASA analysis used an improved tooth-stiffness model coupled to dynamic-load calculations, rather than prescribing stiffness independently of the load solution.[ref]
Predicted Effect of Dynamic Load on Pitting Fatigue Life for Low-Contact-Ratio Spur Gears by David G. Lewicki. Summary, printed p. 1, modified TELSGE and stiffness–dynamic-load iteration
The elementary parallel-spring sum explains the linear limit, while real contacts require a stated engagement and deformation model.The gear mesh tangent stiffness is the local derivative of total mesh force with respect to a specified relative approach, with contact position and other state variables held fixed:It predicts a sufficiently small incremental force . Unlike a reference-based secant stiffness , it describes the local response rather than the whole loading interval.
For away from any gear tooth engagement threshold,Only members of the gear mesh active-contact set contribute. With , and gaps and , the gear mesh tangent stiffness is before the second contact and after it. At approach , an additional gives more force within the same branch.
The ideal transition at has distinct left and right derivatives. A centered finite difference with any sufficiently small positive giveswhere numerical displacements are expressed in micrometres. The value is the mean of the two branch slopes; it does not establish a unique derivative at the corner, even as shrinks.
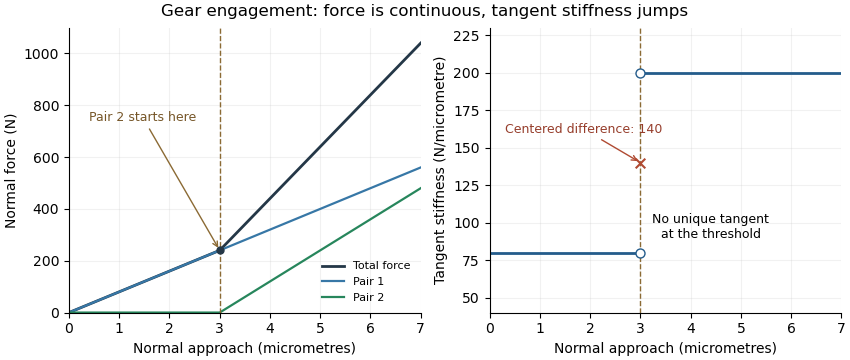
Original unilateral-contact model: continuous force, a gear tooth engagement threshold, and distinct one-sided gear mesh tangent stiffness values
. Details. 
The measured displacement channel also matters. If a contact stiffness is in series with support stiffness , their mechanical compliances add, givingA measurement spanning the whole assembly would therefore not isolate the contact stiffness.
For a perturbation experiment, report the mean load, mesh position, displacement endpoints and whether the increment crosses a contact transition. A primary NASA analysis used a coupled tooth-stiffness/dynamic-load calculation; the derivative above explains a local quasistatic limit, rather than replacing that dynamical model.[ref]
Articles by others on the same topic
There are currently no matching articles.