Merge sort is a divide-and-conquer algorithm that sorts a finite array by splitting it into contiguous halves, sorting each half using recursion, and combining the two sorted arrays with the merge algorithm. An empty or one-entry array is returned immediately. For length , put the first entries on the left and the remaining on the right; the brackets are the floor function and ceiling function. Always choose the left head on equal keys to obtain stable sorting. This is the split, sort, combine structure taught in the MIT lecture notes.[ref]
Take the concrete input arrayThe tags identify the entries originally at indices and , counting from zero. Both keys are ; the tags are never compared. Reading downward in the figure follows the splits, then the returned sorted arrays. Arrows show dependencies; the level layout groups independent calls rather than giving their chronological execution order.
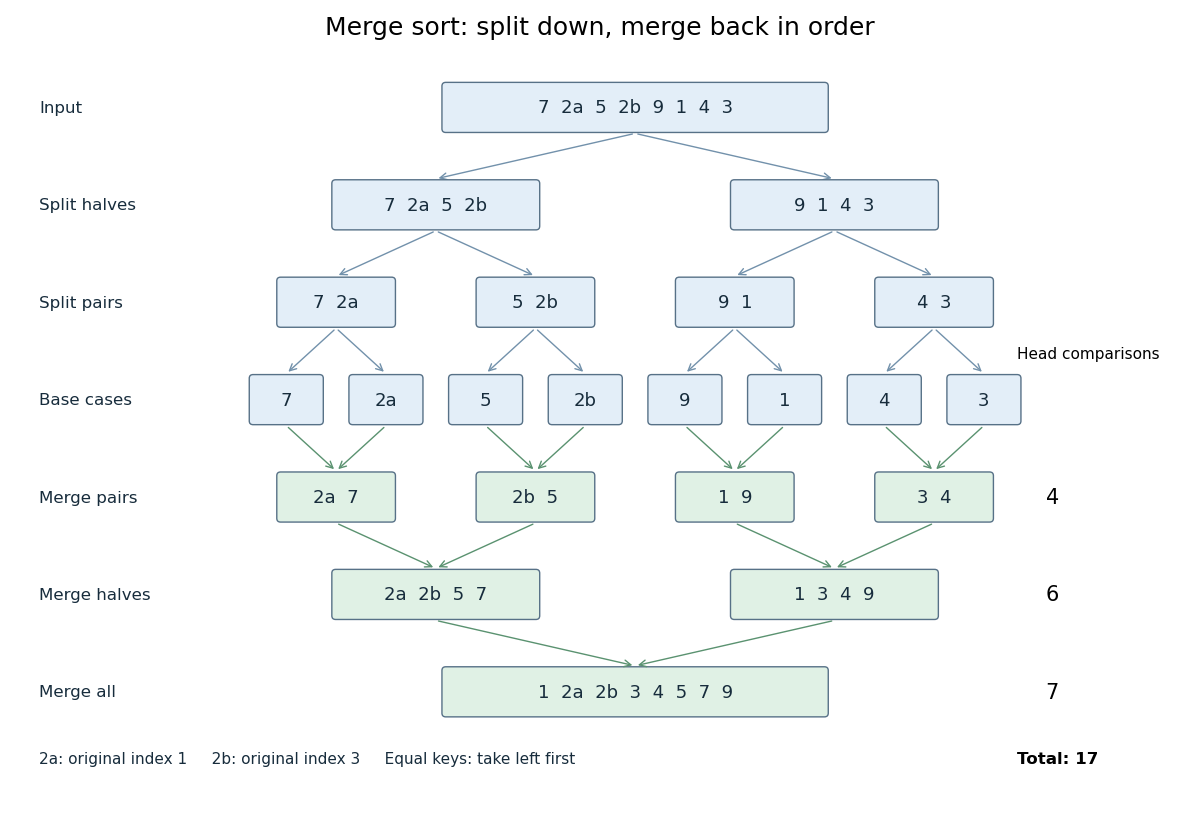
Merge sort splits into base cases and returns sorted arrays
. The tagged keys 2a and 2b retain their original order through stable sorting. The merge algorithm makes 4, 6 and 7 head comparisons on the three returning levels, for 17 in total. Details.The first two halves are and . Their pairs split into one-entry base cases. Applying the merge algorithm gives the following fully worked return levels; each number in the last column counts only comparisons between two available heads.
| Returning level | Resulting sorted arrays | Head comparisons |
|---|---|---|
| Pairs | , , , | |
| Halves | , | |
| Whole array |
In the left-half merge algorithm, the head pairs are , and ; it takes , then appends . In the final merge algorithm, the head pairs are , , , , , and . It takes , then appends . Thus this precise version makes head comparisons and, ignoring identity tags, returns .
The elegance of merge sort is that it creates exactly the structure its next step needs: two smaller sorted arrays make the larger ordering inexpensive. Once the whole array is sorted, equal keys are adjacent and binary search can serve repeated queries. Stable sorting also retains information that the keys alone do not express. If the left-half merge algorithm instead takes the right head on the tie, it returns ; the keys are sorted but stable sorting has failed.
For time complexity, assume each key comparison, entry access and entry copy has constant cost. The merge algorithm processes entries in time. In Big O notation, the resulting recurrence relation isFor , the balanced levels contain entries each and there are returning levels. Each costs , so the worst-case time complexity is . For arbitrary , there are at most returning levels, each processing at most entries, giving the same bound. The worst-case number of head comparisons is also . Here is the base-two logarithm. The MIT notes give this level-by-level analysis for merge sort.[ref]
https://ocw.mit.edu/courses/6-006-introduction-to-algorithms-spring-2020/6d1ae5278d02bbecb5c4428928b24194_MIT6_006S20_lec3.pdf. MIT 6.006 (2020), lecture 3, page 5: merge sort analysis
The conventional array implementation uses a reusable buffer of entries for the merge algorithm, together with pending calls for recursion. Its auxiliary space complexity is therefore , beyond the original array. This bound describes that implementation. A linked list permits a merge algorithm that reconnects existing nodes; its storage accounting differs from copying array entries into a buffer.
For a short algorithm correctness outline, the empty and one-entry base cases are sorted. Assuming recursion correctly sorts both shorter halves, the merge algorithm returns all their entries in order. Equal keys within a half keep their relative order by the same argument applied to the smaller call; across halves, every left entry originally preceded every right entry, so taking left first preserves stable sorting. Both half-lengths decrease for , establishing termination.
Articles by others on the same topic


Merge sort is a classic, efficient, and stable sorting algorithm that follows the divide-and-conquer strategy. It was invented by John von Neumann in 1945. Here's a breakdown of how it works: ### Key Concepts: 1. **Divide:** - The input array is divided into two halves. This process continues recursively until each subarray has one or zero elements, at which point they can be considered sorted.