For fixed endpoint values, a stationary differentiable path obeys the Euler-Lagrange equationIt follows by taking the first variation of the functional and integrating the term in by parts; vanishes at the endpoints.
If has no explicit dependence, the chain rule givesConsequentlyon an Euler-Lagrange equation solution. Thus the Beltrami identity supplies the first integralThe opposite sign is an equally valid convention. The conserved value can be zero for particular integrands or paths; absence of explicit alone does not guarantee a nonzero numerical value. The useful statement is that this expression is constant along an extremal.
On the cylindrical surface , the line element is . For a single-valued path parametrized by increasing ,The integrand has no explicit , so its Euler-Lagrange equation gives the constant conjugate quantity . Its derivative with respect to is strictly positive, hence itself is constant. The two endpoints determineThis is a constant-pitch helix on the cylinder. To verify global minimality, unroll the cylinder with planar coordinates . The path becomes a straight line between points separated by and , so the triangle inequality for arc length givesThis is the standard description of geodesics on a circular cylinder.
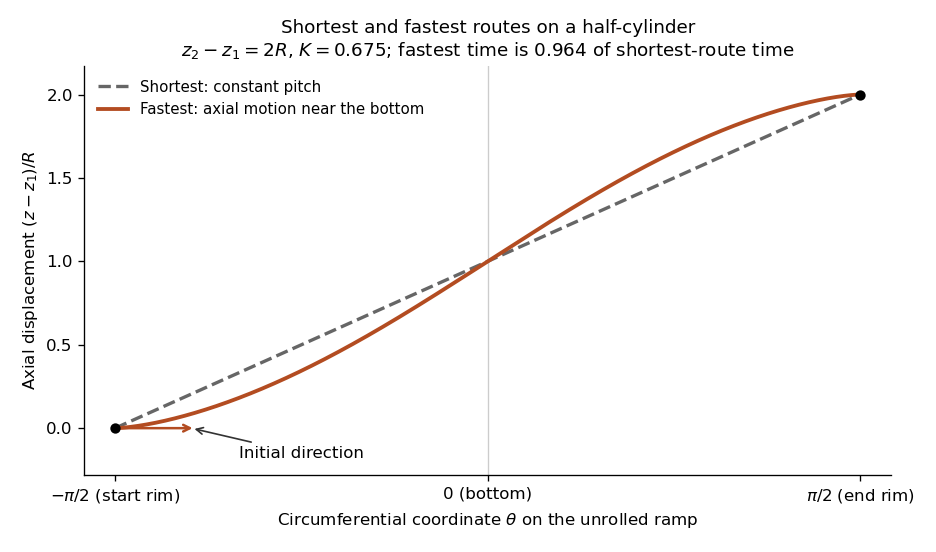
The downward drop from the starting rim to angle is . With no dissipative forces, conservation of energy gives , so . Dividing the line element by this speed yieldsThe endpoint singularities are integrable for the minimizing path. The integrand is independent of ; its Euler-Lagrange equation gives a constant , after absorbing the overall prefactor:Solving for and taking the positive branch required by givesThe constant is fixed implicitly byThis integral is strictly increasing from zero to infinity as increases from zero to one, so every finite positive separation selects a unique . The time integrand has second derivative with respect to . Its supporting-line inequality, integrated between fixed endpoints with constant first derivative with respect to , proves this stationary path is the unique global minimum within the stated single-valued class.
As , . Therefore the skater should initially head directly down the curved ramp, perpendicular to the cylinder axis, and gain axial motion later. The path differs from the constant-pitch shortest route because extra distance is cheaper in time near the faster, lower part of the ramp. This is the brachistochrone on a horizontal half-cylinder.

Articles by others on the same topic
There are currently no matching articles.