Model the AFM cantilever as a driven damped harmonic oscillator. If the drive stays at the free-space resonance and the spring constant and effective mass are unchanged, its steady amplitude isHere is intrinsic damping and the added dissipative interaction with the surface. At large average separation there is no tapping, so and . As the lower turning point reaches the surface, intermittent contacts dissipate energy and the amplitude decreases. With further approach the oscillation becomes strongly constrained, eventually approaching a continuously contacting, nearly quenched response. The damping-only sketch has a free-amplitude plateau followed by a descending amplitude on approach. The rounded transition in the sketch is illustrative; adhesion and actual contact mechanics determine its shape. The deliberately omitted force-gradient-induced resonance shift can make real approach curves more complicated.
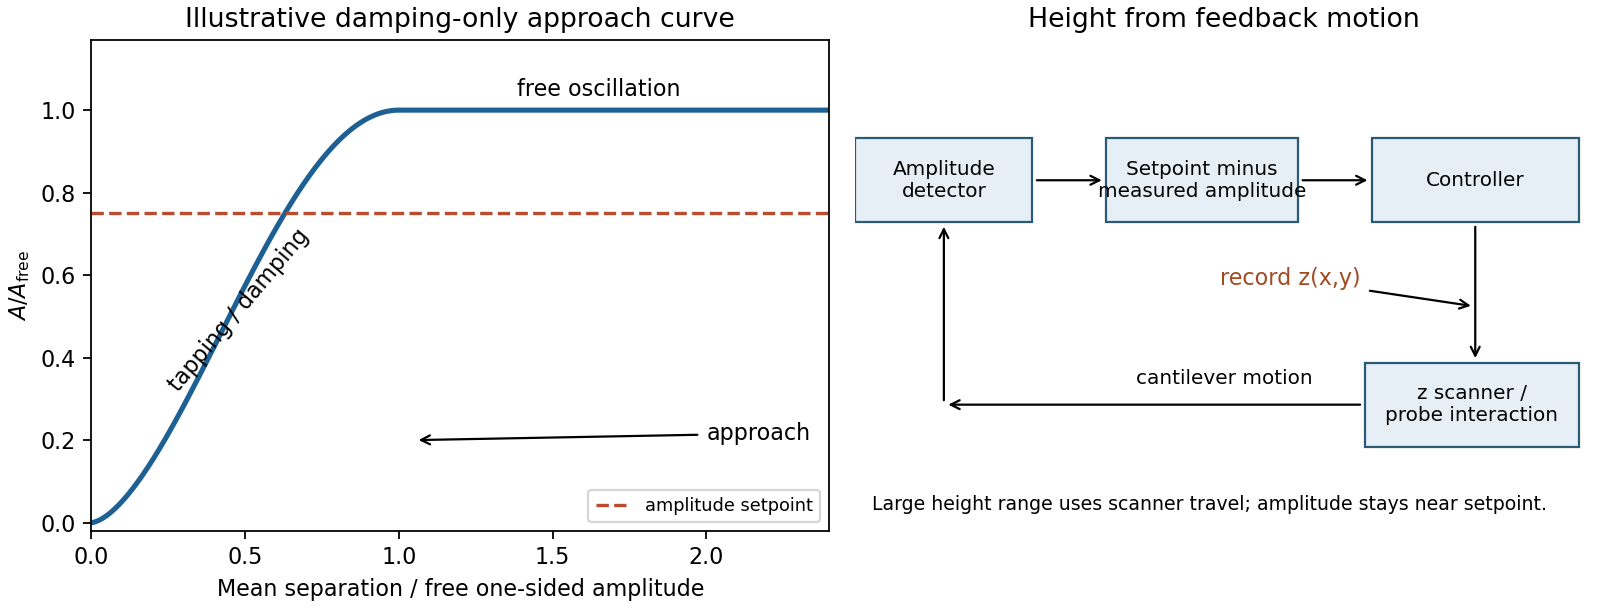

An uncorrected amplitude image has a useful vertical range only across the transition between free oscillation and strongly suppressed oscillation. If the free motion is a few tens of nanometres peak-to-peak, its one-sided amplitude is half that excursion. The relevant vertical height range is therefore of the order of the oscillation excursion, only tens of nanometres, rather than micrometres. It is not a sharp universal limit equal to the quoted peak-to-peak value: the chosen mean gap, contact law and usable sensitivity determine the actual range. A sufficiently high feature can quench the motion or produce destructive contact; a sufficiently deep depression leaves the probe oscillating freely with essentially no height sensitivity. This argument limits height tracking, not the lateral width of a feature. Lateral resolution instead depends on AFM tip convolution, sampling and the probe-surface interaction.
In tapping-mode atomic force microscopy, demodulate the cantilever displacement to obtain its amplitude and compare it with a setpoint below . A closed-loop control system drives a piezoelectric scanner in to restore the setpoint as the raster crosses raised or depressed regions. The interaction remains in its sensitive amplitude range while the scanner follows heights much larger than the oscillation amplitude. The principal height image is the calibrated feedback displacement at each lateral pixel. The amplitude-error and phase channels are supplementary signals, rather than interchangeable height measurements. Maximum height is now bounded by scanner travel, clearance and stable tracking. Steep features require adequate feedback bandwidth and sufficiently slow scanning; trace/retrace disagreement tests tracking, while a changed AFM probe tests geometric broadening. Surface-dependent dissipation can move the setpoint height even on a geometrically flat specimen.
Articles by others on the same topic
There are currently no matching articles.