Energy accounted for through a system's chemical composition and state. A galvanic cell can convert part of the change associated with a redox into electrical work; the system boundaries determine which thermal losses also enter the balance.
An energy unit with several historical definitions. The thermochemical small calorie is exactly joules; a kilocalorie is one thousand such calorie units. A calorimetric calculation must specify its unit convention.
Useful power generated from nuclear energy release, usually controlled nuclear fission in a reactor supplying heat to a power cycle. Operational carbon emissions, full fuel-cycle impacts, accident risks, waste and decommissioning are distinct assessment dimensions. Replacing existing output requires comparison of both annual energy and dependable capacity.
Energy obtained from naturally replenished flows or stocks on a human timescale. Replenishment does not by itself prove low life-cycle emissions or negligible environmental impact. Variability, geographic availability and conversion equipment matter when a source is integrated into an energy system.
Useful power extracted from surface-water waves. Resource variability, extreme-storm survivability, offshore access, moorings and electrical connections affect practical performance. Its potential and costs are distinct from those of tidal power, even when both use marine locations.
Power extracted from tidal water-level differences or tidal currents. Astronomical timing is predictable, but output is not constant. Basin geometry, flow changes caused by extraction, environmental effects and connection infrastructure constrain practical resources; a local undisturbed-flow power density is not a whole-channel extractable-energy estimate.
Conversion of sunlight into useful power through photovoltaic or solar-thermal systems. A first areal estimate is annual mean irradiance times conversion efficiency and system-performance factors. Storage, transmission, land use, night-time operation and seasonal balance require separate accounting.
Conversion of atmospheric kinetic energy into useful power, commonly by turbines driving generators. Annual energy equals nameplate capacity times capacity factor times elapsed time, while the contribution to reliable peak supply is a separate system property. Weather correlation, transmission, flexibility and curtailment affect large-scale integration.
Energy recovered from biologically produced material, for example by combustion or conversion into fuels. Sustainable regrowth can recycle biogenic carbon, but land-use change, cultivation, processing, transport and regrowth time belong in its life-cycle assessment. Harvested energy is incident solar energy times area, elapsed time and annual conversion efficiency; dry and wet mass yields require different heating-value conventions.
Returning energy from a used flow or beam to an upstream supply or a useful reservoir. An electron beam decelerated before collection returns much of its acceleration energy; the net input then covers unrecovered energy and auxiliary losses.
Storing recoverable energy for later use. Energy capacity, maximum power, duration, round-trip efficiency and degradation are independent dimensions of performance; a high specific energy need not imply high power or efficiency.
The ratio of useful energy recovered on discharge to the energy supplied during charging for a complete storage cycle. Generation efficiency alone excludes the preceding charging losses.
Storage of hydrogen as a chemical-energy carrier. Comparing electricity-storage systems requires including production, containment and reconversion; the fuel heating value alone does not specify electrical round-trip efficiency.
Water is pumped to an upper reservoir and later discharged through a turbine. For approximately constant head, useful discharge energy is while power is ; reservoir volume and flow rating set different properties.
Energy measured at the resource or initial-input stage before downstream conversion to final useful energy. Comparisons with electrical output must state the accounting convention and avoid treating a primary-energy thermal input as the same service as delivered electricity.
A unit of energy equal to one thousand thermochemical calories, or . In dietary usage the capitalized Calorie commonly denotes a kilocalorie.
Collection of ambient light, heat flow, thermal cycling, motion or other available energy into a usable electrical supply. Available average power, conversion loss and peak-load buffering must be distinguished.
Electrical generation from mechanically induced electric polarization in a piezoelectric element.
A polymer exhibiting piezoelectricity. A compliant, low-density film can accept larger bending or strain than a brittle ceramic, while low permittivity can yield a large voltage coefficient despite a modest charge coefficient. Extractable energy still depends on mechanical input, capacitance and electrical loading.
A ceramic material used for piezoelectricity, often offering large charge response and electromechanical coupling with comparatively high stiffness. Brittle fracture, mechanical impedance matching and mounting conditions can limit a vibration harvester. A high charge coefficient alone is not a device power ranking.
Conversion of mechanical motion into electrical output through changing magnetic flux.
Conversion using changes in capacitance of a charged or electrically biased structure.
Energy per unit mass, with units such as or . Active-material, cell and packaged-system mass bases can give very different values.
A logarithmic comparison of specific power against specific energy for storage or conversion devices. With consistent mass and energy units, constant-duration lines satisfy . The plotted capability depends on operating conditions and mass convention.
The Q value of a reaction or particle decay is the initial total rest energy minus the final total rest energy. Positive releases kinetic energy; a negative requires energy supplied by incident motion or another source. Atomic and bare nuclear mass conventions must be distinguished when counting electrons in beta decay.
For a Lagrangian , its energy function isIt is conserved along Euler-Lagrange trajectories when has no explicit time dependence.
Mechanical energy is the sum of kinetic energy and potential energy. It is conserved when all forces are conservative and the potential has no explicit time dependence.
For constant masses, a time-independent potential energy and forces with zero total extra power , Newton's second law gives . Thus mechanical energy is conserved. Smooth stationary constraint reactions and a purely magnetic Lorentz force supply zero power. This is more restrictive than conservation of energy in general, which may include thermal or other internal forms.
Total kinetic energy is unchanged between the incoming and outgoing states of an elastic collision. This does not require each body's kinetic energy to be unchanged, nor that kinetic energy remain constant during temporary elastic deformation. In general mechanical energy includes potential energy, so conservation of mechanical energy alone does not imply constant kinetic energy.
Work measures the energy transferred by a force as its point of application moves. For a point mass following a path , add the contribution of the force along each small displacement:This line integral uses the actual path, and the dot product selects the component of force along the motion. A large force perpendicular to every small displacement does zero work; holding something still also does zero mechanical work on it, even if holding it feels tiring. The SI unit is . [ref]
The usefulness of work is that it connects a description in terms of forces and distances to one in terms of energy. The work-energy theorem gives the change in kinetic energy from the total net work, often without solving for the entire motion. The work of one selected force equals that change only when the other forces contribute zero total work.
The work done by a uniform pressure on an expanding boundary is . With internal energy , the first law of thermodynamics for an adiabatically expanding region reads . For a homogeneous cosmological perfect fluid, and give the cosmological continuity equation .
When a vacuum vessel's window shatters, a nearly atmospheric initial pressure difference gives inward pressure force on frontal area . Dividing by the glass mass estimates its initial collective acceleration. An ideal atmospheric pressure-work budget for vessel volume would give a collective kinetic energy estimate if assigned entirely to the fragments. This is a model-dependent energy budget, not a universal bound on every fragment's speed: air motion, fragmentation, pressure equalization and wall impacts alter the transfer, and unequal sharing can accelerate a small fragment faster than the collective estimate.
For a fixed force and endpoint displacement , the line integral reduces to a dot product:Here is the angle between the force and the displacement. For straight motion, is also the distance traveled. A force acting along a displacement does of work. Turning the same force perpendicular to the displacement gives and zero work; reversing it gives and . At , the work is . These signs describe energy transferred to or from the moving body. [ref]
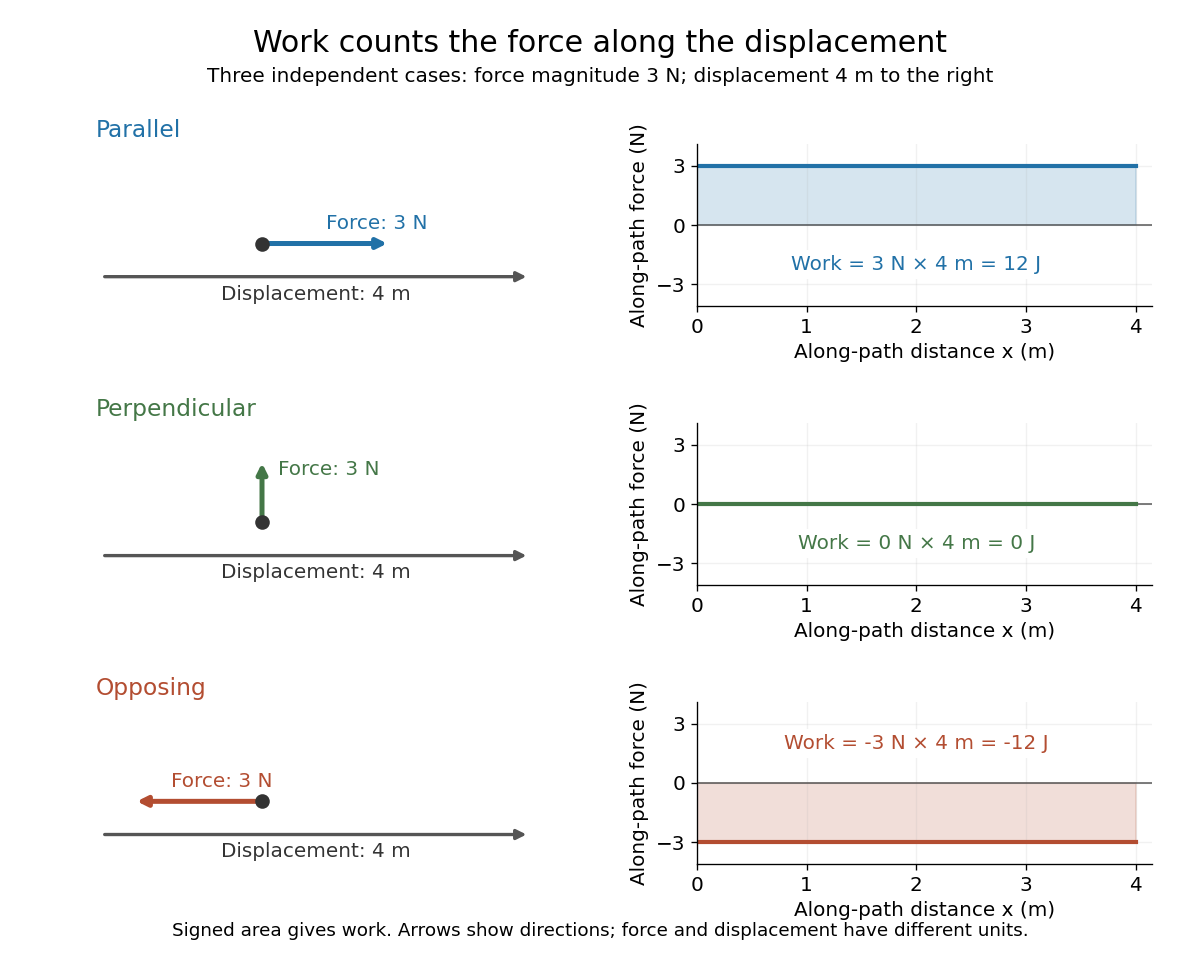
For a point mass of constant mass observed in an inertial frame, the net work along its actual path equals its change in kinetic energy:The middle expression is a line integral; the dot product selects the component of force along the displacement. Positive net work increases speed, negative net work decreases it, and zero net work leaves the endpoint speeds equal. Equal endpoint speeds do not imply equal velocities: a perpendicular force can continually change direction while doing zero work. [ref]
https://ocw.mit.edu/courses/8-01sc-classical-mechanics-fall-2016/mit8_01scs22_chapter13.pdf. MIT mechanics, Chapter 13, section 13.11
The bridge to Newton's second law is short: take the dot product of with velocity. The chain rule gives , equating the rate of change of kinetic energy to instantaneous power. Integrating gives the theorem. No conservative force assumption entered this argument; friction also contributes to the net work.
For the harmonic oscillator with spring stiffness , release a mass from rest at . The spring exerts . Its work before the first passage through isThus gives speed there. The velocity is negative on this passage because the position is decreasing. The energy calculation alone determines its magnitude, so the direction still requires information about the motion.
For a time-independent potential energy , the conservative force contributes work . Separating all other work as gives . Consequently conservation of mechanical energy requires zero net other work; the work-energy theorem itself does not require that conservation. With damping, mechanical energy decreases even though the theorem remains valid. [ref]
https://ocw.mit.edu/courses/8-01sc-classical-mechanics-fall-2016/mit8_01scs22_chapter14.pdf. MIT mechanics, Chapter 14: mechanical energy and nonconservative work
Power describes how quickly energy is transferred. For mechanical work, the instantaneous power supplied by a force isThe SI unit is , distinct from the velocity unit . The italic symbol for work and the upright unit for power mean different things. Two processes can transfer the same energy while requiring different powers: doing of work in requires an average , whereas doing it in requires an average . [ref]
The instantaneous rate of energy transfer through a circuit port is , with positive electric current entering the positive voltage terminal for the passive sign convention. Peak phasors in sinusoidal steady state give . The factor is absent for root mean square phasors.
Power output or input divided by the relevant mass, commonly expressed in watts per kilogram. Device-level and active-material values cannot be compared without stating their different mass bases.
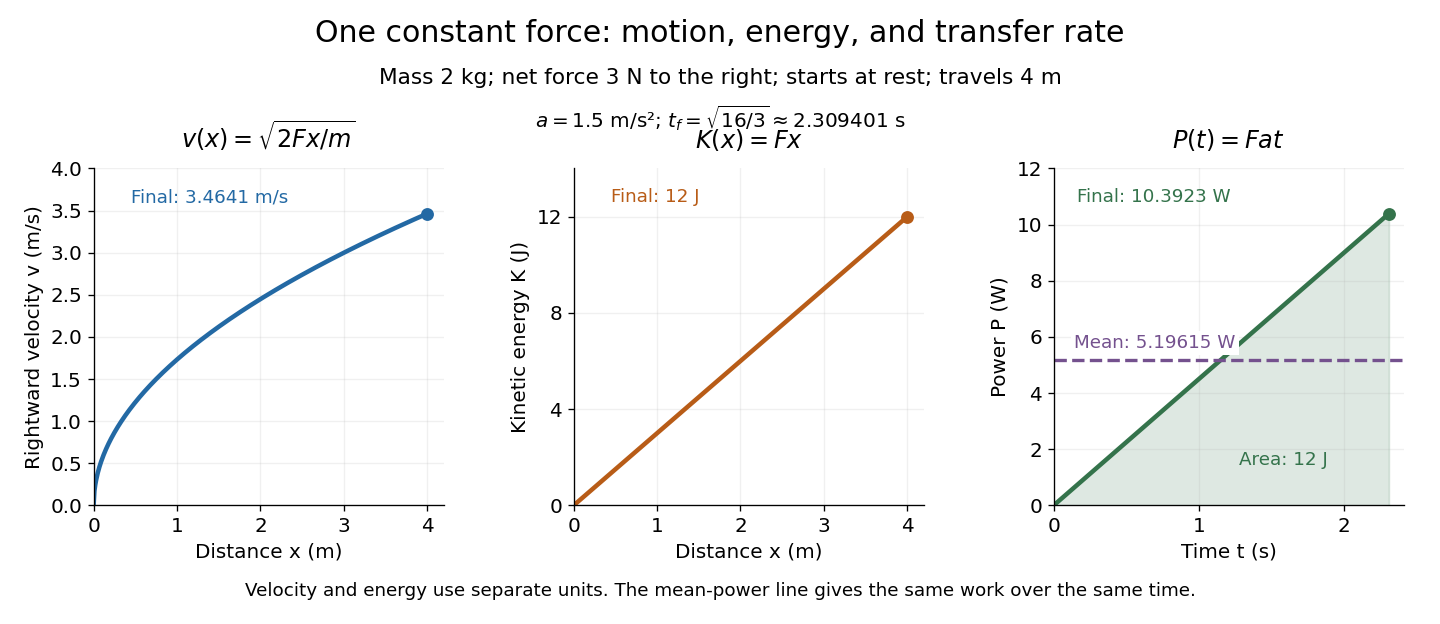
Instantaneous power is power at a particular moment. Consider a point mass with mass , initially at rest, acted on by a constant net force along a straight path. Newton's second law gives constant acceleration , hence velocity andThe instantaneous power starts at zero even though the force is nonzero, because the initial velocity is zero. At distance , the kinetic energy example below gives speed , so the final instantaneous power is . Negative instantaneous power means the selected force is removing energy at that moment.
Average power divides the work over a nonzero interval by the elapsed time. For the same point mass driven from rest through by a net force, the displacement is . ThusThis average power is half the final instantaneous power because is a linear function of time, starting at zero. Its graph of a function bounds a triangle of area ; the horizontal line at average power encloses a rectangle with the same area. In general, an endpoint value of instantaneous power does not determine average power. [ref]
Kinetic energy is the energy associated with motion. For a nonrelativistic point mass of mass , measured in a specified inertial frame,Here is velocity and is speed; is another common symbol for kinetic energy. The dot product makes nonnegative regardless of the direction of velocity. At fixed mass, doubling speed quadruples kinetic energy: a point mass at has , whereas at it has . The SI units are . Different reference frames can assign different velocities and therefore different kinetic energies. [ref]
A short outline explains why kinetic energy has this formula. In a nonrelativistic inertial frame, constant mass and Newton's second law give, using the chain rule,Integrating over time proves the work-energy theorem, . The net force is the sum of all forces, and is their total work, not merely the work of a chosen driving force. This route to final speed is useful when the forces as functions of position are known but the full motion as a function of time would be harder to find. [ref]
In the running example, a point mass starts at rest and receives a constant net force through . Its net work is , soAt any intermediate distance , and : kinetic energy is a linear function of distance, while speed is proportional to the square root of distance. If a net opposing braking force subsequently acts for , it does of work and brings this point mass to rest. Negative net work decreases kinetic energy; it does not make kinetic energy negative. Beyond the stopping point the motion must be reconsidered, since the point mass cannot keep moving forward with a negative .
Kinetic energy also makes the exchange with potential energy intuitive: a falling body's loss of gravitational potential energy can appear as increased kinetic energy. The formula above applies when speed is small compared with the speed of light; at higher speeds, special relativity changes the expression. [ref]
Kinetic energy per unit mass. For an acceleration field , its change along an actual trajectory is , by the chain rule. This differs by a mass factor from the work integral of a physical force.
For unidirectional flow through area with mean speed , the outgoing kinetic-energy flux is , where . Cubing the mean speed generally differs from averaging the cube. A uniform profile has ; circular laminar Hagen-Poiseuille flow has .
For a free particle of rest mass , subtract its rest energy from its total energy , where is the Lorentz factor. The low-speed binomial series gives , recovering classical kinetic energy.
For rotational motion about a fixed axis, let be cylindrical radius, the signed tangential velocity, and the mass measure. Define the kinetic energy, axial angular momentum, and moment of inertia byThe Cauchy-Schwarz inequality gives . More precisely, direct expansion gives the nonnegative energy gapThus the minimum at fixed and fixed mass distribution occurs exactly when almost everywhere with respect to . This means constant angular velocity , or solid-body rotation. If the profile is continuous, the equality holds at every point in the mass support.
For a uniform unit-density cylinder of radius , height , and volume , the moment of inertia is . Therefore , with equality for . Multiplying by a uniform nonunit density changes the mass measure and consistently.
Writing particle positions relative to the center of mass as makes , so the cross term in the squared velocities vanishes. The total kinetic energy splits into center-of-mass translation and relative motion as displayed. For a rigid body, the latter is , where is the moment of inertia about the instantaneous rotation axis through the center of mass.
For a twice differentiable position away from the origin, write with radial unit vector . Its unit-length constraint gives and , separating radial and directional contributions to speed and kinetic energy. The identity is kinematic and does not require a particular force law.
The kinetic energy density of a continuum with mass density and velocity is . For a displacement field, the material velocity is its time derivative.
Rotational kinetic energy is the kinetic energy of a rigid body's rotation. For pure rotation about an axis fixed in an inertial frame,Here is the perpendicular distance of a mass element from that axis, is the moment of inertia about that same axis, and is the common angular speed, measured in radians per second. The rigid body assumption fixes the relative positions of the mass elements; they share angular velocity but have different speeds . Summing their kinetic energies gives the formula. This is a nonrelativistic model; deformation or internal motion can contribute additional kinetic energy.[ref]
For a computed example, take a uniform disc and an ideal thin ring, each of mass and radius , rotating about its central perpendicular axis at angular speed . The moment of inertia of a uniform disc is , while the ring has moment of inertia . Their rotational kinetic energies are therefore and . The ring stores twice the energy at the same angular speed, because more mass lies farther from the axis. At the same nonzero rotational kinetic energy, its angular speed would instead be times the disc's. This makes radial placement useful for storing energy in a rotating wheel, although a real design must also withstand the stresses of rotation.
For fixed-axis rotation with constant moment of inertia, write the signed rotation rate as , with angle in radians. The axial component of net external torque obeys , so the work-energy theorem becomesAn opposing torque removes rotational kinetic energy; bearing friction must be included in the net torque. The signed matters when the direction reverses. Rotation about a fixed axis need not be about a principal axis: the scalar energy formula still holds, but transverse bearing torques can be needed to maintain that axis.
For general rigid body motion, use the inertia tensor about the centre of mass :This is the kinetic-energy decomposition about the centre of mass. In a principal body frame, the rotational term is , using the principal moments of inertia. Away from a principal axis, angular momentum and angular velocity need not be parallel. A freely rotating asymmetric rigid body can change the direction of angular velocity relative to the body even while rotational kinetic energy remains constant; Euler equations for a torque-free rigid body govern that motion. One constant axial moment of inertia is then insufficient.[ref]
Potential energy assigns energy to a system's arrangement, so a change of arrangement accounts for the work done by a conservative force. For a time-independent potential energy ,The gradient points toward increasing potential energy; the force points toward decreasing potential energy. Only differences matter: adding a constant to changes neither the force nor its work. This endpoint rule follows by substituting into the line integral for work. [ref]
Near Earth's surface, stipulate constant gravitational acceleration and measure height upward from a chosen zero. Then gravitational potential energy is . Raising a mass by increases its gravitational potential energy by , while gravity does of work. These are computed model values, not measurements of a particular lift. An ideal spring obeying Hooke's law instead has , with displacement from its relaxed state and spring constant : and give relative to . [ref]
In uniform gravity a body's gravitational potential energy is its mass times gravitational acceleration times the Cartesian height of its centre of mass. If that height is represented by an axis distance and tilt angle , it is and the energy becomes . Treating simultaneously as a Cartesian height would introduce an extra, unjustified cosine.
Named after John Lennard-Jones, this is a pair potential energy combining steep short-range repulsion with nonretarded London dispersion force attraction. Its minimum is at , found by differentiation. The power twelve is a convenient model for repulsion, rather than an exact consequence of the Pauli exclusion principle. The power six in the attractive energy follows from second-order coupling of atomic electric dipoles, before retardation matters.
A quadratic potential energy about a stable equilibrium. In one dimension is the restoring stiffness and the force is . A mass undergoing undamped motion has angular frequency . A smooth potential with a nondegenerate local minimum is approximately harmonic for sufficiently small displacements; higher-order terms describe departures from simple harmonic motion.
A region of lower potential energy surrounded by higher potential energy; a particle must gain sufficient energy to escape classically.
A potential energy landscape with two local minima separated by a barrier. In a symmetric one-dimensional case, its two lowest wavefunctions are an even function and an odd function, with their energies split by quantum tunnelling. A two-mode approximation for a Bose gas retains these two orbitals when higher energy levels are sufficiently remote.
A confining Quantum Hamiltonian on with , potential and a Dirichlet boundary condition at zero has natural length and energy . Rescaling gives , so every energy eigenvalue scales as . The potential derivative diverges at the wall even though the potential itself is finite there.
This potential energy generates a repulsive central force . It is an inverse-square potential but an inverse-cube force; the powers must not be confused with the Coulomb or gravitational potential proportional to .
For with , nonzero physical angular momentum and positive energy , put and . Direct integration of the effective potential radial equation gives the displayed orbit. It has one radial minimum and two straight-line asymptotes separated by polar angle . The repulsive scattering deflection is ; no bounded or circular orbit exists at finite positive energy.
The potential energy associated with gravitational interactions. For a self-gravitating spherical body with a fixed dimensionless density profile, for a positive profile-dependent constant ; a uniform sphere has . The scaling competes with the same radius dependence of ultrarelativistic electron degeneracy pressure in a white dwarf, giving the Chandrasekhar mass scale.
The portion of a fluid system's potential energy that can be released by admissible rearrangement relative to a stable reference state. In a uniformly stratified incompressible fluid, the quadratic density is , where is vertical fluid displacement and the buoyancy perturbation. It is positive for stable stratification and measures the restoring energy of internal gravity waves.
The background potential energy is the gravitational potential energy of the statically stable state obtained by adiabatically sorting a fluid's parcels. The difference is available potential energy. Pure rearrangement changes but not ; irreversible density mixing can increase . Molecular exchange with internal energy must be separated when defining an irreversible mixing rate.
A potential function assigns a scalar to each point of a configuration or spatial domain. In mechanics it represents potential energy, and its negative gradient gives the corresponding conservative force.
A central potential depends only on distance from a fixed centre, . Its force is radial, and rotational symmetry implies conservation of angular momentum.
Adding an inverse-cube force can preserve radial motion while rescaling angular motion. For potential and angular momentum , the radial effective potential equals that of with effective angular momentum when this is real.
A force is conservative when its work depends only on the endpoints. On a simply connected domain this is equivalent to for a potential energy .
A nonconservative force has path-dependent work. On a simply connected domain, a continuously differentiable force is nonconservative exactly when its curl does not vanish identically.
Here inverse-square potential means the potential energy associated with an attractive inverse-square law for a central force: the potential energy itself varies as inverse distance. For and position with ,The gradient makes the distinction explicit: doubling halves the magnitude of potential energy but quarters the magnitude of force. The neighboring repulsive inverse-square potential instead has potential energy proportional to and an inverse-cube force; the two naming conventions must be distinguished.
For Newton's law of universal gravitation, , where is the gravitational constant. Treat the attracting mass as an isolated fixed point mass, or as a body with spherical symmetry and exterior test particle of constant mass . The spherical shell theorem gives the same exterior Newtonian gravitational potential energy without requiring uniform mass density. Here is measured from the centre, and the formula applies outside the body; it does not describe its interior. The Newtonian gravitational potential per unit mass is .[ref]
Chapter 13: Work and Potential Energy (A). §13–2, equations 13.11–13.12: radial work and conserved energy; §13–4: gravitational field outside a sphere
The negative sign records binding relative to infinite separation, rather than a negative kinetic energy. Moving from to increases potential energy byBecause the force is a conservative force, this work depends on the endpoints, including for a curved path. Integrating with zero at infinity gives ; adding a constant leaves the force unchanged but shifts the numerical escape energy threshold by that same constant. This is why the reference at infinity must accompany an escape velocity calculation.
For an exact synthetic comparison, stipulate the standard gravitational parameter and a test particle. At , and the inward force has magnitude ; at , and the inward force has magnitude . The increase is of potential energy. These stipulated parameters are an arithmetic example, not observations of a particular body. The escape-energy balance diagram uses the same parameters.
In the isolated model, conservation of energy and angular momentum conservation reduce the exterior test particle's motion toHere is specific orbital energy and is specific angular momentum. The effective potential is . A zero radial velocity is a radial turning point, and need not mean zero total speed: at the periapsis or apoapsis of a nonradial Kepler orbit, tangential velocity remains. Thus the vertical gap between and represents total kinetic energy per unit mass, whereas the gap above represents its radial part.
For , the orbital eccentricity obeys . Negative gives an elliptic orbit, including a circular orbit at its minimum allowed energy; zero gives a parabolic trajectory; positive gives a hyperbolic Kepler orbit. The effective potential tends to zero from below at infinity, so its outer region creates no extra positive escape barrier. This explains why escape velocity depends on energy even though angular momentum changes the path. The case is radial motion, rather than a nondegenerate parabola or hyperbola; inward radial motion can end in collision.
One motivating laboratory demonstration compares two balls initially at the same height. A switch releases one vertically when the other leaves a horizontal track; arranging their paths to meet gives a collision as the readout of equal downward displacement over equal time. Equal initial height and synchronized release control the comparison. This tests the local independence of horizontal motion and free fall, under nearly constant gravitational acceleration; it does not measure an inverse-square law.[ref]
A complementary astronomical comparison uses the Moon's distance and orbital period to infer inward centripetal acceleration, , and compares it with surface gravitational acceleration scaled by . The approximately sixtyfold distance ratio gives the approximately prediction. The inference links terrestrial free fall to a lunar orbit. Distance calibration matters; the circular orbit approximation and the Sun's tidal force limit this elementary comparison.[ref]
Chapter 7: The Theory of Gravitation. §7–4: lunar distance, period, and the inverse-square comparison
Lunar laser ranging gives a more discriminating orbit readout. An observatory directs short laser pulses at a retroreflector array on the Moon, and a detector records returning photons. Round-trip time, statistically combined over several returns, constrains distance; pressure and temperature accompany the readout. The fitted model includes Newtonian gravity, terrestrial and lunar rotation, geophysical effects, and corrections from general relativity. Comparing orbit determination residuals across stations and model choices checks consistency. The inspected study reports weighted root mean square residuals for its 2005–2011 ranges, rather than for a bare isolated inverse-square potential. It tests the equivalence principle using the Earth and Moon's response to the Sun; it is not a direct escape velocity measurement. Uneven coverage near new and full Moon, radiation pressure, and thermal expansion of reflector mounts limit that inference.[ref]
A retroreflector returns incident light approximately toward its source. Corner-cube arrays make the lunar laser ranging round trip possible.
Three mutually perpendicular mirrors reverse a ray's direction when it encounters all three. With orthonormal normals , write the reflections as , , . Their orthogonal projection matrices have pairwise products zero and sum to by the resolution of the identity in an orthonormal basis. The product of the three reflections is therefore . It reverses every incident direction independently of the order in which the mirrors are met. Real apertures restrict which incoming rays actually reach all three reflecting faces. Such retroreflectors provide the returning-light geometry in lunar laser ranging.
The even potentialhas a cusp at the origin and approaches the finite value . Motions below that value oscillate between symmetric turning points; motions above it escape.
The escape velocity is the least initial speed that permits a freely coasting body to move arbitrarily far from an isolated attracting body. Despite its conventional name, it is a speed, not a unique velocity vector. For a fixed point mass , or outside a body with spherical symmetry, set Newtonian gravitational potential energy zero at infinity. An exterior test particle of constant mass then hasHere is the standard gravitational parameter, and is distance from the centre, not height above the surface. Set for surface escape velocity. Evaluate velocity in the body's rest inertial frame. Neglect drag, later rocket thrust, other bodies' gravity, and relativistic effects.[ref]
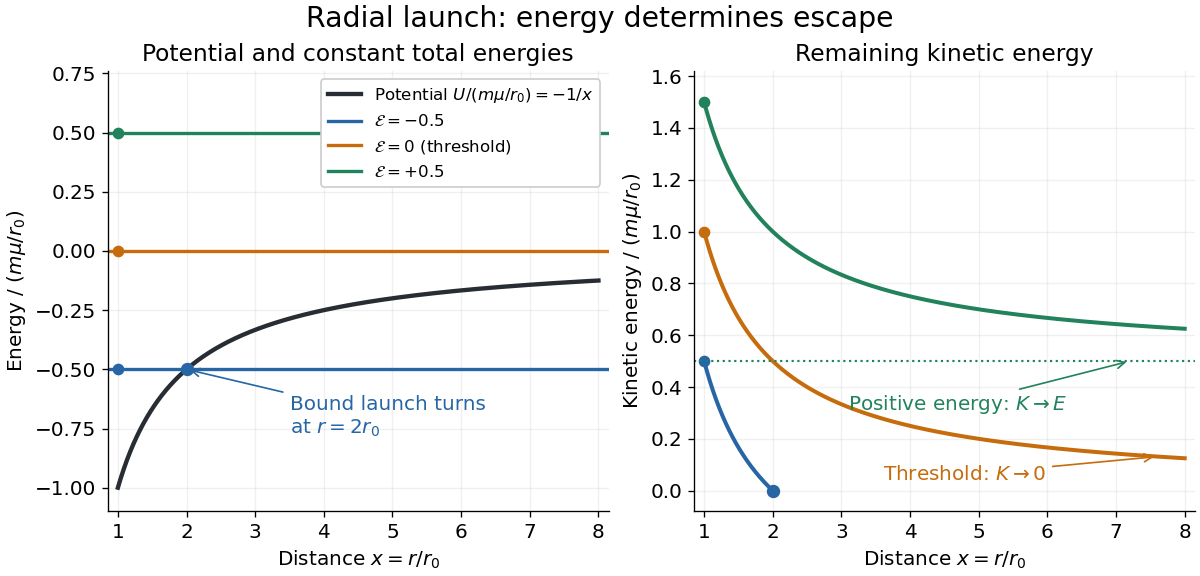
Conservation of energy gives the threshold by requiring : at infinity the potential energy tends to zero and the kinetic energy cannot be negative. If , the outward motion loses speed continuously toward zero. If , the asymptotic speed is . If , infinity is inaccessible. For a radial outward launch, its outer turning point is . For nonradial motion use angular momentum and the escape energy threshold to distinguish zero radial velocity from zero total speed.
Direction still determines the orbit and whether the body hits an obstacle. An initially inward velocity can cause collision even when . For an isolated spherical body, an exterior outward launch, or a tangential launch at or above escape velocity, has an outward escape branch without intersecting the body. A parabolic trajectory is the nonradial threshold path; a hyperbolic Kepler orbit has positive energy. The formula specifies their required local speed, not their orientation.[ref]
13.3 Gravitational Potential Energy and Total Energy. §13.3, “Energy and gravitationally bound objects”: scalar energy and finite-body collisions
For a spherical nonrotating asteroid of the same mean mass density as a reference planet of radius R and surface gravity g, the mass scales as r cubed. Its surface escape speed therefore obeys . A take-off speed permits escape for . If that same take-off speed gives ballistic height H above the reference planet, , and the limiting asteroid radius is . A chosen H is an explicit performance estimate, not a universal human constant.
Equating the molecular root-mean-square speed to the surface escape velocity gives , or . This compares speed scales; the high-speed tail can escape below that temperature, and molecular dissociation can invalidate the assumed species at high temperature.
Use the synthetic standard gravitational parameter and launch distance . Then escape speed is . Three outward radial launches give exact comparisons: has specific orbital energy and stops outward at ; has zero specific orbital energy; has specific orbital energy and asymptotic speed . The second case has speed at . Doubling divides escape speed by , whereas doubling at fixed multiplies it by . Changing the test particle's mass changes but cancels from the escape speed.
The same initial distance can lead to strikingly different orbits. Let and launch tangentially in one orbital plane. Then periapsis is the launch point, specific angular momentum is , andwhere is true anomaly. These follow by combining the initial specific orbital energy with the orbital eccentricity relation and the Kepler orbit equation. With and , the initial speeds , , , and give : a circular orbit, an elliptic orbit with apoapsis distance , a parabolic trajectory, and a hyperbolic Kepler orbit. The two open paths have asymptotic speeds zero and respectively. Their different directions at large distance are part of the Kepler orbit, not an extra scalar escape threshold.
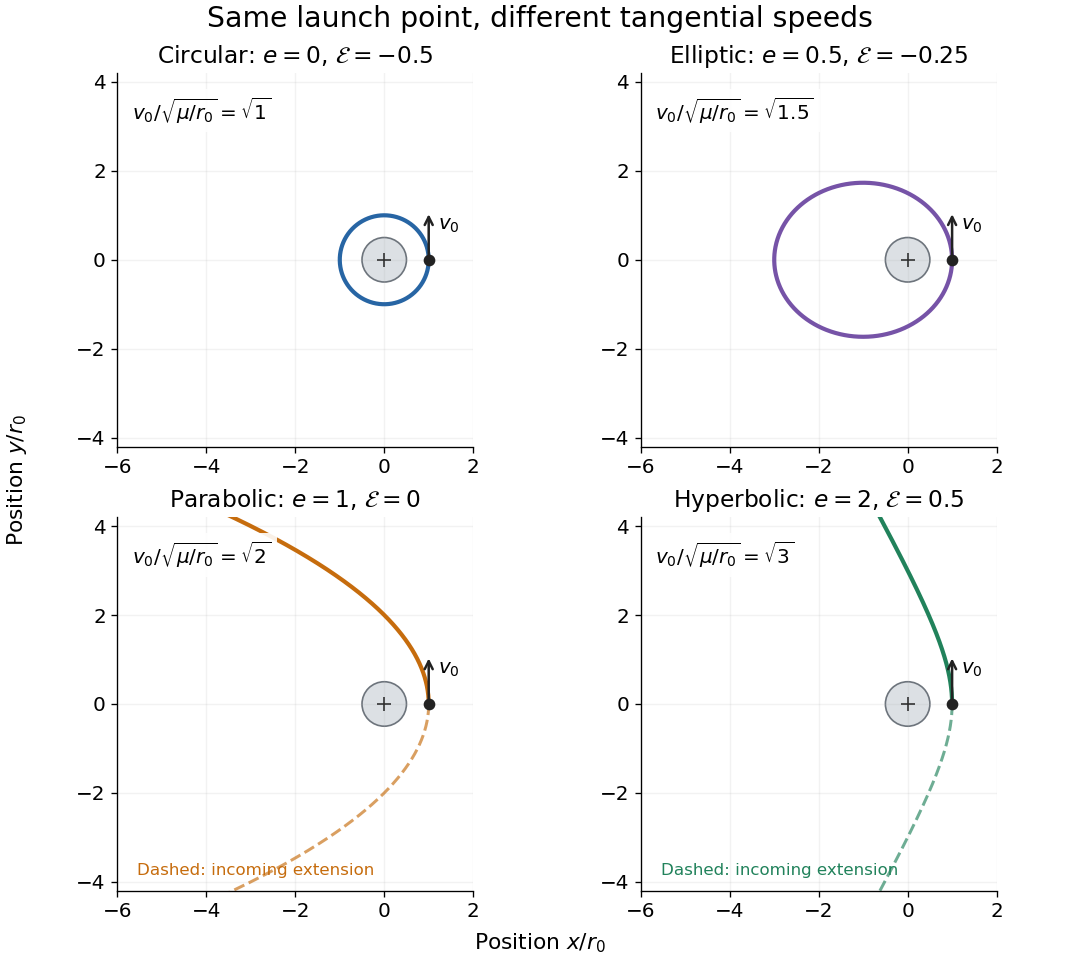
Tangential launches give circular, elliptic, parabolic, and hyperbolic Kepler orbits
. All panels use equal spatial scales, a fixed attracting centre at the origin, a launch point , and an initially upward velocity. The gray body's radius is stipulated as , so all displayed paths remain exterior. Colored solid curves follow motion after launch; dashed curves on the open orbits are their incoming extensions, not an additional part of the launch. Open curves continue beyond the viewing window. The normalized launch speeds and specific orbital energies are computed from the stated isolated model. Details.“Arrives at infinity with zero speed” is an asymptotic statement. For outward radial motion at zero specific orbital energy,Every finite distance takes finite time, but as . There is no instant of rest at an infinitely distant destination. Differentiating the displayed solution gives , independently checking Newton's second law. In the synthetic example, reaching takes exactly . For nonzero specific angular momentum, the Barker equation gives the corresponding infinite-time limit along a parabolic trajectory. Positive-energy escape also takes infinite time to reach infinity; it retains nonzero asymptotic speed.
For a circular orbit, gravity supplies centripetal acceleration, giving . ThusA body in a circular orbit is bound despite its continuous free fall. At the same , escape needs twice its kinetic energy per unit mass. An instantaneous forward tangential velocity increment from the circular orbit requires , rather than the full escape speed from rest. In the synthetic example this is exactly .[ref]
13.4 Satellite Orbits and Energy. §13.4, “Circular Orbits” and “Energy in Circular Orbits”: centripetal balance and negative total energy
Escape speed is a coasting threshold, not a required continuously maintained speed or a measure of rocket propellant. A powered vehicle can start at rest and acquire energy gradually. The rocket equation relates an ideal velocity increment to rocket exhaust speed and rocket mass ratio; rocket thrust, drag, and the timing and direction of propulsion affect a real ascent. Rotation also changes the relation between surface-relative velocity and the inertial frame used in the calculation.
Reaching another body is a finite-destination spacecraft trajectory problem. In the synthetic radial example, a launch at reaches while remaining bound. A spacecraft can similarly encounter the Moon on a bound geocentric transfer; actual planning must include the Moon's gravity, target motion, arrival velocity, and any propulsion needed for capture. Escaping Earth alone does not imply escaping the Sun, because the relevant reference frame and attracting mass have changed. The isolated formula describes one gravitational well; a full mission requires more than its scalar threshold.
Operational evidence comes from reconstructing a spacecraft's motion. A ground antenna transmits a coded signal; the spacecraft returns it. Corrected round-trip time constrains distance, while the Doppler effect of a coherent carrier constrains the line-of-sight relative velocity. NASA's navigation account describes calibration of onboard turnaround delays before launch, calibration of ground delays before use, and corrections for the terrestrial atmosphere. Measurements over multiple stations and epochs constrain the orbit; range and Doppler effect alone do not directly give all transverse motion. Navigators compare a fitted spacecraft trajectory with later tracking and remeasure after propulsion to assess the maneuver. The account identifies radiation pressure and imperfect propulsion as disturbances. This provides practical checks of a dynamical model and its corrections, rather than a laboratory measurement of a universal escape speed. The simple inverse-square potential predicts an unpowered exterior arc; accurate navigation includes additional forces and measurement delays.[ref]
A spacecraft trajectory is the path traced by a spacecraft's position over time. An unpowered exterior arc can approximate a Kepler orbit; other bodies' gravity, radiation pressure, and propulsion can change it.
Orbit determination infers a body's position and velocity from observations and an equation of motion. It is an inverse problem; a residual of an inverse problem compares an observed readout with its modeled prediction.
For a sphere of radius and uniform mass density , with no surrounding mass and gravitational potential zero at infinity, the spherical shell theorem gives inside. Matching to the exterior point-mass potential gives . Since , the displayed relation follows for . Exterior shells leave the interior circular speed unchanged but deepen the potential and change the escape velocity; a uniform core alone is insufficient to determine escape.
An equipotential surface is a level set of a scalar potential. Its gradient and the corresponding conservative force are normal to every smooth level surface.
An equipotential curve is a planar level curve of a scalar potential. Where the gradient is nonzero, its tangent is perpendicular to that gradient. In potential flow, it is therefore perpendicular to the velocity field; this distinguishes equipotential curves from streamlines.
A turning point of one-dimensional motion is a position where the kinetic energy and instantaneous velocity vanish before the direction of motion reverses.
Binding energy is the energy required to separate a bound state into specified free constituents. For an electron bound in a chemical atom, neglecting this cost is an assumption of the free-electron Compton scattering model.
In Newtonian gravity, assembling a spherical mass distribution from shells gives the gravitational potential energy in the title formula, with zero at infinite separation. Its magnitude measures the gravitational contribution to binding. The full energy accounting of a hot self-gravitating body also includes its internal energy; the virial theorem relates the two in equilibrium. A uniform-density sphere has .
If all mass of a spherical body lies within radius , then in the shell-assembly integral for its gravitational binding energy. Therefore . The inequality is strict for an extended interior mass distribution; a thin shell gives equality. Dividing by a stipulated luminosity gives a lower bound on that reservoir-to-luminosity ratio. A Kelvin-Helmholtz cooling time also needs a structure model and the accessible fraction of gravitational release.




