For a rigidly rotating prescribed vacuum path, use spatial coordinates attached to the apparatus and laboratory time . At a path point , the local apparatus velocity is . A light displacement has instantaneous laboratory displacement , up to the common rotation of the spatial axes. The null condition is thereforeWrite . To first order in , the positive root isReversing the path reverses the dot product term but leaves the leading path-length term unchanged. Subtract the two return times and use the scalar triple product identity:This is a line integral version of the Sagnac area law; the vector area identity also follows from Stokes theorem. For a mirror-defined polygon the actual ray paths move slightly as the mirrors rotate; the stationary optical path at zero rotation gives the same first-order result. The prescribed-path calculation is an idealization, not an exact finite-speed formula for every moving-mirror layout.
The dot product explains the geometry: only the projection of the oriented vector area along the angular velocity contributes. A planar loop whose normal vector is perpendicular to has zero leading delay. For repeated traversals with the same orientation, the signed vector areas add; oppositely oriented lobes can cancel even when the total unsigned area is large. Equal perimeter alone does not imply equal response. A constant translational velocity contributes nothing to this leading closed-path line integral, since .
For a stationary rotating apparatus driven by a source with optical coherence and proper frequency , define . The source wave phase advances by between the emission times of the two contributions that meet at one readout spacetime event. Define the signed phase lag of the contribution and the corresponding displacement in units of one interference fringe byThe sign of a photographed spatial displacement also depends on the imposed fringe orientation; this definition fixes the theoretical sign through the delayed beam. In an equal-amplitude output, a representative light intensity is , where sets the chosen spatial interference fringe spacing . Moving by shifts the pattern by one fringe. A fixed output exactly at a bright or dark fringe has zero first-order intensity slope, so a known phase bias or a spatial fringe readout is useful for determining a small signed delay.
Choose a square of side , a rectangle by , and , with angular velocity parallel to the positive normal vectors. Both perimeters are , but the areas are and . Using , the leading predictions areThese are original model choices and predictions, not measured points. The square has times the response despite the equal path lengths. Reversing from to gives : the displacement magnitude between opposite rotations is twice the displacement magnitude from rest. Confusing these two comparisons introduces a factor-of-two error.
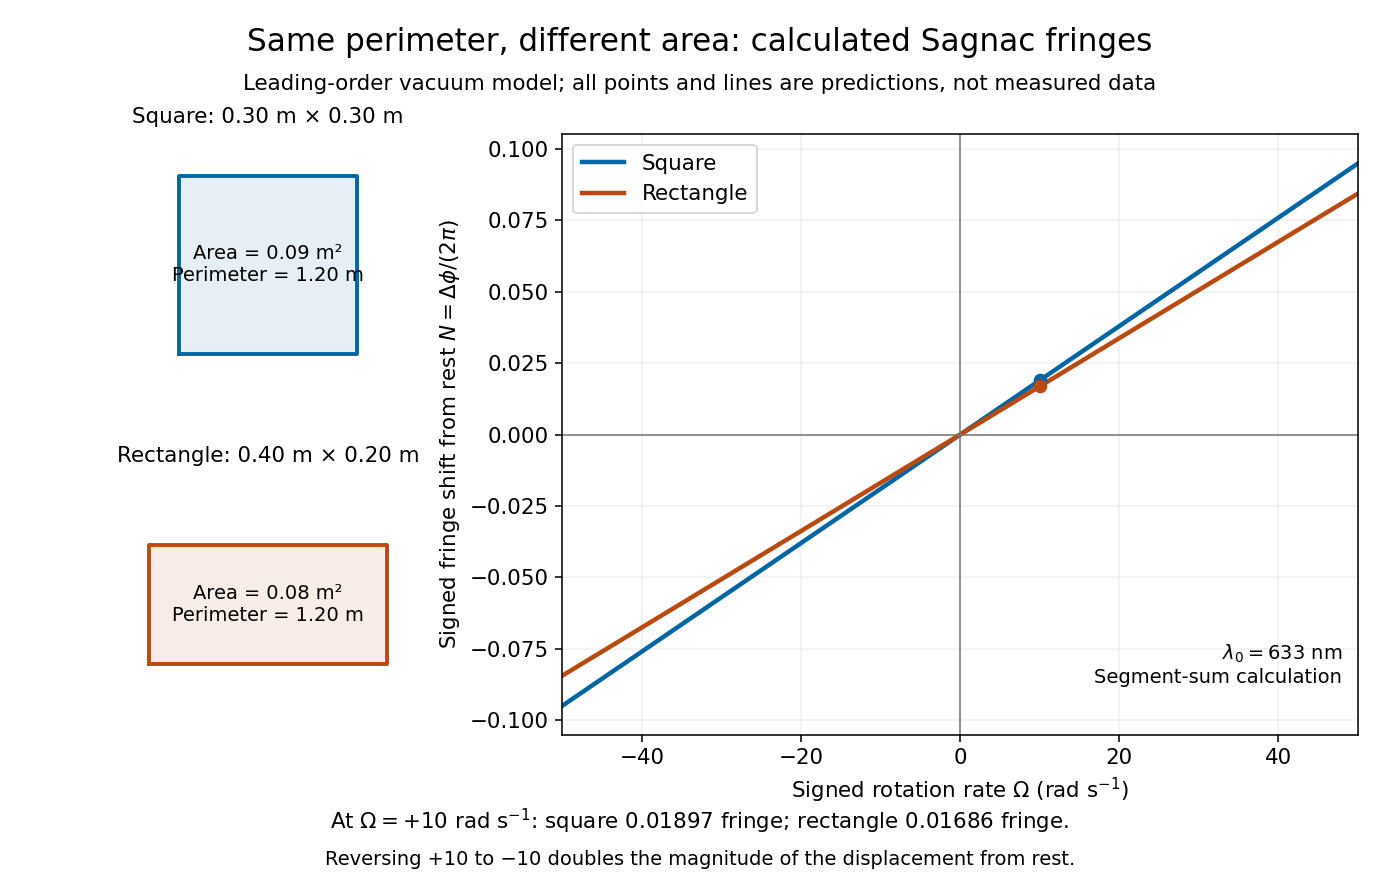
Independent path-segment calculation of the predicted fringe displacement for two equal-perimeter loops
. The generator sums along each straight segment, rather than inserting the enclosed area into the answer. Both loops are oriented counterclockwise. Lines and marked values are leading-order vacuum model predictions; no historical measurements are plotted. Details.
Articles by others on the same topic
There are currently no matching articles.