Feasible triangle with a squared-distance objective
ID: feasible-triangle-with-a-squared-distance-objective

Take the decision domain and minimize the objective functionEach inequality permits a closed half-space; their intersection is the filled triangle with vertices , and , including its edges. The feasible region is a compact set and a convex set. The point is a feasible point, but its objective function value will not be best. Without the optimization constraints, the unique global minimum is at with value . That point is infeasible because .
The objective function is the squared Euclidean distance from . Its positive level sets are circles centered there. Expanding a circle from that center, the first contact with the feasible region is at , with objective function value . Thus the optimum is the Euclidean projection onto a convex set of the target . Squaring a nonnegative Euclidean distance preserves which point is nearest.[ref]
Convex Optimization by Stephen Boyd and Lieven Vandenberghe. §8.1.1, printed p. 398: squared Euclidean projection onto a polyhedron and half-space projection formula
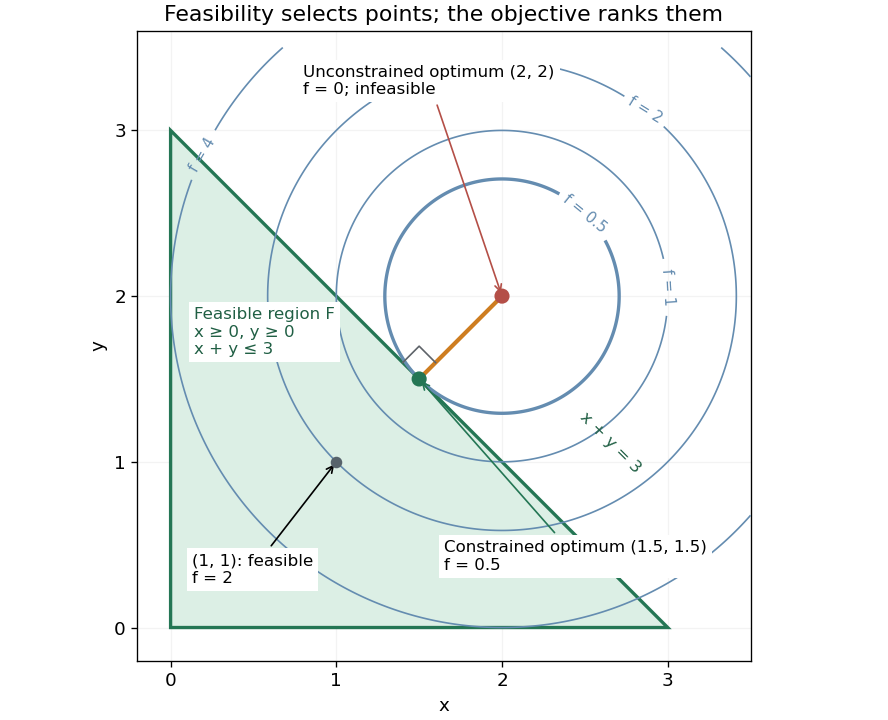
Feasible triangle with a squared-distance objective: the first attainable level set has value 0.5 at (1.5,1.5)
. Details. 
Here is a direct certificate, without relying on the picture. Put and . The objective function becomesEquality requires and , so the unique optimum is . At this point is an active constraint, while and are strict. An active constraint identifies a tight restriction at a specified point; it alone does not establish optimality. For example, has the same tight sum restriction but objective function value .
For a check using the Karush-Kuhn-Tucker conditions, write the inequalities as , , . Their Lagrange multipliers at the optimum are . The gradient equation isFeasibility, nonnegative Lagrange multipliers and complementary slackness also hold. With this strictly convex function and affine optimization constraints, the Karush-Kuhn-Tucker conditions certify the unique global minimum.[ref]
Convex Optimization by Stephen Boyd and Lieven Vandenberghe. §5.5.3, printed pp. 243–244, equation (5.49) and sufficiency for convex problems
New to topics? Read the docs here!