Since the exponential factor is positive, equilibria must have and . Thus . At either point the Jacobian matrix is . At its eigenvalues are , so this is a saddle point. At they are : the linearization has a centre equilibrium.
The requested first-order approximation follows by putting , : and . The linearized system conserves , giving the approximate ellipsesHowever, the printed nonlinear system has a weak repelling focus at , rather than a centre. A centre in the linearization need not be a nonlinear centre. Here that distinction can be proved explicitly, without relying on the numerical drift in the figure.
Put , , and . The weak focus of an exponential polynomial planar system has the local positive functionExpanding the vector field through cubic order and differentiating givesThe cubic correction cancels the cubic terms in the derivative of , and the quartic correction leaves the positive radial term . Since is positive and the angular velocity stays near , small nonzero trajectories spiral outward. Equivalently the reversed system has a strict local Lyapunov function and an asymptotically stable equilibrium. In particular, a periodic orbit sufficiently near the equilibrium is impossible, because would have to increase strictly and return to its starting value. This proves the failure of the printed centre assertion while retaining its correct linearized ellipse calculation.
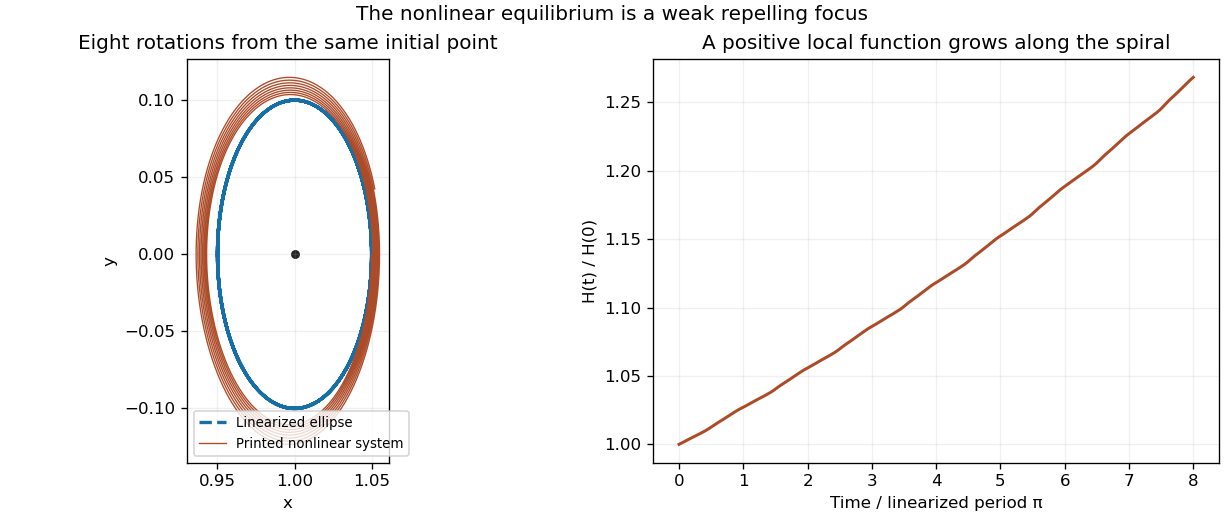
The linearized ellipses hide the nonlinear outward spiral
. Original fourth-order Runge-Kutta integration of the printed vector field, compared with its linearization from the same initial point. The local polynomial calculation, rather than the plot, proves the weak instability. Details.
Articles by others on the same topic
There are currently no matching articles.