Put and . The constant-force spatially gated motor producesThe limit is approached after the periodic steady state is established; at exactly arbitrary initially bound heads in inactive phase intervals need not equilibrate. The curve decreases from and has formal large- tail . Extrapolation of that tail beyond the small- detachment assumptions is not controlled.
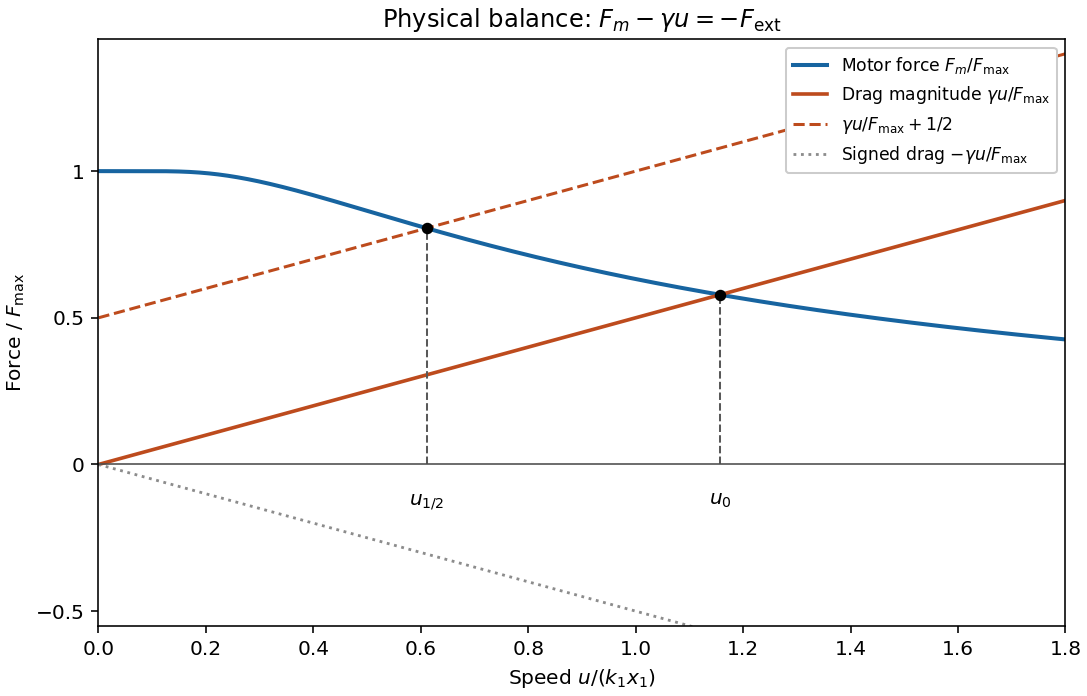
Sign inconsistency in the printed force balance. For a positive viscous drag coefficient , the signed drag force is . The printed cannot give the requested positive no-load contraction speed: both last terms are positive when . With , the left side starts at and may have zero, one or two positive roots depending on parameters; the requested usual load construction is not implied by that equation.
The physical linear-drag load curve for a spatially gated motor usesOn the same axes plot the positive drag magnitude and the decreasing motor force . The no-load speed is their intersection. For opposing load , intersect with the parallel raised line ; equivalently intersect with . Drop verticals to the speed axis. The loaded speed obeys . Each intersection is unique because decreases and increases. The signed drag is also indicated below the axis in the sketch.

Articles by others on the same topic
There are currently no matching articles.