A force is an interaction that changes momentum; in Newtonian mechanics it satisfies for constant mass.
In planar potential flow, encode a physical force by , using the same negative-imaginary-component convention as the complex velocity . The Blasius force theorem then expresses the force per unit span as a single contour integral. The encoding is a convention: the physical vertical component is the negative imaginary part of this complex number.
The vector sum of applied forces. To replace a force system on a rigid body by a single force, its line of action must also reproduce the original torque; a nonzero force couple cannot be replaced by one force.
An interaction described between spatially separated bodies without specifying a local contact mechanism. A successful mathematical force law and an account of its physical mediator are distinct explanatory achievements.[ref]
A specified relation giving a force from relevant positions, velocities or other physical variables. Combined with Newton's laws of motion, it constrains the possible motion.
A constraint force enforces a restriction on the allowed position or velocity of a mechanical system. For a bead sliding on a smooth wire, it has zero dot product with the wire's tangent vector. A moving wire can nevertheless do work because the bead's absolute velocity need not be along that instantaneous tangent vector.
An ideal concentrated force. In a one-dimensional distributed-load equation it is represented by its magnitude times a Dirac delta function.
A force density is force per unit volume, measured in . Pressure gradients, the divergence of a viscous stress and gravitational body force have this dimension in a local momentum balance.
A force between molecules, including effects of electrostatics, polarizability and London dispersion forces. Hydrogen bonds describe a directional interaction pattern rather than an additional fundamental force to add independently to all those components.
Interaction involving a quadrupolar charge distribution. benzene has no permanent dipole by symmetry but can still have orientation-dependent electrostatic interactions.
Two benzene molecules associated by dispersion and electrostatic interactions. T-shaped and parallel-displaced geometries are important low-energy arrangements; a single permanent dipole–dipole model is inadequate.
Short-range repulsion associated with the antisymmetry requirement for overlapping electronic states, related to the Pauli exclusion principle. It competes with attractive electrostatic and London dispersion forces at small intermolecular separations.
An existing charge distribution polarizes a neighbouring molecule, changing its electron density and interaction energy. The resulting interaction depends on the molecular polarizability and local electric field.
A force field specifies a force vector as a function of position and, when necessary, time, for a specified test body. It is a vector field. A time-independent conservative vector field has , where is the body's potential energy; its work along a path equals the decrease in . Position-dependent forces can have nonzero curl, so a scalar potential need not exist.
A propulsive force exerted on a body by an engine or another momentum-transfer mechanism. In a vehicle moving through a fluid, its direction need not coincide with the vehicle's actual velocity, and a transverse component can steer the motion. The component along the velocity contributes mechanical power ; a purely transverse component changes direction without doing instantaneous work. Rocket thrust is one particular mechanism and includes momentum carried by expelled material.
An entropic force is the part of a generalized force arising from the dependence of entropy on a coordinate. At fixed temperature, the system's force is , where is the Helmholtz free energy. If the internal energy is independent of the coordinate, the force is entirely entropic. For an ideal chain whose configurations become less numerous on extension, it acts toward shorter extension. The external tension holding the chain extended has the opposite sign. Thus the force depends on the statistical number of available configurations, even when the energy of each configuration is unchanged.
A force per unit length describes a distributed force on a filament and has units . For a charged filament with linear charge density and longitudinal current , the external Lorentz force is . Length, density and force must all refer to the same measurement frame. An infinite uniform filament generally has a finite force density but no finite total force.
A free-body diagram isolates a body and shows the forces exerted on it. A third-law interaction pair acts on different bodies and belongs in separate body diagrams.
An internal force is a force between members inside the chosen system boundary. Changing that boundary can change which forces are internal. Pairwise Newtonian mechanics interactions cancel through third-law interaction pairs in the system's total momentum balance.
An external force is a force exerted on a member inside the chosen system boundary by a body outside it. Changing that boundary can change which forces are external. Their sum changes the system's total momentum when its internal forces cancel.
Here gravitational weight means the force on a body due to gravity. In the Newtonian model, a body of mass in a uniform gravitational acceleration has gravitational weight , with magnitude . Its direction follows ; a buoyant force is a separate contribution to the body's net force. [ref].
Apparent weight measures support rather than the gravitational force itself. In an ideal scale model, it is the magnitude of the normal force exerted on the body. A scale calibrated to display mass divides that support force by its calibration value of .
Take upward as positive in a constant downward gravitational acceleration of magnitude . If a body stays in contact with a horizontal scale and accelerates upward at , Newton's second law gives , hence . At rest, . In common free fall, , so despite the nonzero gravitational weight . If the formula would require , ordinary supporting contact cannot realize it: the body loses contact instead.
Weightlessness is the absence of supporting or constraining forces that would give a body an apparent weight. It does not require zero gravitational acceleration. A freely falling cabin and a small freely falling object inside share the same acceleration in a uniform field, so neither needs to support the other.
The circular orbit as continuous free fall gives a sustained example. Real spacecraft have small residual relative accelerations from tidal forces, atmospheric drag force and onboard disturbances; the ideal common-fall explanation does not assert that every point in an extended spacecraft experiences exactly the same Newtonian gravitational field. [ref]
https://ntrs.nasa.gov/citations/20000083212. Ramachandran, Numerical and Experimental Investigation of the Effects of Acceleration Disturbances on Microgravity Experiments (2000), abstract: vibration, atmospheric drag and gravity-gradient effects
A restoring force acts toward an equilibrium when a body is displaced from it. In one dimension, taking displacement at equilibrium, this means for sufficiently small nonzero . An ideal linear spring has with positive spring constant , producing simple harmonic motion for a constant mass without damping. More general restoring forces need not be linear.
Tension is a pulling force transmitted along a taut string, rope, or similar body. For an ideal uniform string with linear mass density , constant tension sets the small transverse wave speed .
An ideal string of negligible mass and fixed length, transmitting tension when taut. In an ideal guide with no friction, the tension magnitude is the same on both sides: otherwise the force balance on an arbitrarily short massless segment would fail. Its fixed length gives a mechanical constraint relating the endpoint velocities. The two endpoint tension powers sum to zero when the guide is stationary; the string can transfer energy between connected particles without adding net energy.
The Van der Waals force is a distance-dependent nonbonded interaction between atoms or molecules, including dispersion and dipolar contributions. In the attractive nonretarded pair model, an interaction energy gives force magnitude . Macroscopic integration introduces a Hamaker constant; it does not replace the sign change and molecular cutoff needed at very short distances.
A pairwise-additive approximation integrating microscopic dispersion interactions over body volumes. For two nonretarded homogeneous half-spaces, it gives interaction energy per area .
The nonretarded attractive normal pressure obtained by differentiating the half-space interaction energy per area: . Total force additionally requires the interacting area.
Named after Fritz London, this is an attractive interaction between fluctuating electric dipoles of atoms or molecules, present even without a permanent dipole. At large separation compared with atomic size in the nonretarded regime, the dipole interaction scales as and its second-order ground-state energy correction is negative and scales as . Differentiating the energy gives an attractive force of magnitude . The short-distance overlap regime and the very-long-distance retarded regime require different descriptions.
For pairwise-additive nonretarded molecular attraction and equal solid number densities , let and let be the distance from a sphere centre to a planar half-space. Integrating the atom–half-space potential energy givesFor , expansion gives the displayed expression. Equivalently expand over the sphere: its odd moments vanish and . This yields the first relative correction . In the opposite near-contact limit, the gap gives and the sphere-plane dispersion force magnitude . The two limits use different distances and must not be confused.
For a sphere of radius at separation from a half-space, pairwise integration of the attractive molecular potential gives . Equivalently, integrate the planar disjoining pressure magnitude over the local gap . Across a third medium the effective Hamaker constant can instead correspond to repulsion; state its sign convention explicitly.
Static friction is the tangential contact force that maintains zero contact slip. “Static” describes the contact state: both surfaces can move together in the chosen inertial frame. In the ideal dry-contact model, the actual static friction adjusts to the equations of motion, subject to a bound, rather than always taking its maximum value.[ref]
6.2 Friction. Static and Kinetic Friction; Magnitude of Static Friction, equation 6.1 and responsive-force paragraph
Here is the magnitude of the normal force and the coefficient of static friction. Equality means limiting static friction; it is a threshold, not an instruction to replace every unknown contact force by .For a stipulated example, place a nonrotating block initially at rest on a stationary horizontal surface. Take gravitational acceleration and coefficient of static friction , with no other vertical force. The vertical force balance gives , so the largest allowed static friction magnitude is . Choose right as positive and apply a horizontal force . Remaining at rest requires Newton's second law to giveAt , the static friction is ; at , it is . Both states have zero acceleration. At , balancing would require , outside the bound, so this initially resting block cannot remain at rest. Its subsequent acceleration requires a kinetic friction law; setting after contact slip begins would still use the wrong contact state. At exactly , the ideal inequality still permits rest at the threshold. These are model calculations, not measured material properties.
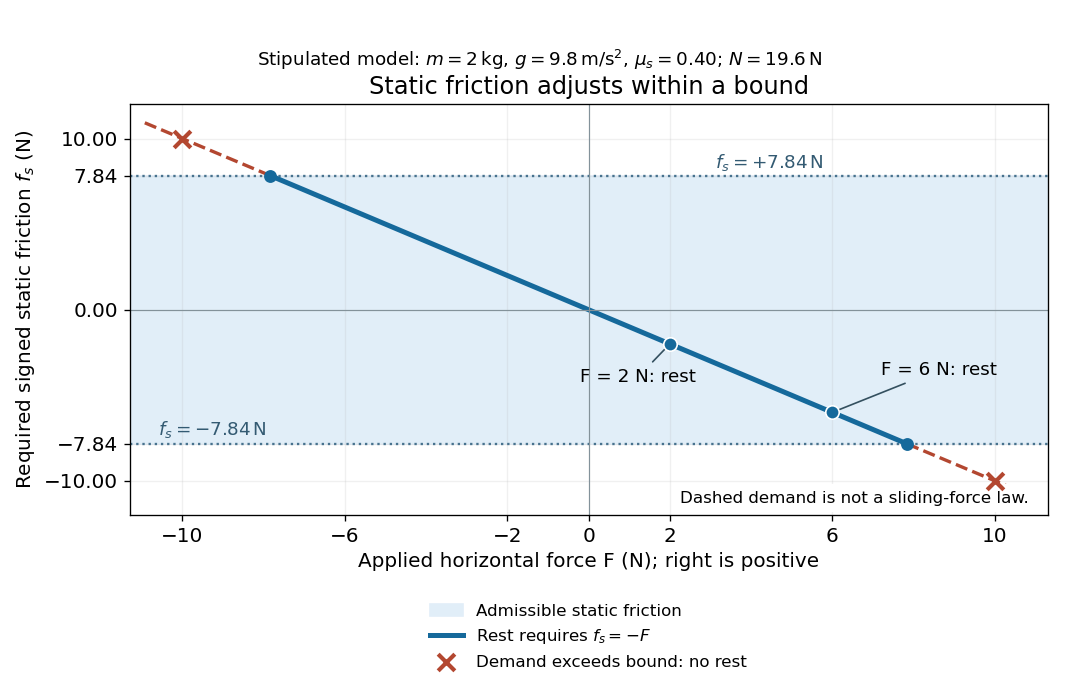
Static friction adjusts to the applied force within its admissible bound
. Original signed horizontal model for the stipulated block: the shaded band is the allowed static friction, the solid line satisfies force balance, and the dashed line shows the demand outside that band. The crossed points at are impossible static demands, not sliding forces. Details.The toy model used in kinetic friction makes the contact-state distinction explicit: , , and coefficient of kinetic friction . On stationary ground, an initially resting box pushed right with has . At it cannot remain at rest; once it slides right, and . At , rest is allowed with , whereas an already right-sliding box has and . The applied force alone does not specify the friction branch: contact slip and motion history matter.
For a flat contact with two tangential directions, the bound applies to a vector norm, not separately to each component:For the stipulated bound, balancing horizontal components and requires a force magnitude , which is allowed. Components and require , which is forbidden even though each component separately is below . This circular bound assumes the same coefficient of static friction in every tangential direction. Near impending contact slip, the limiting static friction opposes the relative contact motion that would otherwise begin. Once actual contact slip exists, kinetic friction instead opposes its tangential relative velocity, which need not have the direction of the body's center of mass motion.
The normal force must also come from the equations of motion. On horizontal ground, an upward pull of magnitude at angle above horizontal gives, for a block remaining at rest with no other forces,The sine component unloads the contact and the cosine component demands tangential support. These equations require ; if the supporting contact opens, this dry-contact model cannot supply a negative normal force. For the stipulated block and , the positive threshold is , with and . A downward pull increases instead. An inclined plane gives another reason why is not always .
To solve a new problem, impose zero contact slip, find the required static friction and normal force from the equations of motion, then check the bound. A demand inside it permits that contact state; a demand outside it rules the state out. For an ideal driven tire undergoing rolling without slipping on stationary ground, a forward static friction can accelerate the vehicle. Its role is to prevent contact slip, rather than to oppose all motion of the whole body.
Nor does the word “static” by itself make friction do zero work. The contact power delivered to a body is , a dot product with its material contact-point velocity in the chosen inertial frame. At an ideal contact undergoing rolling without slipping on stationary ground, , so this power is zero. For a rigid body, adding the translational and rotational contributions gives , where is the contact torque about the center of mass and its angular velocity. Counting only the first term omits the rotational contribution.
At a moving contact with zero contact slip, the two material contact points share a velocity that can be nonzero. For instance, a nonrotating block moving with an accelerating belt receives positive contact power when the belt's rightward velocity and rightward static friction are positive. The belt receives by Newton's third law. These contact contributions sum to zero in the ideal no-slip model, while the block's kinetic energy can increase. Zero contact slip and zero work on each body are different conditions.
The limiting angle between a contact resultant and the compressive normal force when static friction obeys . Resolving the resultant gives , so admissible contact forces lie within a cone of half-angle about the inward normal. A contact-force magnitude is generally , distinct from N.
For symmetric upper faces inclined by alpha from the vertical, inward normals push partly downward. Limiting upward friction gives vertical support . Balancing weight yields the displayed minimum normal grip. The corresponding minimum total contact magnitude per face is . It is achieved at the limiting friction angle. The formula assumes symmetric contacts with cancelling horizontal force and torque and positive denominator.
The coefficient of static friction is the nonnegative dimensionless quantity , with , in the ideal dry-contact model. It characterizes the pair of surfaces under specified conditions. It describes the largest supported tangential force, whereas the coefficient of kinetic friction describes sliding. It is an empirical approximation, not a universal material constant.[ref]
In the horizontal example, an observed state balancing a pull would only establish under the model assumptions. It would not establish : the actual static friction is below its limit. Identifying the coefficient needs an onset measurement, such as inclined-plane measurement of static friction, or the starting peak in a suitably controlled horizontal pull. The sustained sliding part of constant-speed measurement of kinetic friction measures a different coefficient.
In a simple grain model, the existing name granular friction coefficient represents resistance to downstream motion. That model excludes lift and detailed contact torques. Its coefficient should not automatically be identified with a bulk pile's angle of repose: individual contact geometry and collective rearrangement can matter.
An inclined plane tilted slowly from horizontal turns a coefficient of static friction into a critical angle. Assume a nonrotating block on a stationary, rigid, dry surface, with gravitational weight and the contact forces as its only forces. Take to be the angle between the uphill surface direction and horizontal. Let be a unit vector pointing uphill and a perpendicular unit vector pointing outward from the surface. Resolving the gravitational weight givesThe angle between the downward vertical and the inward normal is also . Thus the inward component uses cosine and the downhill component uses sine. These are components of one force, not two additional forces.
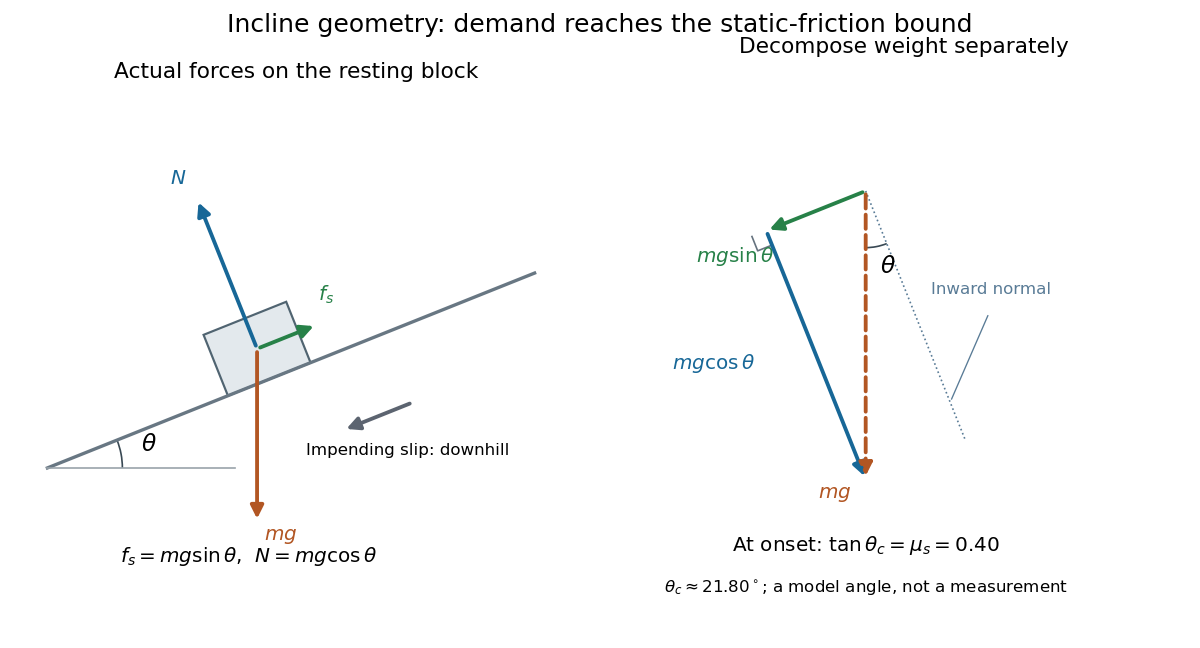
Before downhill contact slip, zero acceleration and Newton's second law requireThe required static friction points uphill. Substituting into the bound and dividing by the positive givesThe tangent function increases on this range of angles, so the last admissible resting angle isThe inverse tangent takes a dimensionless quantity to an angle. At equality the ideal model still permits a limiting resting state; increasing further excludes it. At a smaller angle, is the demand ratio, not the coefficient of static friction.[ref]
For the stipulated , and , the critical angle is approximately . At , and , comfortably below the bound . At , maintaining rest would require , but the bound is only : rest is impossible. At , and . Notice that the limiting tangential force here is smaller than the horizontal limit because tilting reduces the normal force.
Cancellation of mass makes this relation useful: the ideal critical angle tests a contact coefficient without needing a calibrated force gauge. Doubling the block's mass doubles both demanded static friction and its bound, leaving unchanged if is unchanged. This is a testable model prediction. It need not survive a change in surface condition, a direction-dependent coefficient, appreciable deformation, or vibration.
The derivation also assumes continued contact and that sliding occurs before tipping or rolling without slipping. The resultant contact force must act within the supporting footprint so that the block can satisfy torque balance; a tall block may tip first. No extra tension, imposed tangential pull, or lift is included. In a slowly raised apparatus, quasistatic process means that motion of the board contributes negligible inertial forces while locating the threshold. Once downhill contact slip begins, a constant-velocity sliding angle would concern kinetic friction, not the onset of static friction.
A university laboratory places an aluminium block on a Teflon-lined wooden board. For its inclined plane stage, the pulley and block string are removed; a rope and hook connect the board to a crank. The block is placed gently near the sheet's middle without prior sliding. Smooth cranking raises the board; a – protractor reads the smallest angle at which sliding begins. Four readings are taken without added load, then four each with , , and added symmetrically at two screws. Removing the string isolates gravity-driven onset; gentle placement and smooth raising avoid premature disturbance.[ref]
Infer under the assumptions of static friction on an inclined plane. Repetition tests onset scatter; added loads test coefficient constancy. No measured onset values are supplied here.
For a replication, additionally check the protractor zero with a level board, retain the same contact face and surface region, and observe whether tipping or rolling precedes sliding. These are proposed additional controls. A finite angle resolution and the disturbance needed to detect first motion limit the estimate; a slow ramp does not by itself establish perfectly rigid, dry, or direction-independent contact. At the model's threshold, differentiating the tangent function gives , with in radians. A hypothetical measurement error would therefore correspond to approximately in the inferred coefficient at first order. This sensitivity calculation is not an uncertainty reported by the laboratory.
Force balance equates the rate of change of momentum to the sum of applied forces. A static continuum segment with internal resultant and force density obeys .
Newton's laws of motion consist of inertia in an inertial frame, the relation between net force and change of momentum, and equal-and-opposite pair forces. The following three children state the individual laws.
Testing requires independently constrained force laws, mass assignments, initial conditions and a common family of inertial frames. Defining the net force separately for every observation by cannot test Newton's second law. With interaction parameters fixed, the same equation predicts new trajectories. Likewise, zero net force implies uniform motion within the second-law framework, but the existence and empirical identification of its inertial frames are extra content. Pairwise Newton's third law adds a constraint not supplied by the individual second-law equations.
In an inertial frame, a body with zero net external force remains at rest or moves with constant velocity. For a point mass of constant positive mass, write the net external force as the vector sum of all external forces on that body:Here and are the position and velocity at time . The zero net external force must hold throughout the interval, not merely at one instant. Both the magnitude and direction of the velocity stay fixed: constant speed along a curved trajectory still involves acceleration. Rest is the case . For an extended closed system, the analogous statement concerns its center of mass; zero net external force need not prevent its parts from moving relative to one another.
The short mathematical argument is to use Newton's second law with , then take the integral of and of . This gives the two constants fixed by the initial position and velocity. The physical content also includes the existence of inertial frames in which these relations apply; an arbitrary accelerating reference frame need not show constant velocity for a body with zero actual net external force.
The useful question is therefore which forces change the motion, rather than which force keeps it going. A free-body diagram may show several nonzero forces whose vector sum is zero. Equal opposing forces on the same body can balance; a third-law interaction pair acts on different bodies and cannot be cancelled within that one body's diagram.
In 1687, Isaac Newton stated Law I in Philosophiae Naturalis Principia Mathematica: a body's rest or uniform straight motion persists unless impressed forces compel a change. The following paragraph identifies air resistance and gravity as influences on the trajectory of a thrown body. The vector equations above are a modern expression of the law, not a quotation of his notation.[ref]
Axiomata sive leges motus. Isaac Newton, Philosophiae Naturalis Principia Mathematica (1687), Axiomata sive leges motus, printed p. 12: Lex I and the following projectile paragraph; normalized transcription
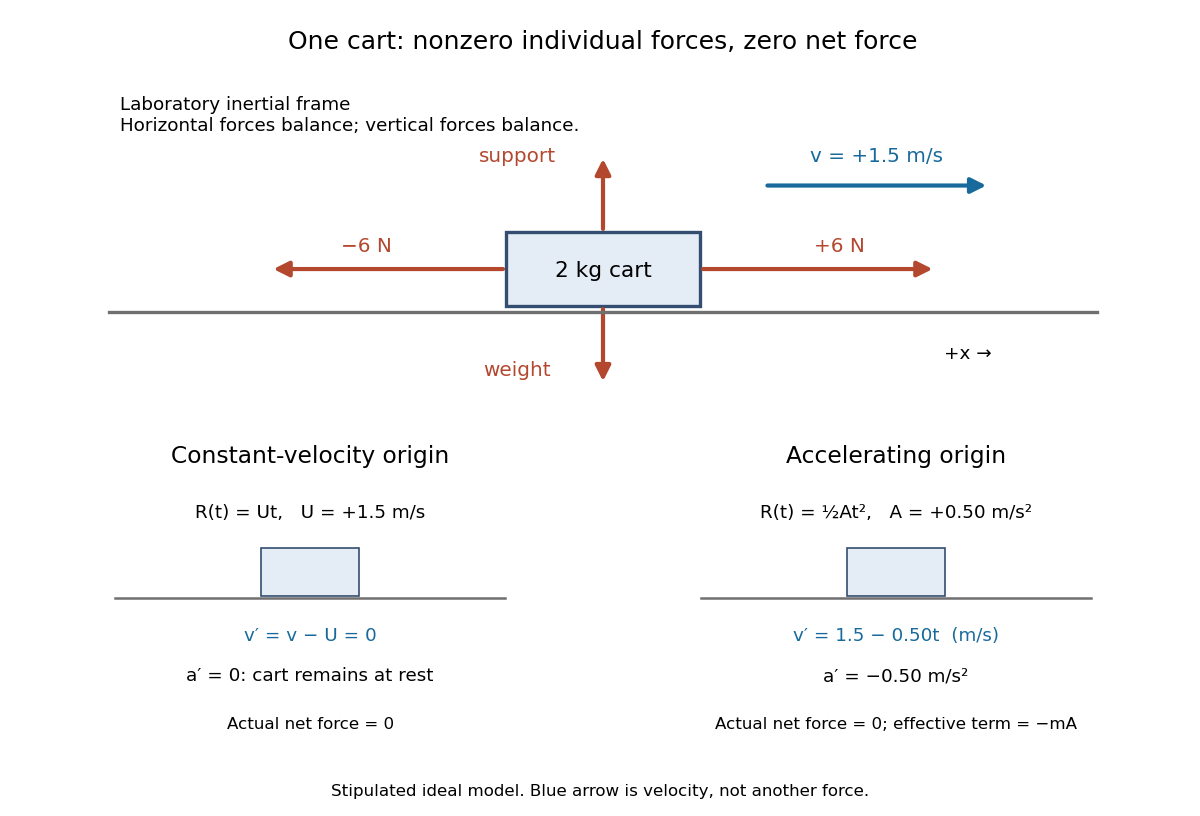
Consider a stipulated ideal cart modeled as a point mass of mass on a horizontal track in a laboratory inertial frame. Its initial position is and its initial velocity is to the right. Independent devices exert horizontal forces and on this same cart. Its upward support force balances its downward gravitational weight; no other forces contribute. Rotation and deformation are excluded from this model.After , the cart is at , still moving right at . Starting the same model at rest instead would leave it at rest. Force balance determines the zero acceleration, while the initial velocity determines whether the cart moves.
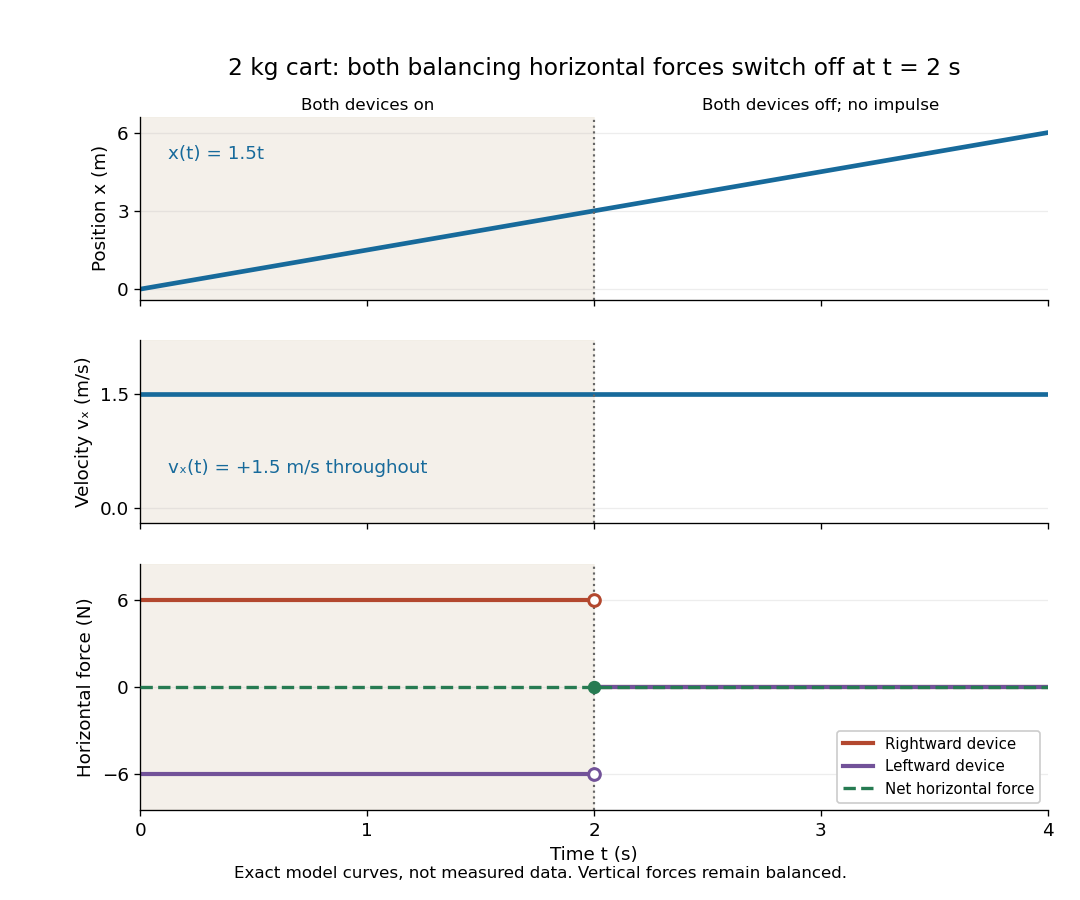
For the plotted model, both horizontal devices are switched off simultaneously at , with no impulse. The support and gravitational weight remain balanced. The individual horizontal forces change, but their sum stays zero on both sides of the switch, so the velocity stays continuous and unchanged. Switching off just one device would be a different model with a nonzero net external force.
An actual teaching experiment in Arbor Scientific's The Level Air Track uses one glider, an air track, two photogates, and a ruler. Turn on the blower and place the glider near the middle. Adjust the feet until it does not drift when released. Put the photogates at least half a track length apart and align them with the glider's flag. Measure the length that interrupts the beams. Give a gentle push, let go, and record each beam-blocking time . The readout is the pair of speeds . The worksheet asks how those speeds compare, which forces remain after the push, and which interaction the air track minimizes.[ref]
The motivating contrast is between a brief push and the subsequent glide. The air cushion reduces contact friction; it does not remove the downward gravitational weight or the upward support force. Similar successive speeds after release are consistent with a small horizontal net external force, rather than with a continuing push. The experiment approximates the zero net external force model over a finite track and observation interval.
To strengthen the documented procedure, use independent measurement calibration: check the flag length and each timer against a known length and time reference; measuring sets the length scale but does not calibrate the timer. Repeat launches in both directions without contact during the timed passage, and check for drift at several track locations. These are additional controls, not reported steps or measured results in the worksheet. A residual inclined plane produces a downhill component of gravitational weight with the same laboratory direction on both runs; friction and drag force oppose the direction of travel. Reversing the launch can therefore help distinguish these effects.
A photogate directly measures a beam-blocking time; is an average speed during that passage, not an exact instantaneous velocity. Assign the direction separately. Equal readings at two gates do not prove zero acceleration everywhere between them: opposing changes could cancel. Measurement uncertainty from timer resolution, an incorrectly measured flag length, residual slope, airflow disturbances, and remaining friction or drag force limit the inference. No measured glider speeds are assumed here.
Constant velocity depends on the reference frame. For nonrotating axes and a moving origin of laboratory position , subtracting that origin givesIf with constant velocity , the Galilean transformation leaves acceleration unchanged. The cart moving at in the laboratory is at rest in a frame moving right at . Both descriptions obey Newton's first law.
Instead choose an origin with , where the stipulated constant points right. The same cart hasAt , the cart is instantaneously at rest relative to this accelerating origin, but its relative acceleration is nonzero. In this translating accelerated reference frame, Newton's second law must include the effective inertial force . This term accounts for the accelerating coordinates; the actual external forces on the cart still sum to zero. No rotation-dependent terms are present because the axes remain parallel to the laboratory axes.
In an inertial frame, a point mass of constant mass obeysThe net force is the sum of all forces acting on that body; momentum, velocity and acceleration refer to the same reference frame. A force changes velocity, rather than sustaining it: zero net force implies constant velocity, including a nonzero one. Doubling the net force at fixed mass doubles acceleration; doubling mass at fixed net force halves it. [ref]
https://ocw.mit.edu/courses/8-01sc-classical-mechanics-fall-2016/mit8_01scs22_chapter7.pdf. MIT mechanics, Chapter 7, section 7.3
For example, an otherwise balanced block of mass receives a constant horizontal net force for . Its acceleration is , so its velocity changes by . Equivalently, the impulse is , and . Starting from rest, its displacement during the pulse is . After the pulse, zero net force leaves it moving at constant velocity.
Applying the law therefore requires both a specification of the net force and initial conditions. In the harmonic oscillator example, the force is , so Newton's second law becomes a differential equation for position. In an accelerating reference frame, the measured relative acceleration includes a contribution from the frame's own motion; the equation of motion in a rotating frame illustrates the extra terms required.
Constant mass is essential to the displayed form. A variable-mass system exchanging matter also exchanges momentum; its balance includes the entering or leaving matter's velocity. Simply differentiating and equating it to external force on that open body can omit this flux. The existing variable-mass system equation specifies the needed correction.
In the 1687 Principia, Newton's second law was stated in terms of change of motion proportional to impressed force, directed along that force. Its original statement is verbal; the derivative equation above is modern notation. [ref]
Axiomata sive leges motus. Philosophiae Naturalis Principia Mathematica by Isaac Newton; Newton, Axiomata sive leges motus (1687), Lex II
An idealized front at distance down a uniform slope entrains stationary material so that its moving mass is proportional to . Its linear momentum balance is , where . Multiplying by gives . Every forward-moving branch tends to as , and . Acceleration is smaller than the constant-mass downslope value because some momentum accelerates newly entrained material.
In the pair-interaction model of Newtonian mechanics, two bodies exert equal and opposite forces on each other:Both vectors are expressed in the same inertial frame at the same time. The subscripts name the agent and the recipient: acts on , and acts on . These are forces on different bodies, so they cannot cancel in the net force on either body. Newton's second law still uses all the forces on the particular body whose acceleration is sought. Identifying this third-law interaction pair does not require the bodies to be isolated: additional external forces can act at the same time.
The distinction makes Newton's third law useful both for drawing a free-body diagram and for deriving momentum conservation. A body-by-body calculation retains one member of each third-law interaction pair; a calculation for a collection containing both bodies cancels that pair in the total momentum balance. Equal interaction forces consequently coexist with nonzero, generally unequal accelerations.
Isaac Newton stated the equality and opposition of mutual actions in Law III of his 1687 Philosophiae Naturalis Principia Mathematica. The explanation distinguishes equal opposite changes of momentum from changes of velocity, which are inversely proportional to the bodies' masses when other influences are absent. Corollary III then explains why mutual interactions preserve the signed total momentum. The equations here are modern notation for that distinction. [ref]
Axiomata sive leges motus. Isaac Newton, Philosophiae Naturalis Principia Mathematica (1687), Axiomata sive leges motus, printed p. 13, Lex III and its explanation; pp. 16–17, Corollarium III
The instantaneous body-pair equation has a scope: use it for the mechanical interactions assumed by this Newtonian mechanics model. In electromagnetism, bodies can exchange momentum with an electromagnetic field; their instantaneous mutual forces need not sum to zero. Momentum conservation then accounts for electromagnetic field momentum as well as matter, and for momentum crossing the chosen boundary. This complication occurs in classical electromagnetism, without invoking quantum mechanics.[ref]
A third-law interaction pair consists of the two forces belonging to the same mutual interaction, with their agent and recipient exchanged. The names action-reaction pair do not imply a delay: in the instantaneous model, the two forces occur together. Test a proposed pair by naming both bodies and the interaction, rather than merely noticing equal magnitudes and opposite directions.
For a book resting on a table, the table's upward normal force and Earth's downward gravitational weight both act on the book. They can balance in the book's free-body diagram, but they are not a third-law interaction pair. The partner of the table's normal force on the book is the book's downward contact force on the table. The partner of Earth's gravitational force on the book is the book's gravitational force on Earth. Their equality does not require equal accelerations: Earth's much greater mass makes its response correspondingly smaller for a given net force.
Similarly, friction on a sliding block from a surface is paired with friction on that surface from the block. For the collection containing only the block, that friction is an external force; including the contacting surface makes both members internal forces. Changing the collection changes the bookkeeping of momentum, not the physical interaction.
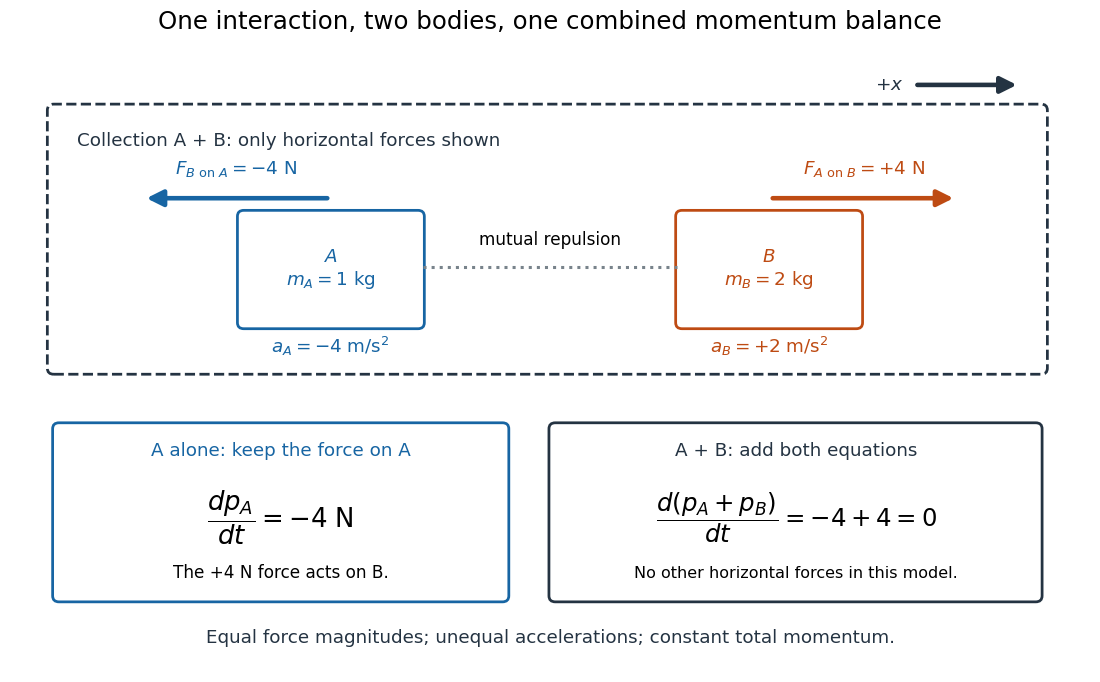
Equal opposite interaction forces act on different bodies and cancel only in the combined momentum balance
. Original one-dimensional model with right positive, and . The upper arrows are the mutual forces; the lower panels retain the force on alone and add both bodies' momentum equations. Only horizontal forces are shown; balanced vertical support is omitted. Details.Choose right as positive and let two carts have total moving masses and , including any attached apparatus. At an instant when their repulsive interaction has magnitude , assume no other horizontal forces. Then Newton's third law gives and , while Newton's second law givesThe smaller mass has the larger acceleration magnitude. For a nonzero interaction and zero other horizontal forces, . Meanwhile in force units. The two carts' velocities change while total momentum stays constant.
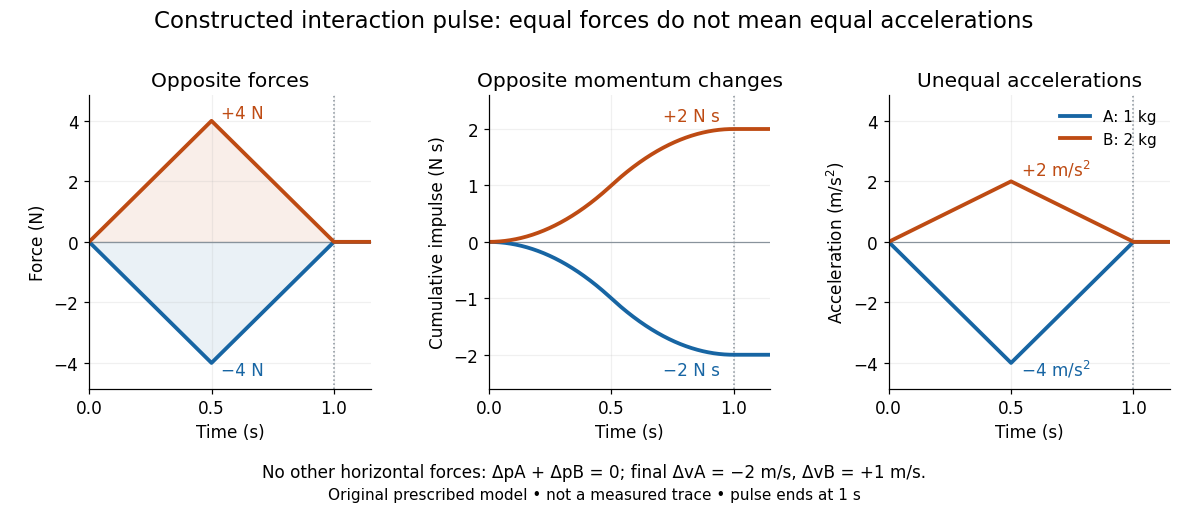
To distinguish an instantaneous force from its accumulated impulse, prescribe an original triangular interaction pulse lasting :This chosen pulse reaches at ; it is a constructed model, not an experimental trace or a claim about a particular bumper's material response. Its positive area is . The impulse-momentum theorem therefore givesOpposite impulses give opposite momentum changes, while the velocity changes differ because of the unequal masses. The cumulative positive impulse is during the first half and during the second half. Thus and cancel throughout the pulse, not merely at its endpoint.
For a fixed collection of two constant-mass bodies in an inertial frame, separate their mutual forces from the resultant external force on each:Adding the two Newton's second law equations and using Newton's third law givesThis is the proof of internal-force cancellation in system momentum. For more bodies, each internal force cancels with its partner once both appear in the sum. A boundary that excludes one interacting body leaves its force in the external force sum. A massive connecting spring must also be included, or its own changing momentum accounted for; its two endpoint forces are not automatically one third-law interaction pair between the carts.
Zero resultant external force gives momentum conservation; complete absence of external forces is sufficient but unnecessary. For constant total mass , the centre of mass has velocity and obeys . Internal interactions can move the parts apart while leaving the centre of mass moving uniformly.
Additional external forces do not invalidate the identified mutual pair. At the instant above, suppose a hand also exerts on . The mutual forces remain and , but the net forces become on and on . Consequently , , , and the centre of mass has acceleration . Pair equality by itself does not promise constant total momentum.
Oberlin College's documented demonstration uses a track, two collision carts, two force probes set to the range, added bars, and a laptop with a Vernier interface. Preparation consists of entering the measurement calibration, securing the force probes to the carts, and zeroing them. Rubber stoppers serve for elastic collisions, clay for inelastic collisions, and hooks with string for pulling. Comparing the two force records tests the mutual interaction; adding mass to one cart tests whether unequal masses change the equality. [ref]
Collision Carts and Force Sensors. Oberlin College, Collision Carts and Force Sensors, Apparatus, Description, and Notes: ranges, mounting, zeroing, attachments, and unequal-mass control
Vernier's force probe uses a bending beam with strain gauges; changing electrical resistance produces a voltage readout calibrated as force. Its manual recommends zeroing in the working orientation. If recalibration is needed, use an unloaded reading and a known suspended gravitational weight; for the range its example is giving . Re-zero after changing orientation. The manual quotes calibrated accuracy , distinct from the resolution of that range, and warns that the interface's data-collection rate can limit collision measurements. [ref]
The following sampling and control choices are proposed additions to that documented experiment. Level the track and check unloaded motion in both directions for slope and friction. Use a soft bumper and one interface for simultaneous records; start before contact and stop after separation. A trial sampling rate of , if supported, would put about 100 samples across a interaction. Increase the sampling rate and repeat until the peak and integrated impulse comparison are stable; a large sample count alone does not establish adequate response. Measure each total moving mass, including the force probe and added bars.
Convert both channels to the same right-positive force convention. Oppositely facing force probes can have matching raw signs because their local positive directions differ; check each sign by a gentle push of known direction before the run. Overlay and , and also examine their signed sum. Integrate both over the same contact interval to compare impulses. Repeat with added mass on one cart, exchange the probes between carts, and check unloaded zeros before and after. These controls help distinguish a physical mass change from a channel offset or gain error.
Agreement within measurement error supports the pair-interaction model over the resolved interval; it does not establish exact equality at arbitrarily short time scales. Misalignment, a loose mounting, sensor-beam dynamics, saturation, unequal timing, and zero drift can spoil the comparison. Track friction and cable pulls are additional external forces; a probe measuring bumper contact need not measure the entire net force on its cart. If a massive connector carries appreciable changing momentum, compare the full cart–connector collection rather than assuming its endpoint forces are an instantaneous cart-to-cart pair. The constructed pulse diagram above illustrates what to compare, and supplies no measurements from this apparatus.
A normal force is a contact force perpendicular to the constraining surface. It supplies support without being identical to gravitational weight: its magnitude depends on the other forces and the body's acceleration. For a body at rest on a horizontal scale with no other vertical forces, it equals . A freely falling body has no supporting normal force, despite its nonzero gravitational weight; this distinction defines the scale's apparent weight.




