For a particular decision tree , its decision-tree query cost is the number of queries along the graph path followed by input . Its actual tree depth isThe query vertices count as operations; each is followed by one answer edge. Thus a leaf reached after queries has graph path length , and a tree consisting only of an output leaf has depth zero. With no repeated coordinates, . The decision-tree depth minimizes over all correct decision trees for ; measures the chosen algorithm, while measures the Boolean function.
Choose an input probability distribution and let have that distribution. Then is a random variable even when the decision tree is deterministic. Its probability mass function describes how often each path length occurs, and its expected value is the expected query cost. None of these quantities changes the actual maximum depth of .
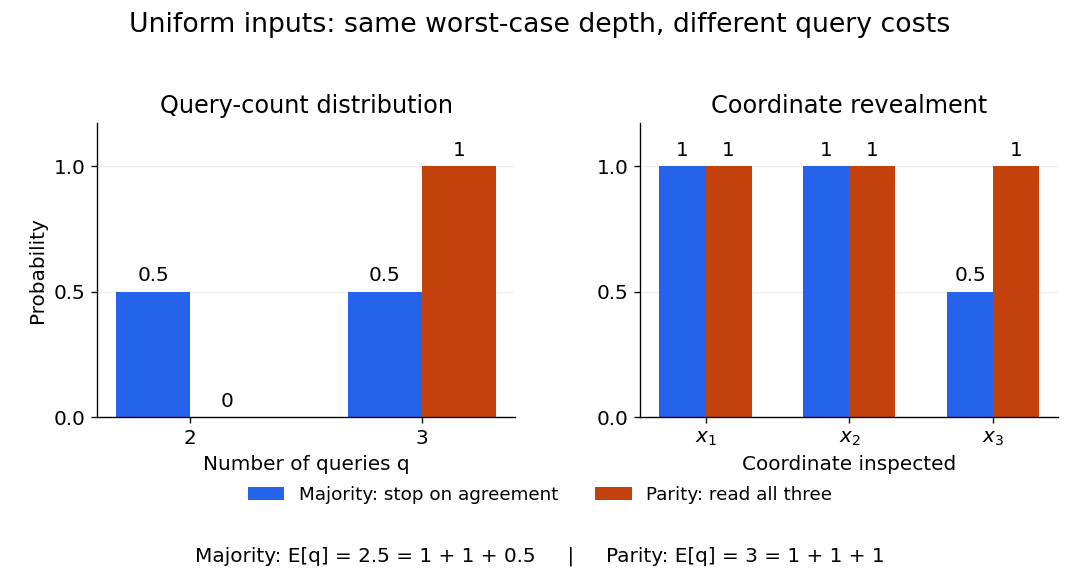
Uniform three-bit inputs: query-count distributions and coordinate revealment for majority and parity
. Details. 
The left panel aggregates the eight inputs from the three-bit majority decision tree: four cost two queries and four cost three. Parity always costs three. The right panel asks a different question, which coordinates are inspected: the majority function algorithm always queries coordinates 1 and 2, but queries coordinate 3 only on disagreements. These are probabilities of inspection, not probabilities that a bit equals one.
For a fixed decision tree and input probability distribution , its expected query cost isUnder the discrete uniform distribution on the eight three-bit inputs, the three-bit majority decision tree hasThis is an exact average, not a fractional query made during one execution. It is also optimal among exact deterministic decision trees under this discrete uniform distribution: one observed bit never determines the majority function; whichever two distinct coordinates are inspected first, their values disagree with probability , forcing a third query. In comparison, querying all three bits unconditionally has the same actual depth three but expected query cost three.
For an arbitrary input probability distribution, the same fixed three-bit majority decision tree gives . For three independent random variables, each a Bernoulli random variable with common one-probability , this becomes ; the value depends on . Averaging over inputs should also be distinguished from averaging over an algorithm's internal random choices at a fixed input.[ref]
The coordinate revealment of coordinate for a decision tree under input probability distribution isIt depends on the chosen decision tree and the probability distribution, not just on the Boolean function. Since no coordinate is queried twice on a graph path, indicator functions giveThe second equality uses linearity of expectation; it does not require independence of random variables or a product measure. The cited paper defines these inspection probabilities and their sum for product measures; the displayed indicator function argument extends the identity to any input probability distribution.[ref]
For the three-bit majority decision tree under the discrete uniform distribution, , whose sum is . Reading coordinate 3 first, then coordinate 1, and stopping on agreement gives the same majority function, depth and expected query cost, but coordinate revealments . The asymmetry belongs to the chosen query order. Parity gives for every exact decision tree without repeated queries. If repeated queries were charged, inspection probabilities would count distinct coordinates; total query count would instead require expected multiplicities.
Articles by others on the same topic
There are currently no matching articles.