This initial value problem uses a square root and absolute value to define a continuous function on all of . For every finite waiting time , a forward solution of a differential equation on isThe constant solution of a differential equation is another choice. For example, at , waits give values . These are dimensionless mathematical trajectories; no measured physical waiting time is being supplied.
Verification uses the original ordinary differential equation, including the join. Before departure, both and vanish. For , their common value is . For , the difference quotient at the join isThus the derivative exists at , equals the rate law there, and is continuous across the join. For the same computation gives the right derivative at the starting endpoint. For , the left and right second derivatives at departure are and : these forward solutions of a differential equation are continuously differentiable functions, without being twice differentiable at departure. The local two-sided statement of the Peano existence theorem is separate from this explicitly forward family.
The rate law tends to zero as , but its secant slopes from zero are unbounded:No finite local Lipschitz constant exists at zero. At the quotient is , even though the rates are shrinking to zero. Continuity controls the rate itself; Lipschitz continuity would control its change relative to the state displacement.
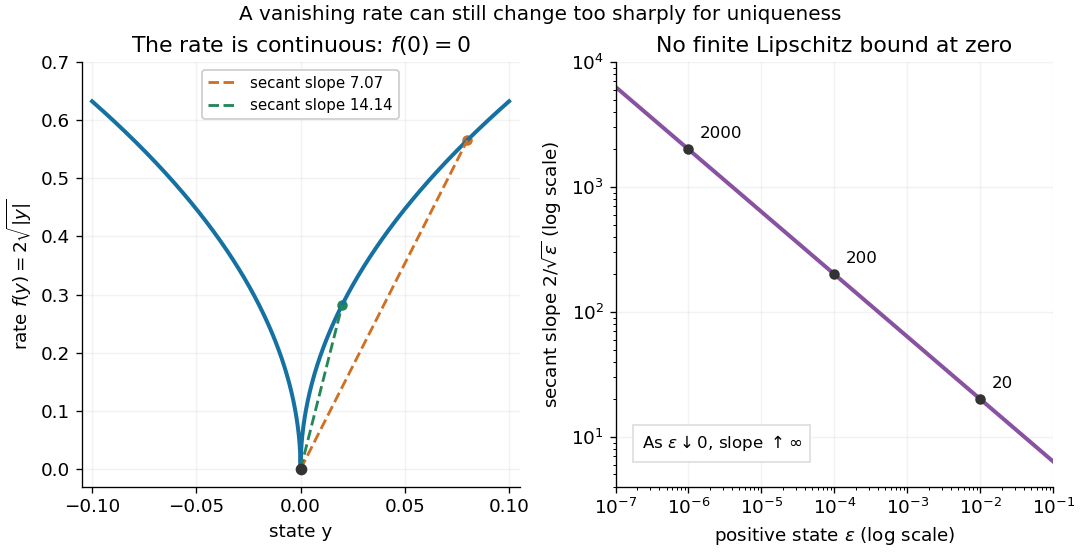

There is also a numerical lesson. The forward Euler method starting exactly at zero gives at every step. It reproduces the constant solution of a differential equation for every positive step size, while the moving trajectories remain equally valid. A computation producing one trajectory cannot establish uniqueness. Likewise, the separable differential equation calculation that divides by only describes the moving pieces: checking the original equation recovers the zero pieces and their joins.
For the autonomous differential equation , the real solutions are nondecreasing and lie in . On each nonconstant interval, separation of variables gives , so the solution crosses from to in exactly time . Every nonconstant solution on the entire real time axis is consequentlyfor some real . The two constant solutions complete the list; solutions on shorter intervals are restrictions of these. At the joins both the derivative and the right-hand side are zero, so these are continuously differentiable functions. The right-hand side is continuous but fails Lipschitz continuity at both endpoints, allowing arbitrary waiting time at before departure. Once reaches , monotonicity forces it to stay there. The sine representation without the nonnegative-cosine restriction would incorrectly introduce decreasing pieces.
Articles by others on the same topic
There are currently no matching articles.